
Headwind, in the context of flight technology, refers to any wind blowing in the opposite direction to an aircraft’s intended or actual flight path. Far from a mere meteorological curiosity, headwind is a critical aerodynamic force that profoundly impacts the performance, stability, and operational parameters of any flying machine, especially advanced drones equipped with sophisticated flight technology. Understanding its dynamics and how flight systems respond to it is paramount for efficient, safe, and precise aerial operations.
The Fundamental Dynamics of Headwind
Headwind fundamentally alters the air an aircraft is moving through, creating a complex interplay between the aircraft’s own thrust and the external atmospheric forces. This dynamic interaction necessitates advanced technological responses to maintain desired flight characteristics.
Defining Headwind and its Aerodynamic Impact
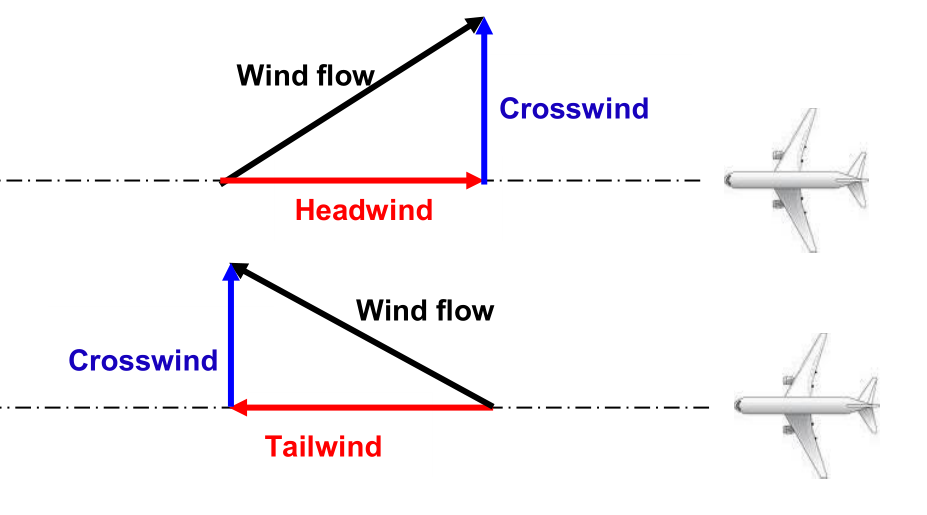
At its core, headwind is the component of the ambient wind vector that is directly opposed to the aircraft’s direction of motion relative to the ground. For instance, if a drone is flying due north, and the wind is blowing from the north, it is experiencing a direct headwind. The crucial distinction lies between airspeed and groundspeed. Airspeed is the speed of the aircraft relative to the air it is moving through, which directly determines the lift and drag forces generated by its airframe and propellers. Groundspeed, conversely, is the speed of the aircraft relative to the ground. When flying into a headwind, an aircraft’s airspeed will be higher than its groundspeed. For example, a drone flying at 30 mph into a 10 mph headwind will have an airspeed of 30 mph but a groundspeed of only 20 mph.
This disparity has direct aerodynamic consequences. While a higher airspeed into the wind provides greater lift and control authority (useful during takeoff or landing), it also significantly increases aerodynamic drag. This increased drag requires more thrust from the propulsion system to maintain a given groundspeed, leading to higher power consumption and reduced efficiency. Conversely, flying with a tailwind (wind in the same direction as flight) results in lower airspeed relative to the groundspeed, decreasing drag but also reducing lift and control effectiveness if not properly managed by flight control systems. The challenge for flight technology is to constantly balance these variables to ensure stable and controlled flight.
Quantifying Wind: Speed and Direction
Accurate quantification of wind speed and direction is a foundational requirement for any sophisticated flight technology. Wind is a three-dimensional phenomenon, constantly varying in both speed (magnitude) and direction (vector). Wind speed is typically measured in knots, miles per hour (mph), or meters per second (m/s). Direction is usually given as the direction from which the wind is blowing, referenced to true north (e.g., a 270-degree wind is from the west).
Advanced flight systems integrate various sensors and data sources to assess current and predicted wind conditions. While basic drones may rely on pre-flight weather reports or onboard GPS drift detection, more advanced platforms might incorporate pitot tubes (to measure true airspeed and derive wind), multi-axis accelerometers, gyroscopes, and even advanced air data computers to estimate effective wind vectors in real-time. This real-time data is fed into the flight controller, allowing for immediate adjustments to propulsion and control surfaces, ensuring the drone maintains its intended trajectory and stability despite fluctuating wind forces. Without precise wind quantification, optimal flight performance and safety cannot be guaranteed.
Headwind’s Demands on Drone Flight Technology
The presence of headwind imposes considerable demands on the various technological subsystems of a drone. These demands require robust design and sophisticated algorithmic solutions to maintain performance and operational integrity.
Propulsion Systems and Energy Consumption
One of the most immediate and significant impacts of headwind is on the drone’s propulsion system and subsequent energy consumption. To maintain a desired groundspeed against a headwind, the drone must generate more thrust than it would in still air. This is because the flight controller commands the motors and propellers to spin faster or at a higher pitch to achieve the necessary airspeed for controlled flight and to overcome the increased drag created by the opposing airflow.
The increased power output from the motors directly translates to higher current draw from the battery. This accelerated energy depletion significantly reduces the drone’s effective flight time and operational range. For a drone engineered for a 30-minute flight in calm conditions, a moderate headwind could easily reduce that to 20 minutes or less, necessitating dynamic adjustments in flight planning and mission execution. Flight technology addresses this through efficient motor and propeller design, optimizing the thrust-to-weight ratio, and implementing advanced power management units that can dynamically adjust voltage and current delivery based on real-time load, attempting to maximize efficiency even under strenuous conditions.
Flight Control and Stabilization
Headwind presents a continuous challenge to a drone’s flight control and stabilization systems. Modern drones rely on sophisticated Inertial Measurement Units (IMUs) — comprising accelerometers and gyroscopes — to sense their orientation and movement in three-dimensional space. These sensor inputs are fed into the flight controller, which then uses Proportional-Integral-Derivative (PID) control loops to adjust motor speeds rapidly, counteracting external disturbances like wind gusts and maintaining the desired attitude and position.
In a headwind, the flight controller must constantly work to maintain the drone’s attitude (pitch, roll, yaw) and stabilize its position, especially when attempting to hover or fly a precise path. Strong headwinds can induce unwanted pitch changes or horizontal drift. The PID loops must be finely tuned to provide sufficient responsiveness without overshooting or creating oscillations. Advanced flight controllers integrate sensor fusion techniques, combining IMU data with GPS, barometric altimeter, and sometimes even optical flow sensors or radar to provide a more accurate and robust estimation of the drone’s state relative to both the air and the ground, enabling more effective stabilization against wind forces.
Navigation Accuracy and Waypoint Following
Navigation accuracy and the ability to precisely follow pre-programmed waypoints are severely tested by headwind. While GPS provides accurate global positioning, it reports the drone’s groundspeed and ground position. The flight controller, however, needs to understand the drone’s airspeed and its movement through the air to command the correct thrust and attitude adjustments. In a headwind, the drone’s heading (the direction its nose is pointing) might differ significantly from its true ground track (the direction it’s actually moving over the ground) if it’s crabbing to maintain a straight line.

Waypoint following algorithms must account for this discrepancy. Basic systems might simply try to push the drone towards the waypoint, struggling inefficiently. Advanced navigation technology employs wind compensation algorithms that estimate the real-time wind vector and proactively adjust the drone’s heading and airspeed to ensure it maintains the most efficient and accurate ground track toward its next waypoint. This might involve pitching the drone slightly into the wind or crabbing its nose to maintain a direct line over the ground. Without such technological sophistication, navigation in headwind conditions can result in off-course deviations, increased flight time, and higher power consumption.
Technological Solutions for Headwind Mitigation
Flight technology has continually evolved to develop sophisticated solutions that mitigate the adverse effects of headwind, enhancing both performance and safety. These advancements span hardware, software, and intelligent algorithmic approaches.
Advanced Flight Controllers and Sensor Fusion
The core of modern wind mitigation lies within advanced flight controllers and their ability to perform sophisticated sensor fusion. Current flight controllers are powerful microcomputers capable of processing vast amounts of data from multiple sensors simultaneously. By fusing data from GPS, IMUs (accelerometers, gyroscopes, magnetometers), barometers, and sometimes even dedicated airspeed sensors (like pitot tubes on fixed-wing drones or more advanced multi-rotor systems), the flight controller can create a highly accurate real-time estimate of the drone’s state, including its true airspeed, groundspeed, and the effective wind vector.
This comprehensive environmental awareness allows for more precise and proactive control adjustments. Instead of merely reacting to observed drift, the flight controller can predict the impact of wind and command pre-emptive corrections. For example, if the system detects a strong crosswind component alongside a headwind, it can automatically adjust the drone’s yaw and pitch simultaneously to maintain a stable ground track, minimizing energy waste and maximizing control authority. This level of integrated sensing and intelligent processing is a hallmark of cutting-edge flight technology.
Aerodynamic Design and Propulsion Optimization
Beyond intelligent control, fundamental improvements in aerodynamic design and propulsion systems play a crucial role in headwind mitigation. Aerodynamic efficiency reduces drag, meaning less power is required to overcome wind resistance. This includes designing more streamlined airframes, optimizing propeller shapes for specific thrust-to-power ratios, and ensuring that the overall mass of the drone is as low as possible without compromising structural integrity.
Propulsion systems are continuously being optimized for efficiency across a wider range of operating conditions. This involves developing more powerful yet lighter motors, designing propellers with advanced airfoils that maintain efficiency at varying RPMs and airspeeds, and integrating electronic speed controllers (ESCs) that precisely manage motor power output. Some advanced systems even incorporate variable pitch propellers, allowing for more dynamic control over thrust and efficiency across different flight regimes and wind conditions. The synergy between optimized aerodynamics and highly efficient propulsion systems allows drones to maintain performance and extend endurance even when battling significant headwinds.
Intelligent Flight Planning and Adaptive Algorithms
Perhaps one of the most proactive technological solutions is the integration of intelligent flight planning and adaptive algorithms. Instead of rigidly following a pre-defined path, these systems can dynamically adjust mission parameters in real-time based on environmental conditions. This includes integrating live weather data and predictive wind models into the mission planning software. Before launch, the system can analyze the expected wind conditions along the entire flight path and suggest a more wind-favorable route, perhaps taking a slightly longer path to avoid strong headwind segments or capitalizing on tailwinds where possible.
During flight, adaptive algorithms continuously monitor the drone’s performance against the actual wind conditions. If an unexpected headwind is encountered, the algorithm can:
- Adjust speed: Reduce groundspeed to conserve battery if the mission is time-flexible.
- Alter altitude: Search for layers of less turbulent or weaker wind.
- Optimize heading: Calculate the optimal crabbing angle to minimize drag while maintaining the ground track.
- Prioritize tasks: If battery life becomes critical due to sustained headwind, the system might autonomously decide to return to home or prioritize critical data acquisition before returning.
These adaptive capabilities, driven by advanced AI and machine learning techniques, move beyond simple reactive control to proactive and intelligent decision-making, significantly enhancing the drone’s resilience and efficiency in challenging headwind environments.
Operational Mastery in Windy Conditions
While flight technology provides advanced solutions, operational mastery remains crucial. Effective use of these technologies, combined with sound operational practices, ensures safe and successful missions even when facing headwinds.
Pre-Flight Wind Assessment and Risk Management
A thorough pre-flight wind assessment is the first line of defense against headwind challenges. Pilots and mission planners must consult detailed weather forecasts, including wind speed, direction, and gust potential, specifically for the operational area and altitude. Advanced drone mission planning software often integrates real-time weather feeds, allowing for a more accurate risk assessment. It is vital to understand the drone’s published wind resistance limits and to establish clear go/no-go criteria based on these limits and the mission’s objectives. Operating beyond these limits significantly increases the risk of loss of control, battery depletion, or structural failure, even with advanced flight technology.
In-Flight Telemetry Monitoring and Pilot Intervention
During flight, continuous monitoring of telemetry data is essential. Modern flight technology provides real-time readouts of crucial parameters such as groundspeed, airspeed, battery voltage, current draw, and estimated remaining flight time. Observing a sustained high current draw or a rapidly decreasing estimated flight time in headwind conditions alerts the pilot or autonomous system to potential issues. Pilots must be prepared to intervene, overriding autonomous modes if necessary, to safely land the drone or alter the mission plan based on actual conditions. The ability of the flight control system to provide clear, actionable telemetry data is paramount for informed decision-making.

Strategic Mission Planning and Battery Management
Strategic mission planning takes into account known or predicted headwind conditions. This involves planning routes that minimize direct headwind exposure, perhaps flying against the wind on the outbound leg (when the battery is full) and with a tailwind on the return leg (to conserve power for landing), or choosing altitudes where wind conditions are more favorable. Advanced battery management systems within flight technology constantly calculate remaining energy and predict endurance based on current consumption rates and environmental factors. This allows for dynamic adjustments to the mission, such as initiating an early return-to-home sequence if headwind causes unexpected battery drain, ensuring a safe recovery before critical power levels are reached.