
Beyond the Green Felt: Game Theory Optimal’s Broader Implications for Tech
While the acronym GTO, or Game Theory Optimal, is most commonly associated with the intricate strategic depths of card games like poker, its underlying principles are far more expansive. At its core, GTO represents a mathematically derived strategy that is unexploitable by any opponent, assuming perfect play from all parties involved. This pursuit of an equilibrium, where no player can improve their outcome by unilaterally changing their strategy, extends far beyond recreational or professional gaming. In the realm of cutting-edge technology and innovation, particularly within the burgeoning field of autonomous systems and unmanned aerial vehicles (UAVs), the concepts inherent in Game Theory Optimal play offer profound insights into designing robust, efficient, and intelligent systems. Understanding GTO, even if its popular context is a card game, unlocks a framework for optimizing decision-making in complex, dynamic, and often unpredictable environments.
The Core Tenets of Game Theory Optimal Play
Game theory, the mathematical study of strategic interaction, provides the foundation for GTO. It analyzes situations where multiple rational agents make decisions that affect each other’s outcomes. A “Game Theory Optimal” strategy is one that maximizes an agent’s expected outcome given the actions of other agents, without being vulnerable to exploitation. This isn’t about predicting an opponent’s specific moves, but rather about developing a strategy so balanced and robust that it remains effective regardless of how the opponent plays, as long as they too are aiming to maximize their own outcomes.
Key concepts in GTO include:
- Mixed Strategies: Rather than always making the same move in a given situation, a GTO strategy often involves randomizing actions with specific probabilities. This unpredictability prevents an opponent from consistently exploiting a deterministic pattern.
- Nash Equilibrium: A state where no participant can gain by a unilateral change of strategy if the strategies of the others remain unchanged. GTO strategies often seek to establish or leverage a Nash Equilibrium.
- Exploitability: The degree to which a strategy can be taken advantage of by an opponent. A true GTO strategy has zero exploitability against a perfect opponent.
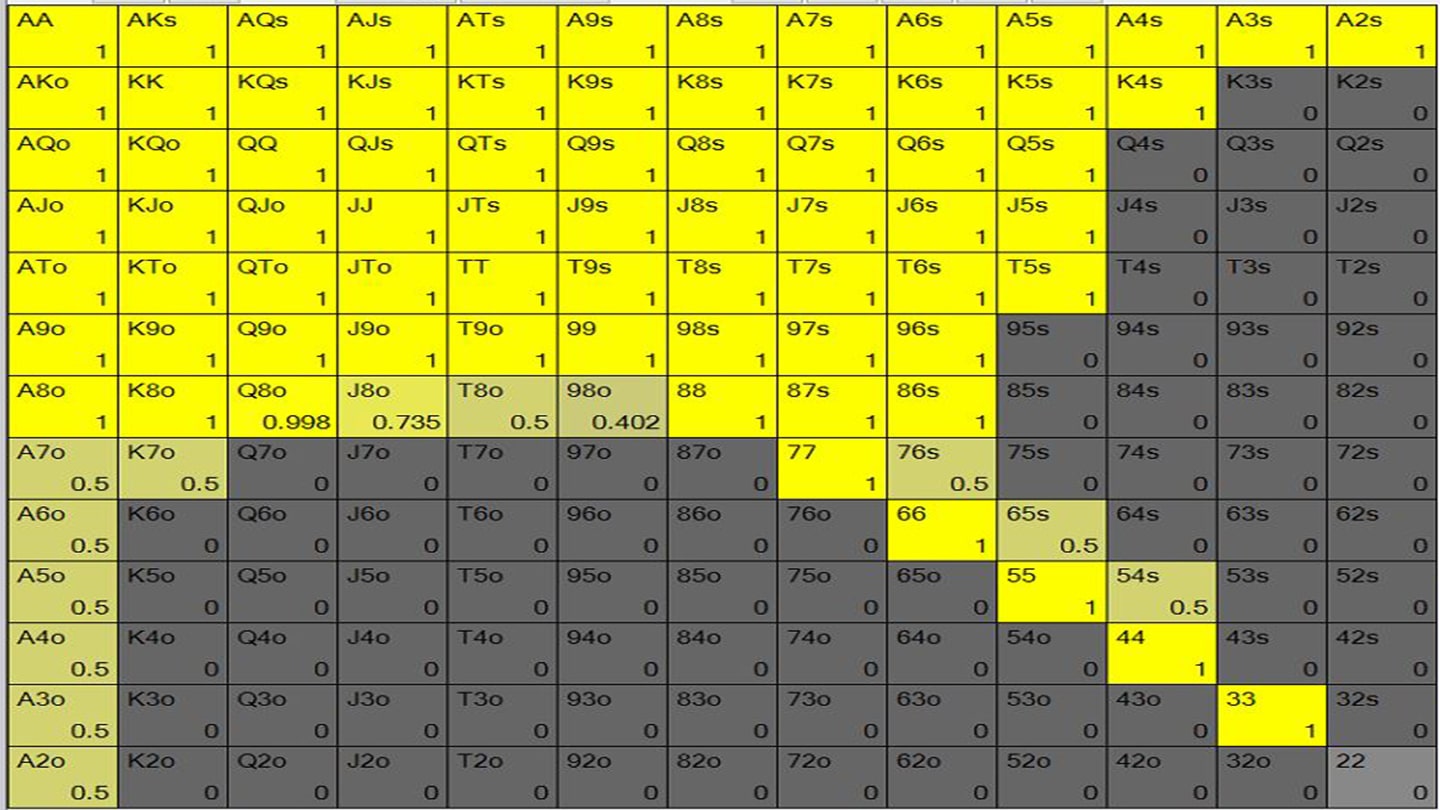
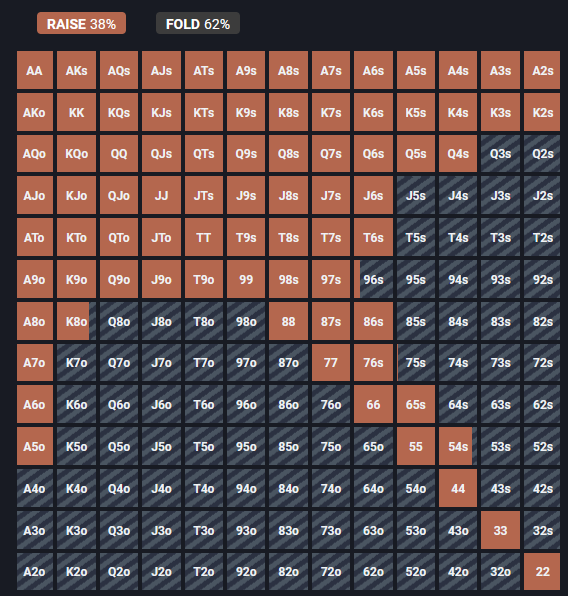
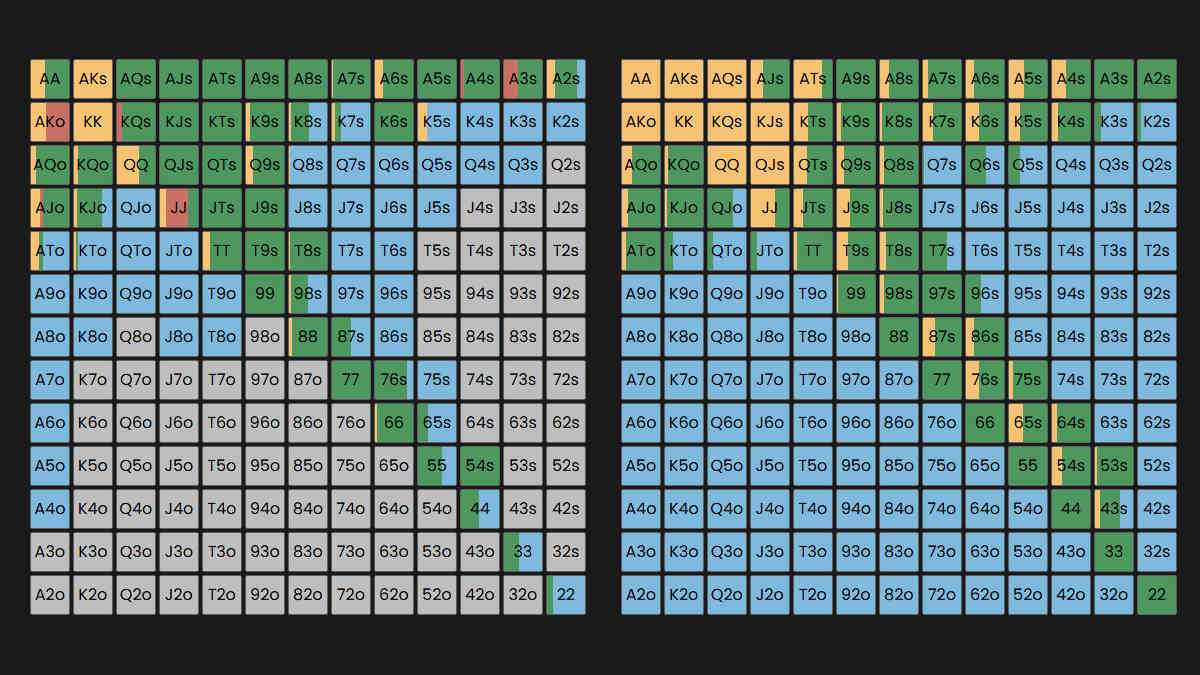
For instance, in traditional applications like poker, GTO dictates how often to bluff, how often to call, and how to size bets, all based on mathematical probabilities and opponent ranges, ensuring that no single line of play can be consistently profitable against it. Transferring this intellectual framework to the domain of autonomous flight involves rethinking how UAVs perceive, decide, and act in environments populated by other drones, human operators, and dynamic obstacles, striving for an equally unexploitable and robust operational paradigm.
GTO Principles in Autonomous Flight and AI
The application of GTO principles to autonomous flight systems promises a new era of UAV intelligence. As drones take on increasingly complex roles, from urban delivery to sophisticated surveillance and environmental monitoring, their onboard AI must navigate environments fraught with uncertainty and potential interaction with other agents. Designing AI that operates optimally, and is resilient to unforeseen circumstances or even intentional interference, aligns perfectly with the goals of Game Theory Optimal strategy.
Robust Decision-Making for UAVs
In an operational context, a drone equipped with GTO-inspired AI would exhibit a heightened level of robustness. This means its decision-making processes are not easily disrupted or exploited. Consider a drone tasked with navigating a complex urban landscape. Its sensors detect numerous dynamic elements: other flying objects, sudden gusts of wind, changes in building reflections affecting GPS, or even potential jamming attempts. A GTO-driven AI would not just follow a pre-programmed path or react to immediate threats; it would employ mixed strategies, varying its flight parameters, altitudes, or speeds with calculated probabilities, making it harder to predict or intercept. This inherent unpredictability, derived from optimal randomization, enhances security and operational reliability, especially in contested airspace or sensitive missions where adversarial elements might be present. By developing flight parameters that achieve maximum mission success rate while minimizing vulnerabilities, UAVs can effectively counter unpredictable external factors.
Optimizing Navigation and Route Planning
Traditional drone navigation often relies on deterministic algorithms that calculate the shortest or most energy-efficient path. While effective in static, predictable environments, these methods can be suboptimal when faced with dynamic variables or intelligent adversaries. GTO principles offer a paradigm shift, enabling drones to:
- Adaptive Route Generation: Instead of a single optimal path, a GTO approach might generate a probability distribution of optimal paths. The drone then randomly selects from these, ensuring that its trajectory is not a fixed target, making it less vulnerable to tracking or interception.
- Dynamic Obstacle Avoidance: When encountering moving obstacles (other drones, birds, shifting weather patterns), a GTO algorithm would calculate optimal evasive maneuvers that account for the potential ‘strategies’ of these obstacles, minimizing collision risk while maintaining mission objectives. This might involve not always taking the shortest evasion route, but rather a less predictable, yet equally safe, path.
- Resource Management Under Uncertainty: GTO can also inform optimal battery usage, sensor activation schedules, or data transmission strategies when resources are finite and environmental conditions (e.g., signal interference, changing light conditions) are uncertain. By framing these as strategic interactions against an unpredictable “environment,” drones can make more resilient resource allocation decisions.
Multi-Drone Coordination and Swarm Intelligence
The true power of GTO in drone technology becomes even more apparent in multi-drone systems and swarm intelligence. Here, multiple agents interact, either cooperatively or competitively, to achieve a common goal or outmaneuver an opponent. This is a classic domain for game theory.
Strategic Interaction in Drone Formations
Imagine a swarm of drones tasked with covering a large area for search and rescue, or performing a coordinated aerial display. In such scenarios, each drone’s actions affect the others. GTO principles can be applied to optimize the collective behavior of the swarm:
- Cooperative Search: Drones can use GTO to randomize their search patterns within assigned sectors, ensuring maximal coverage while minimizing redundant effort, even if individual communication is intermittently lost or if certain drones fail. This makes the overall search operation robust against single points of failure.
- Coordinated Movement: For complex aerial maneuvers or formations, GTO can help design protocols where each drone’s movement is optimized in relation to its neighbors, preventing collisions and maintaining formation integrity even in the face of external perturbations or strategic repositioning by an “adversary” (e.g., strong wind currents).
- Target Tracking and Interception: If a drone swarm is tracking a moving target, GTO can dictate optimal pursuit and containment strategies, where each drone’s position and velocity are part of a coordinated, unexploitable plan to box in or follow the target, even if the target itself is attempting evasive maneuvers.
Mitigating Adversarial Challenges
In scenarios involving competing or adversarial drone operations (e.g., military applications, or even highly competitive drone racing), GTO provides a framework for designing strategies that are resistant to exploitation.
- Counter-UAS Strategies: GTO can inform defensive strategies against hostile drones, optimizing sensor deployment, electronic countermeasures, or kinetic interception based on the predicted (or optimally unpredictable) behavior of the adversary.
- Competitive Flight Paths: In drone racing, a GTO-inspired AI might randomize its approach to gates or turns, making it harder for an opponent to predict and cut off its path. It focuses on maximizing its own performance while simultaneously making it difficult for opponents to gain a predictable advantage.
- Information Asymmetry: GTO can also guide strategies where drones purposefully withhold or obscure information (e.g., true intentions, exact trajectory) to gain an advantage, similar to a poker player masking their hand strength.
Future Horizons: The Evolution of GTO in Drone Innovation
The integration of GTO principles into drone technology is still in its nascent stages, but the potential for enhancing intelligence, autonomy, and resilience is immense. As AI and machine learning continue to evolve, so too will the sophistication of GTO applications.
Learning Algorithms and Adaptive GTO
Current GTO models often rely on perfect information or clearly defined game trees. However, real-world drone operations involve imperfect information and constantly changing environments. Future innovations will see GTO principles integrated with adaptive learning algorithms:
- Reinforcement Learning for GTO: Drones could use reinforcement learning to discover and refine GTO-like strategies through trial and error in simulated or real-world environments. This would allow them to adapt to previously unseen scenarios and develop robust responses.
- Opponent Modeling: AI systems could learn to model the behavior patterns of other drones or environmental factors, and then use GTO to devise optimal counter-strategies tailored to those specific models, while still retaining general robustness.
- Dynamic Strategy Adjustment: As mission parameters change or new threats emerge, the drone’s GTO strategy could dynamically re-evaluate and adjust its probabilities and actions in real-time.
Ethical and Safety Considerations
Implementing GTO in autonomous systems also brings forth crucial ethical and safety considerations. Designing GTO-driven AI requires careful attention to ensuring that “optimal” behavior aligns with human values and safety standards.
- Predictable Unpredictability: While GTO emphasizes unpredictability to prevent exploitation, there must be a baseline of predictable, safe operation for human interaction and regulatory compliance. The randomization must occur within defined safety parameters.
- Fail-Safe GTO: In critical applications, GTO algorithms must incorporate fail-safe mechanisms and fallback strategies that prioritize human safety and property protection above all else, even if it means deviating from a purely GTO-optimal, but potentially risky, action.
- Transparency and Explainability: As GTO strategies become more complex, there will be a growing need for explainable AI, allowing human operators to understand why a drone made a particular GTO-informed decision, especially in incident analysis.
In conclusion, while “GTO poker” introduces a concept rooted in a popular card game, its underlying tenets of mathematical optimization, robust strategy, and unexploitability offer a powerful framework for advancing drone technology. By applying Game Theory Optimal principles, developers can engineer UAVs that are not only more intelligent and autonomous but also supremely resilient, adaptable, and capable of navigating the complex, dynamic skies of tomorrow with unparalleled strategic prowess. The pursuit of optimal, unexploitable strategies is a universal endeavor, extending its reach from the poker table to the boundless potential of autonomous flight.