
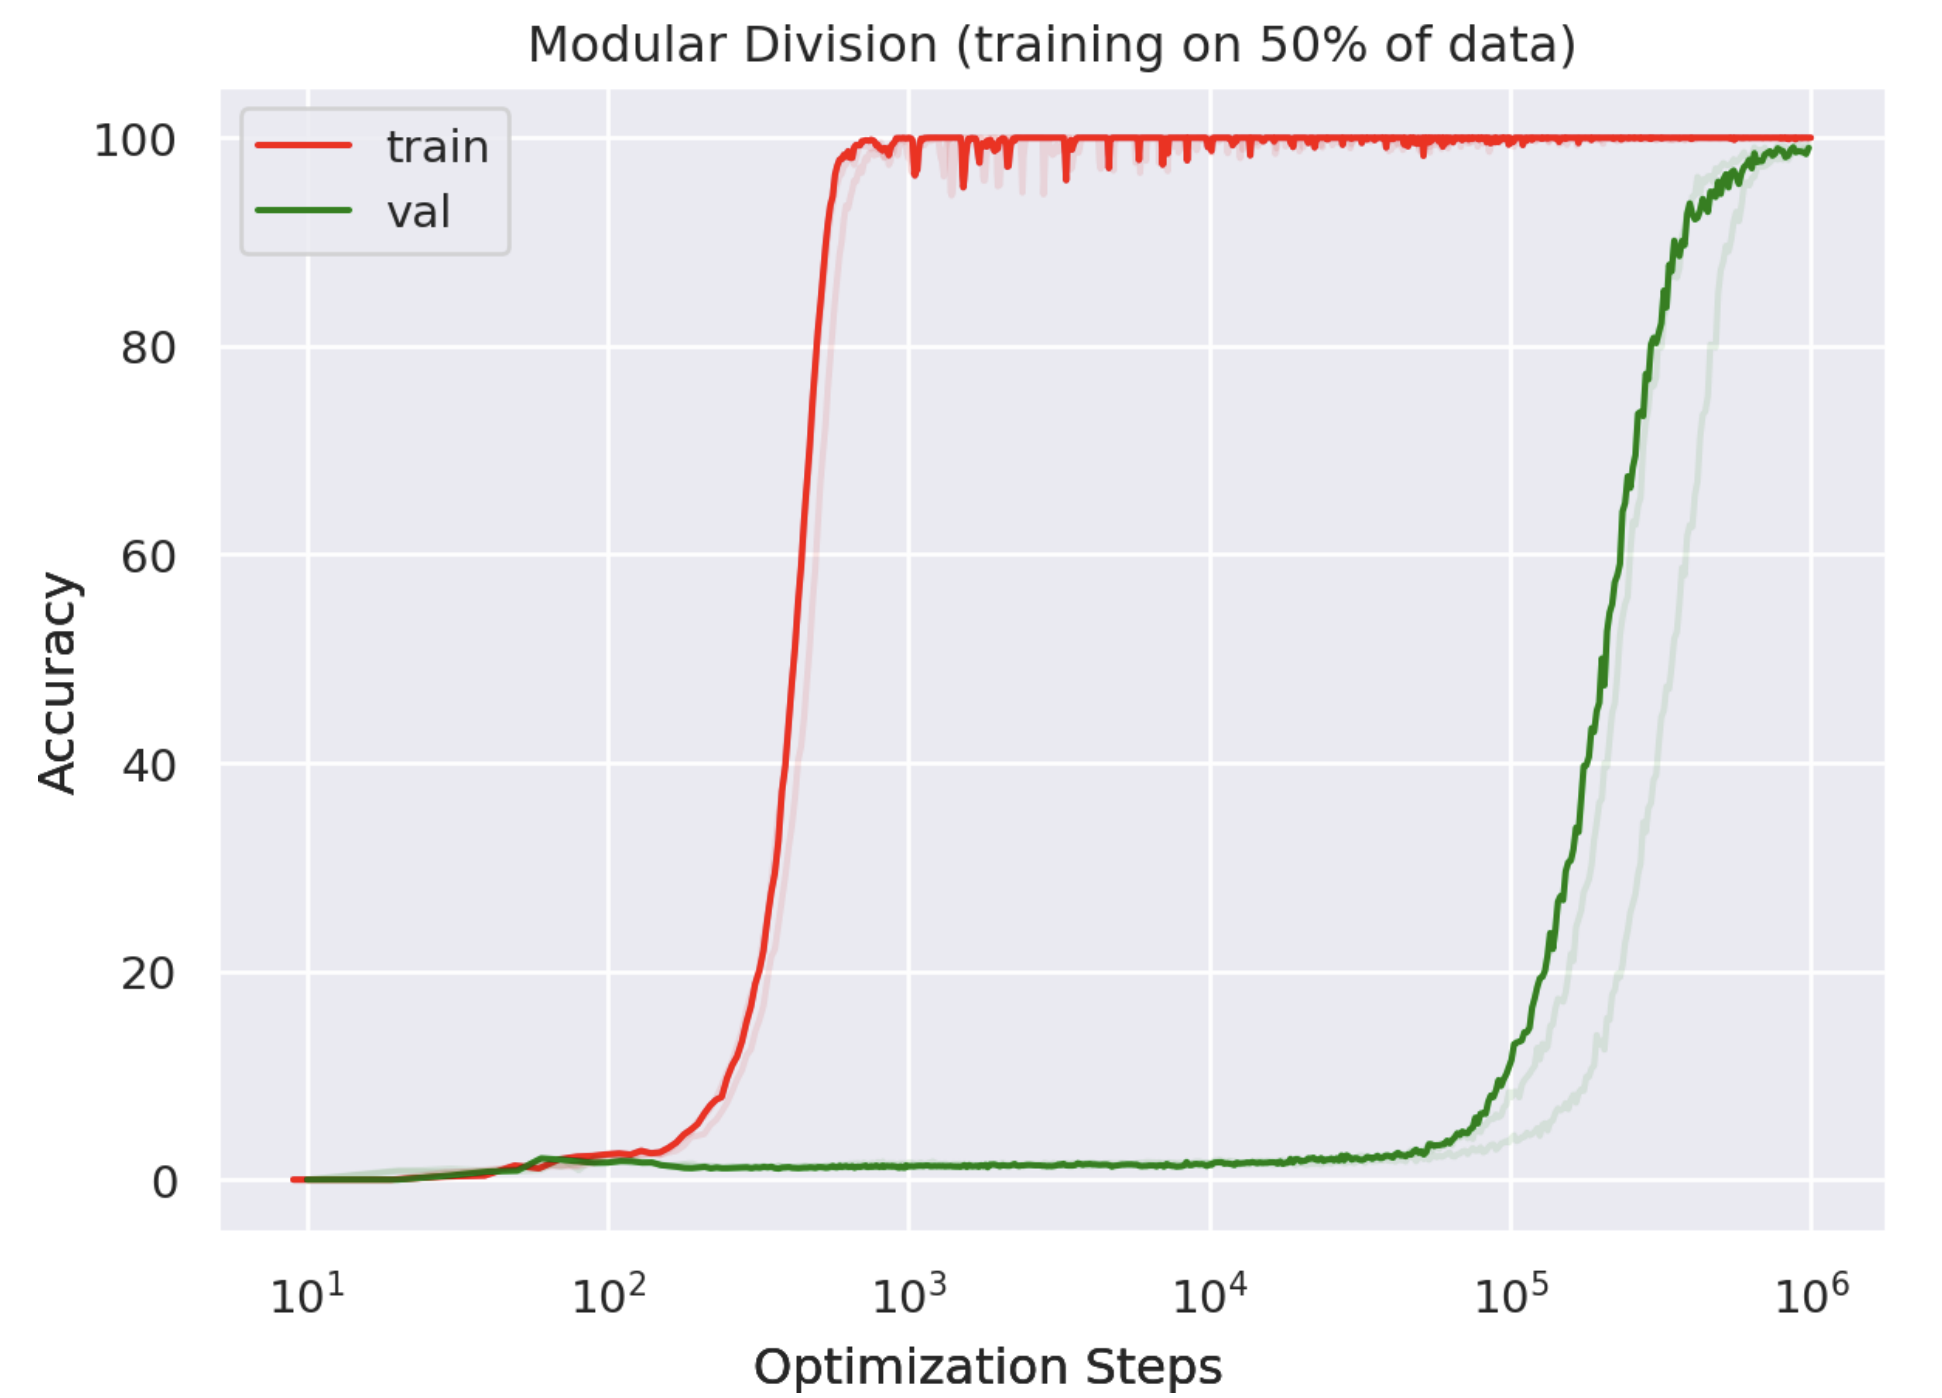
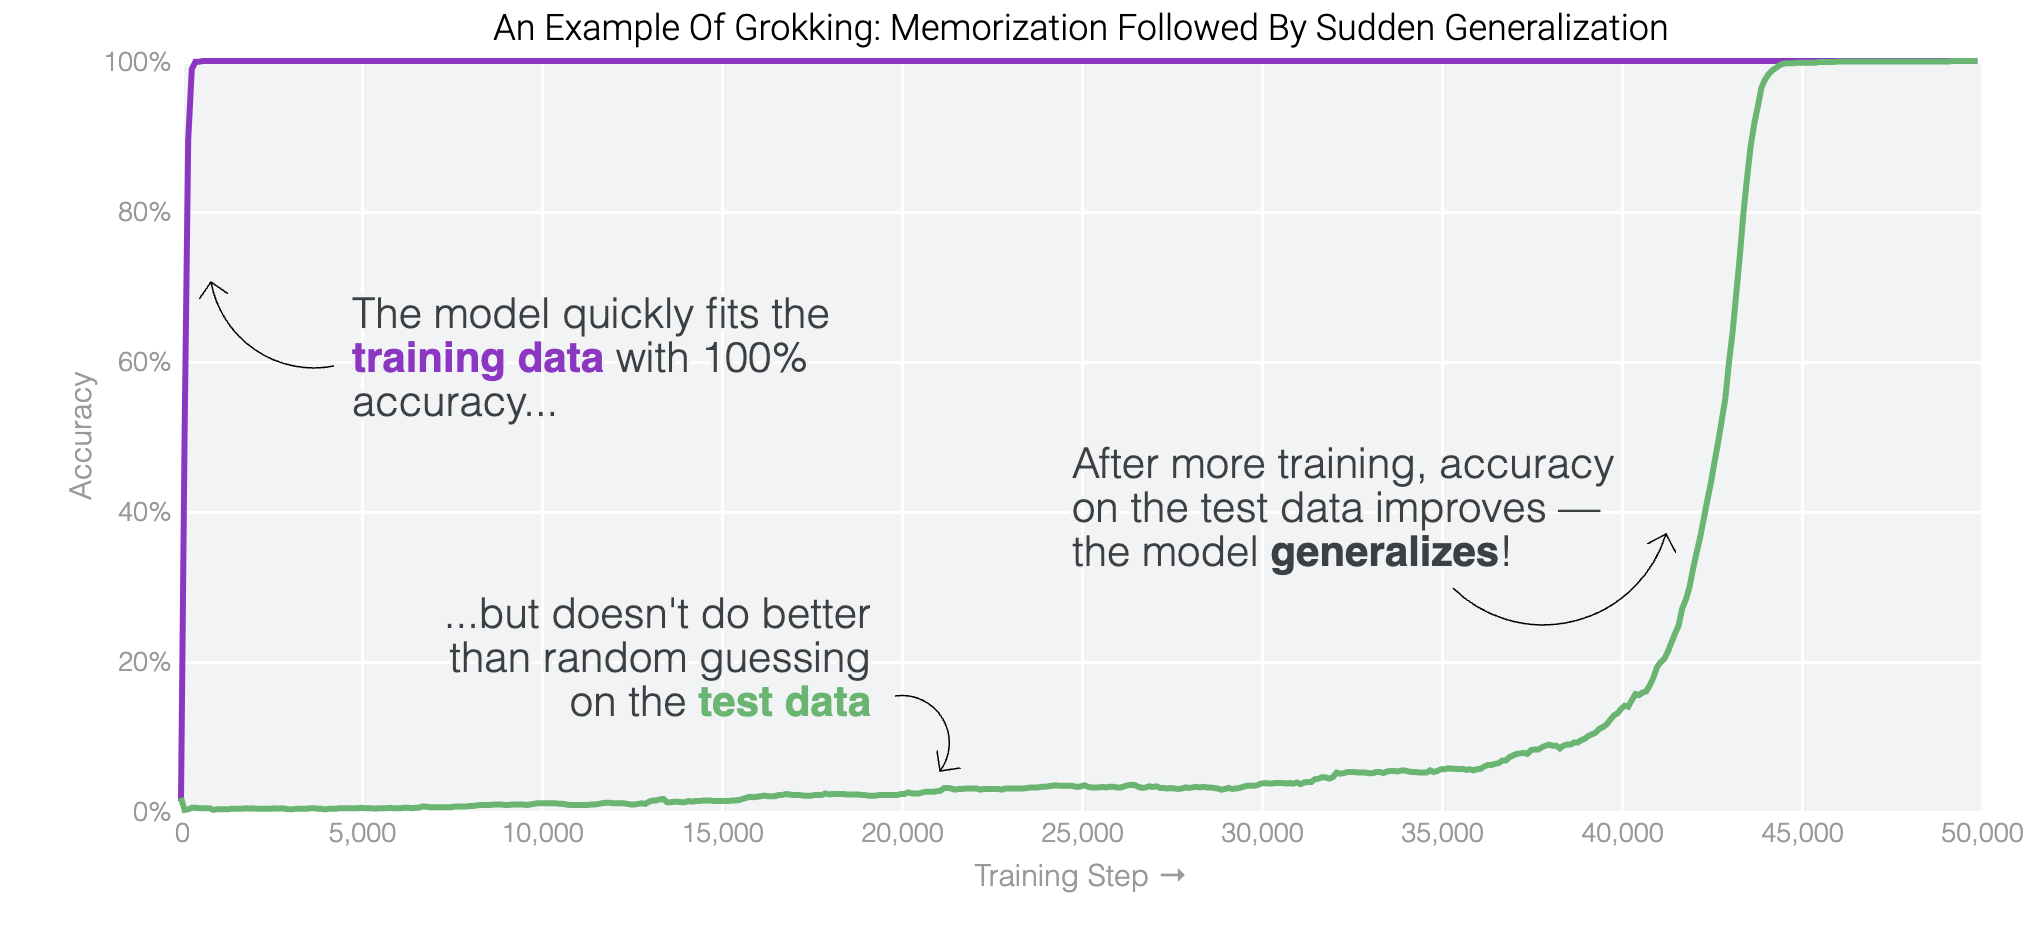
In the rapidly evolving landscape of artificial intelligence and its transformative applications across various industries, a peculiar and profound phenomenon known as “grokking” has emerged as a subject of intense interest and study. While the term itself originated in science fiction, its contemporary relevance within deep learning paradigms speaks volumes about the intricate ways AI models learn and generalize. For the realm of drone technology, particularly in areas like autonomous flight, advanced mapping, and intelligent remote sensing, understanding grokking is not merely an academic exercise; it offers a deeper insight into the foundational capabilities that empower these sophisticated aerial systems. Grokking, in essence, refers to the moment when a neural network, after fitting its training data perfectly, suddenly generalizes to unseen data with remarkable accuracy, often exhibiting a delayed and sometimes sudden improvement in performance on validation sets. It’s a leap from memorization to genuine understanding, a critical transition for AI systems operating in the unpredictable complexities of the real world.

Beyond Memorization: The Essence of Grokking in AI
The journey of an AI model from raw data ingestion to intelligent decision-making is often fraught with challenges, primarily the distinction between memorization and true generalization. Grokking represents a pivotal moment in this journey, particularly for deep learning architectures that power much of modern drone innovation.
Origins and Evolution of a Concept
The term “grok” was coined by Robert Heinlein in his 1961 novel Stranger in a Strange Land, signifying a profound, intuitive understanding so complete that the observer “becomes one with” the observed. It implies an empathic, comprehensive knowing that transcends mere factual recall. Decades later, this evocative term found an unexpected home in the lexicon of machine learning researchers. Initial observations of grokking in deep learning models, particularly those trained on algorithmic datasets, revealed a peculiar dynamic: models would first achieve zero training error—meaning they perfectly memorized the training data, even noisy or contradictory elements—and then, after a prolonged period of stagnant or slowly improving validation accuracy, suddenly “grok” the underlying pattern, leading to a dramatic increase in generalization performance. This unexpected delay and subsequent sudden leap in generalization challenged conventional understanding of overfitting and model learning dynamics.
Grokking in Machine Learning: A Deep Dive
From a technical perspective, grokking involves a phase transition. Initially, a model might overfit, meticulously learning every detail of the training data, including noise. However, instead of collapsing into a state of poor generalization, the model somehow extracts the underlying principles or rules that govern the data, allowing it to apply this understanding to new, unseen examples. Researchers have attributed grokking to various factors, including the interplay of weight decay (a regularization technique), model capacity, dataset size, and the specific architecture of the neural network. It suggests that deep learning models possess an inherent capacity to move beyond surface-level pattern matching to a more abstract, rule-based comprehension. This phenomenon underscores the non-linear and often counter-intuitive nature of deep learning optimization, where seemingly minor adjustments to hyper-parameters or training regimes can unlock a profound shift in a model’s capabilities.
The Challenge of Generalization
The primary goal of any AI system, especially one deployed in mission-critical applications like autonomous drones, is robust generalization. A drone’s navigation system, for example, must not just recognize obstacles it has seen during training but also novel obstacles in varied lighting and environmental conditions. Traditional overfitting, where a model performs well on training data but poorly on new data, is a persistent threat. Grokking offers a hopeful counter-narrative: it suggests that even after perfect memorization, there’s a potential for the model to “forget” the noise and truly learn the signal. This transition is crucial for building reliable and adaptable AI for drones, enabling them to operate safely and effectively in the complex, dynamic, and often unpredictable real world.
Grokking’s Impact on Autonomous Drone Systems
The capacity of AI models to grok underlying patterns rather than simply memorize makes them invaluable for enhancing the autonomy and intelligence of drone systems across diverse applications.
Enhanced Navigation and Obstacle Avoidance
Autonomous drones rely heavily on real-time data processing for navigation and obstacle avoidance. A drone’s onboard AI must interpret sensor data (from LiDAR, cameras, ultrasonic sensors) to identify flight paths, detect moving and stationary objects, and predict their trajectories. If the AI merely memorizes obstacle shapes or environmental layouts from its training, it will fail when encountering novel situations. Grokking, however, implies the AI has developed a fundamental understanding of what constitutes an obstacle, how to assess its distance and threat level, and the principles of safe navigation. This deeper comprehension allows drones to adapt to unexpected scenarios, navigate through complex environments like dense forests or urban canyons, and avoid collisions with previously unseen objects or dynamic threats such as rapidly appearing birds or shifting weather patterns. The ability to grok ensures robustness far beyond simple rule-based programming or rote memorization.
Intelligent Follow Mode and Object Recognition
For applications such as aerial filmmaking, search and rescue, or surveillance, drones often employ “intelligent follow mode,” where they track a subject autonomously. This requires sophisticated object recognition and prediction capabilities. A grokking AI in a follow-me drone doesn’t just recognize a specific human figure it was trained on; it understands the concept of a human, their typical movement patterns, and how to maintain optimal distance and angle despite changes in attire, lighting, or background. Similarly, in surveillance or reconnaissance, a grokking model can identify target objects (vehicles, specific infrastructure, wildlife) even under partial occlusion, varied orientations, or environmental camouflage, because it has grasped the essential features of the object rather than just its pixel-perfect appearance from training data. This elevates the reliability and versatility of AI-driven drone operations significantly.
Robust Decision-Making in Dynamic Environments
Drones operate in inherently dynamic environments where conditions can change rapidly. Wind gusts, sudden precipitation, varying light conditions, and unexpected human or animal intervention all contribute to an unpredictable operational space. An AI that has “grokking” capabilities can make more robust decisions because it has learned the underlying physics and environmental interactions, not just specific responses to specific inputs. For instance, if a drone’s AI has grokked the principles of aerodynamics and sensor behavior, it can better compensate for sudden wind changes or sensor noise, maintaining stable flight and mission parameters. This deeper understanding allows for more adaptive flight control, optimized energy consumption, and superior overall performance, enabling drones to execute complex missions with greater autonomy and less human intervention.
Advancing Mapping and Remote Sensing with Grokking AI
The capabilities unlocked by grokking extend profoundly into the fields of aerial mapping and remote sensing, transforming raw data into actionable insights with unprecedented precision.
Precision in Data Interpretation
In mapping and remote sensing, drones collect vast quantities of imagery (photographic, multispectral, thermal) and spatial data (LiDAR). The interpretation of this data is critical for applications ranging from agricultural yield prediction to infrastructure inspection and environmental monitoring. An AI model capable of grokking moves beyond simply classifying pixels; it understands the contextual relationships within the data. For example, in agriculture, a grokking AI can discern not just healthy versus unhealthy plants, but also why a plant is unhealthy (e.g., specific nutrient deficiencies, pest infestation patterns) by interpreting subtle textural, spectral, and temporal signatures across vast fields. This allows for hyper-localized interventions, optimizing resource use and improving outcomes significantly. Similarly, in infrastructure inspection, it can differentiate between cosmetic damage and structural integrity issues based on learned material properties and stress patterns rather than just visual anomalies.
Predictive Analytics and Anomaly Detection
One of the most powerful applications of grokking in remote sensing is its contribution to predictive analytics and anomaly detection. By grokking the ‘normal’ state and dynamics of an environment or object over time, an AI can accurately predict future states or identify deviations that signal emerging problems. For instance, in monitoring geological formations for landslides, a grokking AI can analyze subtle shifts in terrain elevation and vegetation patterns over months, predicting potential instability before it becomes visually evident. For pipeline surveillance, it can detect minute changes in ground temperature or vegetation stress that indicate a leak, significantly reducing response times and preventing environmental catastrophes. This predictive capability transforms remote sensing from reactive monitoring to proactive management, offering immense value in diverse sectors.
Creating Intelligent Digital Twins
The concept of a “digital twin” – a virtual replica of a physical asset or environment – is becoming central to smart infrastructure and urban planning. Drones are key to creating and updating these twins with real-time data. When the AI processing this data has grokking capabilities, these digital twins become truly “intelligent.” Rather than just being static models, they can simulate behaviors, predict maintenance needs, and optimize operations based on a deep understanding of the physical twin’s characteristics and environmental interactions. A grokking AI can continuously refine the digital twin, ensuring it accurately reflects changes and can be used for sophisticated “what-if” analyses, from simulating traffic flow in a smart city to optimizing energy consumption in a large industrial complex based on drone-collected thermal data and learned building physics.
The Future of Grokking in Drone Tech & Innovation
As research into grokking deepens, its implications for the future of drone technology promise even more profound advancements, pushing the boundaries of what autonomous aerial systems can achieve.
Towards Truly Autonomous and Adaptive UAVs
The ultimate goal for many drone applications is complete autonomy—UAVs that can operate independently for extended periods, adapt to unforeseen circumstances, and even learn new skills on the fly. Grokking is a cornerstone of achieving this vision. An AI that can grok environmental dynamics and mission objectives can enable drones to not only navigate complex terrains but also perform complex tasks with minimal human oversight, such as dynamic path planning in contested airspace, self-repair mechanisms through predictive diagnostics, or collaborative swarm intelligence where individual drones adapt their roles based on the collective’s grokked understanding of a mission. This level of adaptive intelligence will unlock new frontiers in exploration, logistics, and critical infrastructure management.
Ethical Considerations and Model Explainability
As AI models become more sophisticated and exhibit grokking behavior, the importance of model explainability (XAI) grows. When a drone’s AI makes a critical decision—such as altering a flight path to avoid an unexpected hazard or identifying a target during a sensitive mission—understanding why it made that decision is paramount. Research into grokking is shedding light on the internal mechanisms of neural networks, helping scientists dissect how models transition from memorization to generalization. This understanding is vital for building trust in autonomous systems, ensuring accountability, and addressing ethical concerns related to AI decision-making. Future drone regulations and ethical guidelines will undoubtedly demand greater transparency from AI systems, making insights from grokking research increasingly valuable.
Unleashing New Possibilities in Aerial Robotics
The full potential of grokking in drone technology is still being uncovered. As researchers refine models and training methodologies that encourage this deep understanding, we can anticipate a new generation of aerial robotics. These drones will be capable of tasks currently deemed impossible for autonomous systems, from highly nuanced manipulation tasks requiring extreme dexterity and real-time adaptation, to sophisticated environmental interactions for scientific discovery, or even autonomous exploration of unknown territories like planetary surfaces or deep caverns. Grokking represents a fundamental shift in AI’s capacity to learn, promising a future where drones are not just tools, but intelligent, adaptive partners in a myriad of endeavors, continually learning and evolving their understanding of the world they operate within.