
The gravitational constant, often denoted by the letter ‘G’, stands as one of the most fundamental constants in physics, a cornerstone of our understanding of the universe. Far from being an abstract theoretical concept, its implications resonate deeply within the realm of flight technology, from the basic principles of achieving lift to the sophisticated navigation and stabilization systems that define modern aerial platforms. While not directly computed in real-time by a drone’s flight controller, the value of G underpins the very physical laws that govern flight, dictating everything from thrust requirements to the precision of satellite-based navigation. Understanding G is thus crucial for anyone seeking to grasp the foundational science behind how aircraft, and specifically unmanned aerial vehicles (UAVs), conquer the skies.
The Universal Constant: Defining G in Flight Dynamics
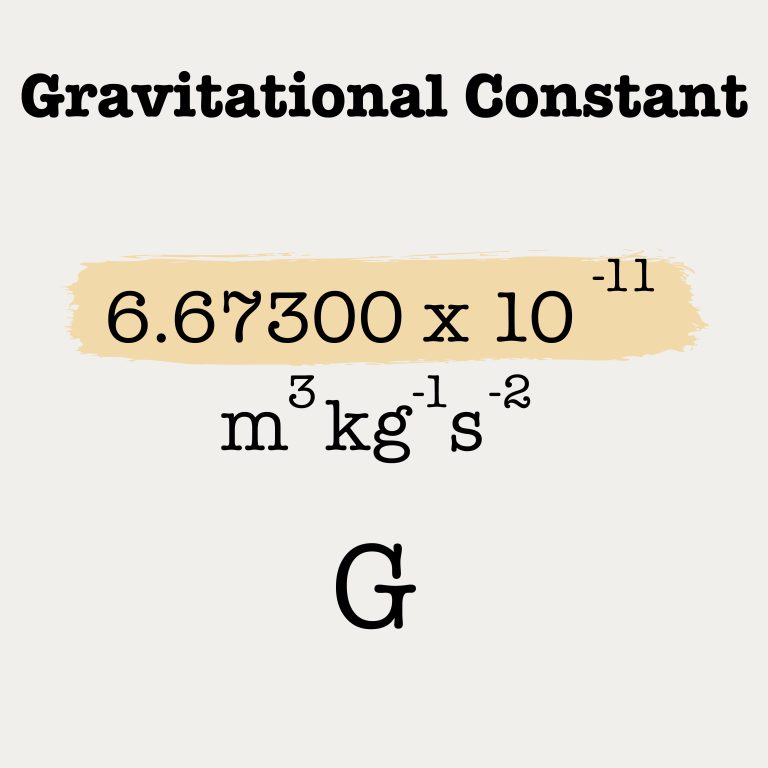
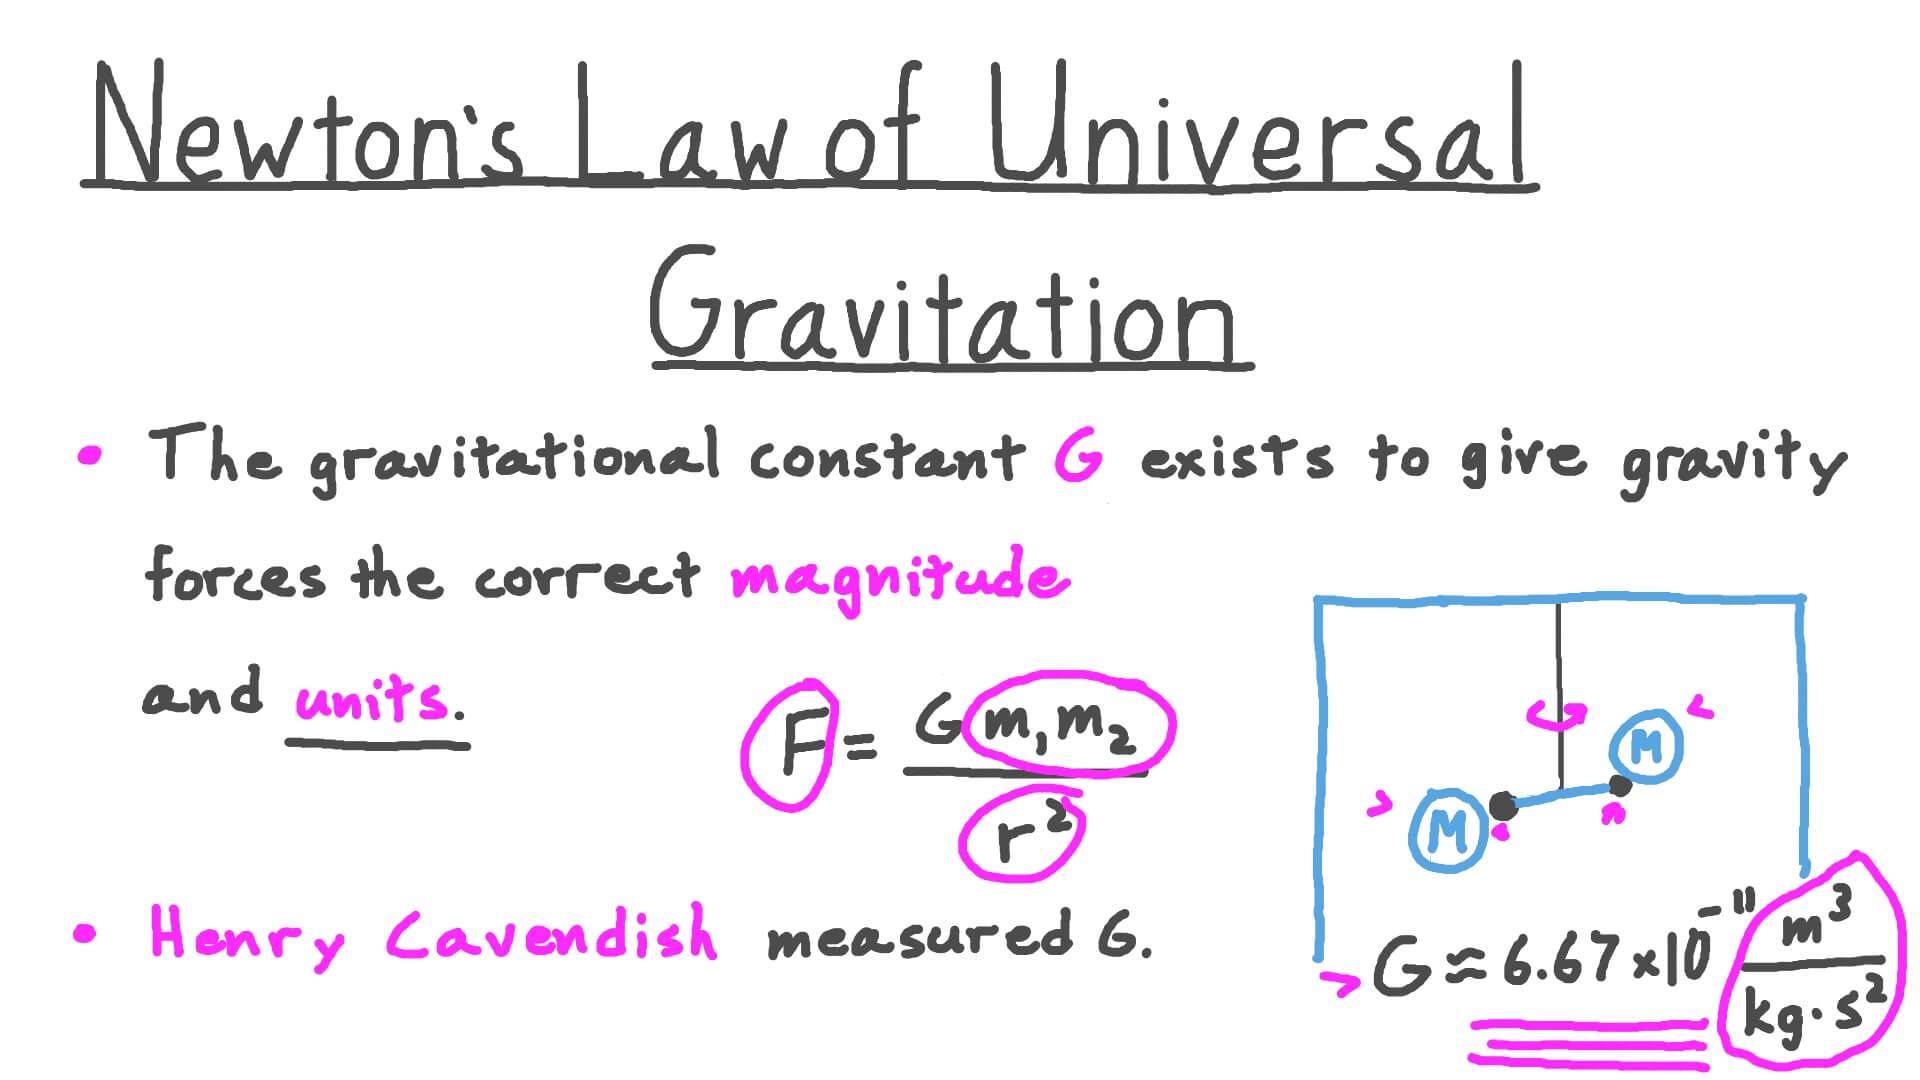
At its core, the gravitational constant ‘G’ is the proportionality constant in Isaac Newton’s law of universal gravitation. This law describes the attractive force between any two objects with mass. Specifically, Newton’s formula states that the gravitational force (F) between two masses (m1 and m2) is directly proportional to the product of their masses and inversely proportional to the square of the distance (r) between their centers. The mathematical representation is F = G * (m1 * m2) / r². The value of G itself is incredibly small, approximately 6.674 × 10⁻¹¹ N⋅(m/kg)², highlighting that gravity is a relatively weak force at the human scale, yet it becomes profoundly significant with larger masses like planets or for sustained flight.
Newton’s Law of Universal Gravitation and its Aerial Relevance
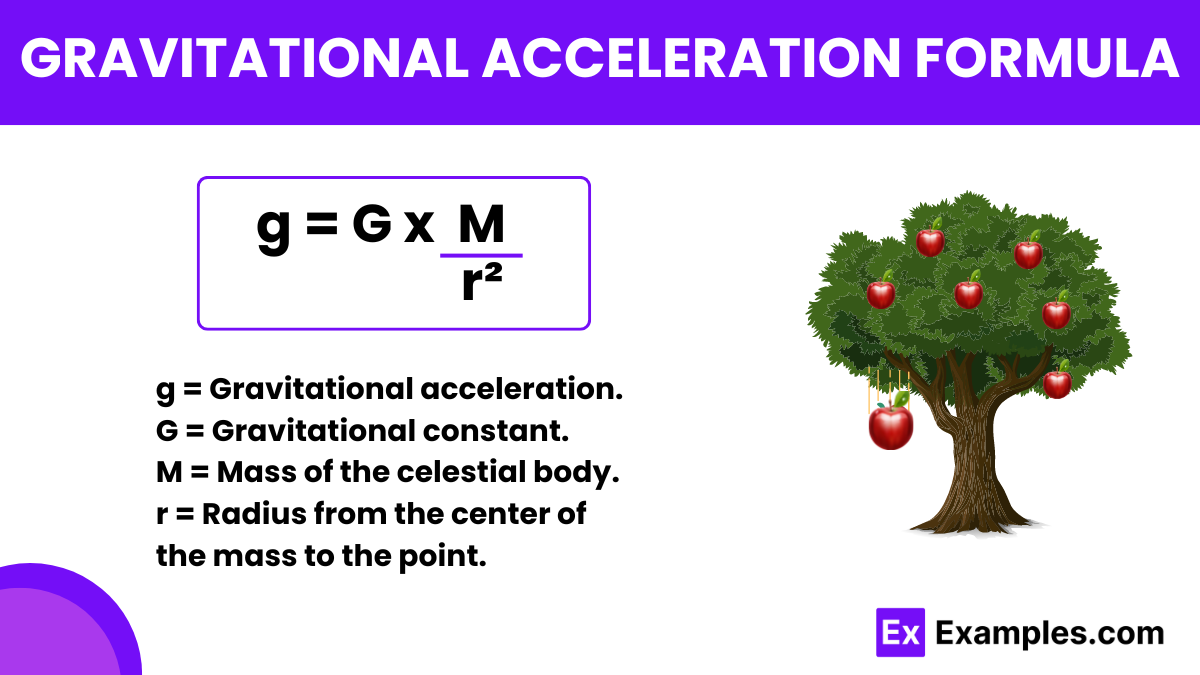
For flight technology, Newton’s law, facilitated by G, is the bedrock upon which all aerodynamic principles are built. A drone, for instance, must generate enough upward thrust to counteract the gravitational force pulling it towards the Earth. The mass of the drone (m1), combined with the mass of the Earth (m2) and the distance from its center (r), determines the precise gravitational pull it experiences. Engineers designing propulsion systems, selecting motors, propellers, and batteries, are implicitly dealing with the parameters set by G. They must ensure that the lift generated by the spinning propellers is sufficient to overcome the drone’s weight (mass × acceleration due to gravity, where ‘g’ is derived from G, Earth’s mass, and radius). Without a precise understanding of G and its role in calculating the force of gravity, designing an aircraft capable of sustained, controlled flight would be an impossible task. Every watt of power consumed by a drone for propulsion is, in essence, a battle against the gravitational force defined by this universal constant.
The Significance of G in Geophysical Models for Flight
Beyond simply counteracting gravity, the gravitational constant plays a pivotal role in the geophysical models that inform advanced flight technology. The Earth is not a perfect sphere, and its mass distribution is not perfectly uniform. These variations create minute differences in the local gravitational field. For highly precise applications such as mapping, remote sensing, and autonomous navigation, particularly over large areas or at very low altitudes, these variations can become relevant. Satellite navigation systems (like GPS), which are critical for modern flight, rely on ultra-precise timing and orbital mechanics. The orbits of GPS satellites themselves are governed by gravitational physics, where G is a crucial parameter in calculating their trajectories and predicting their positions. Therefore, understanding the gravitational constant is fundamental not only to the initial lift-off but also to maintaining precise spatial awareness throughout a flight mission.
Gravity’s Ubiquitous Influence on Flight Technology
The omnipresent force of gravity, quantified by the gravitational constant, is a central challenge and consideration for every aspect of flight technology. From the initial conceptual design to the intricacies of control systems, understanding gravity’s pull is paramount. Modern flight systems, especially autonomous UAVs, incorporate a multitude of sensors and algorithms specifically designed to contend with, measure, and leverage gravity for stable and controlled operation.
Overcoming Gravity: Thrust, Lift, and Propulsion Systems
The most immediate technological challenge presented by gravity is simply to overcome it. For multirotor drones, this means generating sufficient thrust from rotating propellers to exceed the drone’s weight. The design of these propulsion systems — including motor Kv values, propeller pitch and diameter, and battery energy density — is directly informed by the need to generate a specific amount of force against gravity. Engineers use formulas derived from aerodynamic principles, which in turn rely on the foundational physics of mass and gravity (via G), to calculate the necessary lift. An inefficient propulsion system means more energy expended to fight gravity, leading to shorter flight times and reduced payload capacity. Therefore, the drive for greater efficiency in drone design is, in part, a continuous optimization effort against the constant pull of gravity.
Stabilization and Inertial Measurement Units (IMUs)
Gravitational forces are also intrinsically linked to the function of Inertial Measurement Units (IMUs), which are critical components in all modern flight technology for stabilization and navigation. An IMU typically consists of accelerometers and gyroscopes. Accelerometers measure linear acceleration, including the acceleration due to gravity (the ‘g-force’ felt by the sensor). Gyroscopes measure angular velocity. By fusing data from these sensors, a drone’s flight controller can determine its orientation (pitch, roll, yaw) and track its movement through space.
The accelerometer’s ability to sense the direction of gravity is key to establishing a stable horizontal reference plane. Without this constant gravitational reference, a drone would quickly become disoriented, unable to distinguish between genuine motion and attitude changes. Advanced algorithms like Kalman filters or complementary filters actively process accelerometer data alongside gyroscope data to filter out noise and drift, providing a reliable estimate of the drone’s attitude relative to the Earth’s gravitational field. Thus, the gravitational constant, through its manifestation as the acceleration due to gravity, is continuously leveraged by IMUs to keep aerial platforms stable and level.
Altitude Hold and Pressure Sensors
Maintaining a precise altitude is another critical function of flight technology, heavily influenced by gravity. While GPS can provide altitude information, barometric pressure sensors (altimeters) are often used for more accurate relative altitude hold, especially for short-term stability. These sensors measure atmospheric pressure, which decreases with altitude. However, pressure readings are also affected by temperature and weather changes. For robust altitude control, the flight controller often fuses data from the barometric sensor with vertical velocity estimates from accelerometers (which are, again, sensing relative to gravity) and GPS altitude data. The control loops governing altitude adjustment constantly work to counteract the persistent downward pull of gravity, ensuring the drone remains at its desired height, compensating for changes in air density or lift efficiency.
Precision Navigation and Gravitational Models
The accuracy of modern flight navigation systems, particularly those relying on satellite constellations, is profoundly influenced by an understanding of gravitational physics, where G is a primary parameter. For drones engaged in critical missions like infrastructure inspection, precise mapping, or autonomous delivery, centimeter-level accuracy can be non-negotiable.
GPS and Satellite Orbit Mechanics
Global Positioning System (GPS) and other Global Navigation Satellite Systems (GNSS) are fundamental to the navigation of almost every modern UAV. These systems operate by satellites orbiting Earth, transmitting precise timing signals. The paths of these satellites are meticulously calculated using models that incorporate the gravitational constant, Earth’s mass, and even minute gravitational perturbations from other celestial bodies. Any error in these gravitational models would lead to inaccuracies in predicting satellite positions, which would, in turn, translate to errors in the drone’s estimated position. For high-precision RTK (Real-Time Kinematic) and PPK (Post-Processed Kinematic) GPS systems, which achieve centimeter-level accuracy, the underlying gravitational calculations must be incredibly refined to ensure the integrity of the satellite’s ephemeris data.
Accounting for Earth’s Gravitational Field Variations
As mentioned, Earth’s gravitational field is not uniform. Due to factors like varying crustal densities, topography, and the planet’s rotation (creating an equatorial bulge), the acceleration due to gravity varies slightly across the globe. While for most consumer drone applications, these variations are negligible, for highly specialized and precise applications—such as long-duration autonomous flights requiring extremely accurate altimetry over vast regions, or scientific research drones performing gravimetric surveys—these localized gravitational anomalies can become significant. Advanced flight control systems and mission planning software for such specialized UAVs may incorporate geoid models and local gravity field data to refine their navigation and altitude estimates, ensuring that what the drone perceives as “level” or “constant altitude” is truly consistent with Earth’s actual gravitational equipotential surfaces.
Advanced Flight Control Algorithms
Modern flight control algorithms leverage sophisticated mathematical models that implicitly or explicitly account for gravity. From PID (Proportional-Integral-Derivative) controllers for attitude stabilization to complex state estimators for autonomous navigation, the entire framework is built upon Newtonian mechanics. These algorithms continuously calculate forces, torques, and accelerations, many of which are directly influenced by the gravitational constant. For example, when a drone performs an aggressive maneuver, the flight controller must rapidly adjust motor speeds to compensate for the changing angle of attack against gravity, ensuring stability and preventing unintended drift or loss of altitude. The precision and responsiveness of these algorithms are a direct testament to our understanding and application of fundamental physical laws, anchored by the gravitational constant.
The Practical Implications for Modern Flight Systems
The theoretical understanding of the gravitational constant transitions directly into tangible engineering decisions and operational capabilities for modern flight systems. Its influence is seen in design choices that optimize performance and in the continuous pursuit of greater efficiency and autonomy.
Design Considerations for Payload and Endurance
For drone manufacturers and operators, the gravitational constant is a silent but ever-present factor in critical design trade-offs. The maximum payload a drone can carry is fundamentally limited by the thrust it can generate relative to its own mass, all against the pull of gravity. Engineers constantly work to minimize the structural weight of drones while maximizing their power-to-weight ratio to improve payload capacity and flight endurance. Every gram saved in the airframe or every increase in battery energy density directly translates to a more effective fight against gravity, allowing for longer missions or the carrying of heavier, more sophisticated sensors. This constant battle against gravity drives innovation in material science, battery technology, and aerodynamic design, all with the implicit goal of optimizing performance within the physical constraints imposed by G.
Future Innovations in Gravitational Understanding and Flight Efficiency
As flight technology continues to evolve, our understanding of gravity and its manipulation could open new frontiers. While anti-gravity remains firmly in the realm of science fiction, ongoing research into gravitational physics, such as general relativity effects or quantum gravity, might one day yield insights that subtly influence propulsion or navigation systems in ways we cannot yet fully predict. More immediately, advancements in gravimetric sensors could allow drones to perform highly detailed surveys of gravitational anomalies, useful for geological exploration or environmental monitoring. Further refinement of flight control algorithms, perhaps incorporating real-time, highly localized gravitational models derived from onboard sensors, could lead to even more precise and stable autonomous flight, pushing the boundaries of what UAVs can achieve in complex environments. The gravitational constant, therefore, is not just a relic of classical physics but an enduring variable in the equation of innovation for flight technology.