
The Heartbeat of Autonomous Navigation
The concept of the directional derivative, though seemingly rooted in abstract mathematics, is fundamental to the sophisticated operation of modern flight technology, particularly in the realms of navigation and stabilization. For any vehicle, especially an autonomous one like a drone, understanding how a particular quantity changes in a specific direction is paramount. This applies to countless variables: altitude, velocity, magnetic field strength, atmospheric pressure, and critically, the gradients of potential fields that guide navigation. Without a firm grasp of the directional derivative, the complex algorithms that enable drones to fly precisely, avoid obstacles, and maintain stable flight paths would simply not be possible.

Imagine a drone navigating through a complex, three-dimensional space. It needs to know not just that its altitude is changing, but how much it’s changing and in which direction relative to its own orientation and the surrounding environment. Similarly, when processing sensor data, such as that from a GPS receiver or an inertial measurement unit (IMU), the drone’s flight controller constantly evaluates how these readings change as the drone moves. The directional derivative provides the mathematical framework to quantify these changes along any conceivable vector.
At its core, the directional derivative is an extension of the familiar concept of a derivative. While a regular derivative tells us the rate of change of a function with respect to a single variable (e.g., how altitude changes with respect to time), the directional derivative allows us to explore the rate of change of a function of multiple variables along a specified direction. In the context of flight technology, these “functions” often represent navigational potentials, error landscapes, or sensor readings that vary across space.
Functions in Flight: Beyond Simple Variables
In the sophisticated world of flight technology, the “functions” we are interested in are rarely simple scalar quantities dependent on a single variable. Instead, they are often scalar fields or vector fields that describe various aspects of the drone’s environment and state.
Scalar Fields in Navigation
A scalar field assigns a scalar value to every point in space. Consider the Earth’s magnetic field. At any given location, there’s a strength value associated with it. As a drone moves, this strength changes. The directional derivative allows the navigation system to calculate how the magnetic field strength changes as the drone moves in, say, its forward direction, its upward direction, or any arbitrary direction. This is crucial for magnetic compasses and advanced magnetic anomaly detection systems that might be used for specialized navigation or surveying.
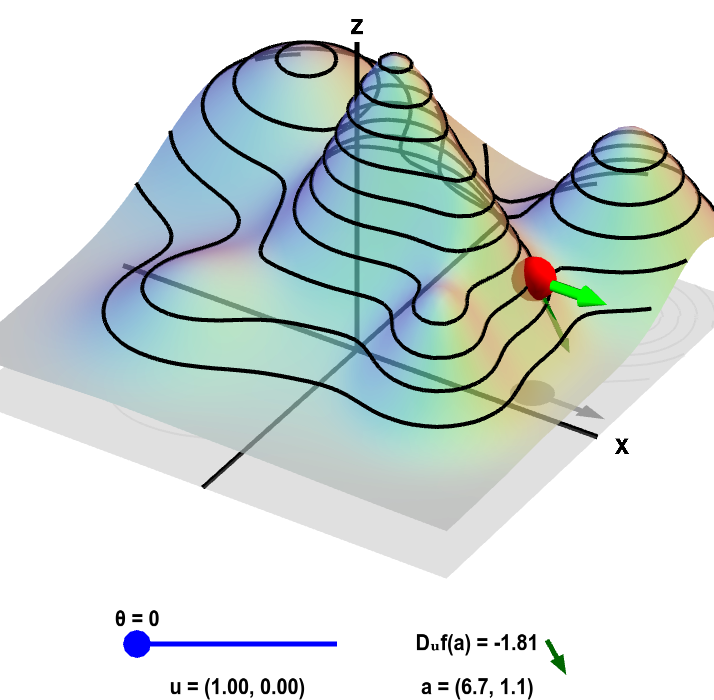
Another critical scalar field is the altitude or elevation map of the terrain. As the drone traverses an area, its altitude relative to sea level or a reference point changes. The directional derivative of this elevation field, with respect to the drone’s direction of travel, tells the flight controller how the ground is sloping beneath it. This information is vital for maintaining a constant altitude above ground level (AGL) in challenging terrain, a capability often referred to as terrain following.
Vector Fields and Forces
Vector fields, which assign a vector to every point in space, are also prevalent. For instance, wind velocity can be represented as a vector field. The drone’s flight controller needs to understand how the wind’s force, and consequently its effect on the drone’s trajectory, changes as the drone attempts to deviate from its intended path. While the directional derivative is primarily defined for scalar functions, its principles are extended in more advanced vector calculus and computational fluid dynamics to understand the rate of change of vector quantities in specific directions, which is essential for advanced aerodynamic modeling and control.
The Mathematical Foundation for Precise Movement
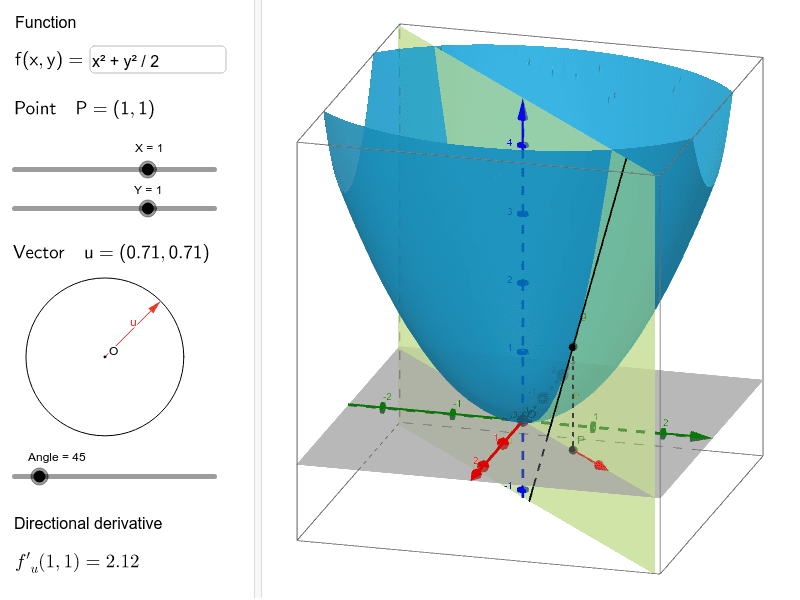
The formal definition of the directional derivative helps illustrate its power. For a scalar function $f(x, y, z)$ of three variables, its directional derivative at a point $(x0, y0, z_0)$ in the direction of a unit vector $mathbf{u} = langle a, b, c rangle$ is given by:
$D{mathbf{u}}f(x0, y0, z0) = nabla f(x0, y0, z_0) cdot mathbf{u}$
where $nabla f$ is the gradient of $f$. The gradient, $nabla f = leftlangle frac{partial f}{partial x}, frac{partial f}{partial y}, frac{partial f}{partial z} rightrangle$, is a vector pointing in the direction of the greatest rate of increase of the function, and its magnitude represents that greatest rate. The dot product then projects this direction of maximum change onto the specific direction $mathbf{u}$, giving us the rate of change in that particular direction.
In two dimensions, for a function $f(x, y)$ and a unit vector $mathbf{u} = langle a, b rangle$, the directional derivative is:
$D{mathbf{u}}f(x0, y0) = nabla f(x0, y0) cdot mathbf{u} = frac{partial f}{partial x}(x0, y0)a + frac{partial f}{partial y}(x0, y_0)b$
For flight technology, the “variables” often aren’t static spatial coordinates $x, y, z$ but can also include time $t$, or even parameters related to the drone’s internal state. The functions might represent error signals, desired trajectory deviations, or sensor readings that are constantly being updated and evaluated.
Navigating Complex Environments: The Role in Pathfinding and Obstacle Avoidance
The directional derivative is indispensable for sophisticated navigation systems, particularly in dynamic and unpredictable environments. Pathfinding algorithms and obstacle avoidance systems rely heavily on understanding how the “cost” or “risk” associated with different trajectories changes as the drone moves.
Gradient Descent for Optimal Paths
Many pathfinding algorithms, especially those used in autonomous systems, employ principles akin to gradient descent. Imagine a cost function that defines the “undesirability” of a particular flight path – perhaps it’s too long, too close to obstacles, or consumes too much energy. The goal is to find the path with the minimum cost.
The directional derivative helps determine the direction of steepest ascent (or descent, if we consider a negative cost function) of this cost landscape. By calculating the directional derivative in various potential directions of movement, the drone can iteratively move towards paths with lower costs. This is especially critical when considering 3D path planning, where the search space is vast. The gradient of the cost function, computed using directional derivatives, points the way to the most efficient way to adjust the drone’s velocity or trajectory to minimize the cost.
Real-time Obstacle Sensing and Evasion
Obstacle avoidance is another area where the directional derivative plays a crucial role. When a drone’s sensors detect an object, the flight controller needs to quickly assess the potential collision course and determine the safest evasion maneuver. This involves analyzing how the distance to the obstacle, or the probability of collision, changes as the drone alters its velocity vector.
Consider a simple scenario: a drone approaching a wall. The distance to the wall is a function of the drone’s position. As the drone moves, the rate of change of this distance in its current direction of motion is monitored. If this rate becomes negative and its magnitude increases rapidly, it signals an imminent collision. The directional derivative helps quantify this rate of change in the direction the drone is currently moving, as well as in potential evasive directions (e.g., moving left, right, up, or down). By calculating the directional derivative of the distance function with respect to these potential movement vectors, the drone can choose the direction that maximizes its distance from the obstacle most effectively. This process happens in real-time, often at high frequencies, to ensure safe operation.
Sensor Fusion and Uncertainty Landscapes
In advanced flight systems, data from multiple sensors (e.g., LiDAR, radar, cameras, GPS, IMU) are fused to create a more robust understanding of the environment and the drone’s state. Each sensor provides information that can be interpreted as a scalar or vector field. For instance, a LiDAR sensor provides distance measurements, effectively mapping a scalar field of distances.
The directional derivative is used to understand how these sensor readings change as the drone moves, which helps in state estimation and localization. By analyzing the rate of change of sensor readings in different directions, the drone can refine its estimate of its position and orientation. Furthermore, when dealing with uncertainties in sensor measurements or environmental models, we can consider “uncertainty landscapes.” The directional derivative helps quantify how the uncertainty itself changes across different potential states or movements, guiding the system towards more certain and reliable navigation solutions.
Stabilization Systems: Maintaining Equilibrium and Smooth Flight
The stability of a drone is paramount for safe and effective operation, especially during complex maneuvers or in turbulent conditions. Directional derivatives are integral to the algorithms that power advanced stabilization systems.
Understanding Gravitational and Aerodynamic Forces
A drone is subject to numerous forces, including gravity, lift, drag, and thrust. The net force acting on the drone dictates its acceleration and, consequently, its motion. Stabilization systems aim to counteract disturbances that would cause the drone to deviate from its desired orientation or altitude.
The orientation of a drone can be described by its pitch, roll, and yaw angles, which can be viewed as parameters in a complex function representing the drone’s dynamics. The forces acting on the drone are often dependent on its orientation and velocity. The directional derivative helps analyze how these forces change in response to small changes in orientation or velocity.
For example, consider the effect of gravity on a slightly tilted drone. The gravitational force vector is constant, but its components along the drone’s body axes change as the drone pitches or rolls. The directional derivative of these components with respect to pitch and roll angles reveals how effectively gravity acts to restore or disturb the drone’s equilibrium. Similarly, aerodynamic forces like lift and drag are functions of airspeed and angle of attack, and their behavior across different flight regimes is understood by analyzing their derivatives in relevant directions.
Feedback Control and Error Correction
Stabilization systems typically employ feedback control loops. These loops continuously measure the drone’s current state (e.g., its actual orientation and angular velocity) and compare it to the desired state. The difference between these is the error signal. The control system then generates corrective commands to minimize this error.
The directional derivative is implicitly used when designing these control laws. For instance, in a Proportional-Integral-Derivative (PID) controller, the derivative term’s purpose is to anticipate future errors based on the current rate of change of the error signal. This “predictive” capability, derived from the concept of a derivative, helps dampen oscillations and improve the system’s responsiveness to disturbances. When considering more advanced control strategies, the directional derivative of performance metrics or error functions with respect to control inputs directly informs how to adjust those inputs to achieve the desired stability.
Inertial Measurement Units (IMUs) and Motion Analysis
IMUs are crucial sensors that measure linear acceleration and angular velocity. These raw measurements are integrated over time to estimate the drone’s attitude and position. However, raw acceleration and angular velocity are not directly the quantities we are interested in for stability. Instead, we need to understand how these rates of change evolve and how they relate to the drone’s overall motion.
The directional derivative framework helps in interpreting the output of an IMU in the context of the drone’s dynamics. For example, when an IMU detects a sudden acceleration, the flight controller needs to determine if this is due to an external disturbance (like wind) or a commanded maneuver. By analyzing the rate of change of acceleration (jerk) and angular velocity, and how these relate to the drone’s inertial properties, the stabilization system can make informed decisions about how to counteract any unwanted motion. This involves understanding the directional derivative of the drone’s kinematic equations, which describe how its position and velocity change over time based on applied forces and torques.
Advanced Flight Operations: Beyond Basic Hovering
As flight technology advances, the applications requiring precise directional understanding become more complex and demanding. From aerial surveying to complex autonomous missions, the directional derivative is a silent but essential enabler.
Precision Altitude Control and Terrain Following
Maintaining a consistent altitude above a complex, undulating terrain is a significant challenge. Standard barometric altimeters are sensitive to atmospheric pressure changes and can be inaccurate. For true terrain following, drones use radar or LiDAR to measure the distance to the ground directly below.
The directional derivative of the terrain’s elevation map, in the direction of the drone’s horizontal movement, provides crucial information. If the derivative is positive and large, it means the ground is rising sharply ahead, requiring the drone to ascend to maintain a constant altitude. Conversely, a negative derivative indicates a descent. This enables sophisticated terrain-following algorithms that are essential for applications like low-altitude agricultural spraying, infrastructure inspection, and low-level reconnaissance.
Magnetic Navigation and Geospatial Data Analysis
While GPS is a primary navigation tool, it can suffer from signal loss in canyons, urban environments, or indoors. Magnetic navigation, using the Earth’s magnetic field, offers an alternative or supplementary system. The Earth’s magnetic field varies spatially, creating unique magnetic signatures that can be used for localization.
The directional derivative of the magnetic field strength and direction is used to compare the drone’s current magnetic readings with pre-existing magnetic maps. By finding the location where the observed directional changes in the magnetic field best match the map’s derivatives, the drone can accurately determine its position, even in GPS-denied environments. This is a powerful technique for autonomous navigation in challenging scenarios.
Autonomous Docking and Precision Landing
Autonomous docking and precision landing require the drone to approach a target with extreme accuracy, often in dynamic conditions. This involves not only precise position control but also the ability to react to slight misalignments or movements of the target.
The directional derivative can be applied to the “error landscape” between the drone and the docking station or landing pad. This landscape might represent the difference in orientation, position, or velocity. By calculating the directional derivative of this error with respect to the drone’s control inputs, the system can determine the optimal adjustments needed to converge on the target. This is critical for applications such as automated package delivery, autonomous recharging, and search and rescue operations where rapid and accurate deployment is vital.
In essence, the directional derivative is more than just a mathematical concept; it’s a fundamental principle that underpins the ability of modern flight technology to perceive, navigate, and interact with the physical world with an ever-increasing degree of autonomy and precision. Its application enables drones to perform complex tasks safely and efficiently, pushing the boundaries of what is possible in the air.