
In the rapidly evolving landscape of drone technology, innovation is often synonymous with sophisticated software. From autonomous navigation and intelligent obstacle avoidance to real-time data processing for mapping and remote sensing, the capabilities of modern drones are deeply rooted in their underlying codebases. Developing these complex systems requires a robust and flexible build process, and at the heart of many such projects, particularly those leveraging C++ for performance and control, lies CMakeLists.txt. Far more than a mere configuration file, CMakeLists.txt serves as the blueprint for building, testing, and packaging the intricate software that powers the cutting-edge features in drone tech and innovation. It is the declarative script that instructs the CMake build system generator on how to transform source code into deployable applications, libraries, and firmware for unmanned aerial vehicles (UAVs). Understanding its function is crucial for anyone involved in developing the next generation of intelligent drone systems, as it dictates how diverse components – from low-level flight control algorithms to high-level AI inference engines – are assembled into a functional whole.
The Architectural Foundation for Advanced Drone Software
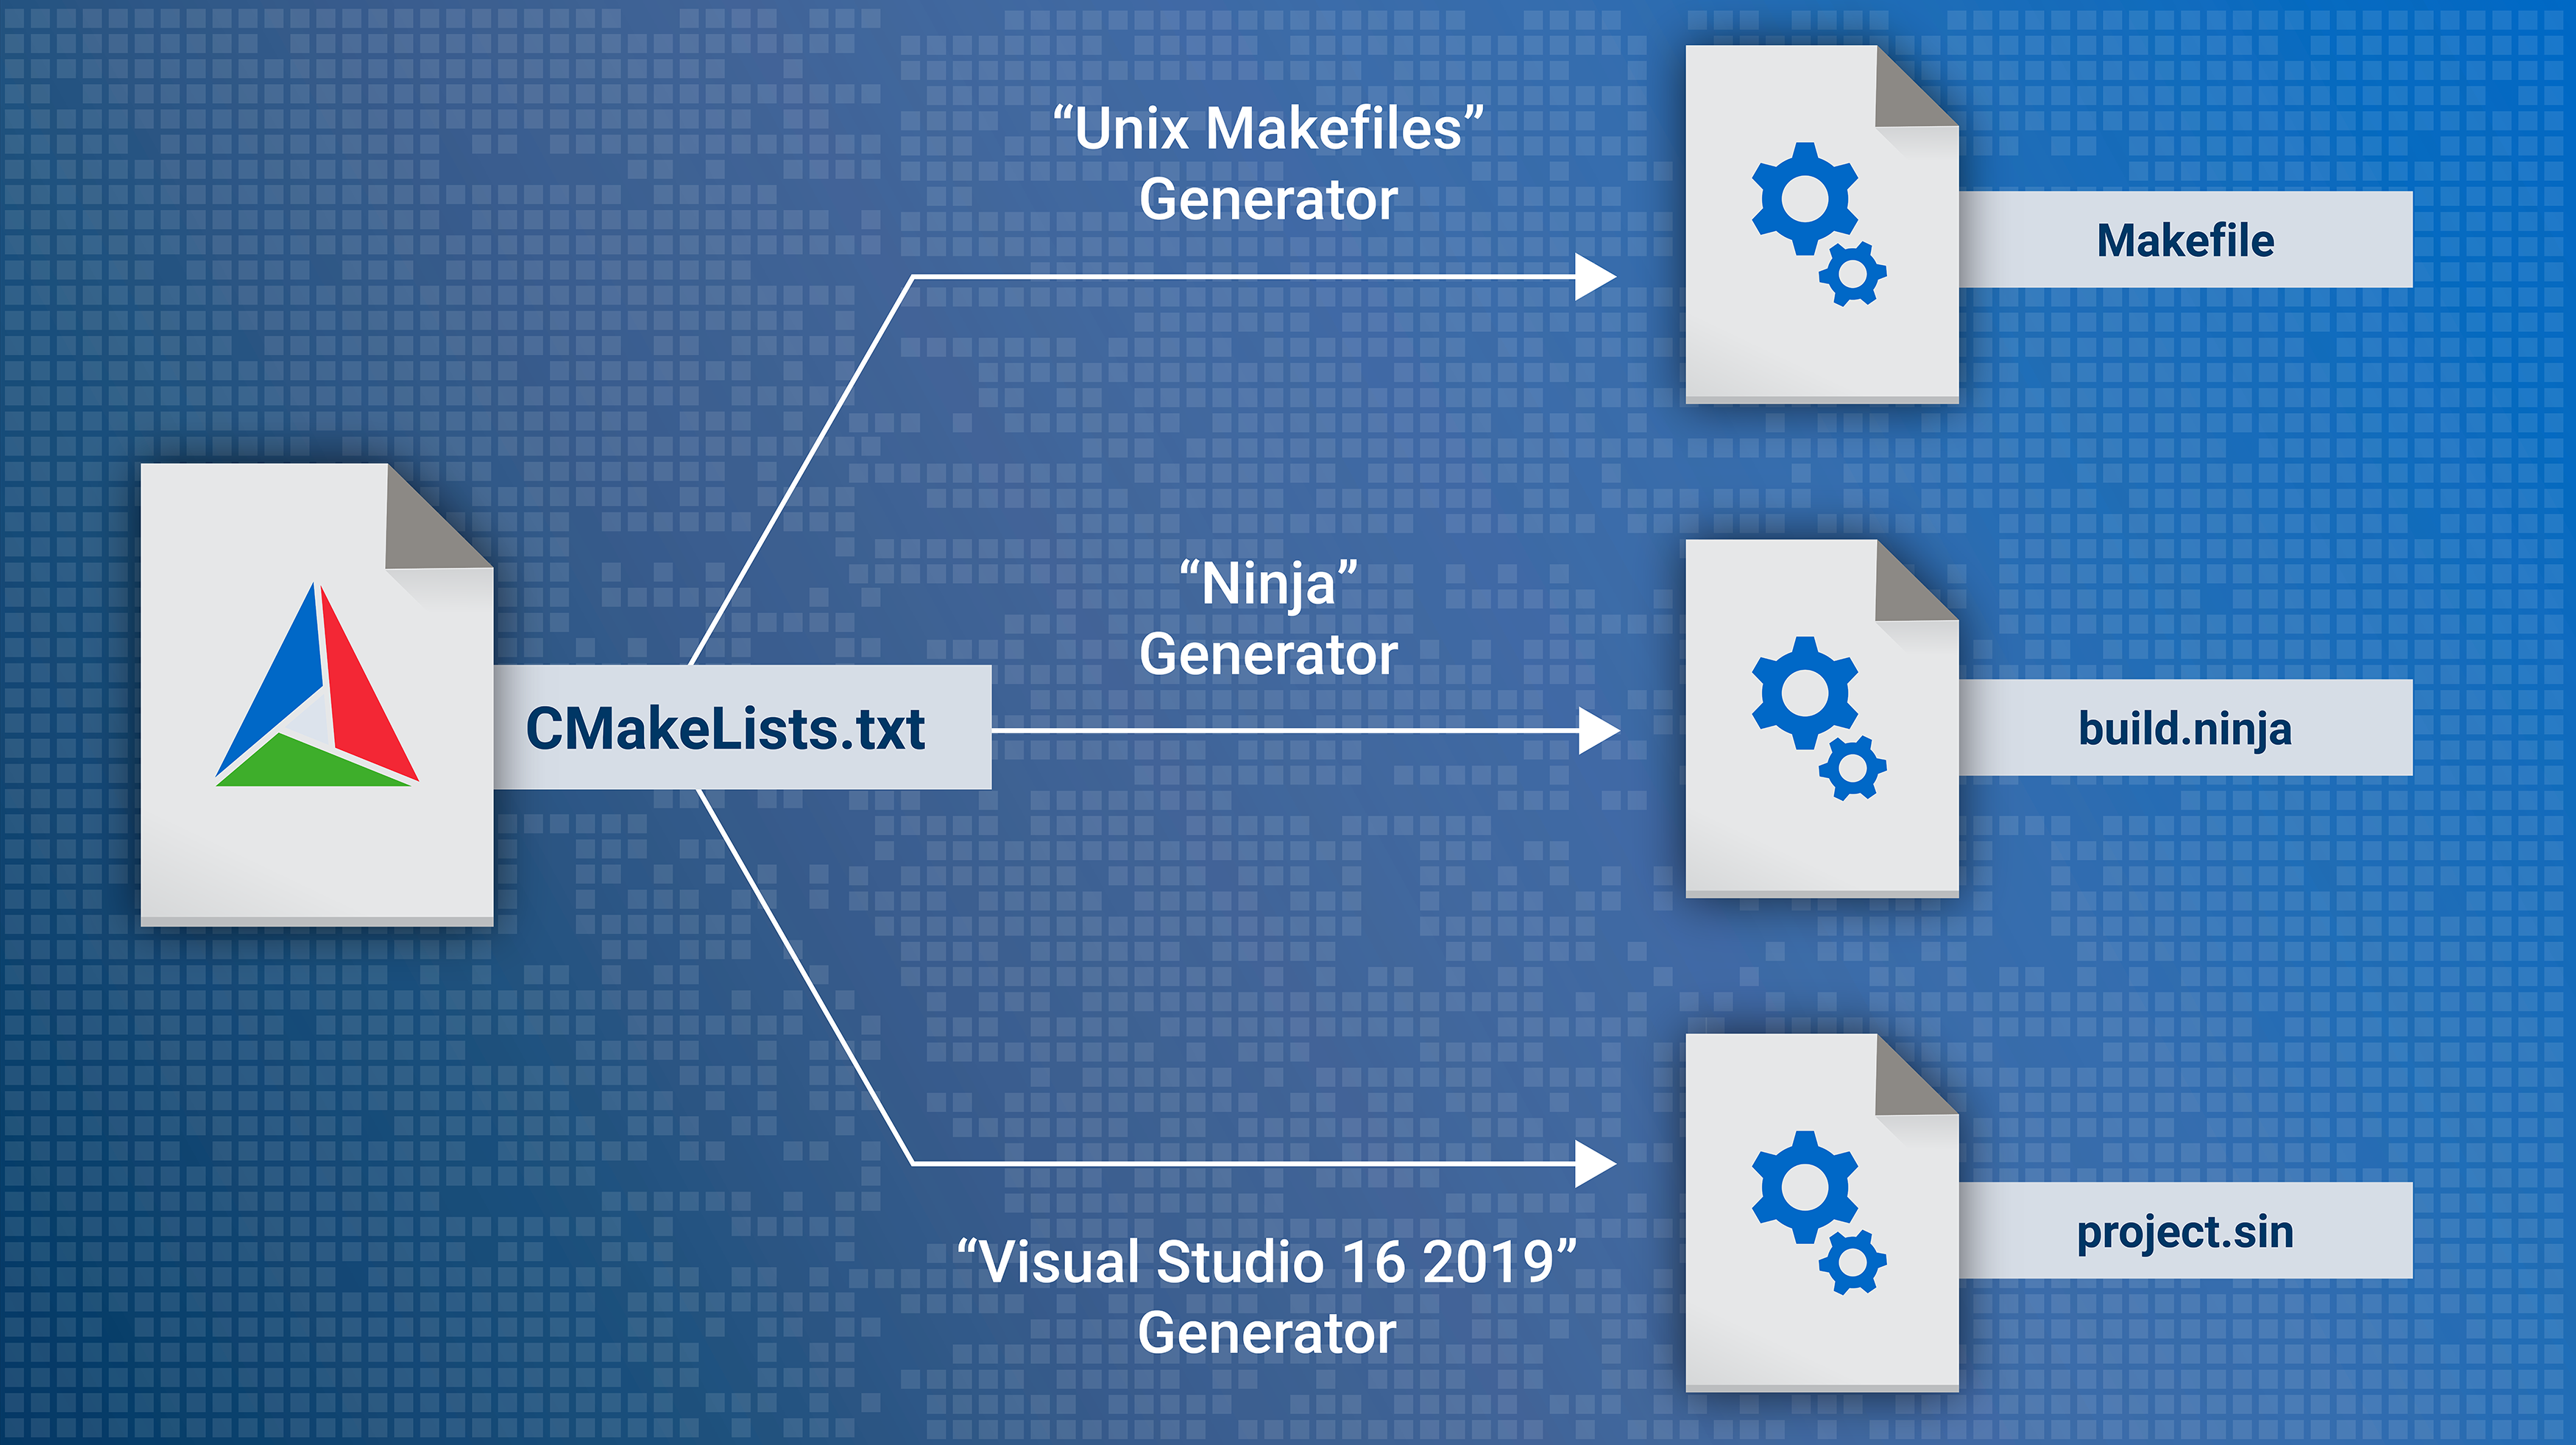
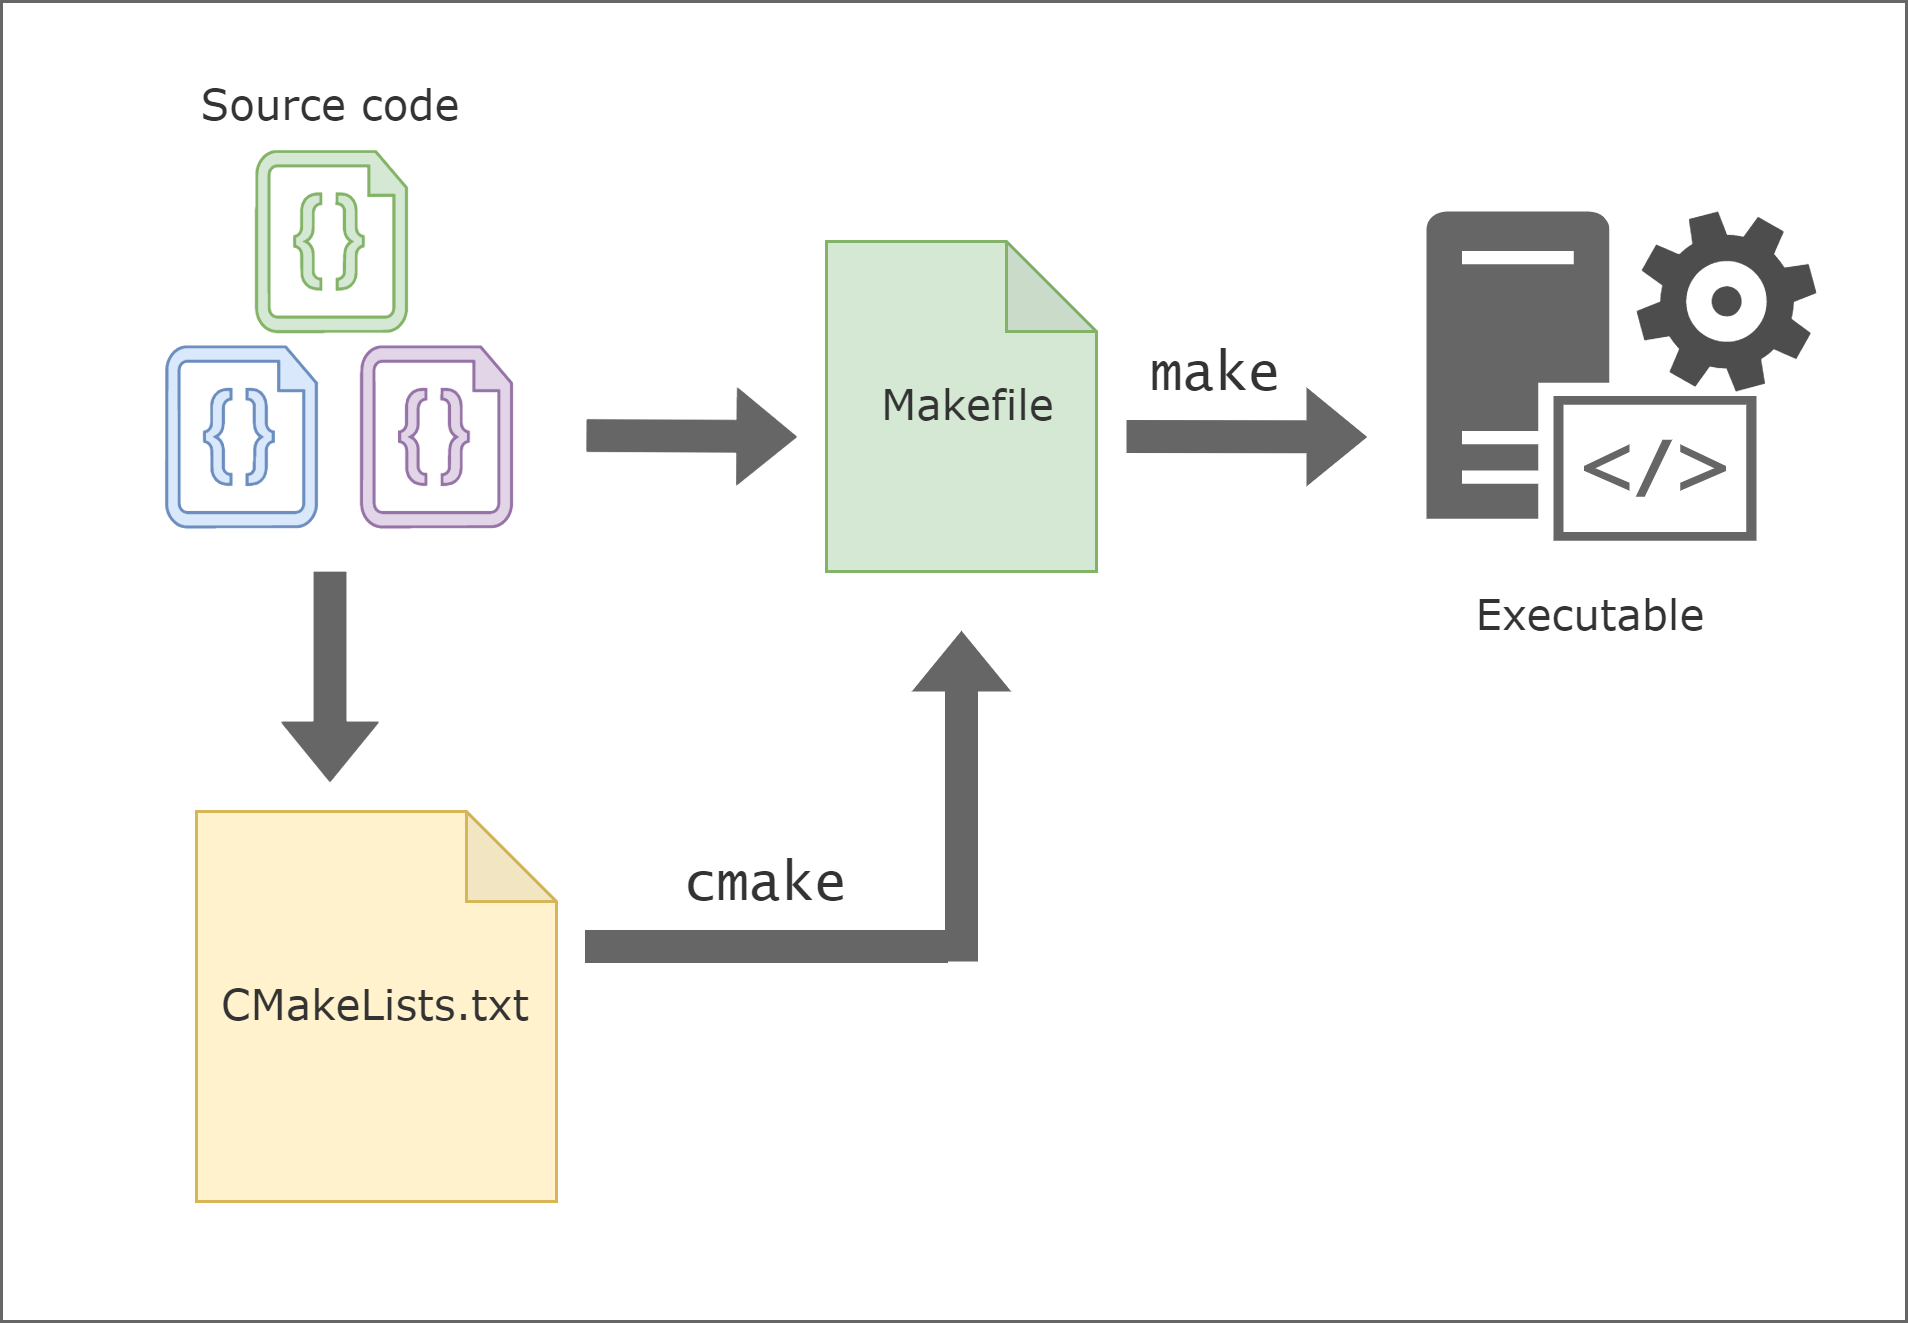
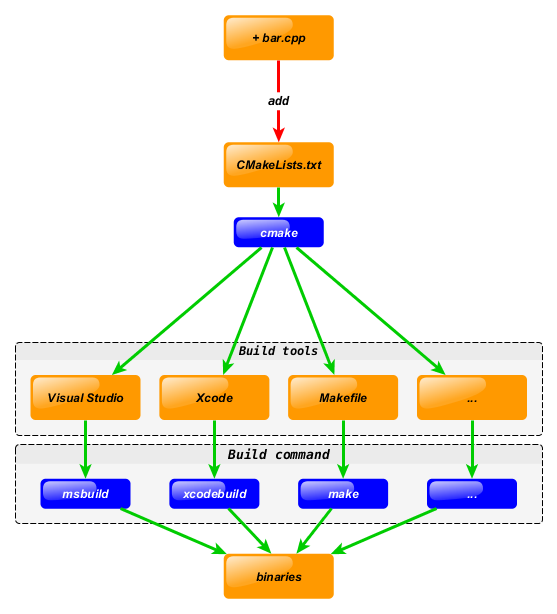
The complexity of drone software, encompassing everything from embedded real-time operating systems to cloud-connected AI services, demands a sophisticated approach to project management and compilation. CMakeLists.txt addresses this need by providing a cross-platform, generator-independent system that orchestrates the build process. Instead of directly compiling code, CMake generates native build system files (like Makefiles for Unix-like systems or Visual Studio project files for Windows) from the CMakeLists.txt script. This abstraction is incredibly powerful for drone development, where target environments can range from tiny ARM microcontrollers on flight controllers to powerful NVIDIA Jetson boards handling onboard AI, or even standard desktop PCs used for simulation and ground control stations.
Bridging Hardware and High-Level Functionality
Modern drones integrate a diverse array of hardware components: GPS modules, inertial measurement units (IMUs), vision cameras, LiDAR sensors, and powerful onboard computing units. Each of these components typically requires specific drivers, communication protocols (like MAVLink), and processing algorithms. CMakeLists.txt is the mechanism through which developers define how all these software pieces interact. It specifies which source files contribute to a particular executable (e.g., the main flight control loop), which external libraries are required (e.g., OpenCV for computer vision, Eigen for linear algebra in navigation), and how these dependencies should be located and linked. This capability is essential for building robust drone software that can seamlessly interface with disparate hardware, enabling features like precise sensor fusion for navigation or real-time image processing for object detection and tracking. Without a unified build system like CMake, managing these interdependencies across various hardware targets would be a monumental and error-prone task.
Cross-Platform Compatibility for Embedded Systems
One of CMake’s most compelling advantages for drone innovation is its inherent cross-platform nature. Drone development often involves targeting various operating systems and hardware architectures. A developer might write C++ code for a Linux-based companion computer on the drone, test it on a Windows or macOS desktop during development, and then deploy it onto a real-time operating system (RTOS) running on an ARM-based microcontroller. CMakeLists.txt centralizes the build configuration, allowing developers to define their project once and then generate native build files for any supported environment. This means that a single CMakeLists.txt file can be used to build the same application for a powerful embedded Linux system (like an NVIDIA Jetson for AI processing) and simultaneously for a simpler microcontroller (for flight stabilization), significantly streamlining the development and deployment pipeline. This consistency is vital for ensuring that complex algorithms and innovative features developed on one platform can be reliably transferred and executed on the diverse array of hardware found in the drone ecosystem.
Deconstructing the Anatomy of a CMakeLists.txt File
A CMakeLists.txt file is essentially a sequence of commands written in CMake’s domain-specific language. While it can appear daunting at first glance, its structure is logical and follows a predictable pattern, defining the project’s properties and instructing CMake on how to build its various components.
Project Definition and Versioning
Every CMakeLists.txt file typically begins with defining the project itself. The cmake_minimum_required() command sets the lowest CMake version that can process the file, ensuring compatibility. The project() command names the project and can specify its version, language support (e.g., CXX for C++), and other metadata. For a drone software project, this might look like project(DroneNavigationSystem VERSION 1.0 LANGUAGES CXX). This initial setup establishes the context for the entire build process, providing a baseline for subsequent commands and configurations.
Source Files and Executables
The core function of CMakeLists.txt is to specify which source files (.cpp, .c, etc.) belong to which executables or libraries. The add_executable() command is used to create an executable target from a list of source files. For example, add_executable(flight_controller main.cpp navigation.cpp sensor_fusion.cpp) would create an executable named flight_controller from the specified source files. Similarly, add_library() is used to create static or shared libraries, which are crucial for modularizing complex drone software into reusable components (e.g., a sensor_drivers library or a path_planning_algorithms library). These commands form the backbone of the project structure, explicitly detailing how the various code modules are compiled into functional programs.
Library Management and Dependencies
Advanced drone features often rely on a multitude of external libraries, both open-source (like ROS for robotics, PCL for point cloud processing, or various machine learning frameworks) and proprietary. Managing these dependencies is where CMakeLists.txt truly shines. The find_package() command allows CMake to search for installed libraries on the system, retrieve their include directories and library paths, and make them available to the project. Once found, target_link_libraries() links these external libraries to specific targets (executables or other libraries). For example, a command like find_package(OpenCV REQUIRED) followed by target_link_libraries(object_detection_node ${OpenCV_LIBS}) integrates OpenCV into a drone’s object detection module. This sophisticated dependency management ensures that all necessary components are correctly located and linked, preventing compilation errors and enabling complex integrations crucial for AI, computer vision, and advanced navigation capabilities.
Build Configurations and Optimizations
CMakeLists.txt also provides granular control over the build process, allowing developers to specify different configurations (e.g., Debug, Release) and apply specific compiler flags. Commands like add_definitions() or target_compile_definitions() can introduce preprocessor macros, which are often used to enable or disable features based on the build type or target hardware. For instance, add_definitions(-DENABLE_DEBUG_LOGGING) might activate verbose logging only in a debug build. Furthermore, set_target_properties() can be used to set properties for specific targets, such as optimization levels (-O3 for Release builds) or custom linker flags. This level of control is vital for optimizing drone software for performance, memory footprint, and power consumption, which are critical considerations for flight endurance and real-time processing on embedded systems.
Powering Tech & Innovation: CMake’s Impact on Drone Capabilities
The underlying stability and flexibility provided by CMakeLists.txt are instrumental in pushing the boundaries of drone technology. It enables developers to focus on innovation rather than wrestling with inconsistent build environments.
Autonomous Flight and AI Integration
The development of truly autonomous drones hinges on sophisticated software that can perceive the environment, make intelligent decisions, and execute complex flight maneuvers. This often involves integrating multiple AI models (e.g., for object recognition, semantic segmentation), sophisticated control algorithms (e.g., PID controllers, model predictive control), and sensor fusion techniques. Each of these components might be developed in different modules, potentially using different libraries. CMakeLists.txt allows these disparate software pieces to be seamlessly compiled and linked together, creating a cohesive autonomous flight stack. Whether it’s integrating a neural network inference engine (like TensorFlow Lite or OpenVINO) with a flight controller’s state estimation algorithm, or linking to a specialized library for path planning, CMake provides the necessary framework to build these complex, multi-faceted systems.
Mapping, Remote Sensing, and Data Processing
Drones are increasingly indispensable tools for mapping, environmental monitoring, and industrial inspection. These applications generate vast amounts of data (imagery, LiDAR point clouds, multispectral data) that require extensive processing. Software for photogrammetry, 3D reconstruction, point cloud registration, and data analytics is often written in C++ for performance, leveraging libraries like PCL (Point Cloud Library) or GDAL (Geospatial Data Abstraction Library). CMakeLists.txt facilitates the development of these powerful data processing pipelines. It ensures that the software can correctly link to the necessary geographic data libraries, image processing frameworks, and parallel computing APIs (like OpenMP or CUDA), enabling the creation of efficient applications that can transform raw sensor data into actionable insights, critical for precision agriculture, construction monitoring, and disaster response.
Rapid Prototyping and Collaborative Development
The agile nature of drone innovation demands rapid prototyping and efficient collaboration among developers. CMakeLists.txt fosters this by standardizing the build process. When new features are introduced, or new sensors are integrated, developers can quickly update the CMakeLists.txt to include new source files, link new libraries, or adjust build settings. This consistency minimizes “it works on my machine” issues and accelerates the development cycle. In large teams, where different engineers might work on separate modules (e.g., one on flight control, another on computer vision, and a third on the ground station interface), CMake ensures that all components can be built together harmoniously from a unified project structure. This collaborative efficiency is paramount for bringing complex, innovative drone capabilities to market quickly.
Best Practices and Future Trends for CMake in Drone Tech
To fully leverage CMakeLists.txt in drone innovation, adhering to best practices and staying abreast of future trends is essential.
Maintainability and Scalability
As drone software grows in complexity, well-structured CMakeLists.txt files become vital for maintainability. This involves organizing projects into logical subdirectories, each with its own CMakeLists.txt file (managed by add_subdirectory()), defining clear targets, and using descriptive variable names. For large-scale projects, leveraging CMake’s modules and functions can encapsulate common build logic, reducing redundancy and improving readability. Scalability also means designing the build system to accommodate future additions, whether it’s support for a new drone platform, an additional sensor, or a new AI algorithm. A well-designed CMakeLists.txt structure allows for seamless expansion without major overhauls.
Integration with CI/CD Pipelines
Continuous Integration/Continuous Deployment (CI/CD) pipelines are fundamental for ensuring the quality and reliability of complex drone software. CMakeLists.txt plays a critical role here, as it provides a standardized interface for automated build and test processes. CI/CD systems can invoke CMake to configure and build the project, run unit tests (using CTest, CMake’s testing tool), and even generate deployment artifacts. This automation drastically reduces human error, speeds up the release cycle, and ensures that every code change is validated against a consistent build environment, which is paramount for mission-critical drone applications.
Community Standards and Open-Source Contribution
The drone industry, particularly in areas like flight controllers and robotics operating systems, benefits immensely from open-source collaboration. Projects like PX4 Autopilot, ArduPilot, and ROS (Robot Operating System) heavily rely on CMake. Contributing to or utilizing these open-source projects often requires understanding and interacting with their CMakeLists.txt files. Adhering to community standards and conventions for CMake usage facilitates collaboration, knowledge sharing, and the integration of new technologies from the broader robotics and software engineering communities into the drone ecosystem. As drones become more sophisticated and integrated into various sectors, the role of a robust, standardized build system like CMake will only grow, underpinning the next wave of technological breakthroughs.