
The Fundamentals of Wheel Alignment in Advanced Robotic Systems
In the rapidly evolving landscape of Tech & Innovation, the discussion around drones often centers on aerial capabilities—flight dynamics, sensor payloads, and autonomous navigation in three-dimensional space. However, as the utility of unmanned systems expands, a significant area of innovation involves ground-based robotic platforms and hybrid air-ground vehicles. These systems, critical for tasks like long-duration remote sensing, precision mapping in complex terrains, or last-mile delivery, rely fundamentally on sophisticated ground mobility. For any wheeled robotic system designed for stable, efficient, and precise movement, understanding wheel alignment parameters such as caster and camber angle is not merely beneficial but essential. These concepts, traditionally rooted in automotive engineering, find new relevance in the design and optimization of cutting-edge ground-based drone innovations and their integrated counterparts.
Caster Angle Explained
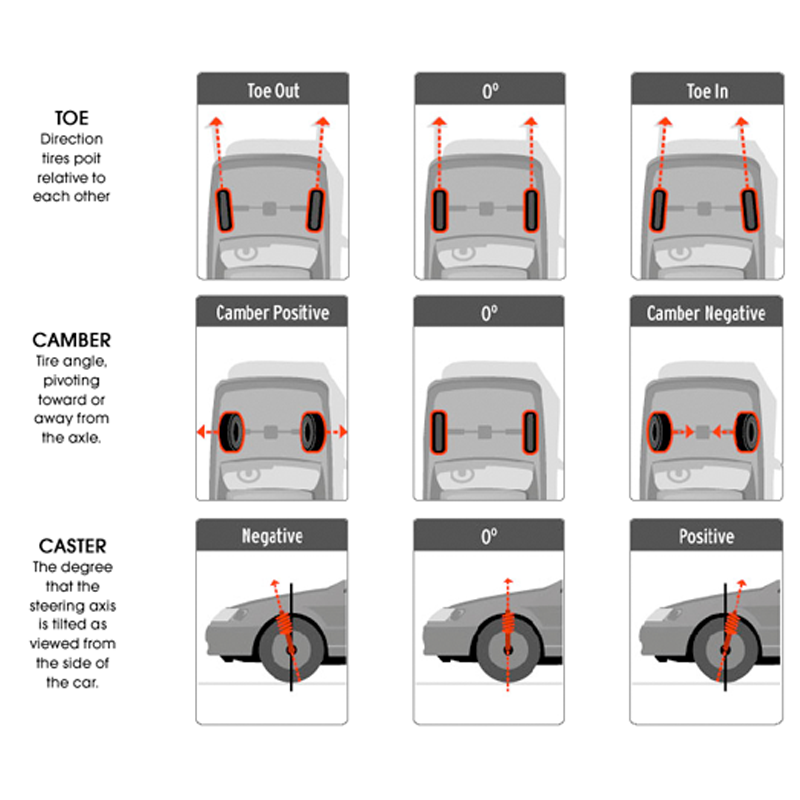
Caster angle refers to the angular displacement of a wheel’s steering axis from the true vertical axis when viewed from the side of the vehicle. Imagine a line running through the upper and lower pivot points of a wheel’s steering mechanism (or the simulated pivot point for a fixed wheel in a multi-wheeled ground drone). If the top of this line is tilted rearward, it’s known as positive caster. If it’s tilted forward, it’s negative caster.
For ground-based drones and robotic rovers, the caster angle plays a crucial role in steering stability and self-centering. A positive caster angle provides a self-centering effect on the steering, meaning the wheels naturally tend to return to a straight-ahead position after a turn. This characteristic is vital for maintaining a straight trajectory during autonomous missions, reducing the constant corrective steering input required from the control system. It enhances directional stability at higher speeds, making the ground platform less susceptible to deviations caused by uneven terrain or external forces. Conversely, too much positive caster can make steering heavy and less responsive, which might be undesirable for agile ground-based surveillance or object manipulation tasks. The precise calibration of caster angle allows developers of advanced drone innovations to fine-tune the balance between stability and maneuverability, ensuring optimal performance across diverse operational environments for systems engaged in remote sensing, mapping, or autonomous navigation.
Camber Angle Explained
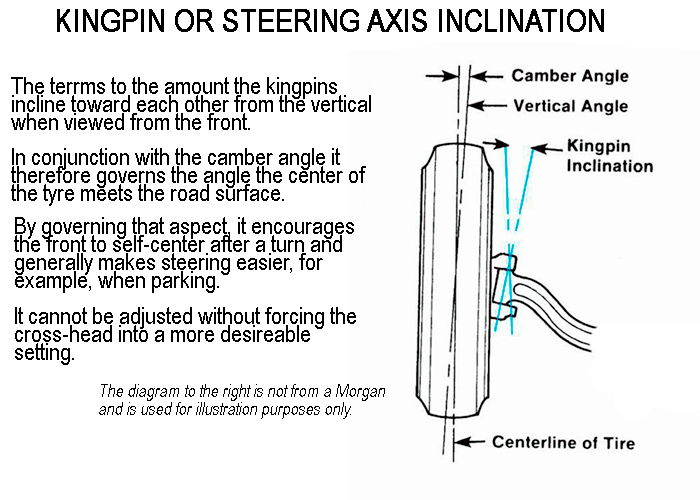
Camber angle describes the angular tilt of a wheel when viewed from the front or rear of the vehicle. If the top of the wheel tilts outward away from the vehicle, it’s referred to as positive camber. If the top of the wheel tilts inward towards the vehicle, it’s negative camber. When the wheel is perfectly vertical, the camber is zero.
In the context of ground-based robotic platforms and hybrid drone systems, camber angle significantly influences tire-to-ground contact patch and load distribution, which in turn affects traction, stability during turns, and component wear.
Negative camber, where the top of the wheels tilt inward, is often employed in ground vehicles designed for high-speed cornering or traversing uneven terrain. It helps maintain a flatter contact patch with the ground during turns, enhancing grip and lateral stability—a critical factor for agile ground drones maneuvering complex environments or quickly changing direction during an autonomous mapping sequence. However, excessive negative camber can lead to uneven tire wear on the inside edge, reducing the lifespan of components, which is a key consideration for long-duration autonomous missions where maintenance is infrequent.
Positive camber, though less common in performance-oriented ground robotics, can be used to optimize load distribution in specific scenarios, particularly for vehicles carrying heavy, off-center payloads or designed to operate primarily on soft, deformable surfaces. The meticulous adjustment of camber angle is a nuanced engineering decision that directly impacts the overall efficiency, durability, and operational effectiveness of wheeled platforms integrated into modern drone ecosystems.
Why These Angles Matter for Ground-Based Drone Innovation
The precise understanding and implementation of caster and camber angles are paramount for the next generation of ground-based drone innovations and hybrid air-ground systems. These parameters move beyond simple mechanical alignment to become fundamental elements in the overall design philosophy, influencing everything from power consumption to the accuracy of data collection in challenging environments. As the complexity of autonomous missions grows, the reliability and performance of the ground mobility platform become as critical as the aerial component itself.
Enhancing Stability and Steering Precision
For autonomous ground vehicles, whether they serve as mobile sensor platforms, drone launch/recovery systems, or reconnaissance robots, predictable and stable movement is non-negotiable. Correct caster angle contributes significantly to straight-line stability, ensuring that the ground drone maintains its intended trajectory with minimal steering correction. This is particularly valuable for long-distance autonomous navigation, where cumulative errors from steering drift can lead to mission failure. The self-centering effect of positive caster also reduces the workload on actuators and control algorithms, leading to more energy-efficient operation—a crucial factor for battery-dependent robotic systems.
Similarly, an optimized camber angle can dramatically improve a ground drone’s handling characteristics, especially when navigating uneven terrain or performing tight turns. In applications like precision agriculture mapping or infrastructure inspection, ground drones often need to follow precise paths and execute sharp maneuvers around obstacles. Proper camber ensures maximum tire contact during these dynamic movements, enhancing grip and preventing rollovers, thereby safeguarding valuable onboard sensors and payloads. The ability to maintain stability and precise steering control directly translates to higher mission success rates and superior data quality, underpinning the core value proposition of advanced robotic solutions in Tech & Innovation.
Optimizing Tire Wear and Traction for Autonomous Operations
Beyond stability and steering, caster and camber angles have a profound impact on the lifespan of tires and the effectiveness of traction—critical considerations for the economic viability and operational longevity of ground-based drone systems. Uneven tire wear caused by poorly configured alignment angles can lead to premature replacement costs and increased maintenance downtime, directly affecting the operational efficiency of a fleet of autonomous vehicles. In remote or hostile environments, where resupply and maintenance are challenging, maximizing component lifespan is an engineering imperative.
Furthermore, optimal alignment ensures that the ground drone can achieve maximum traction under various conditions. For systems designed to traverse sand, gravel, mud, or rock, the contact patch of the tire is paramount. Correct camber angle ensures that the tire makes even contact with the surface, distributing the vehicle’s weight uniformly across the tread. This maximizes the available grip for propulsion and braking, enabling the ground drone to overcome obstacles and maintain mobility in adverse conditions. For autonomous systems where human intervention is limited, reliable traction is directly linked to mission completion, whether it’s deploying sensors for environmental monitoring or transporting vital supplies across challenging terrain as part of a hybrid drone logistics network.
Applications in Advanced Drone and Robotic Mobility
The principles of caster and camber angles are increasingly being integrated into the design and control of sophisticated ground-based drone innovations, moving beyond theoretical concepts to practical, real-world applications that are reshaping industries from logistics to environmental monitoring.
Hybrid Drone-Rovers for Diverse Environments
One of the most exciting areas of innovation is the development of hybrid drone-rovers—vehicles that combine the aerial capabilities of a drone with the robust ground mobility of a rover. These systems are designed to overcome the limitations of purely aerial or purely ground-based platforms. For example, a hybrid system might fly over an impassable canyon and then land to deploy ground-based sensors that require stable, long-term placement, or traverse dense foliage that an aerial drone cannot penetrate.
In such hybrid designs, the ground mobility component is crucial, and here, caster and camber angles become critical. These rovers often face extremely diverse and unpredictable terrains, from smooth indoor floors to rugged outdoor landscapes. Optimizing caster ensures the ground module maintains directional stability during autonomous navigation on varied surfaces, providing predictable handling whether driving across a paved area or through loose gravel. Camber optimization allows for maximized tire contact and traction, essential for climbing obstacles, descending slopes, and maintaining stability during lateral movements. The ability to fine-tune these angles, even dynamically in some advanced prototypes, allows hybrid drone-rovers to seamlessly transition between different operational modes and environments, significantly expanding their mission versatility and effectiveness in tasks such like exploration, surveillance, or search and rescue.
Precision Ground Platforms for Mapping and Remote Sensing
While aerial drones excel at broad-area mapping, ground-based robotic platforms offer unparalleled precision for localized mapping, ground-penetrating radar, subsurface inspection, and collecting detailed sensor data that requires direct contact or close proximity to the ground. These ground-based systems often work in conjunction with aerial drones, providing complementary data sets for comprehensive environmental or infrastructure assessments.
For these precision ground platforms, the accuracy of data collection is directly tied to the stability and predictability of their movement. Caster angle contributes to the robot’s ability to maintain a straight line with high fidelity, which is critical for creating accurate transects for sensor sweeps or generating high-resolution 3D models of specific ground features. Any deviation in path can introduce errors into the collected data, compromising the integrity of the mapping or sensing mission. Camber angle, by optimizing the tire-to-ground contact, ensures consistent traction and minimizes slippage, preventing jerky movements that could disturb sensitive instruments or degrade data quality. The design and calibration of these angles are thus integral to maximizing the efficacy of ground-based drone innovations in scientific research, industrial inspection, and agricultural intelligence, where millimeter-level accuracy is often a prerequisite.
The Future of Integrated Air-Ground Mobility
As drone technology continues to push boundaries within Tech & Innovation, the integration of air and ground mobility is becoming an increasingly important frontier. The foundational principles of wheel alignment, specifically caster and camber, will continue to evolve in sophistication, moving towards adaptive and intelligently controlled systems.
Software Control and Adaptive Geometry
The next generation of ground-based drone innovations may feature active suspension and wheel alignment systems, where caster and camber angles can be dynamically adjusted on the fly, controlled by advanced AI algorithms. Imagine a ground drone detecting an upcoming steep slope and automatically adjusting its camber for optimal climbing traction, or reconfiguring its caster for enhanced stability on a high-speed straightaway. This adaptive geometry, managed by sophisticated software, would allow a single platform to optimize its performance across an unprecedented range of terrains and tasks, from traversing dense urban environments to navigating rugged off-road conditions. Such intelligent systems would revolutionize the autonomy, efficiency, and robustness of hybrid drone operations.

Beyond Traditional Wheels: Legged and Tracked Systems
While caster and camber angles are inherently tied to wheeled systems, the underlying principles of stability, contact patch optimization, and directional control extend conceptually to other forms of ground mobility. As ground-based drones and robots explore legged or tracked designs for extreme terrain, the lessons learned from optimizing wheeled alignment will inform the design of articulated limbs and track systems. The goal remains the same: to ensure maximum stability, efficient movement, and robust performance across the most challenging environments. Whether it’s through adjustable leg kinematics that mimic optimal “camber” for ground engagement or tracking systems that dynamically adjust their “caster” equivalent for superior steering, the pursuit of enhanced ground mobility will continue to be a cornerstone of drone innovation, pushing the boundaries of what unmanned systems can achieve in a multi-domain operational landscape.