
In the dynamic realm of drone technology and innovation, where autonomous flight, sophisticated AI follow modes, and real-time remote sensing are becoming standard, the underlying logic that orchestrates these complex systems is paramount. At the heart of this logic, within the Python programming language widely adopted for drone software development, lies the Boolean data type. Far from a mere theoretical concept, Boolean values—True and False—are the fundamental building blocks for all decision-making processes, conditional executions, and state management that define an intelligent drone’s operational capabilities. Understanding booleans in Python is not just about grasping a programming primitive; it’s about comprehending the very mechanism by which drones perceive their environment, interpret data, and respond autonomously, pushing the boundaries of what these aerial vehicles can achieve.

The Foundational Logic of Autonomous Drone Systems
The ability of a drone to operate autonomously, from navigating complex environments to executing precise maneuvers, relies entirely on its capacity to make decisions. These decisions are invariably rooted in binary evaluations: is a condition met or not? Is a sensor reading within tolerance? Is the target in sight? Each of these questions resolves to a True or False outcome, which is precisely what the Boolean data type in Python represents.
The Binary Core: True and False
In Python, True and False are built-in keywords representing the two possible states of a Boolean value. They are not strings or numbers but distinct data types. True signifies an affirmative or valid condition, while False denotes a negative or invalid one. For instance, a drone’s flight control system might evaluate whether altitude_safe is True before initiating a descent, or if obstacle_detected is False before proceeding along a planned trajectory. These simple binary states form the bedrock of complex control algorithms, allowing the drone’s onboard computer to interpret its environment and the status of its internal systems. Without this basic true/false dichotomy, even the most rudimentary autonomous functions would be impossible.
Decision Making with Comparison Operators
The power of booleans comes to life when combined with comparison operators, which evaluate relationships between values and return a Boolean result. These operators are critical for a drone’s ability to monitor its own performance, track objects, and avoid hazards.
Consider a drone running Python-based flight software:
==(Equals):current_speed == target_speedmight returnTrueif the drone is maintaining its intended velocity, orFalseif it’s drifting.!=(Not equals):battery_level != 0would beTrueas long as the battery has power, preventing a sudden loss of control.<(Less than):temperature < critical_tempcould beTruefor normal operation, triggering an alert or shutdown ifFalse.>(Greater than):signal_strength > minimum_thresholdensures reliable communication with the ground station.<=(Less than or equal to):distance_to_obstacle <= safety_bufferwould returnTrueif the drone is too close, initiating an avoidance maneuver.>=(Greater than or equal to):payload_weight >= max_capacitycould prevent takeoff if the drone is overloaded.
These comparisons are constantly performed in real-time by a drone’s flight controller, providing the essential True/False inputs for its operational logic.
Boolean Operators: Orchestrating Complex Drone Behaviors
While simple comparisons are vital, real-world drone operations demand the evaluation of multiple conditions simultaneously. This is where Python’s boolean operators—and, or, not—become indispensable. They allow drone engineers to combine and manipulate Boolean values, creating sophisticated logical expressions that govern intricate autonomous behaviors.
AND: Ensuring Multi-Condition Readiness
The and operator returns True only if all the conditions it connects are True. This is crucial for scenarios where several prerequisites must be met before an action can be safely executed.
For example, an AI-powered drone might only initiate an autonomous mapping mission if:
gps_locked and sufficient_battery and weather_clear.
If any of these conditions areFalse(e.g., GPS signal is weak, battery is low, or it’s raining), the entireandexpression evaluates toFalse, and the mission will not commence, thus preventing potentially hazardous situations. This operator is fundamental in robust pre-flight checks and complex mission planning.
OR: Handling Alternative Scenarios
The or operator returns True if at least one of the conditions it connects is True. This is particularly useful for redundancy, fallback mechanisms, or accepting multiple valid inputs for a single action.
Consider an obstacle avoidance system:
(front_sensor_blocked or side_sensor_blocked) and evasive_maneuver_possible.
Here, if either the front or side sensor detects an obstacle, the drone considers an evasive action. Similarly, a drone might decide to return home if(battery_critical or communication_lost), providing multiple triggers for a critical safety protocol. Theoroperator ensures flexibility and resilience in responding to diverse environmental and operational challenges.
NOT: Inverting States and Conditions
The not operator inverts the Boolean value of a single condition. If a condition is True, not makes it False, and vice versa. This is invaluable for expressing negative conditions or flipping the logic of an existing state.
For instance, a drone might use not to confirm safety before proceeding:
if not obstacle_ahead:move_forward().
Or to manage system states:if not payload_attached:adjust_gimbal_for_empty_flight().
Thenotoperator simplifies the expression of conditions that are more naturally stated in the negative, making code cleaner and more intuitive for developers working on drone intelligence.
Conditional Execution: The Intelligence Behind Smart Drones
The true intelligence of autonomous drones manifests through their ability to execute different actions based on different conditions. Python’s conditional statements—if, elif, else—are the primary constructs that leverage Boolean logic to achieve this dynamic behavior.
if, elif, else: Guiding Flight Paths and Responses
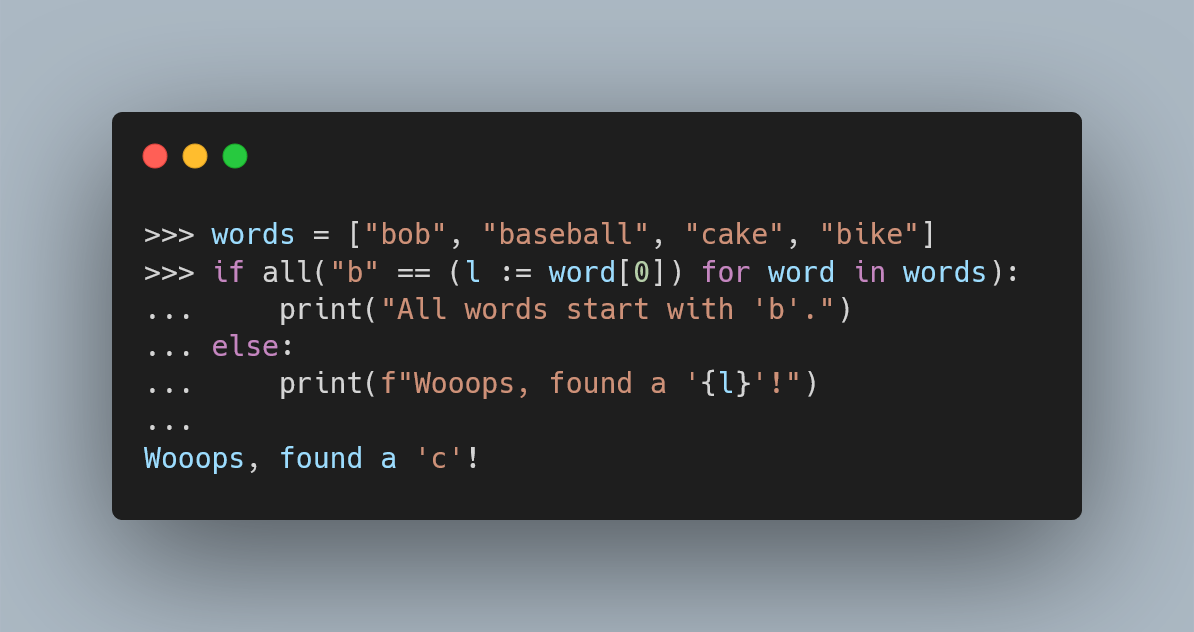
These statements allow a drone’s program to follow specific execution paths depending on whether certain Boolean conditions are True or False. This forms the core of its decision-making capabilities.
if obstacle_detected:
    initiate_evasive_maneuver()
elif low_battery_warning:
    return_to_home()
else:
    continue_mission_path()
In this simplified example for an autonomous drone, if an obstacle_detected is True, the drone prioritizes avoidance. If no obstacle but low_battery_warning is True, it executes a return-to-home sequence. Otherwise, if neither is True, it proceeds with its mission_path. This nested logic, driven by Boolean outcomes, enables adaptive and intelligent responses to a constantly changing operational environment.
Loops and Booleans: Continuous Monitoring and Adaptation
Booleans are also critical for controlling the flow of loops, allowing drones to continuously monitor sensors, process data, and adapt their behavior. A while loop, for instance, continues to execute as long as its Boolean condition remains True.
is_mission_active = True
while is_mission_active:
    # Read sensor data
    # Process camera feed for object tracking
    # Check battery level
    # Check for ground station commands

    if mission_complete or battery_critical or emergency_stop_command:
        is_mission_active = False # Set to False to exit loop
        initiate_landing_sequence()
This pattern ensures the drone’s systems are constantly vigilant, processing information and making decisions until a condition (like mission completion or an emergency) dictates a change in overall state, ultimately setting is_mission_active to False to halt the main operational loop.
Practical Applications in Drone Tech & Innovation
The practical applications of Boolean logic in Python for drone technology and innovation are extensive, impacting everything from navigation to data analysis.
AI Follow Mode and Object Tracking
In advanced AI follow modes, booleans are used extensively to manage tracking states.
if target_in_frame and tracking_locked:maintain pursuit.if not target_in_frame and search_mode_active:initiate search pattern.if object_identified_as_threat:trigger alarm or evasive action.
Boolean flags help the AI system understand if it has a lock on the target, if the target is visible, or if specific criteria for identifying the target have been met, enabling seamless and intelligent object tracking.
Advanced Obstacle Avoidance
Modern drones employ multiple sensors (LiDAR, ultrasonic, vision) for robust obstacle avoidance. Boolean logic integrates these inputs:
if (lidar_front_obstacle or ultrasonic_left_obstacle) and (not evasive_action_already_taken):calculate new path.if camera_detects_no_fly_zone_marker and altitude_below_threshold:ascend.
The complex interplay of sensor data is reduced toTrue/Falseconditions, which then inform the drone’s real-time path planning algorithms, ensuring safe and dynamic navigation.
Real-time Data Processing for Remote Sensing
For remote sensing applications, drones collect vast amounts of data. Booleans are essential for filtering, classifying, and processing this information in real-time.
if infrared_reading > vegetation_threshold:classify_pixel_as_plant_life().if thermal_signature_present and temperature_above_average:flag_for_further_inspection().if data_packet_checksum_valid:store_data_point().
This conditional processing allows for immediate insights, anomaly detection, and efficient storage of only valid and relevant data, which is critical for applications like precision agriculture, environmental monitoring, or infrastructure inspection.
Beyond the Basics: Advanced Boolean Concepts and Future Drone Intelligence
As drone technology evolves, so too does the sophistication of its underlying software. Advanced uses of booleans extend to managing complex system states and integrating with machine learning outputs.
Boolean Flags and State Management
In larger, more intricate drone software architectures, Boolean flags are used to denote the current state or status of various subsystems. For example, arming_sequence_complete = True, gimbal_calibrated = False, data_logging_active = True. These flags provide a quick, binary overview of the drone’s readiness and ongoing operations, simplifying debugging and state transitions within the flight controller’s finite-state machine.
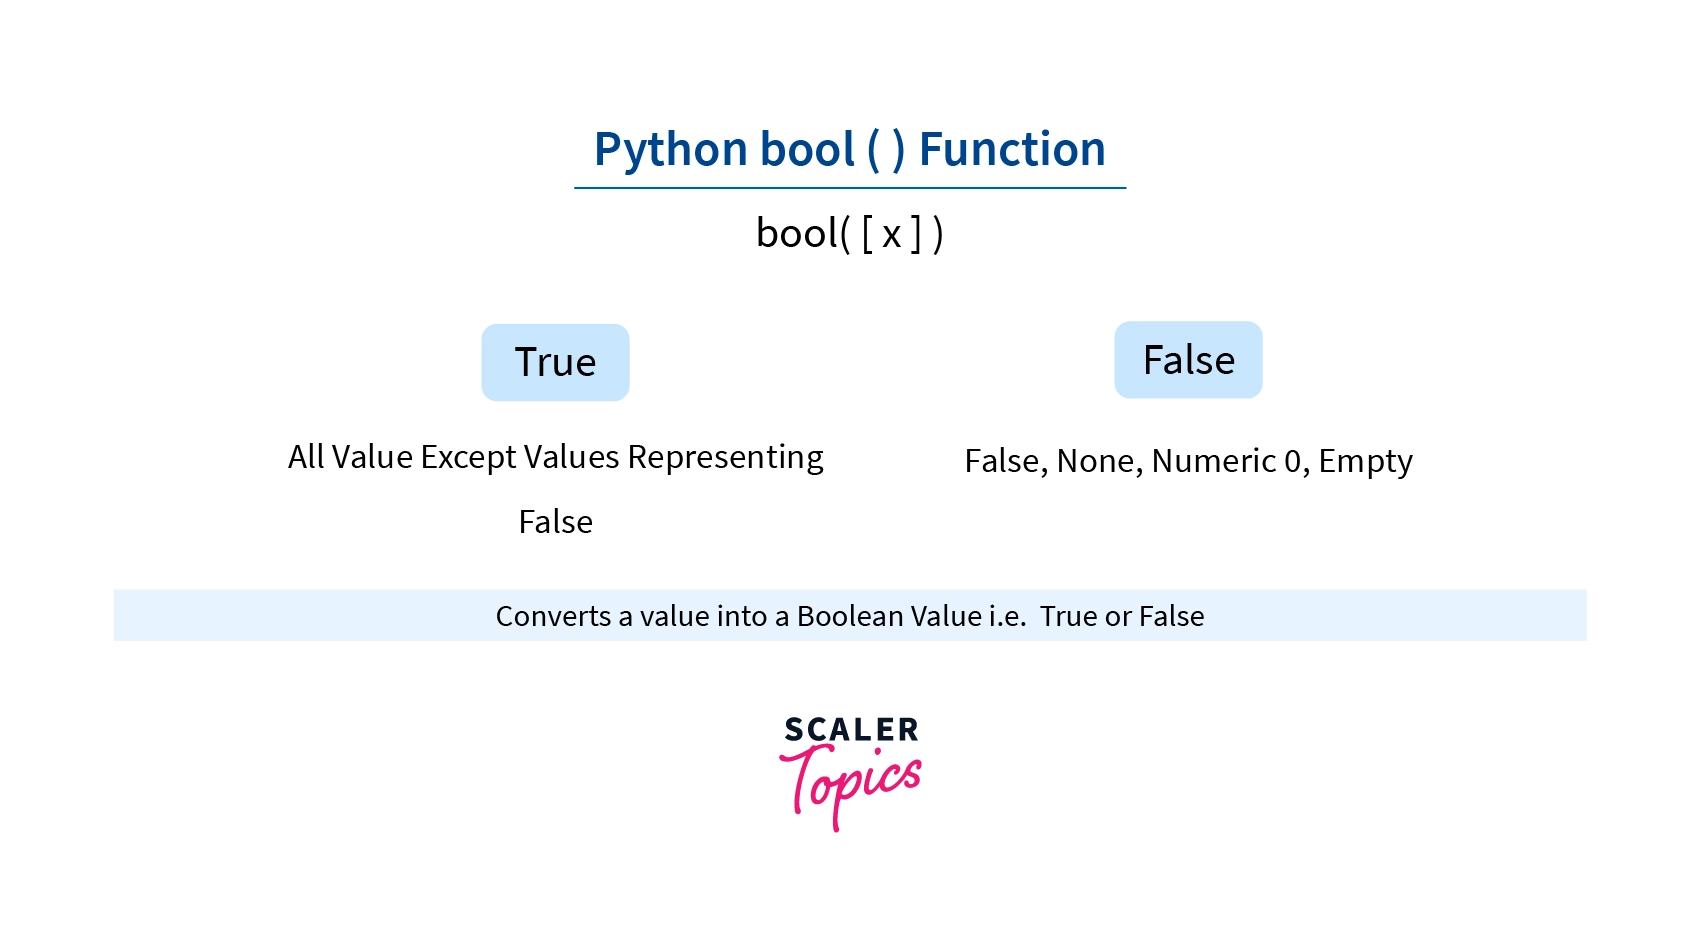
Integrating Boolean Logic with Machine Learning Outputs
Machine learning models, particularly those used for computer vision in drones, often output probabilities or classifications. These outputs are frequently converted into Boolean values for decision-making.
- If an object detection model predicts a “human” with 90% confidence, a developer might set
human_detected = (confidence > 0.8). - If an anomaly detection algorithm returns a score,
anomaly_present = (score > anomaly_threshold).
This conversion bridges the gap between probabilistic AI outputs and the deterministic Boolean logic required for immediate, actionable decisions by the drone’s flight control system, enabling truly intelligent and reactive aerial platforms.
In conclusion, Booleans in Python are far more than just True or False. They are the indispensable logical backbone empowering the sophisticated functionalities that define modern drone technology and innovation. From safeguarding autonomous flight to enabling real-time intelligent responses for complex missions, the elegant simplicity of Boolean logic underpins the cutting-edge capabilities transforming the aerial landscape. Mastering this fundamental concept is crucial for anyone involved in developing the next generation of smart, autonomous drones.