
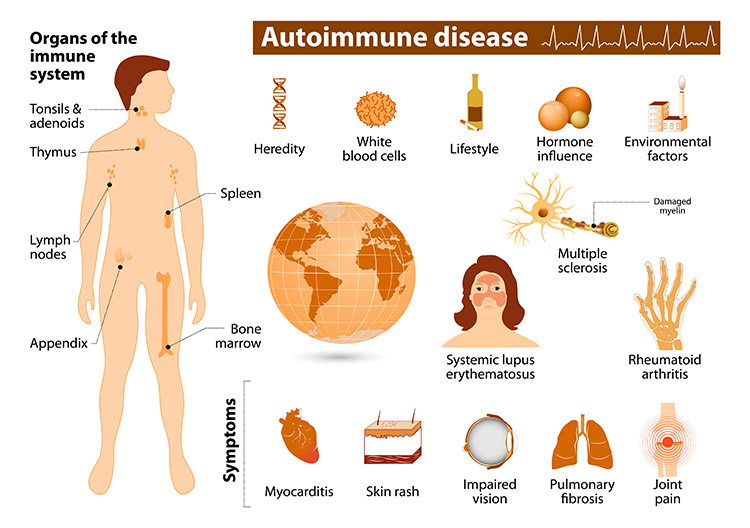
The term “autoimmune” traditionally evokes images of the human body’s intricate biological systems mistakenly attacking its own healthy tissues. This phenomenon, where internal defense mechanisms misidentify benign elements as threats, leading to self-inflicted harm, offers a powerful analogy for understanding potential vulnerabilities and advanced failure modes within complex technological systems, particularly in the rapidly evolving domain of drone technology and autonomous flight. As drones become more sophisticated, incorporating advanced AI, intricate sensor arrays, and self-diagnosing capabilities, the conceptual risk of an “autoimmune” system—where internal processes or algorithms inadvertently undermine the system’s own operational integrity—becomes a pertinent area of consideration for engineers, developers, and operators alike in the Tech & Innovation sphere.
The Analogy in Autonomous Systems
In the realm of autonomous drones, an “autoimmune” scenario refers to a situation where the drone’s internal monitoring, diagnostic, or control systems misinterpret essential operational data or components as detrimental, subsequently initiating corrective or protective actions that paradoxically lead to system degradation, instability, or mission failure. This is distinct from external interference or component wear; instead, it originates from an internal logic flaw, a calibration error, or an overzealous self-preservation mechanism. For instance, an AI-powered flight controller, designed to detect and correct anomalies, might begin to ‘fight’ against valid sensor readings or even its own primary control inputs if a subtle, underlying bug or miscalibration causes it to perceive these as errors. The consequences can range from minor erratic movements to a complete loss of control, mirroring the spectrum of effects seen in biological autoimmune disorders.
Self-Correction vs. Self-Sabotage
The boundary between robust self-correction and detrimental self-sabotage is critically thin in autonomous systems. Modern drones employ sophisticated stabilization systems, redundant sensors, and AI algorithms that constantly monitor flight parameters, component health, and environmental data. These systems are designed to identify and mitigate issues like motor failure, sudden wind gusts, or GPS signal loss. They perform a critical ‘immune’ function, protecting the drone from internal and external threats. However, if the logic governing these self-correction mechanisms becomes flawed, an internal feedback loop could emerge where the system continuously tries to ‘fix’ a non-existent problem or overcompensates for a minor transient, thereby inducing a larger, systemic instability.
Consider a drone with an advanced AI navigation system equipped with an ‘intelligent’ obstacle avoidance module. If this module, due to a software glitch or environmental misinterpretation (e.g., reflections, sensor noise), begins to falsely flag harmless elements within its own flight path or even parts of its own structure (like propellers in certain light conditions) as obstacles, it could initiate evasive maneuvers unnecessarily. Repeated or sustained false positives could lead the drone into an energy-draining, circuitous route, or worse, cause it to inadvertently collide with actual obstacles while attempting to avoid phantom ones. In an extreme case, a drone’s internal diagnostic system might interpret a perfectly functioning component’s unique operational signature as an anomaly, leading to a self-initiated shutdown or isolation of that critical component, ultimately compromising the entire mission. This continuous internal struggle, where the system’s own protective measures become its undoing, is the essence of an “autoimmune” failure in a drone.
Diagnostic Paradoxes and AI
The advent of Artificial Intelligence and Machine Learning (AI/ML) in drone technology introduces new layers of complexity to this “autoimmune” concept. AI-driven systems are designed to learn, adapt, and make autonomous decisions, often based on vast datasets and complex neural networks. While this capability offers unprecedented advancements in areas like AI follow mode, autonomous flight planning, and intelligent mapping, it also presents novel challenges regarding system interpretability and potential for self-generated errors.
Misidentifying Internal States

One significant area of concern lies in how AI-powered diagnostics or decision-making algorithms perceive and interpret the drone’s internal state. If an AI model, trained on specific failure patterns, encounters a novel, benign operational state that it misclassifies as a critical fault, it could trigger a series of incorrect responses. For example, slight, intended oscillations during certain advanced maneuvers or high-wind conditions might be misidentified by an over-sensitive AI diagnostic system as a flight instability requiring immediate, drastic correction. This could lead to a ‘diagnostic paradox’ where the system is healthy, but its own internal ‘health monitor’ declares it unwell and initiates disruptive ‘treatment’.
Furthermore, deep learning models can exhibit ‘black box’ characteristics, making it difficult to fully trace the reasoning behind their decisions. If an AI operating an autonomous drone begins to exhibit unexpected or self-defeating behaviors, pinpointing the exact internal trigger—whether it’s a corrupted data input, a faulty sensor interpretation, or an emergent property of the learned model itself—can be incredibly challenging. This lack of transparency can hinder rapid diagnosis and correction, allowing an “autoimmune” process to persist or escalate. The risk is magnified in scenarios requiring high reliability, such as remote sensing missions over critical infrastructure or delivery operations in complex urban environments, where an AI’s self-inflicted error could have significant consequences.
Building Resilient Autonomous Architectures
Preventing “autoimmune” failures in drones requires a multi-faceted approach focusing on robust system design, advanced fault tolerance, and intelligent monitoring mechanisms. The goal is to create systems that can distinguish between true threats and normal operational variance, and to implement self-correction that doesn’t inadvertently lead to self-sabotage.
Redundancy and Multi-Modal Validation
One fundamental strategy is the implementation of redundancy, not just in hardware (e.g., dual flight controllers, multiple GPS modules) but also in software logic and sensor data interpretation. Multi-modal validation involves using diverse sensor types (e.g., visual, infrared, radar, lidar) and processing their data through independent algorithms. If a discrepancy arises, no single sensor or algorithm should unilaterally dictate a drastic system response. Instead, a consensus mechanism or a hierarchical decision-making process should be employed to weigh evidence from various sources before initiating critical actions. This reduces the chance that a single point of failure or misinterpretation can trigger an “autoimmune” response across the entire system. For example, a single sensor anomaly would not cause an emergency landing unless corroborated by other sensors or validated by a broader system health check.
Human Oversight and Learning Systems
While autonomy is the objective, a sophisticated level of human oversight remains crucial, especially during the development and testing phases, and for complex missions. Telemetry data, system logs, and diagnostic reports must be designed for clarity and interpretability, allowing human operators to quickly identify unusual patterns that might indicate an emerging “autoimmune” issue. Beyond human oversight, the integration of advanced learning systems designed to learn from their own mistakes and continuously refine their diagnostic capabilities is paramount. This involves creating adaptive AI that can differentiate between actual system faults and false positives, gradually improving its ability to accurately assess internal states without overreacting. Such systems could, for example, flag a new type of vibration as unusual but hold off on initiating emergency procedures until further corroborating evidence or repeated occurrences are observed, then categorize and learn from this new data point. The goal is to develop an adaptive immunity that is precise rather than overzealous.
Future Implications and Preventative Measures
As drone technology progresses towards fully autonomous fleets and complex swarming behaviors, the risk of “autoimmune” system failures becomes even more pronounced. A single miscalibrated AI within a swarm could potentially trigger a chain reaction of erroneous behaviors across multiple units, leading to significant coordinated failure. Therefore, future development must prioritize not only individual drone resilience but also the collective “immune system” of a drone network.
Preventative measures will involve developing sophisticated simulation environments that can stress-test autonomous systems under an exhaustive range of normal and anomalous conditions, including injecting subtle data corruptions or simulated hardware glitches to observe how the AI responds. Furthermore, the concept of “explainable AI” (XAI) will be vital, allowing developers and operators to understand the rationale behind an autonomous system’s critical decisions. This transparency is key to diagnosing and rectifying the root causes of “autoimmune” behaviors before they can manifest in real-world operations. Ultimately, the quest is to build autonomous drone systems that are not only capable of extraordinary feats but are also intrinsically stable, self-aware, and immune to the potential of turning their formidable capabilities against themselves.