Reconceptualizing Antiport for Drone Technology
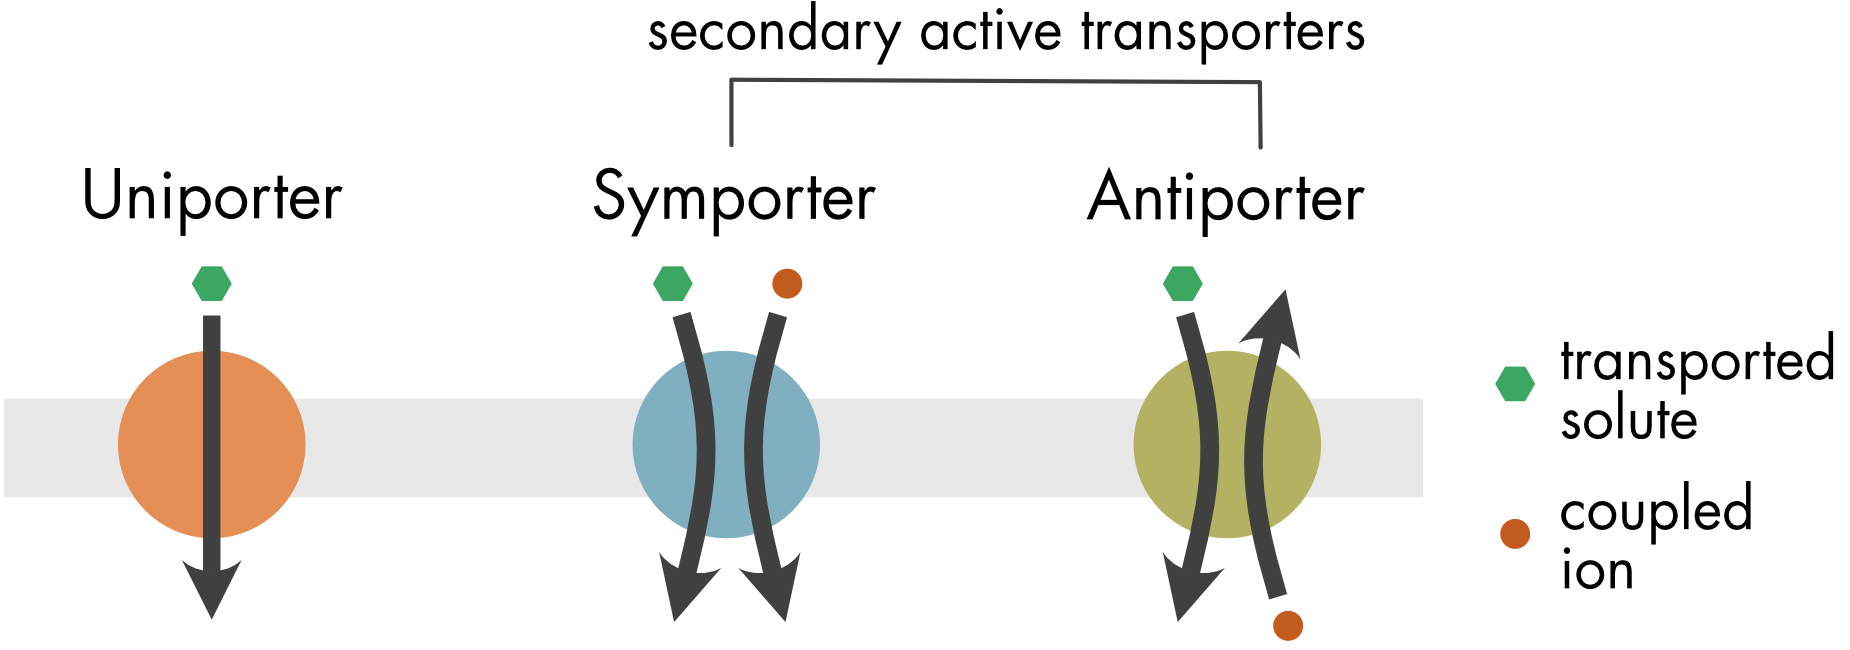
Traditionally, antiport describes a biological mechanism where two different substances are transported across a cell membrane in opposite directions simultaneously by a single protein. In the dynamic and rapidly evolving realm of cutting-edge drone technology and innovation, the concept of “antiport” transcends its biological origins to become a powerful metaphor for advanced system design, data flow management, and the intricate balancing of opposing forces within sophisticated unmanned aerial vehicles (UAVs). Here, antiport signifies a singular, integrated system or principle that efficiently orchestrates two counter-directional processes, data streams, or physical actions to achieve optimal performance, stability, or intelligent operation. This reconceptualization is vital as drones evolve beyond simple remote-controlled devices into complex, autonomous platforms that demand highly integrated and efficient operational methodologies.

From Biological Transport to Systemic Balance
The core idea of simultaneous, opposite movement is retained, but the “substances” and “carrier” are redefined. Instead of ions or molecules, we consider data packets, energy flows, control signals, or even physical forces. The “carrier” becomes an intelligent flight controller, a sophisticated sensor fusion algorithm, or an integrated propulsion system. This shift allows engineers to think about how a drone can manage conflicting demands or complementary functions through a unified, elegant solution, thereby reducing complexity and improving responsiveness. For instance, while a drone might be transmitting telemetry data out, it is simultaneously receiving control commands in. While not strictly “antiport” in the biological sense of a single protein carrying two different things in opposite directions, the underlying principle of managing opposing information or energy flows through a shared ‘channel’ or processing unit offers a compelling analogy for optimizing system architecture. This analogy is particularly pertinent in the drive towards miniaturization, enhanced computational efficiency, and robust autonomy in drone systems.
Antiport Principles in Autonomous Flight and Control Systems
The intricate dance of autonomous flight relies heavily on the ability to manage a myriad of opposing forces and data flows. Antiport principles provide a powerful conceptual framework for understanding how drones achieve unparalleled stability, navigate complex environments, and execute precise maneuvers with increasing autonomy.
Thrust Vectoring and Stability Management
Consider a multi-rotor drone maintaining a stable hover or executing a precise trajectory. Its motors generate upward thrust (a force) to directly counteract gravity (an opposing force). While no single “carrier protein” is involved, the flight controller acts as the central ‘antiport’ mechanism, constantly adjusting individual motor speeds to precisely balance these forces. Furthermore, during flight, the drone might adjust the thrust of opposing propellers (e.g., front-left and rear-right for yaw control) to induce or counteract rotational movement. This precise, simultaneous management of opposing thrust vectors, channeled through the sophisticated algorithms of the flight controller, is a prime example of an antiport-like operation ensuring both stability and agility. The system is continuously inputting sensor data from accelerometers, gyroscopes, and barometers, and simultaneously outputting motor commands in a dynamic feedback loop that balances deviations with corrective, opposing forces.
Navigation and Obstacle Avoidance
Autonomous navigation systems embody antiport principles through the continuous, integrated processing of environmental perception and directional control. A drone’s onboard sensors (Lidar, stereoscopic cameras, ultrasonic arrays) feed information about obstacles and terrain in, forming a detailed spatial map. Concurrently, its navigation algorithms and path planning modules simultaneously compute and issue commands out to adjust its flight path, ensuring avoidance of potential collisions or adherence to a predefined trajectory. This isn’t merely a sequential “sense-then-act” process; robust autonomous systems often predict future states based on current velocities and environmental dynamics, simultaneously managing immediate trajectory adjustments alongside strategic, longer-term path planning. This effectively processes “threat incoming” data against “safe path outgoing” commands through its AI-driven flight management unit, enabling dynamic and safe operation in complex, unpredictable environments.
AI Follow Mode and Dynamic Tracking
In advanced AI follow modes, the drone’s perception system is constantly monitoring a designated moving target, ingesting data in about its position, velocity, and predicted trajectory. Simultaneously, the flight control system is issuing commands out to adjust the drone’s own position and velocity, ensuring it maintains the designated follow distance and angle. The core challenge lies in managing the opposing dynamics: the target’s often unpredictable movement versus the drone’s controlled and calculated adjustments. The AI algorithms act as the antiport mechanism, harmonizing these opposing influences to keep the target seamlessly within the camera’s frame while ensuring stable and safe flight for the drone itself. This often involves real-time predictive modeling of the target’s movement and initiating counter-movements by the drone, demonstrating a sophisticated balancing act of dynamic perception and precise actuation.
Data Antiport in Remote Sensing and Mapping
Modern drones are unparalleled powerhouses for data collection, particularly in remote sensing, surveying, and mapping applications. The efficient management of vast, often complementary or even seemingly conflicting, data streams is where antiport concepts find significant relevance in optimizing drone operations.
Simultaneous Data Ingestion and Transmission
A high-performance mapping drone, for instance, might be actively collecting gigabytes of high-resolution imagery, multispectral data, or Lidar point clouds in from its primary sensors—a massive, continuous data stream. Simultaneously, it must transmit vital telemetry, health diagnostics, real-time sensor status, and perhaps even low-resolution preview data out to a ground station or cloud platform. The drone’s onboard communication and data processing units act as the antiport system, managing these two high-bandwidth, counter-directional flows through shared hardware and communication channels. This efficient multiplexing and concurrent processing are crucial for maintaining operational awareness, ensuring data integrity, and preventing data bottlenecks without overwhelming the system’s limited onboard computational and communication resources. The ability to dynamically prioritize and route these opposing data flows effectively is a hallmark of sophisticated and reliable drone systems.
Sensor Fusion for Enhanced Environmental Perception
Drones frequently employ multiple types of sensors (e.g., visual cameras, thermal cameras, Lidar, radar, ultrasonic sensors) that provide diverse, sometimes conflicting, yet ultimately complementary perspectives of the environment. The sensor fusion algorithms act as the ‘antiport’ mechanism, taking these heterogeneous inputs and processing them simultaneously to create a unified, more accurate, and robust environmental model. For example, thermal data might reveal heat signatures or targets invisible to optical cameras, while optical data provides fine textual details and color information lacking in thermal. The fusion algorithm effectively combines these “opposing” or distinct sensory perspectives into a holistic understanding, where the strengths of one sensor compensate for the weaknesses of another. This integrated approach effectively ‘transports’ different aspects of reality into a coherent internal representation that is richer and more reliable than any single sensor could provide.
Edge Computing and Cloud Integration
In advanced drone operations, the concept of antiport is evident in the strategic interplay between edge computing and cloud integration. Critical data processing, such as real-time object detection, immediate navigation decisions, or anomaly detection, occurs onboard at the ‘edge’ of the network in real-time. Simultaneously, less time-sensitive, aggregated, or processed data is prepared and transmitted out to cloud platforms for deeper analysis, long-term storage, machine learning model retraining, and broader enterprise integration. The drone’s onboard processing unit effectively serves as the antiport gateway, managing the immediate, localized data processing for mission-critical functions against the broader, distributed data transfer needs for strategic insights. This dual-direction processing and communication strategy optimizes bandwidth utilization, reduces latency for critical decisions, and leverages the massive scalability of cloud infrastructure for post-processing and archival.
The Future of Antiport in Drone System Architecture
As drone technology continues to push the boundaries of autonomy, efficiency, and intelligence, the metaphorical application of antiport principles will become even more pronounced in future system designs and operational paradigms.
Adaptive Energy Management
Future drones will likely feature highly sophisticated energy antiport systems. This could involve simultaneously drawing power for high-demand propulsion during ascent or aggressive maneuvers while regenerating energy during descent, through integrated solar cells, or via inductive charging during brief pauses. Intelligent power distribution networks would dynamically reallocate power between different subsystems (e.g., reducing sensor power during high-G maneuvers to boost propulsion, then reversing the flow for detailed imaging). These systems would manage the “input” and “output” of energy across various drone components through an intelligent power management unit, optimizing flight duration, operational flexibility, and payload capacity. The goal is to maximize the utility of every joule of energy, often by managing the trade-offs between different energy demands simultaneously and adaptively.
Biomimicry and Adaptive Autonomy
Drawing inspiration more directly from biological antiport mechanisms, future drone AI could implement adaptive learning algorithms that simultaneously balance exploration (seeking and acquiring new, novel information about an environment) with exploitation (efficiently using known, existing information to achieve mission goals). This ‘cognitive antiport’ would allow drones to learn and adapt to new, unfamiliar environments more efficiently, dynamically weighing the benefits of acquiring novel data against the immediate utility of existing knowledge. Such systems could autonomously decide when to prioritize detailed scanning (data in) versus direct mission execution (actions out), dynamically shifting between modes based on real-time environmental feedback, mission objectives, and perceived uncertainties. This sophisticated balance will be key to true autonomous intelligence.

Secure Communication and Counter-Measures
In increasingly sensitive and contested applications, drones must not only manage secure, legitimate data transmission (trustworthy information out) but also simultaneously monitor for and counter potential interference, jamming, or cyber threats (malicious signals in). An antiport-inspired security module could efficiently process these opposing communication flows, actively filtering out threats while ensuring the integrity and timely delivery of legitimate data, all within the same communication hardware and software stack. This advanced capability would significantly enhance the resilience and trustworthiness of drone operations in contested environments, balancing the critical need for open and effective communication with robust defensive mechanisms against cyber and electronic warfare attacks.
By embracing this expansive conceptual framework of antiport, drone engineers and innovators are poised to design more integrated, efficient, and intelligent UAV systems capable of performing complex tasks with unprecedented levels of autonomy, reliability, and adaptability. This metaphorical lens encourages a holistic view of drone architecture, fostering innovations that manage opposing forces and information flows as seamlessly and elegantly as nature itself.