
In the rapidly evolving landscape of drone technology, where data acquisition and analytical precision are paramount, understanding fundamental statistical concepts becomes increasingly vital. From optimizing autonomous flight paths to generating highly accurate topographical maps or monitoring vast agricultural fields, drones are sophisticated data collection platforms. However, raw data is only as valuable as the insights that can be extracted from it. This is where statistical tools, such as the Interquartile Range (IQR), play a crucial role in enhancing data analysis within the realm of Tech & Innovation, particularly in mapping, remote sensing, and the development of intelligent drone systems.
While often introduced in basic mathematics, the Interquartile Range is far from a theoretical abstraction when applied to real-world drone operations. It offers a robust measure of data variability, providing critical insights into the spread and consistency of the vast datasets generated by drone sensors. Unlike simpler measures like the range (maximum minus minimum), the IQR focuses on the central spread of data, making it less susceptible to extreme outliers—a common challenge when dealing with environmental sensor readings, GPS fluctuations, or complex terrain mapping.
Understanding Data Spread in Drone Operations
The operational efficacy of drones, especially in tasks like remote sensing, precision agriculture, and infrastructure inspection, hinges on the quality and reliability of the data they collect. Data spread, or variability, is a key characteristic that influences how we interpret these measurements and make informed decisions.
The Challenge of Variability in Remote Sensing
Drone-based remote sensing involves capturing diverse data types—from multispectral imagery for crop health assessment to LiDAR data for detailed 3D modeling. Each data point, whether it’s a Normalized Difference Vegetation Index (NDVI) value for a specific plant or an elevation reading at a coordinate, is subject to a degree of variability. This can arise from environmental factors (e.g., lighting changes, atmospheric conditions), sensor noise, minor calibration discrepancies, or inherent natural variations in the surveyed environment.
Consider a drone mapping a large construction site. The elevation data collected might show slight variations even across flat surfaces due to sensor error, minor drone altitude fluctuations, or even small debris. An average elevation value might hide these variations, but understanding the spread of these readings is crucial for validating the accuracy of the generated Digital Elevation Model (DEM). Similarly, in precision agriculture, monitoring nitrogen levels across a field with multispectral sensors might yield a range of values. A simple average might suggest a healthy field, but significant variability in specific zones could indicate patchy nutrient distribution requiring targeted intervention.
Beyond Averages: Why Median and Quartiles Matter
Traditional statistical measures like the mean (average) provide a central tendency but tell us little about how the data points are distributed around that center. The overall range (maximum – minimum) can be misleading because a single erroneous reading—a common occurrence with automated data collection—can drastically skew it.
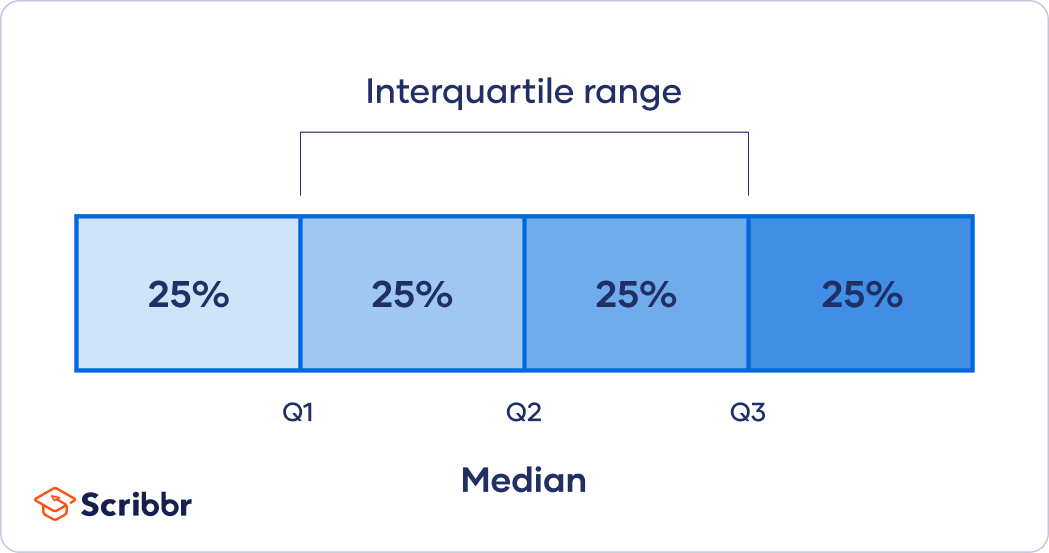
This is where the concept of the median and quartiles becomes particularly powerful. The median is the middle value in a sorted dataset, dividing it into two equal halves. It’s robust against outliers because its position is unaffected by extreme values. Building on this, quartiles further divide the data into four equal parts, each containing 25% of the data points.
- First Quartile (Q1): Represents the 25th percentile, meaning 25% of the data falls below this value. It’s essentially the median of the lower half of the data.
- Second Quartile (Q2): This is the median (50th percentile) of the entire dataset.
- Third Quartile (Q3): Represents the 75th percentile, meaning 75% of the data falls below this value. It’s the median of the upper half of the data.
By focusing on these quartiles, we can begin to isolate the central spread of the data, minimizing the influence of extreme values at the very ends of the spectrum.
Deconstructing the Interquartile Range (IQR)
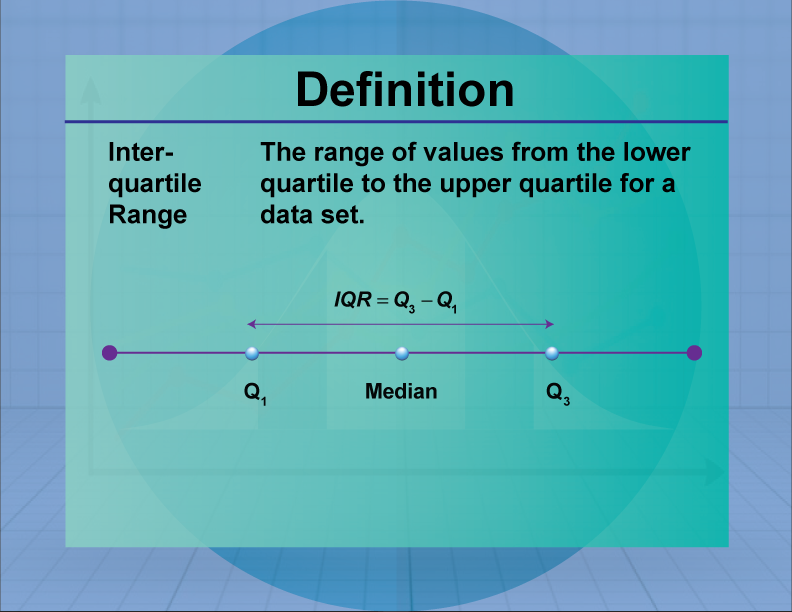
The Interquartile Range (IQR) is a measure of statistical dispersion, specifically the difference between the third quartile (Q3) and the first quartile (Q1). It quantifies the range over which the central 50% of the data points are spread.
Calculating the Quartiles
To calculate the IQR for a set of drone-collected data (e.g., sensor readings, GPS accuracy logs, image pixel intensities), the process generally follows these steps:
-
Collect and Sort Data: Gather all the relevant data points and arrange them in ascending order.
Example: A drone’s GPS logs 15 accuracy readings (in meters) for a specific hover point:[1.2, 1.5, 1.1, 2.8, 1.3, 1.6, 1.2, 1.4, 1.7, 1.3, 1.5, 1.8, 1.3, 1.6, 1.4]
Sorted Data:[1.1, 1.2, 1.2, 1.3, 1.3, 1.3, 1.4, 1.4, 1.5, 1.5, 1.6, 1.6, 1.7, 1.8, 2.8] -
Find the Median (Q2): Locate the middle value of the entire sorted dataset. If there’s an odd number of data points, it’s the exact middle value. If even, it’s the average of the two middle values.
Example: With 15 data points, the median is the 8th value ( (15+1)/2 = 8 ).
Q2 = 1.4 (the 8th value in the sorted list). -
Find Q1 (First Quartile): This is the median of the lower half of the data (excluding the overall median if the total number of points is odd).
Lower half:[1.1, 1.2, 1.2, 1.3, 1.3, 1.3, 1.4](7 data points)
Q1 = 1.3 (the 4th value in the lower half ( (7+1)/2 = 4 ) ). -
Find Q3 (Third Quartile): This is the median of the upper half of the data (excluding the overall median if the total number of points is odd).
Upper half:[1.5, 1.5, 1.6, 1.6, 1.7, 1.8, 2.8](7 data points)
Q3 = 1.6 (the 4th value in the upper half).

- Calculate the IQR: Subtract Q1 from Q3.
IQR = Q3 – Q1 = 1.6 – 1.3 = 0.3
The Significance of the IQR Value
An IQR of 0.3 meters in our GPS accuracy example means that the middle 50% of the drone’s GPS readings for that hover point fall within a range of 0.3 meters. This is a far more stable and reliable indicator of typical performance than the overall range, which in this case is 2.8 - 1.1 = 1.7 meters, heavily influenced by the 2.8 outlier.
A smaller IQR suggests that the central data points are clustered more tightly together, indicating less variability and higher consistency. A larger IQR suggests greater spread among the central 50% of the data. This insight is invaluable for setting performance benchmarks, evaluating sensor quality, or detecting anomalies in real-time drone operations.
Practical Applications of IQR in Drone Mapping and Analysis
The power of the Interquartile Range comes alive when applied to the diverse data streams generated by advanced drone systems. It offers a robust method for quality control, anomaly detection, and performance assessment across various drone-centric applications.
Identifying Outliers in Terrain Models
When drones equipped with LiDAR or photogrammetry sensors map large areas for infrastructure development or environmental monitoring, they collect millions of elevation points. Slight sensor glitches, reflective surfaces, or transient objects (e.g., a bird flying through the laser path) can lead to erroneous elevation readings—outliers that can severely distort the accuracy of a Digital Terrain Model (DTM).
Using the IQR, data analysts can systematically identify these outliers. Any data point that falls below Q1 - 1.5 * IQR or above Q3 + 1.5 * IQR is typically considered an outlier. This statistical rule provides a reliable, automated way to flag potentially incorrect elevation points for review or removal, ensuring the integrity of the generated terrain models. For instance, in analyzing a DTM derived from a construction site, an IQR analysis might flag areas where elevation data deviates significantly from the central 50% of readings, potentially indicating unrecorded changes, temporary structures, or mapping errors that need human inspection.
Assessing Sensor Data Consistency for Precision Agriculture
Precision agriculture relies heavily on drones for collecting multispectral data to assess crop health, water stress, and nutrient deficiencies. Indices like NDVI (Normalized Difference Vegetation Index) are derived from these spectral bands. For a large field, a drone might capture hundreds of thousands of NDVI values.
By calculating the IQR of NDVI values across different zones or over time, agriculturalists can gain deeper insights. A small IQR in a specific section of a field suggests consistent crop health, whereas a large IQR might indicate significant variability, highlighting areas with patchy growth or localized stress. This information allows for targeted application of fertilizers or pesticides, optimizing resource use and improving yield. For example, if the IQR for a particular crop section suddenly increases from one flight to the next, it could signify an emerging disease or pest infestation spreading inconsistently through the crop, prompting early intervention.
Quality Control for Environmental Monitoring Data
Drones are increasingly deployed for environmental monitoring, from tracking wildlife populations with thermal cameras to assessing water quality with specialized sensors. The data collected (e.g., animal counts, temperature readings, chemical concentrations) needs rigorous quality control.
The IQR serves as an excellent tool for flagging suspicious readings. In a thermal drone survey of a forest for fire detection, sudden, isolated spikes in temperature readings could be significant, but sensor noise can also produce high values. By analyzing the IQR of temperature data over a given area or flight path, anomalies significantly outside the central 50% spread can be identified as potential hotspots or, conversely, as sensor errors requiring validation. This systematic approach ensures that resources are not wasted chasing false positives, while critical environmental threats are accurately identified.
Enhancing Autonomous Flight and AI Models with IQR Insights
Beyond data analysis for human interpretation, the Interquartile Range also finds applications in refining the intelligence and autonomy of drone systems themselves.
Refining Anomaly Detection for Obstacle Avoidance
Autonomous drones rely on a suite of sensors (ultrasonic, LiDAR, vision cameras) for obstacle avoidance. These sensors continuously feed data about the drone’s surroundings to onboard processing units. In dynamic environments, unexpected sensor readings (e.g., a sudden, close object detection) need immediate attention.
However, not all unusual readings represent real threats. Environmental noise, reflections, or temporary obstructions can generate spurious data. Implementing IQR-based anomaly detection can enhance the robustness of obstacle avoidance systems. By maintaining a rolling window of sensor readings and continuously calculating the IQR, the drone’s AI can differentiate between typical sensor fluctuations and genuine, statistically significant deviations that indicate a potential collision threat. Readings falling outside the IQR’s outlier thresholds would trigger further verification or evasive maneuvers, minimizing false alarms and improving flight safety.
Improving Machine Learning Model Robustness
Machine learning models, central to features like AI Follow Mode, autonomous navigation, and intelligent data processing, are only as good as the data they are trained on. Noisy or outlier-laden training data can lead to biased or brittle models that perform poorly in real-world scenarios.
The IQR can be employed in the data preprocessing phase to clean and prepare datasets for machine learning. By using IQR-based outlier detection, developers can identify and either remove or transform anomalous data points before feeding them into training algorithms. This ensures that the models learn from representative data, leading to more robust object recognition for AI follow modes, more accurate predictive models for battery life estimation, or more reliable classification for remote sensing applications. For instance, if training a model to identify specific crop diseases from drone imagery, excluding images with extreme, non-representative pixel value distributions (identified by IQR) can significantly improve the model’s accuracy on typical disease patterns.
In conclusion, the Interquartile Range, though a basic mathematical concept, offers profound utility in the advanced technological sphere of drones. Its ability to provide a robust, outlier-resistant measure of data spread makes it an indispensable tool for data quality control, anomaly detection, and the development of more intelligent and reliable autonomous drone systems across mapping, remote sensing, and various other innovative applications. As drone technology continues to push boundaries, the nuanced insights provided by statistical measures like the IQR will only grow in importance.