
In the intricate world of flight technology, where precision, stability, and autonomous capabilities are paramount, the seemingly simple mathematical concept of a vertical line takes on profound significance. Far from being a mere abstract geometric construct, an “equation for a vertical line” underpins fundamental aspects of drone navigation, stabilization systems, sensor interpretation, and obstacle avoidance. Understanding how verticality is mathematically defined and physically manifested is crucial for developing robust and intelligent aerial platforms.
The Geometric Foundation: Understanding Verticality in Spatial Coordinates
At its core, a vertical line is defined by its orientation relative to a chosen reference frame. While this concept is straightforward in two-dimensional Cartesian coordinates, its application in the three-dimensional space occupied by flight technology necessitates a more nuanced understanding.
From 2D Abstraction to 3D Reality
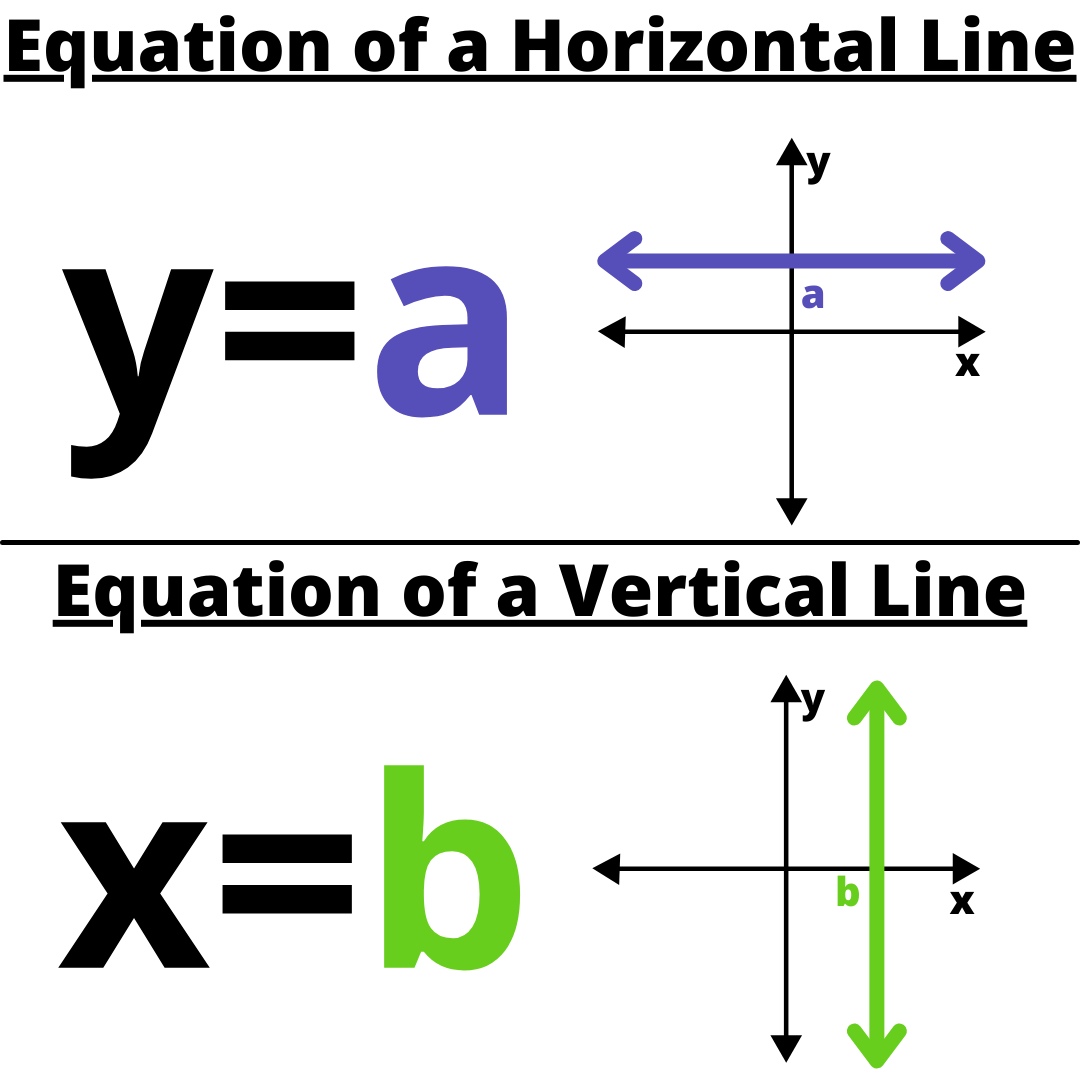
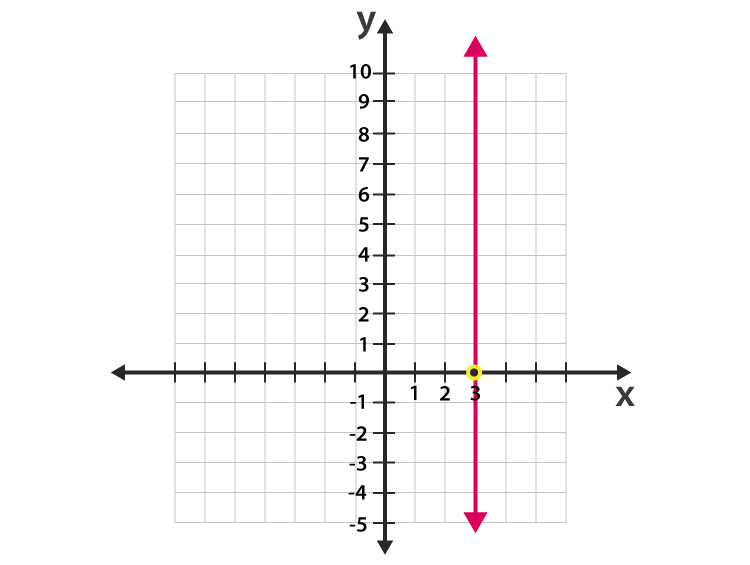
In basic analytic geometry, an equation for a vertical line in a 2D Cartesian plane (x, y) is simply x = k, where k is a constant. This means that for every point on the line, its x-coordinate remains unchanged, while its y-coordinate can vary infinitely. This representation is intuitive when visualizing a line parallel to the y-axis.
However, aerial vehicles operate in a 3D environment, where a third dimension (z) representing altitude or depth is critical. In a 3D Cartesian system (x, y, z), a “vertical line” typically refers to a line parallel to the z-axis. If the z-axis is aligned with the local gravity vector (pointing straight down or straight up), then a vertical line would be defined by constant x and y coordinates: x = k1 and y = k2. In this scenario, only the z-coordinate changes. This mathematical definition allows flight systems to define specific vertical paths or fixed vertical positions within their operational space.
Reference Frames and the Gravitational Vector
The interpretation of “vertical” is inherently tied to the chosen coordinate system or reference frame. For flight technology, several frames are commonly employed:
- Earth-Centered, Earth-Fixed (ECEF) Frame: This global coordinate system has its origin at the Earth’s center, with axes fixed relative to the Earth’s surface. While useful for global positioning, local verticality calculations are complex.
- North-East-Down (NED) Frame: This local tangent plane system is often used for navigation. Its origin is typically the drone’s initial position, with the X-axis pointing North, the Y-axis East, and the Z-axis Down. In this frame, a purely vertical ascent or descent involves changing only the Z-coordinate, while X and Y remain constant.
- Body Frame: This frame is fixed to the drone itself, with its axes aligned with the drone’s pitch, roll, and yaw axes. Sensors like Inertial Measurement Units (IMUs) primarily report data in this frame. The relationship between the body frame and the NED frame (or local vertical) is determined by the drone’s attitude (orientation).
The universal constant that defines “vertical” for an aerial vehicle is gravity. Accelerometers within an IMU constantly sense the direction and magnitude of the gravitational force. By integrating data from accelerometers, gyroscopes, and magnetometers, the flight controller can determine the drone’s orientation relative to the Earth’s gravitational vector, thus identifying which direction is “down” and, by extension, which direction is truly “vertical” in its local environment.
Crafting Flight Paths: Vertical Lines in Navigation and Waypointing
The ability to accurately define and follow vertical lines is fundamental to various aspects of drone navigation, from maintaining a stable hover to executing complex inspection maneuvers.
Precision Altitude Control and Vertical Hold
One of the most basic yet critical functions of any modern drone is altitude hold. This involves maintaining a constant vertical position relative to the ground or a specific reference altitude. Barometric pressure sensors provide relative altitude data, while GPS offers absolute altitude (though less precise on the vertical axis than horizontally). Ultrasonic or lidar sensors provide highly accurate height-above-ground measurements for low-altitude flight.
The flight controller uses an “equation” for vertical hold that is effectively z = constant (or altitude = target_altitude). It continuously compares the current altitude with the target and adjusts motor thrusts to counteract gravity and achieve equilibrium. For precision tasks, PID (Proportional-Integral-Derivative) controllers are finely tuned to ensure minimal vertical drift, crucial for stable aerial photography or surveying.
Defining Ascent, Descent, and Inspection Trajectories
Beyond simple altitude hold, drones frequently need to execute controlled vertical movements. This could involve a pure vertical take-off or landing, a rapid ascent to an operational altitude, or a slow, deliberate descent for an inspection. These flight profiles can be mathematically described:
- Pure Vertical Ascent/Descent: In an NED frame, this is where
x = k1,y = k2, andzvaries monotonically over time. The flight controller ensures that horizontal position is maintained while vertical velocity is controlled. - Vertical Inspection Paths: For tasks like inspecting building facades, wind turbine towers, or bridge piers, drones might follow a series of vertical lines. A common strategy involves flying a horizontal grid at multiple altitudes, or performing purely vertical scans along a predefined x,y coordinate. Here, the drone might trace multiple
x = k1, y = k2lines, each with a differentk1ork2, ascending or descending along them to cover the entire structure. Advanced systems can use parametric equations for more complex 3D paths that include vertical segments or curves.

Establishing Vertical Boundaries for Safety and Regulation
Geofencing is a critical safety feature that creates virtual boundaries to prevent drones from entering restricted airspace or exceeding operational limits. These boundaries often include vertical components.
- Altitude Ceilings and Floors: Regulators impose maximum flight altitudes (
z_max) and sometimes minimum altitudes (z_min). These are defined by simple inequalitiesz < z_maxandz > z_min, creating vertical planes that the drone cannot cross. - Cylindrical No-Fly Zones: Around airports or sensitive installations, cylindrical geofences are common. These involve a horizontal circular boundary (e.g.,
x^2 + y^2 < r^2) combined with vertical limits (z_min < z < z_max). The “walls” of this cylinder are, in effect, vertical lines extending between the floor and ceiling. Drone flight software actively monitors the drone’s 3D position relative to these defined vertical surfaces and triggers warnings or autonomous braking if boundaries are approached. - Obstacle Avoidance: While dynamic, real-time obstacle avoidance uses sensors to detect physical objects, the underlying principles often involve defining “keep-out” zones around detected obstacles that can be approximated by vertical lines or planes. For example, if a lidar sensor detects a tall, narrow pole, the system might virtually “draw” a vertical exclusion cylinder around it, guiding the drone to maintain a safe horizontal distance as it flies past.
Dynamic Stability: How Systems Maintain Vertical Orientation
Beyond defining flight paths, the concept of verticality is paramount for maintaining the drone’s stable orientation and the quality of its sensor data.
Inertial Measurement Units (IMUs) and Attitude Estimation
The heart of a drone’s stabilization system is its IMU, which typically comprises accelerometers, gyroscopes, and sometimes magnetometers.
- Accelerometers: These sensors measure linear acceleration in three axes. Crucially, they continuously sense the Earth’s gravitational acceleration (approximately 9.81 m/s²). By knowing the direction of this constant force, the flight controller can determine the drone’s “down” direction and, consequently, its pitch and roll angles relative to the true horizontal plane.
- Gyroscopes: These measure angular velocity (rate of rotation) around three axes. They are critical for detecting immediate changes in orientation and helping to maintain the desired attitude.
- Magnetometers: Often used as a compass, they help determine the drone’s yaw (heading) relative to magnetic North.
Through sensor fusion algorithms (such as Kalman filters or complementary filters), the data from these sensors are combined to provide a highly accurate estimate of the drone’s attitude – its orientation in 3D space relative to the Earth’s vertical and horizontal planes. This attitude estimation is a continuous “equation” solving process, constantly updating the drone’s relationship to the vertical.
Flight Controllers and Gimbal Stabilization for True Verticality
The flight controller uses the attitude information from the IMU to issue commands to the motors, maintaining the drone’s desired pitch, roll, and yaw. For instance, to hold a level hover, the flight controller ensures the drone’s body frame X-Y plane remains parallel to the horizontal plane, meaning its Z-axis is aligned with the local vertical. Any deviation (e.g., a gust of wind causing a roll) is immediately corrected.
Furthermore, for high-quality aerial imaging and sensing, the camera or payload often needs to remain perfectly stable and oriented along a precise vertical axis, even as the drone itself moves or tilts. This is achieved through a gimbal stabilization system. Gimbals use their own IMUs and motors to actively counteract the drone’s movements, keeping the attached camera pointed consistently down (truly vertical) or at a specified angle relative to the vertical. The gimbal’s internal control system effectively solves for a dynamic “vertical line” for the camera’s optical axis, independent of the drone’s motion.
Pushing the Boundaries: Advanced Applications of Vertical Line Principles
As drone technology evolves, the sophistication of how verticality is managed and utilized continues to grow, opening new possibilities for autonomous operations.
Autonomous Vertical Inspection and Mapping
Automated inspection tasks frequently leverage predefined vertical flight paths. Drones can be programmed to autonomously ascend or descend along the face of a structure, capturing imagery or sensor data at precise intervals. For facade inspections, a drone might execute a grid pattern composed of multiple vertical passes, ensuring comprehensive data collection. This relies on the flight system’s ability to precisely follow x = k1, y = k2 trajectories while controlling vertical speed and sensor triggers.
In 3D mapping and modeling, particularly for urban environments or complex industrial sites, creating accurate digital twins requires dense vertical data. Drones equipped with lidar or photogrammetry systems perform flights designed to capture rich point clouds or image sets that resolve vertical features with high fidelity. The mission planning software defines these vertical scan lines, and the drone’s navigation system ensures adherence to these equations, contributing to the creation of highly detailed vertical profiles of structures.
The Future of Urban Air Mobility (UAM) and Vertical Corridor Management
The burgeoning field of Urban Air Mobility (UAM), involving passenger-carrying eVTOL (electric Vertical Take-Off and Landing) aircraft, places an even greater emphasis on vertical line management. These aircraft are designed to take off and land vertically, operating within dense urban airspaces.
Defining and managing “vertical corridors” for ascent and descent, akin to virtual elevator shafts, will be critical for safety and efficiency. These corridors will be mathematically defined by equations describing their horizontal boundaries and vertical extent, similar to advanced geofencing. Air traffic management systems will need to track multiple eVTOLs simultaneously within these vertical lines, ensuring separation and preventing conflicts. Precise vertical navigation, landing on designated vertiports, and maintaining strict vertical flight paths will be fundamental to the successful integration of UAM into future cities.
In conclusion, while “an equation for a vertical line” may seem like a simple mathematical concept, its practical implications are vast and fundamental within flight technology. From basic altitude hold to complex autonomous inspections and the future of urban air mobility, the ability to define, perceive, and control verticality is a cornerstone of safe, efficient, and innovative aerial operations.