
In the rapidly evolving landscape of drone technology, particularly within autonomous flight, mapping, and remote sensing, the ability to represent complex relationships and structures is paramount. One fundamental mathematical tool that underpins many of these sophisticated applications is the adjacency matrix. Far from being a mere abstract concept, the adjacency matrix provides a precise, computational framework for describing connections, pathways, and dependencies, making it indispensable for advanced drone operations and innovation.
The Core Concept: Representing Relationships
At its heart, an adjacency matrix is a square matrix used to represent a finite graph. In graph theory, a graph is a collection of “nodes” (also called vertices) and “edges” (or links) that connect pairs of these nodes. Think of nodes as individual entities – perhaps locations in a map, individual drones in a swarm, or data points from sensors – and edges as the relationships or connections between them. The adjacency matrix offers a systematic way to encode all these connections into a format that computers can readily process and analyze.
From Graphs to Matrices: A Seamless Translation
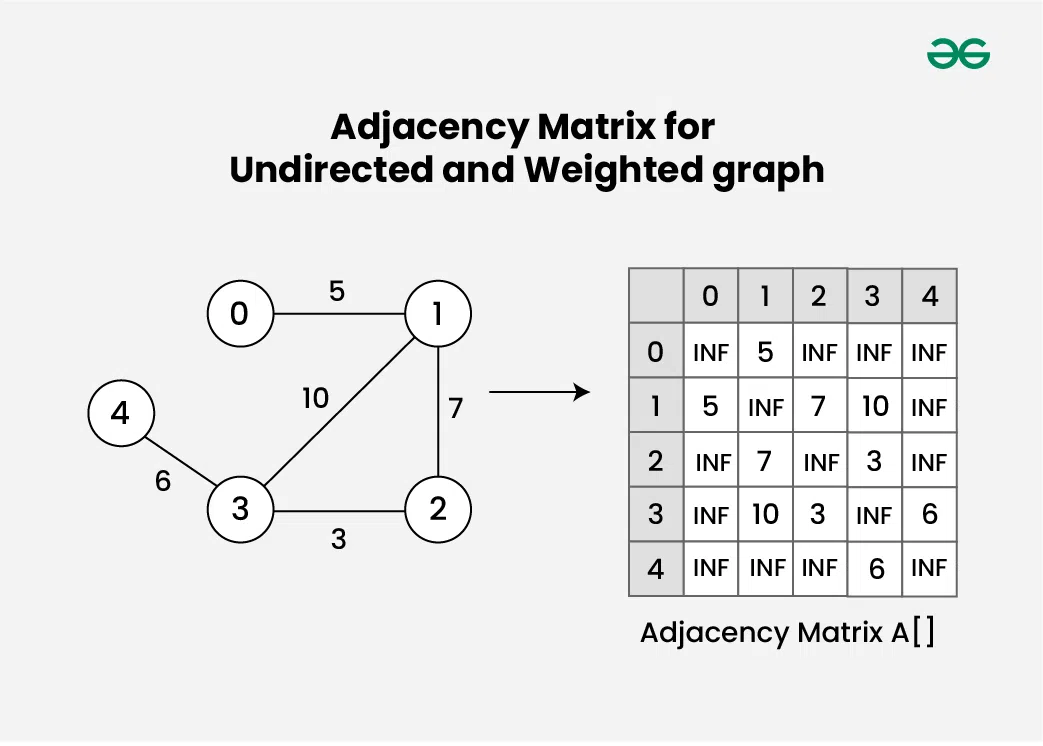
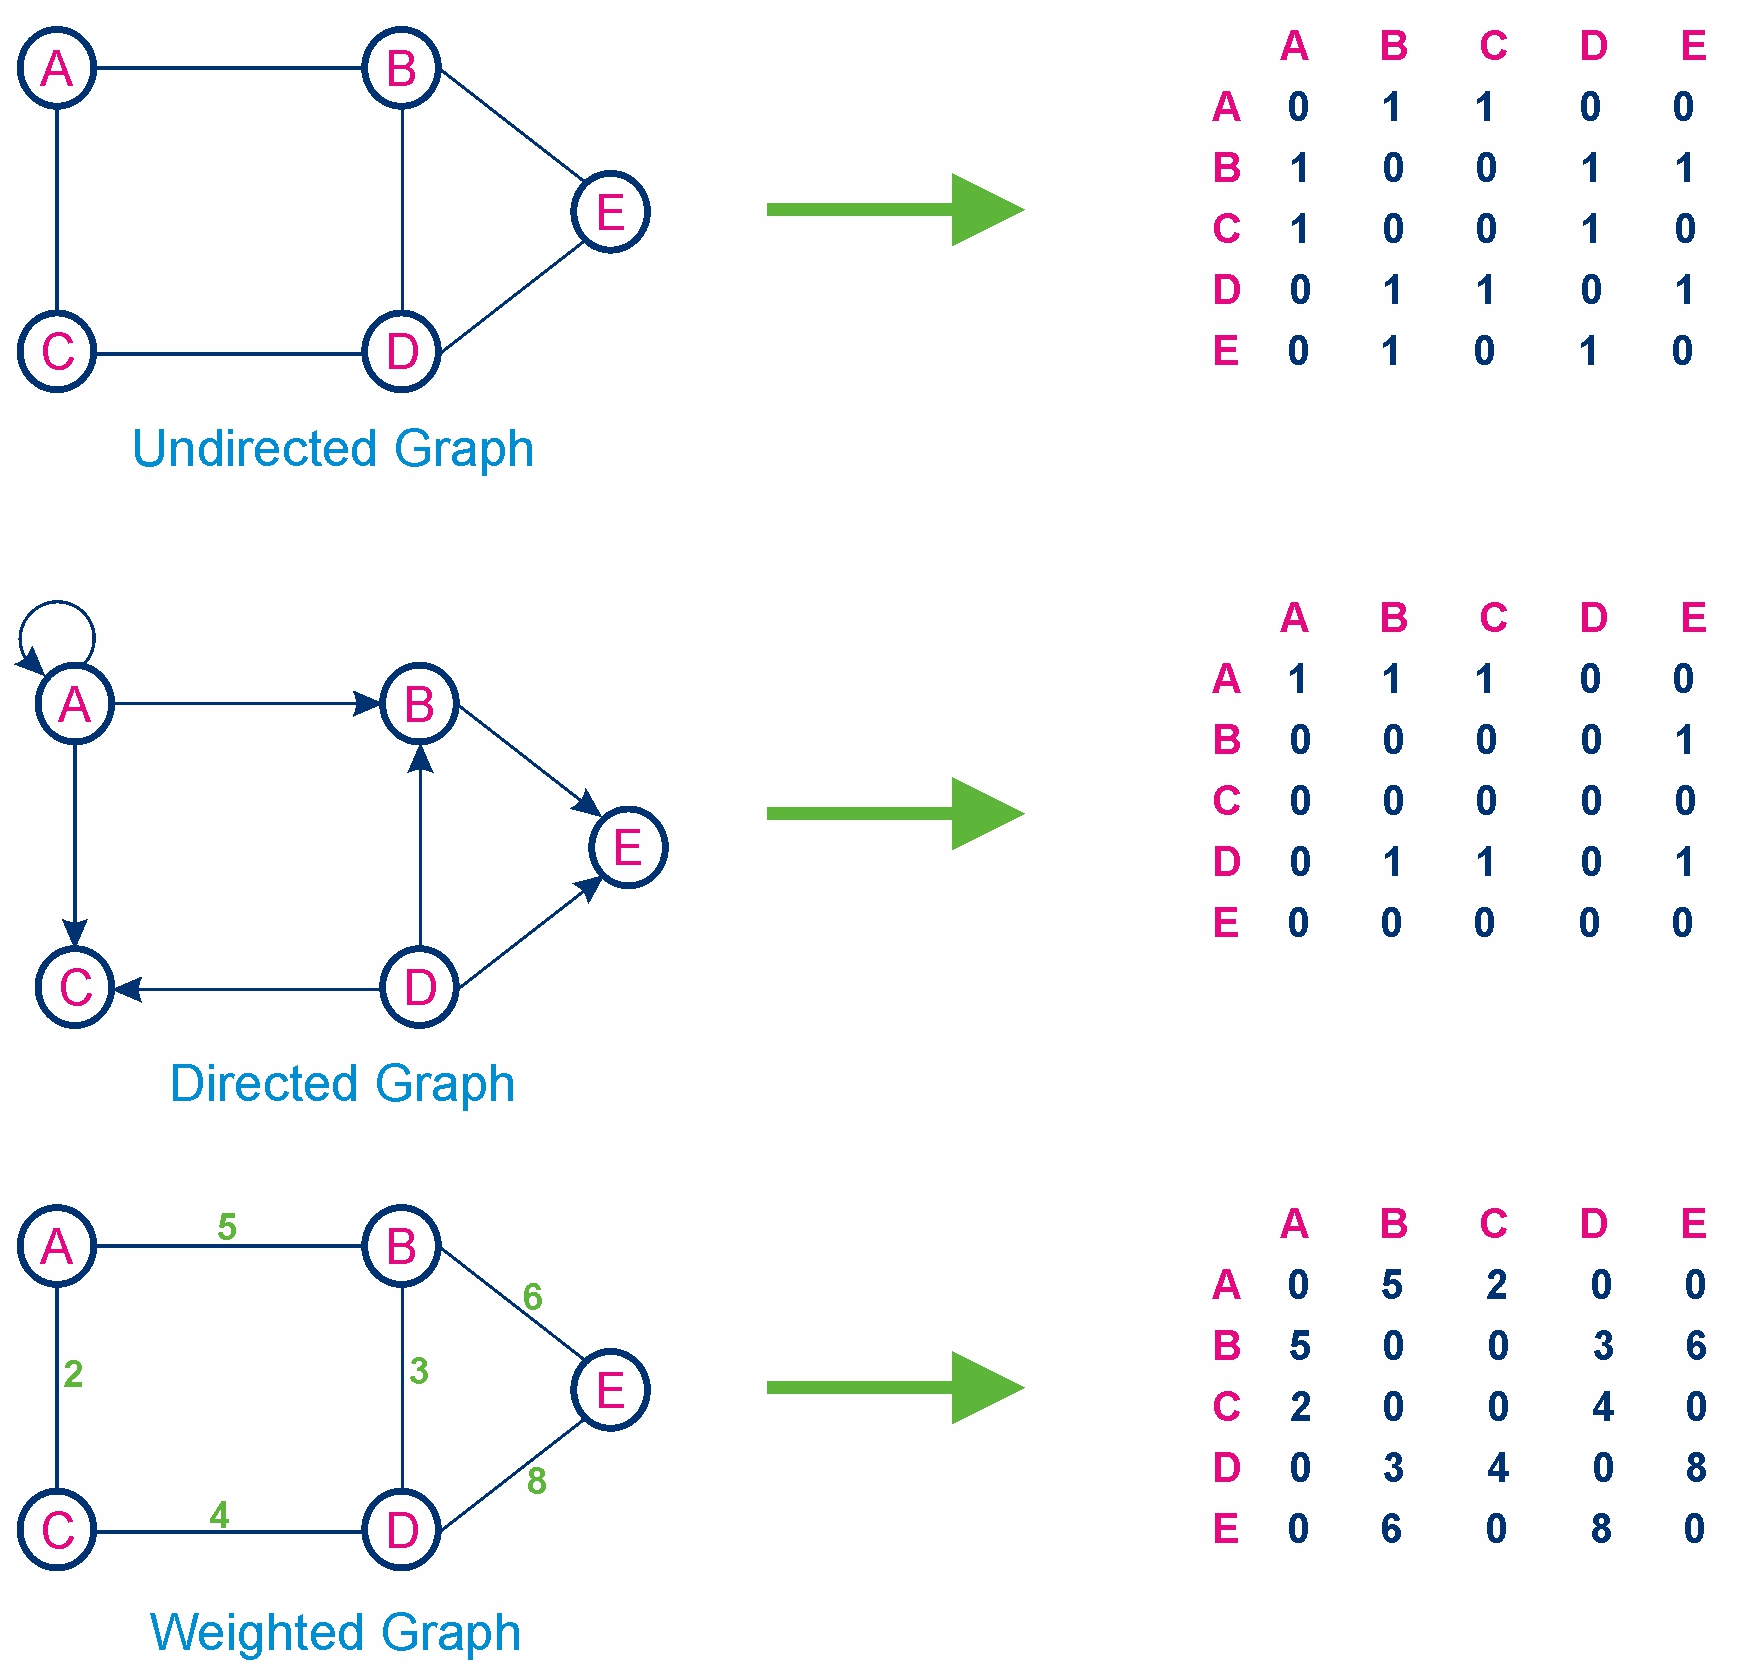
Imagine a simple network of waypoints for a drone to navigate. Each waypoint is a node. If a drone can fly directly from waypoint A to waypoint B, there’s an edge between them. The adjacency matrix translates this visual representation into a numerical table. If a graph has ‘N’ nodes, its adjacency matrix will be an N x N matrix. Each row and column corresponds to a specific node. An entry at position (i, j) in the matrix tells us whether there’s an edge from node ‘i’ to node ‘j’.
For an undirected graph (where if A connects to B, B also connects to A), the matrix will be symmetric. For a directed graph (where A might connect to B, but B does not necessarily connect back to A), the matrix can be asymmetric. This distinction is crucial in drone applications; for instance, a one-way communication link between two drones would be represented by a directed edge.
Understanding the Entries: Connectivity and Weight
The values within the adjacency matrix are highly informative. In its simplest form, a ‘1’ at (i, j) indicates the presence of an edge between node ‘i’ and node ‘j’, while a ‘0’ signifies no direct connection. However, the utility of adjacency matrices extends beyond mere binary connectivity.
In many real-world drone scenarios, edges have properties or ‘weights’. For example, the path between two waypoints might have an associated cost, such as distance, estimated flight time, or energy consumption. The adjacency matrix can accommodate these weights, with the entry (i, j) representing the cost of traversing the edge from node ‘i’ to node ‘j’, instead of just a ‘1’. If there’s no direct connection, an ‘infinity’ value or a ‘0’ (depending on the algorithm) can denote this. This weighted representation is fundamental for optimization problems, allowing autonomous drones to calculate the most efficient routes based on various criteria.
Adjacency Matrices in Autonomous Drone Systems
The power of adjacency matrices truly shines in the domain of autonomous drones, where sophisticated decision-making and environmental understanding are paramount. From navigating complex terrain to avoiding unforeseen obstacles, this mathematical tool provides the backbone for many critical functionalities.
Environmental Mapping and SLAM
Autonomous drones rely heavily on accurate environmental models. Simultaneous Localization and Mapping (SLAM) is a core technology that enables a drone to build a map of an unknown environment while simultaneously tracking its own position within that map. Within SLAM algorithms, particularly those based on graph optimization, the environment is often represented as a graph. Key landmarks, features, or even distinct positions visited by the drone become nodes, and the relationships (e.g., relative poses, sensor measurements linking them) become edges. An adjacency matrix then efficiently stores the connectivity and relative transformations between these nodes, allowing the SLAM system to perform robust estimations and loop closures, correcting drift and building a consistent map.
Path Planning and Navigation
Effective path planning is central to autonomous flight. Whether a drone needs to inspect a bridge, deliver a package, or survey a vast agricultural field, it must determine an optimal route. This process often involves discretizing the operational environment into a network of possible locations or waypoints. Each waypoint is a node, and possible transitions between them (accounting for obstacles, no-fly zones, and terrain) are edges. The adjacency matrix becomes the direct input for graph search algorithms like Dijkstra’s or A*. These algorithms query the matrix to identify direct connections and associated costs (e.g., distance, energy) to compute the shortest, safest, or most energy-efficient path from a starting point to a destination. The matrix’s efficient structure allows for rapid querying and computation, essential for real-time navigation.

Obstacle Avoidance and Dynamic Environments
In dynamic environments, drones must continuously adapt to new information, including moving obstacles or changes in environmental conditions. While direct sensor data processing handles immediate collision avoidance, higher-level planning can leverage adjacency matrices. For instance, if a drone identifies a new, persistent obstacle that blocks a previously viable path, the corresponding entry in the adjacency matrix can be updated from a low cost to ‘infinity’ (or a very high cost), effectively removing that path from consideration for future planning cycles. This real-time modification capability ensures that the drone’s navigation strategies remain adaptive and safe, even when the environment changes unpredictably.
Enabling Multi-Drone Coordination and Swarm Intelligence
Beyond single-drone operations, adjacency matrices are vital for orchestrating the complex interactions required for multi-drone systems and swarm intelligence, opening doors to highly efficient and robust aerial operations.
Communication Topologies
In a multi-drone swarm, understanding the communication links between individual units is critical for coordinated behavior, data sharing, and mission success. An adjacency matrix can meticulously model the communication topology of the swarm. Each drone is a node, and an edge exists between two drones if they can directly communicate. This matrix can represent various communication patterns:
- Centralized: One drone acts as a hub, connected to all others.
- Decentralized: Drones only communicate with their immediate neighbors.
- Dynamic: Communication links might change based on distance, line-of-sight, or mission requirements.
By analyzing the adjacency matrix, swarm algorithms can determine communication pathways, identify single points of failure, and optimize data dissemination, ensuring robust and resilient collective decision-making.
Task Allocation and Resource Management
Complex missions often require multiple drones to cooperate, dividing tasks and sharing resources. Consider a search-and-rescue operation where drones need to cover a large area or a mapping project requiring concurrent data collection. The allocation of tasks to available drones can be formulated as a graph problem where drones are nodes, and tasks (or available resources) are associated with nodes or edges. An adjacency matrix can help represent which drones are capable of performing specific tasks or accessing particular resources, and the costs associated with those assignments. This representation enables sophisticated optimization algorithms to efficiently distribute workloads, minimize redundancy, and maximize operational efficiency across the entire drone fleet.
Advanced Applications and Future Horizons
As drone technology continues to advance, the role of adjacency matrices will only deepen, particularly in the integration of artificial intelligence and more sophisticated sensor networks.
Machine Learning and AI for Drone Decision-Making
Artificial intelligence and machine learning are increasingly driving the next generation of autonomous drone capabilities, from intelligent object recognition to adaptive flight control. Graph Neural Networks (GNNs), a cutting-edge field in AI, leverage graph structures and their adjacency matrices to process non-Euclidean data. In drones, GNNs can be trained on environmental graphs (where nodes are features and edges are their spatial relationships) to improve scene understanding, predict trajectories of dynamic objects, or even learn optimal navigation strategies in complex, unseen environments. The adjacency matrix serves as the fundamental input, defining the graph structure upon which these powerful AI models operate, enabling more nuanced and intelligent decision-making for drones.
Sensor Network Optimization
Drones are increasingly equipped with multiple sensors—visual, thermal, LiDAR, chemical—each contributing valuable data. When multiple drones operate together, they form a distributed sensor network. An adjacency matrix can model the connectivity and data flow paths within this network. This allows for optimization of sensor placement, data fusion strategies, and the identification of redundant or critical sensor nodes. By understanding the network’s structure through its adjacency matrix, drone systems can ensure comprehensive data coverage, enhance data integrity, and allocate processing resources effectively, especially in remote sensing applications where data accuracy and coverage are paramount.
Real-Time Adaptability and Resilience
The ability of a drone system to adapt to failures or unexpected events is crucial for mission success and safety. Whether it’s a drone malfunctioning in a swarm or a communication link dropping, the system must reconfigure itself. Adjacency matrices are critical in modeling the current state of connectivity and resource availability. Upon detecting a failure, the corresponding entries in the matrix can be updated. Subsequently, algorithms can quickly re-evaluate paths, reallocate tasks, or re-establish communication routes based on the modified matrix. This dynamic re-planning capability, facilitated by the clear and computable representation of relationships in an adjacency matrix, contributes significantly to the resilience and robustness of advanced drone systems in challenging operational scenarios.