
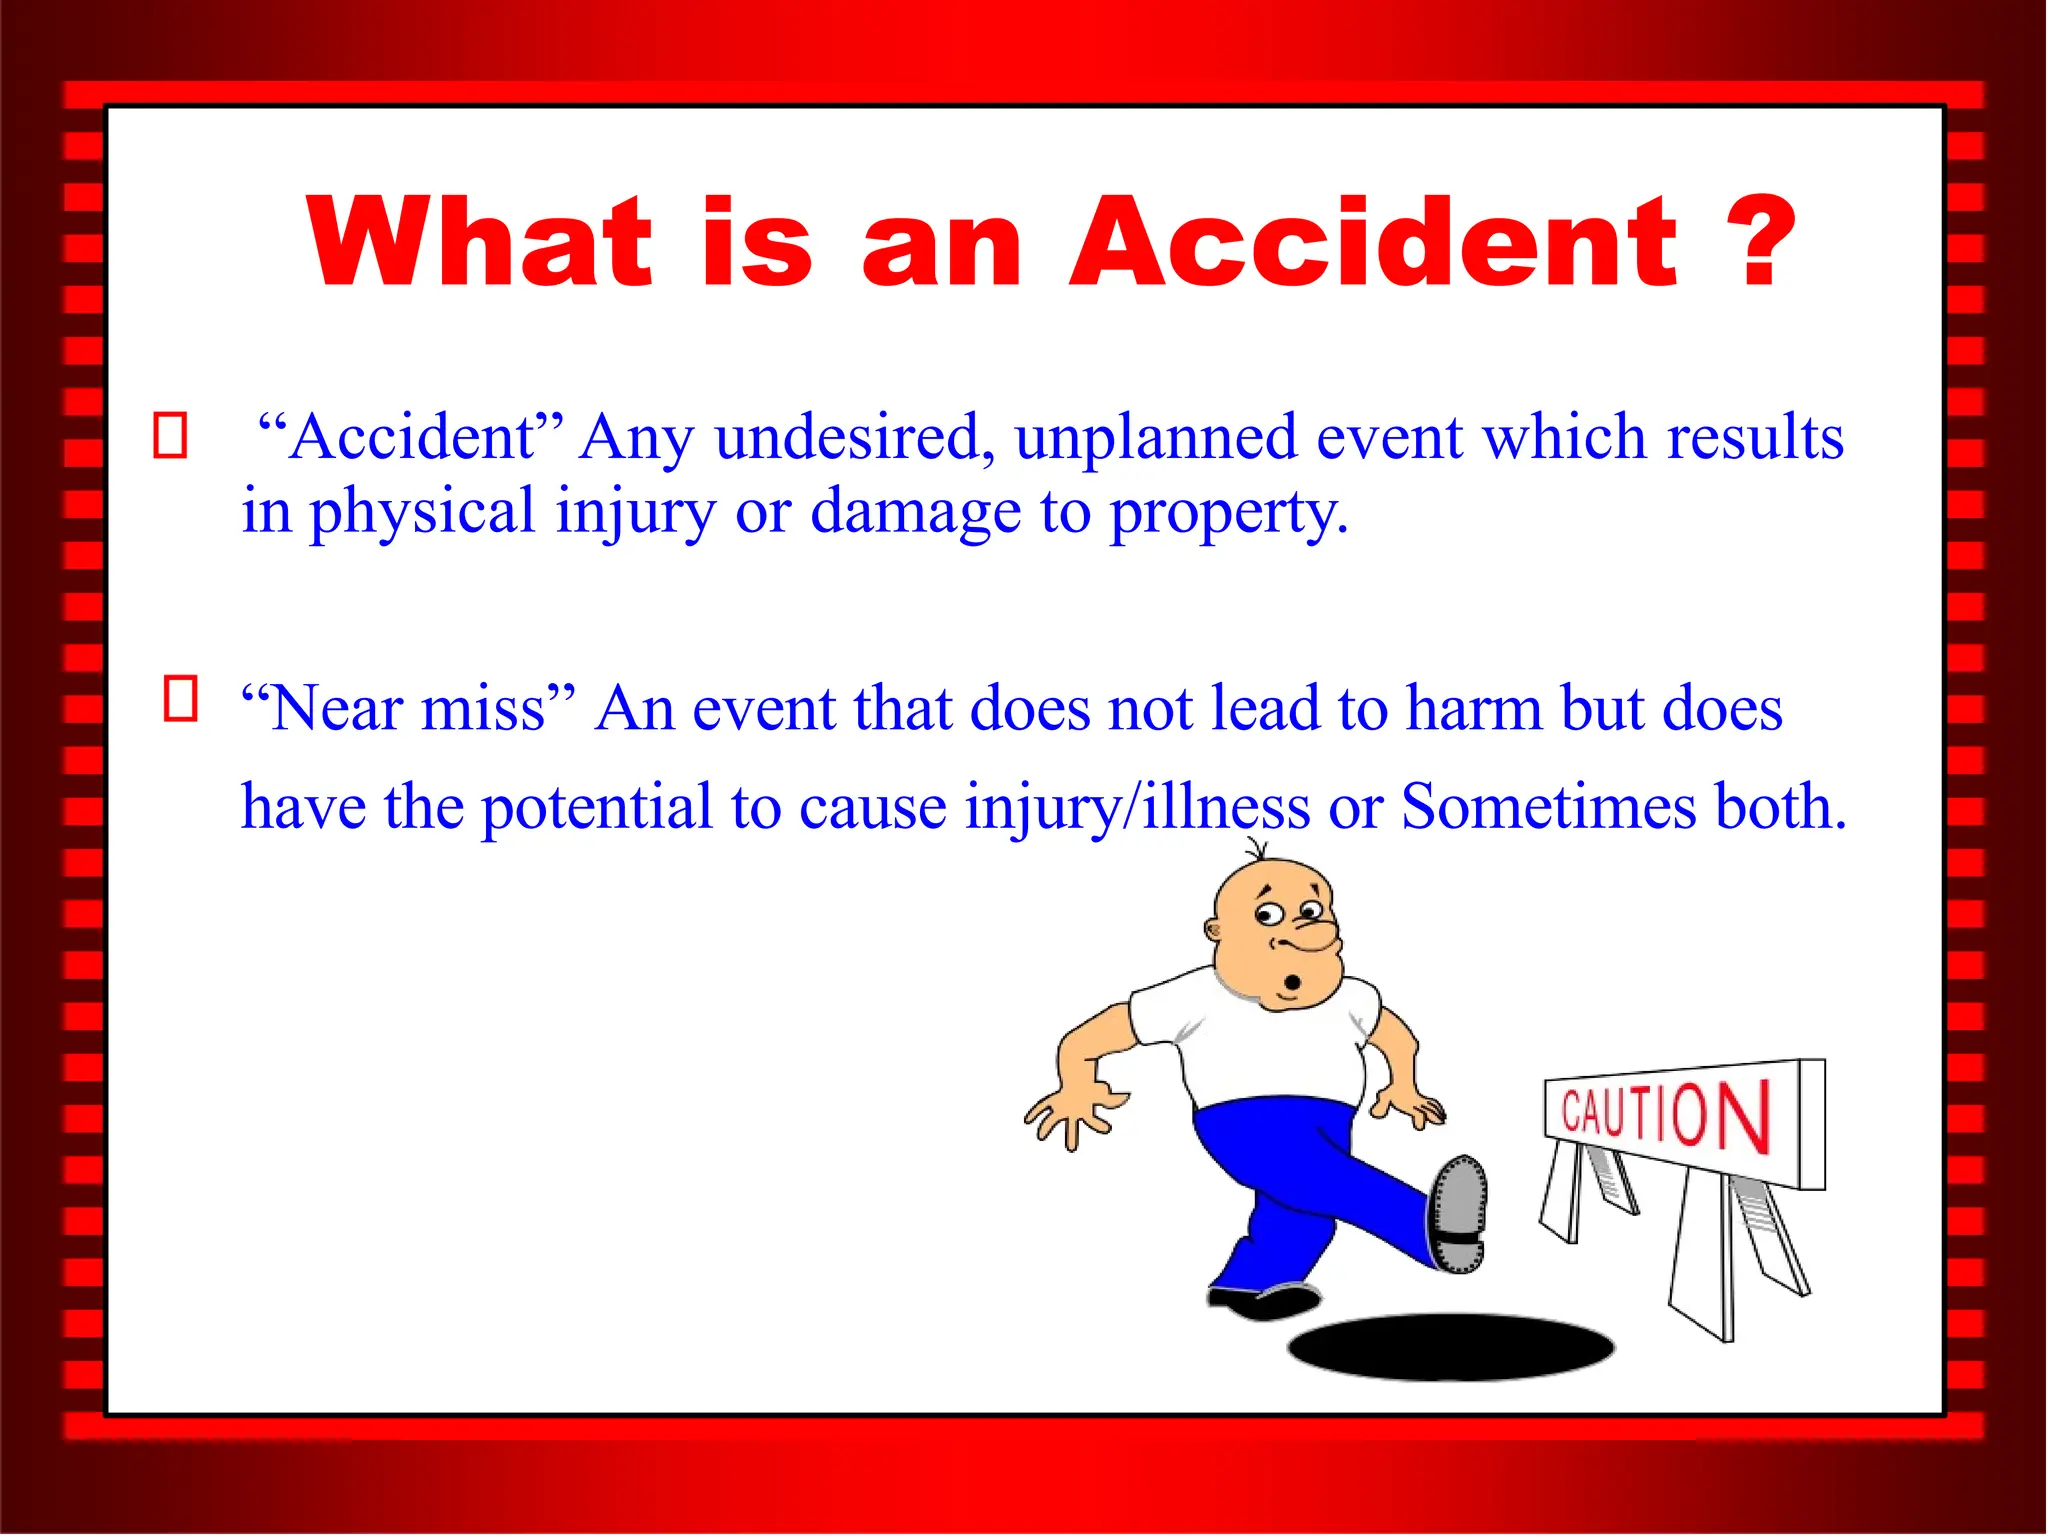
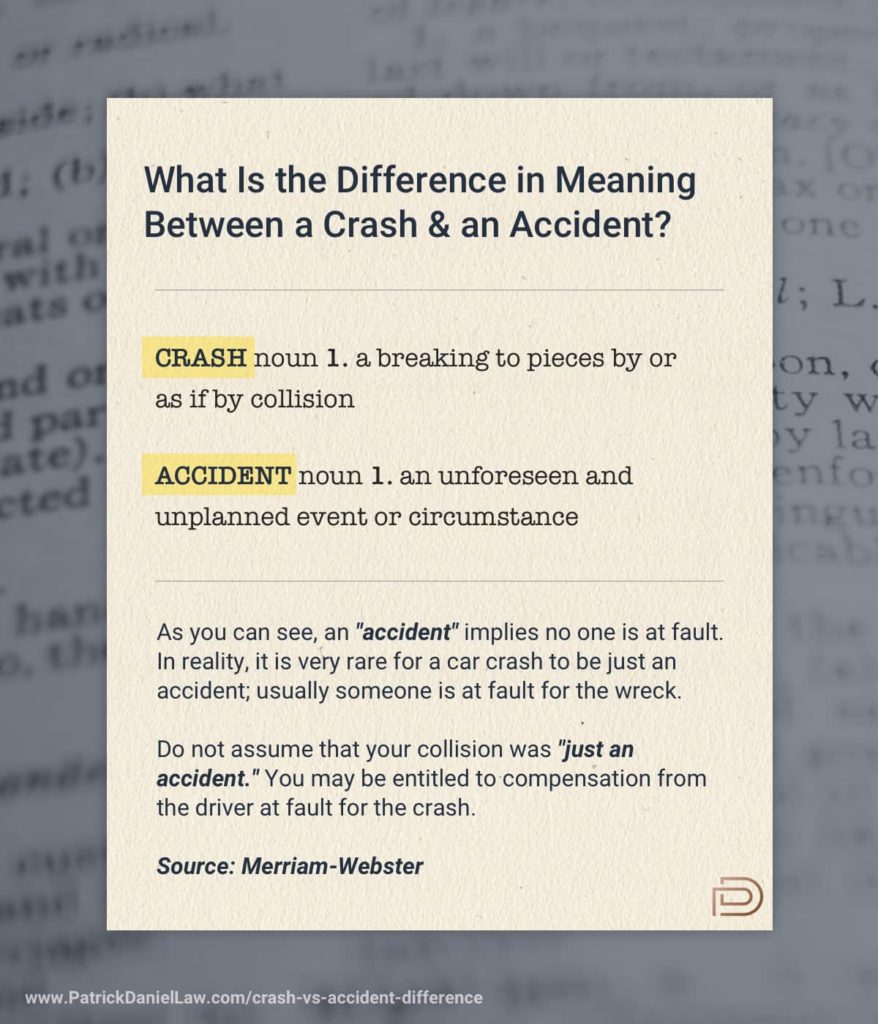
In the dynamic and increasingly autonomous realm of flight technology, defining “what is an accident” transcends the simple observation of a crash or an unexpected landing. An accident within this sophisticated ecosystem is not merely a singular event but often the culmination of a sequence of failures, misinterpretations, or unforeseen interactions stemming from the very technologies designed to ensure safe and stable flight. It demands a nuanced understanding of system integrity, environmental perception, human-machine interface, and the intricate interplay of software and hardware components that govern modern aerial platforms. For flight technology, an accident represents a deviation from intended operational parameters, resulting in undesirable outcomes that can range from minor system glitches to catastrophic equipment loss or, in rarer cases, harm to individuals or property.
Defining Accidents in Autonomous Flight
The definition of an accident in the context of autonomous flight technology necessitates a shift from a purely human-centric perspective. While traditional aviation accidents often involve pilot error, maintenance oversight, or environmental factors, autonomous systems introduce new dimensions. Here, an accident can originate from algorithmic errors, sensor misinterpretations, communication failures, or unexpected emergent behaviors of complex adaptive systems. It’s not just about a drone falling from the sky; it’s about why it fell, tracing the incident back through layers of software logic, sensor data streams, navigation algorithms, and stabilization protocols.
For instance, an autonomous drone programmed for parcel delivery might deviate from its flight path, collide with an unseen object, or perform an erratic maneuver. Each of these scenarios, while visually distinct, traces its root to a failure or limitation within the underlying flight technology. The accident, therefore, is the symptomatic event revealing a deeper issue in the navigation, stabilization, sensing, or control systems. Understanding this distinction is paramount for engineers and operators alike, enabling a proactive approach to risk mitigation and the development of more resilient autonomous flight systems.
The Role of Navigation Systems in Accident Causation and Prevention
Navigation systems are the bedrock of any flight technology, providing the aerial platform with its sense of position, velocity, and orientation. Failures or inaccuracies within these systems are primary contributors to accidents. Conversely, robust and redundant navigation is the first line of defense against unforeseen incidents.
GPS and Positional Accuracy
Global Positioning System (GPS) data is fundamental for outdoor navigation. An accident can occur if GPS signals are lost, jammed, spoofed, or simply inaccurate due to multipath effects or satellite geometry. If a drone relies solely on GPS for its absolute positioning, an unexpected degradation of signal quality can lead to significant positional drift, causing the aircraft to veer off its intended course, enter restricted airspace, or collide with obstacles it was programmed to avoid. For example, a temporary GPS drop-out during a complex urban delivery route could cause a drone to lose its bearings, potentially resulting in a collision with a building or an uncontrolled landing. Advanced flight technologies combat this by integrating multiple GNSS constellations (GPS, GLONASS, Galileo, BeiDou) and employing Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) techniques to achieve centimeter-level accuracy, significantly reducing positional errors that could lead to accidents.
Inertial Measurement Units (IMUs) and Stabilization
While GPS provides absolute position, Inertial Measurement Units (IMUs) – comprising accelerometers, gyroscopes, and magnetometers – provide relative motion data critical for stabilization and orientation. An accident stemming from IMU failure could involve loss of control due to incorrect attitude estimation. If a gyroscope drifts or an accelerometer provides erroneous readings, the flight controller receives inaccurate information about the drone’s pitch, roll, and yaw. This can lead to incorrect motor commands, resulting in instability, uncontrolled rotations, or a complete loss of attitude control, inevitably culminating in a crash. Modern flight controllers mitigate this risk through redundant IMUs, sensor fusion algorithms that cross-reference data from multiple sensors, and advanced filtering techniques (like Kalman filters) to estimate true state and reject noisy data, thereby enhancing the platform’s resilience against single-point IMU failures.
Sensor Integration and Environmental Awareness
Beyond basic navigation, a drone’s ability to perceive and interpret its environment is crucial for accident prevention, especially in complex or dynamic settings. Accidents often arise from misinterpretations of sensory data or failures in the very systems designed to provide environmental awareness.
Obstacle Avoidance Technologies
Obstacle avoidance systems, utilizing technologies such as ultrasonic sensors, stereo cameras, lidar, and radar, are designed to prevent collisions. However, these systems are not infallible. An accident can occur if the sensors fail to detect an obstacle due to its size, material, speed, or environmental conditions (e.g., transparent surfaces for optical sensors, soft materials for lidar, or rain/fog for all types). For instance, a drone flying autonomously might collide with thin power lines or glass windows if its obstacle avoidance system is not adequately tuned or if the environmental conditions exceed the sensor’s capabilities. The “accident” here is not just the physical impact but the systemic failure of the avoidance algorithm to correctly process and react to the perceived threat, or the sensor’s inability to register the threat at all. Continuous research into multi-modal sensor fusion and more sophisticated AI-driven perception models aims to reduce these blind spots and enhance robust obstacle avoidance in diverse environments.
Visual and Thermal Sensing Failures
Cameras and thermal sensors provide critical visual and spectral data for autonomous operations, ranging from visual odometry for GPS-denied environments to object recognition and environmental mapping. An accident can result from the misinterpretation of this visual data or a failure of the sensing hardware. For example, in poor lighting conditions, a vision-based navigation system might misidentify ground features, leading to incorrect localization and subsequent collision. Similarly, a thermal sensor failure could lead to a drone designed for inspection flying too close to an overheated component, damaging itself or exacerbating an existing problem. The ‘accident’ here isn’t just the physical damage, but the operational failure caused by inadequate or erroneous sensory input, highlighting the importance of robust image processing algorithms and reliable sensor hardware in flight technology.
Software Glitches, System Malfunctions, and Human-Machine Interaction
Beneath the physical components of flight technology lies the intricate layer of software and the critical interface with human operators. Many accidents can be traced back to issues within these domains, which are often less tangible but equally impactful.
Autonomy and Unexpected Behavior
The increasing sophistication of autonomous flight systems introduces the potential for accidents arising from software glitches, logical errors in algorithms, or unintended emergent behaviors. A bug in a flight control algorithm, an error in a mission plan, or an incorrect parameter setting can lead to erratic flight patterns, uncontrolled maneuvers, or a failure to respond to environmental changes. For example, an AI follow-mode might misinterpret a moving target’s intention, leading to a collision, or a mapping drone’s autonomous flight path generation could route it through an unsafe area due to incorrect topographical data. The accident in such cases is a direct consequence of the system’s own “decision-making” process, which, while autonomous, is ultimately a reflection of its programmed logic and data inputs. Ensuring robust software verification, extensive testing, and fail-safe mechanisms is paramount to mitigating these risks.
The Human Factor in System Overrides
While autonomous systems reduce human error in routine flight operations, the human element remains critical, particularly in emergency situations or when intervention is required. An accident can occur due to a failure in the human-machine interface (HMI), where an operator misinterprets telemetry, provides incorrect commands, or fails to take control effectively during a system anomaly. For instance, a drone might exhibit unexpected behavior, prompting the operator to switch to manual control. If the HMI is poorly designed, or if the operator lacks sufficient training or real-time information, their attempt to regain control might exacerbate the situation, leading to an accident. The “accident” here involves a breakdown in the symbiotic relationship between the autonomous system and its human supervisor, underscoring the need for intuitive controls, clear feedback mechanisms, and comprehensive training protocols in advanced flight technology.
Towards Accident-Resilient Flight Technology
Understanding “what is an accident” within flight technology is not merely an exercise in retrospective analysis but a crucial step towards engineering more resilient and safer aerial platforms. The continuous evolution of navigation systems, sensor integration, and autonomous software aims to minimize the probability of these multi-faceted accidents. Redundancy in critical systems, advanced fault detection and recovery mechanisms, robust cyber-physical security, and predictive maintenance are all vital components of this endeavor.
Furthermore, the development of standardized accident investigation protocols for autonomous systems, akin to those in traditional aviation, is essential. These protocols must delve into log data, sensor outputs, algorithm states, and communication records to pinpoint the root causes, whether they lie in hardware malfunction, software anomaly, environmental misinterpretation, or human interaction. By meticulously dissecting each incident, the flight technology community can learn, adapt, and innovate, paving the way for a future where accidents, while never entirely eliminated, are systematically minimized through superior design, rigorous testing, and continuous improvement. The goal is not just to recover from accidents, but to design systems that are inherently less prone to their occurrence, fostering greater trust and wider adoption of these transformative technologies.