
Within the rapidly evolving landscape of drone technology, understanding the cognitive processes that underpin advanced drone capabilities is becoming increasingly vital. While we often focus on the hardware – the rotors, the sensors, the cameras – the “brain” that orchestrates these components is equally, if not more, important. This is where the concept of working memory, particularly as it applies to autonomous and semi-autonomous flight systems, comes into play. Far from being solely a human psychological construct, the principles of working memory are being actively simulated and integrated into the sophisticated algorithms that drive modern drones.
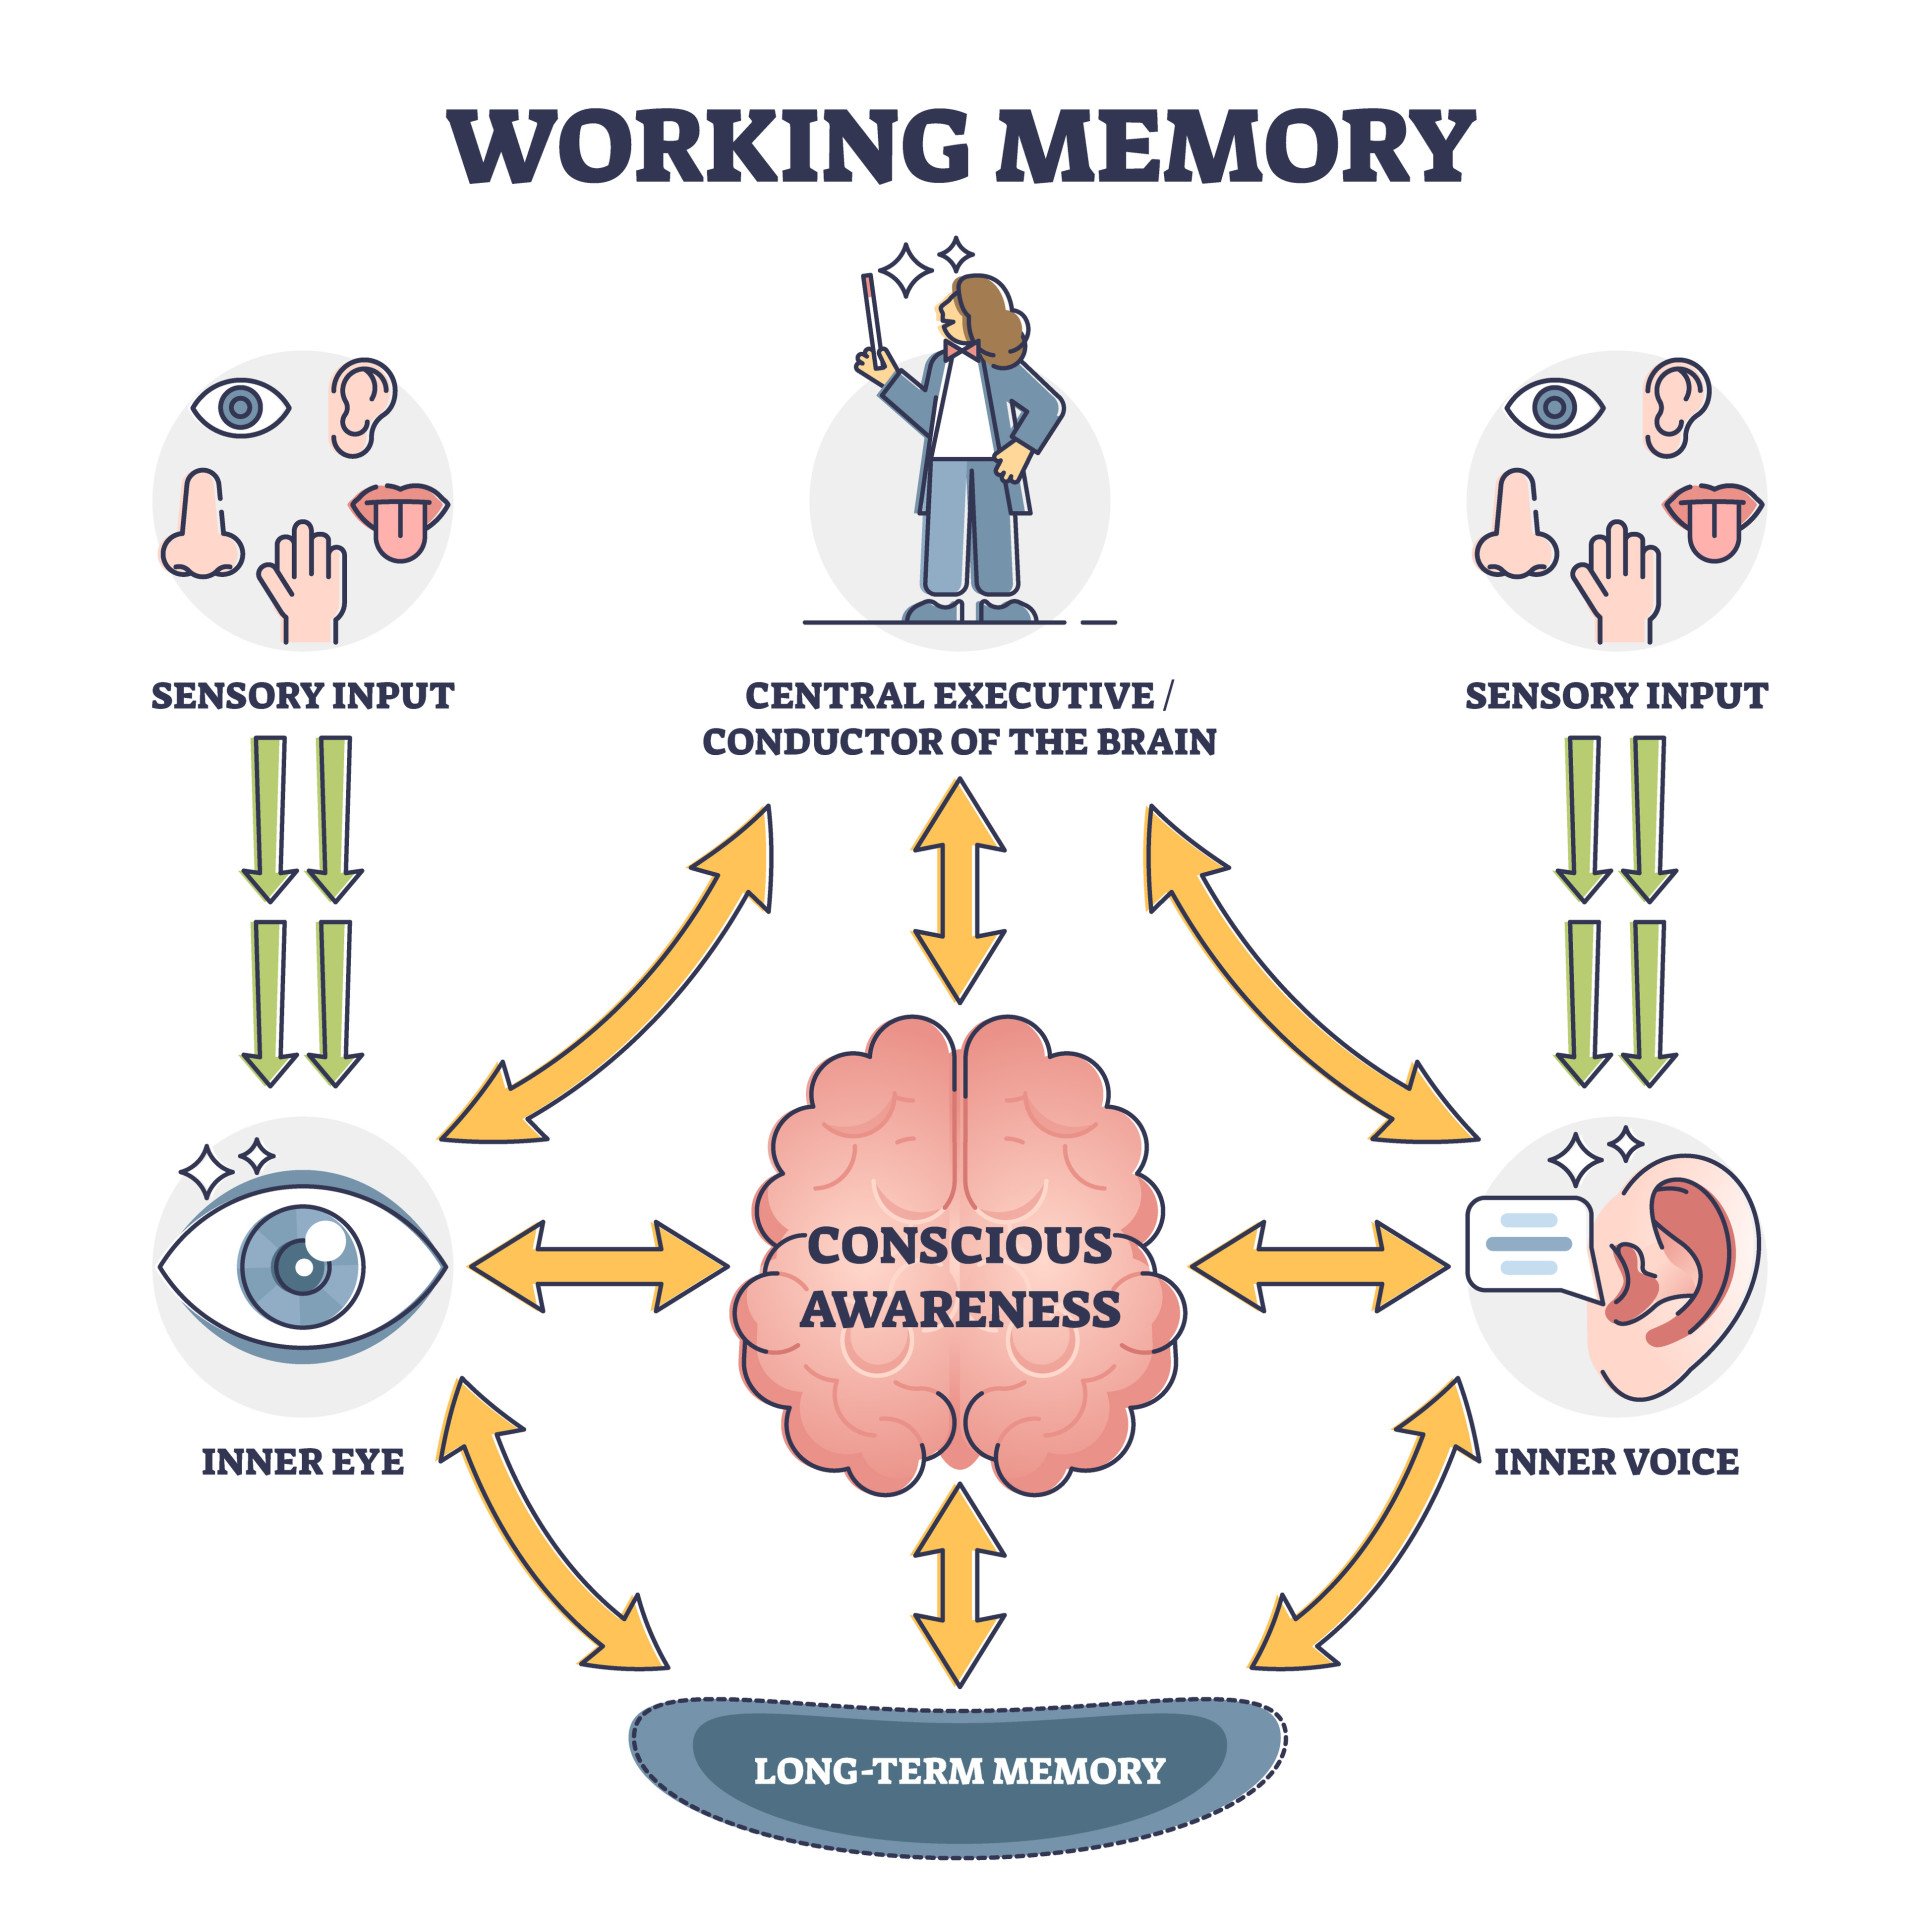
The Core Functionality of Drone Working Memory
At its heart, a drone’s “working memory” is a computational system designed to temporarily store and manipulate information necessary for immediate task performance. In the context of drones, this involves holding and processing data from various onboard sensors, navigational waypoints, flight control commands, and even environmental models. Unlike long-term storage, which is designed for vast amounts of data over extended periods, working memory is characterized by its limited capacity and its focus on active, dynamic processing.
Short-Term Data Buffering
When a drone’s flight controller receives a stream of data from its GPS receiver, Inertial Measurement Unit (IMU), or obstacle avoidance sensors, this information needs to be held in a readily accessible format. Working memory acts as a high-speed buffer, retaining this crucial data for fractions of a second to allow for immediate decision-making. For instance, if an obstacle avoidance system detects an imminent collision, the raw sensor data is temporarily stored in working memory to be rapidly analyzed and acted upon by the navigation algorithms.
Active Information Manipulation
Beyond simple storage, drone working memory is actively involved in manipulating information. This can include:
- Trajectory Prediction: Algorithms might use data currently in working memory (e.g., current velocity, acceleration, and recent path) to predict the drone’s future trajectory. This is critical for smooth flight control and for planning evasive maneuvers.
- Sensor Fusion: Data from multiple sensors (e.g., camera, LiDAR, ultrasonic) is often fused to create a more robust understanding of the environment. Working memory plays a role in holding and integrating these disparate data streams before they are processed into a unified perception model.
- Task-Specific Data Management: For complex missions, such as aerial surveying or inspection, working memory holds details about the current target area, the required flight pattern, and the status of the operation. This allows the drone to efficiently switch between different aspects of the task without needing to re-fetch all the information from slower storage.
Limited Capacity and Cognitive Load Analogies
Just as human working memory has a finite capacity, so too does the computational working memory of a drone. This limitation influences the complexity of tasks a drone can perform simultaneously and the sophistication of its algorithms. When processing demands exceed capacity, performance can degrade, leading to slower response times, increased errors, or the need to prioritize certain data over others. This analogy highlights the importance of efficient algorithm design and sufficient processing power for advanced drone operations. The concept of “cognitive load” in human psychology translates to “computational load” in drone systems, where overwhelming the working memory can lead to performance bottlenecks.
Working Memory in Autonomous Navigation and Obstacle Avoidance
The most prominent applications of working memory principles in drone technology are found in autonomous navigation and obstacle avoidance systems. These systems rely heavily on real-time data processing and rapid decision-making, capabilities intrinsically linked to the functions of working memory.
Real-Time Environmental Mapping
When a drone operates autonomously, it needs to build and maintain a dynamic map of its surroundings. Working memory is instrumental in this process by:
- Storing Perceptual Data: Information gathered from cameras, LiDAR, or radar about the immediate environment – the positions of trees, buildings, other drones, or terrain features – is temporarily stored. This allows the navigation system to have a snapshot of the local area.
- Updating Environmental Models: As the drone moves, its perception of the environment changes. Working memory allows for the rapid updating of the environmental model by incorporating new sensor data and discarding outdated information. This continuous refinement is essential for accurate navigation.
- Path Planning and Re-planning: Based on the current environmental model held in working memory, the path planning algorithms can chart a course. If an unexpected obstacle appears or the drone deviates from its intended path, working memory provides the necessary context to re-plan the route efficiently.
Predictive Obstacle Avoidance
Effective obstacle avoidance requires not just detecting an object, but also predicting its movement and the drone’s future position relative to it. This is a prime example of where working memory’s ability to hold and process dynamic information is critical:
- Tracking Object Trajectories: Sensor data is continuously processed to estimate the velocity and direction of potential obstacles. This information, held in working memory, allows the system to predict where the obstacle will be in the near future.
- Simulating Collision Scenarios: Working memory can store hypothesized future states of the drone and its environment. By running brief simulations, the system can determine if a collision is likely and then initiate evasive maneuvers.
- Balancing Safety and Mission Objectives: The working memory system must balance the imperative of obstacle avoidance with the drone’s primary mission. This involves rapidly assessing the threat level of an obstacle and determining if a minor course correction or a more significant diversion is required, all while striving to maintain progress towards the mission goal.

Working Memory in Advanced Flight Control and Task Management
Beyond immediate survival, working memory plays a crucial role in enabling sophisticated flight control behaviors and managing complex multi-task operations.
Stabilization and Dynamic Response
Even in seemingly simple flight, the drone’s flight controller constantly makes micro-adjustments to maintain stability. Working memory holds the real-time attitude (pitch, roll, yaw) and acceleration data, allowing the control algorithms to:
- Compensate for Disturbances: Wind gusts or sudden movements can disrupt the drone’s flight. Working memory allows the flight controller to quickly process the resulting deviations and issue corrective commands to the motors.
- Execute Smooth Maneuvers: When the pilot or autonomous system commands a turn or change in altitude, working memory holds the target state and the current state, enabling the controller to smoothly transition between them. This involves calculating the necessary motor outputs based on the discrepancy between the desired and actual flight parameters.
Mission Sequence Execution and Context Switching
For drones performing complex tasks, such as precision agriculture, infrastructure inspection, or search and rescue, working memory is vital for managing multi-step mission sequences:
- Maintaining Mission State: At any given point, the drone needs to know where it is in its mission plan, what the next objective is, and what data needs to be collected. Working memory holds this “mission state” information.
- Context Switching: If the mission requires the drone to perform a specific inspection pattern, then collect a sample, and then return to a base station, working memory facilitates the efficient switching between these distinct operational contexts. It ensures that the relevant parameters and goals for each sub-task are readily available.
- Adaptive Task Execution: In dynamic environments, the drone may need to adapt its mission plan on the fly. For example, if a sensor fails during an inspection, the working memory system might trigger a protocol to compensate or re-route the task. This requires holding the original plan, recognizing the deviation, and activating alternative strategies.
The Future of Drone Working Memory: AI and Enhanced Autonomy
As artificial intelligence continues to permeate drone technology, the capabilities of their computational working memory are expanding dramatically. This evolution is paving the way for even more sophisticated autonomous behaviors.
Learning and Adaptation
Future drones will likely incorporate more advanced machine learning algorithms that leverage working memory to learn from experience:
- Reinforcement Learning: Working memory can store sequences of actions and their outcomes, allowing reinforcement learning algorithms to identify optimal strategies for navigation, task completion, or even energy management over time.
- Predictive Modeling Enhancements: With access to more historical data processed through working memory, AI models can develop more accurate predictions of environmental changes, potential hazards, and even the behavior of other entities in the airspace.
Enhanced Situational Awareness
The concept of “situational awareness” in human cognition – knowing where you are, what’s happening around you, and what might happen next – is a key aspiration for drone autonomy. Working memory is central to achieving this:
- Integrating High-Level Concepts: Beyond raw sensor data, future working memory systems might store and manipulate higher-level cognitive representations, such as understanding the purpose of a building being inspected or recognizing the typical movement patterns of wildlife.
- Anticipatory Planning: By holding and processing complex environmental models and potential future scenarios, drones will be able to move beyond reactive obstacle avoidance to more proactive and anticipatory planning, making flight smoother, safer, and more efficient.

Collaborative Swarm Intelligence
In the context of drone swarms, working memory takes on an even more distributed and complex role:
- Shared Information Processing: Each drone in a swarm will need to maintain its own working memory while also contributing to and drawing from a shared pool of information. This allows for coordinated decision-making and complex collective behaviors.
- Dynamic Task Allocation: Working memory will enable swarms to dynamically allocate tasks among their members based on individual capabilities, current state, and overall mission objectives, ensuring efficient and adaptive group operations.
In conclusion, while the term “working memory” originates in human psychology, its principles are fundamental to the design and operation of modern autonomous drones. From real-time sensor data processing for stabilization and obstacle avoidance to managing complex mission sequences and paving the way for advanced AI capabilities, the computational analogue of working memory is the unsung hero enabling the sophisticated flight behaviors we see today and will witness in the future.