
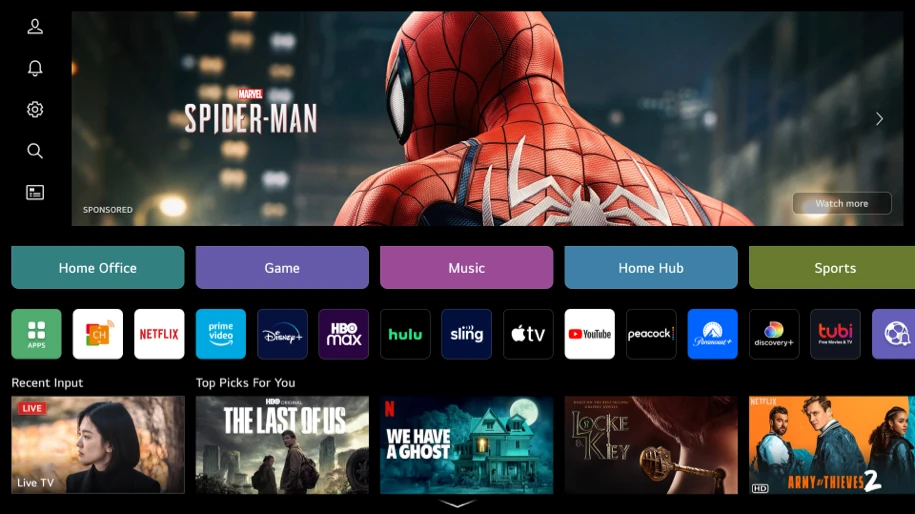
In the rapidly evolving landscape of unmanned aerial vehicles (UAVs) and sophisticated flight systems, the underlying operating system (OS) plays a pivotal, often unsung, role. While a general-purpose operating system like webOS might not be immediately associated with the highly specialized world of drones, understanding its core principles—and how those principles could be applied or adapted—offers profound insights into the future of drone tech and innovation. At its essence, webOS is a Linux-based mobile operating system distinguished by its elegant, card-based graphical user interface (GUI) and strong focus on connectivity and multitasking. Developed initially for smartphones and later adapted by LG for smart TVs and other devices, webOS represents a paradigm of intuitive interaction and seamless integration that holds significant implications for how we might interact with, control, and leverage advanced drone platforms.
Understanding WebOS in the Context of Advanced Drone Technology
To appreciate the potential impact of webOS-like architectural thinking on drone innovation, it’s crucial to first grasp its fundamental design philosophy. Unlike highly specialized real-time operating systems (RTOS) often found in flight controllers, webOS provides a more comprehensive, user-centric environment. Its principles, however, offer a blueprint for enhancing the user experience, managing complex operations, and ensuring robust connectivity for sophisticated drone applications.
The Core Tenets of WebOS UI/UX for Drone Applications
One of webOS’s most celebrated features is its intuitive, highly visual user interface. The “card” metaphor, where each running application or task is represented as a distinct, manipulable card, allows for quick context switching and easy access to multiple functions simultaneously. For drone technology, this design philosophy could be revolutionary for ground control stations (GCS) and even onboard diagnostic interfaces. Imagine a GCS where flight telemetry, live camera feed, mission planning waypoints, and payload controls are each displayed as interactive cards. A pilot could quickly swipe between these views, arrange them for optimal workflow, or pull up contextual information without diving through complex menus. This approach significantly reduces cognitive load, allowing drone operators to manage intricate tasks—such as precision mapping, multi-spectral inspection, or dynamic aerial filmmaking—with greater fluidity and reduced risk of error. The “Universal Search” feature, another webOS hallmark, could enable operators to instantly locate specific flight logs, sensor data points, or even available third-party drone applications, streamlining critical workflows and enhancing operational efficiency.
Multitasking and Resource Management for Complex Drone Operations
WebOS was designed from the ground up to handle multiple concurrent applications seamlessly, providing robust memory and process management. In a drone context, this translates to the ability of a GCS or a sophisticated onboard companion computer to manage a multitude of simultaneous tasks without performance degradation. For instance, a single drone mission might involve real-time video streaming, LiDAR data collection, autonomous obstacle avoidance algorithms, and communication with a cloud-based mapping service. An OS with webOS’s multitasking capabilities could efficiently allocate computational resources, ensuring that critical flight control processes maintain priority while background tasks like data upload or deep learning analysis proceed uninterrupted. This level of sophisticated resource management is vital for the next generation of autonomous and semi-autonomous drones, which require dynamic processing power to interpret complex sensor data, make real-time decisions, and execute intricate flight plans.
Connectivity and IoT Integration for Future Drone Ecosystems
The “web” in webOS emphasizes its strong focus on internet connectivity and integration with networked services and devices. This is a critical parallel for the future of drones, which are increasingly becoming integral components of the Internet of Things (IoT). Drones equipped with an OS designed for seamless connectivity could effortlessly communicate with smart city infrastructure, other autonomous vehicles, remote command centers, or specialized ground sensors. This enables sophisticated applications like synchronized drone swarms for agricultural monitoring, real-time data relay to emergency services during disaster response, or automated package delivery systems that interface directly with smart home devices. An OS architecture that prioritizes robust, secure, and flexible connectivity protocols, akin to webOS’s approach, is fundamental for realizing the full potential of drones as interconnected nodes in a vast, intelligent network.
Innovating Drone Control and Interaction with OS Principles
The principles embodied by webOS offer a compelling vision for innovating how humans interact with drones, moving beyond mere joystick control to a more integrated, intelligent, and intuitive experience.
Rethinking Ground Control Stations with WebOS-Inspired Interfaces
Current ground control stations, while functional, can often be clunky, requiring significant training and manual input. A webOS-inspired GCS could transform this experience. Imagine a tablet-based controller running a customized OS offering a card-based interface for mission planning, flight execution, and data analysis. Flight plans could be designed by dragging and dropping waypoints on a map card, while a separate telemetry card provides real-time altitude, speed, and battery status. A camera control card could offer intuitive sliders for gimbal pitch, zoom, and exposure, seamlessly integrated with the live video feed. Furthermore, features like webOS’s “notification bar” could provide critical alerts (e.g., low battery, no-fly zone proximity, wind shear warnings) without interrupting the primary operational view. This shift towards a highly visual, touch-friendly, and context-aware interface would significantly lower the barrier to entry for complex drone operations and enhance the precision and safety of professional missions.
Enhancing Onboard Intelligence and Autonomy via OS Design
While webOS is a high-level OS, its underlying architectural principles—especially regarding process isolation and service management—are relevant for onboard drone intelligence. For drones to achieve true autonomy, they need robust, secure, and modular software environments capable of hosting diverse AI algorithms (e.g., AI follow mode, object recognition, path planning), sensor fusion engines, and decision-making logic. An OS that facilitates the secure deployment and management of these discrete intelligent services, much like webOS manages applications, ensures that one software component’s failure doesn’t compromise the entire system. This modularity allows for easier updates, independent development of new AI features, and greater resilience in highly dynamic operational environments. Such an OS would act as the central nervous system, coordinating inputs from various sensors, processing data through onboard AI, and executing commands via the flight controller, enabling advanced capabilities like predictive obstacle avoidance and adaptive mission re-planning.
WebOS Principles as a Catalyst for Drone Software Ecosystems
Beyond immediate control and interaction, an OS with webOS’s characteristics could foster a vibrant software ecosystem around drones, enabling greater customization, specialization, and data leverage.
Enabling Modular Applications and Services for Specialized Drone Tasks
The app store model championed by modern operating systems, including webOS, is a powerful driver of innovation. Applied to drones, this could mean a standardized drone OS that allows third-party developers to create specialized applications. Imagine an “app store for drones” where users can download applications for specific tasks: a precision agriculture app to analyze crop health, a thermal inspection app for industrial infrastructure, or a photogrammetry app for 3D mapping. Each app could run within its own sandboxed environment, leveraging the drone’s hardware capabilities (cameras, sensors, computing power) through well-defined APIs. This modularity would accelerate the development of niche drone solutions, allowing companies and researchers to focus on specific problems without having to build entire drone software stacks from scratch. This would democratize access to advanced drone functionalities and foster a competitive, innovation-driven market.
The OS Role in Advanced Data Handling and Remote Sensing
Modern drones are powerful data collection platforms, gathering vast amounts of information through 4K cameras, LiDAR, thermal sensors, and other remote sensing payloads. An OS with strong data management capabilities is crucial for efficiently processing, storing, and transmitting this data. WebOS’s inherent ability to manage multiple data streams and its focus on cloud integration provides a strong conceptual framework. For drones, this could translate to onboard capabilities for pre-processing sensor data to reduce bandwidth requirements, encrypting sensitive information before transmission, and intelligently offloading data to cloud services or local storage based on mission parameters and connectivity. For applications like mapping and remote sensing, the OS would facilitate the rapid ingestion of diverse data types, perform initial stitching or analysis, and present actionable insights directly to the operator or seamlessly integrate with larger data analytics platforms.

The Strategic Importance of OS Architecture for Drone Security and Scalability
Finally, the architectural integrity of an operating system is paramount for the long-term viability, security, and scalability of drone technology. WebOS, built on a Linux kernel, inherits a legacy of robustness and security best practices. For drones, especially those operating in sensitive environments or handling critical data, OS-level security features—such as secure boot, access control, sandboxing, and regular over-the-air (OTA) updates—are non-negotiable. An OS designed with these considerations ensures that drone platforms are resilient against cyber threats, unauthorized access, and software vulnerabilities. Furthermore, a well-designed OS provides a scalable foundation, allowing drone manufacturers to easily integrate new hardware components, deploy advanced software features, and adapt to evolving regulatory requirements without undertaking fundamental redesigns. In essence, while webOS itself might not power the next generation of flight controllers, its principles offer a powerful vision for an open, secure, intuitive, and highly capable operating environment that could redefine the future of drone innovation and interaction.