
The intricate dance of modern flight technology, especially in the realm of unmanned aerial vehicles (UAVs) like drones, relies on a sophisticated bedrock of mathematics and physics. At the heart of many critical functions—from navigation and stabilization to obstacle avoidance and precise trajectory following—lies the fundamental concept of a vector projection. Far from an abstract mathematical exercise, vector projection is an indispensable tool that enables drones to understand their environment, maintain stability, and execute complex maneuvers with unparalleled precision. It provides a way to deconstruct vector information, allowing onboard systems to isolate specific components of forces, velocities, or sensor readings that are relevant to a particular direction or task.
The Core Concept of Vector Projection
To fully grasp its importance in flight technology, one must first understand what a vector projection is at its fundamental level. A vector is a mathematical entity possessing both magnitude (size) and direction. In the context of flight, vectors represent quantities like velocity (speed in a specific direction), force (push or pull in a specific direction), or displacement (change in position in a specific direction).
Vectors and Their Significance in Flight
Every aspect of a drone’s movement and interaction with its environment can be described using vectors. The drone’s velocity, the gravitational force acting upon it, the thrust generated by its propellers, and even wind gusts are all vector quantities. For a drone’s flight controller to make sense of this continuous stream of information, it often needs to break down these complex vectors into simpler, more manageable components. This is where vector projection becomes invaluable. It allows the system to determine how much of one vector acts along the direction of another vector. For instance, how much of the drone’s total velocity is directed purely upwards, or how much of a wind force is directly pushing it sideways.
Geometric Interpretation of Projection
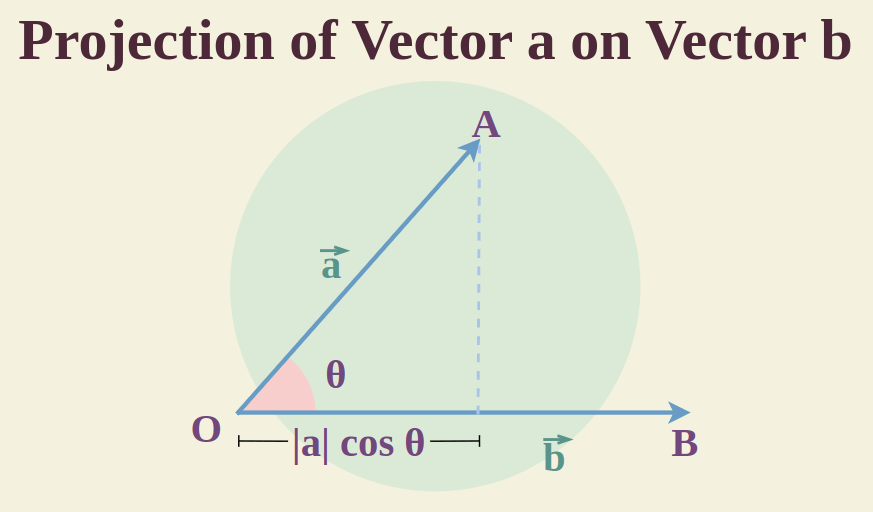
Imagine two vectors, a and b. The projection of vector a onto vector b can be thought of as the “shadow” that a casts on b if a light source were shining perpendicularly onto b. Geometrically, this involves dropping a perpendicular from the tip of vector a to the line containing vector b. The resulting segment along b is the vector projection. The length of this segment is called the scalar projection, while the vector itself, oriented along b, is the vector projection. This process effectively isolates the component of a that is parallel to b, discarding any component of a that is perpendicular to b.
The Scalar and Vector Projection Formulas
Mathematically, the projection of vector a onto vector b (denoted as projb a) is calculated using the dot product, a measure of how much two vectors point in the same direction.
The scalar projection of a onto b, which gives the signed magnitude of the projected component, is:
Scalar Projection = (a ⋅ b) / ||b||
Where a ⋅ b is the dot product of a and b, and ||b|| is the magnitude (length) of vector b.
The vector projection of a onto b, which is a vector in the direction of b with the scalar projection as its magnitude, is:
Vector Projection = ((a ⋅ b) / ||b||²) * b
Alternatively, this can be written as:
Vector Projection = ((a ⋅ b) / (b ⋅ b)) * b
These formulas are not just theoretical constructs; they are actively computed thousands of times per second by drone flight controllers to make real-time decisions, influencing everything from motor speeds to gimbal adjustments.
Vector Projection in Drone Navigation and Control
In the realm of flight technology, vector projection is a cornerstone for ensuring a drone knows where it is, where it’s going, and how to get there stably.
Understanding Direction and Position with GPS
Global Positioning System (GPS) data provides a drone with its absolute position (latitude, longitude, altitude) and velocity relative to the Earth. However, this raw data often needs to be translated into the drone’s local coordinate system or into specific components relevant for flight. For example, if a drone is programmed to fly along a specific bearing (a vector), its current velocity vector from GPS can be projected onto this desired bearing vector. This projection tells the flight controller how much of its current speed is aligned with the intended path and how much is orthogonal (sideways drift), allowing for corrective maneuvers to stay on course. Similarly, converting global coordinates into a local, mission-specific frame often involves vector transformations and projections to understand displacement relative to a home point or a target.
Decomposing Forces and Accelerations for Flight Stability
A drone’s stability is paramount, especially when facing external disturbances like wind gusts or when performing rapid maneuvers. The forces acting on a drone—thrust from propellers, gravity, air resistance, and aerodynamic lift/drag—are all vectors. A flight controller uses vector projection to decompose these forces and the resulting accelerations into components along the drone’s axes (roll, pitch, yaw, and vertical/horizontal translation). For instance, an accelerometer might measure the total acceleration vector. To determine if the drone is purely accelerating upwards or tilting, the acceleration vector is projected onto the drone’s body axes. This allows the system to isolate the vertical acceleration component (for altitude control) from the horizontal acceleration components that contribute to pitch and roll. By understanding these projections, the flight controller can precisely adjust individual propeller speeds to counteract unwanted rotations or translations, maintaining a stable hover or executing a smooth turn.

Path Planning and Trajectory Following
Autonomous flight missions involve defining a desired path or trajectory, which is essentially a sequence of interconnected vectors. As the drone moves along this path, its actual velocity vector is continuously compared to the desired velocity vector at each point. Vector projection plays a critical role in this comparison. The actual velocity can be projected onto the desired path vector to determine the forward progress. Any component of the actual velocity perpendicular to the desired path indicates deviation, prompting the flight controller to generate corrective control signals. Furthermore, when planning complex trajectories, such as curves or spirals, the desired path itself can be broken down into infinitesimal vector segments. At any given moment, the drone’s control system computes the projection of its current state (position and velocity) onto the immediate target segment to ensure smooth and accurate adherence to the planned route, anticipating future positions based on current dynamics.
Sensor Data Interpretation and Obstacle Avoidance
Modern drones are equipped with an array of sensors that constantly feed data into the flight control system. Vector projection is crucial for translating this raw sensor data into actionable information for navigation, stabilization, and especially for intelligent obstacle avoidance.
Interpreting Accelerometer and Gyroscope Data
Accelerometers measure linear acceleration, and gyroscopes measure angular velocity. Both output data as vectors relative to the sensor’s internal frame. To be useful for flight control, these measurements must be transformed into the drone’s body frame or an Earth-fixed frame. For example, an accelerometer reading will include the acceleration due to gravity. By knowing the drone’s orientation (from the gyroscope and a magnetometer), the gravitational vector can be projected onto the accelerometer’s axes. This allows the system to subtract the gravitational component, revealing the true linear acceleration caused by motor thrust or external forces, which is essential for accurate flight dynamics calculations. Similarly, projecting angular velocity measurements onto specific axes helps in isolating roll, pitch, and yaw rates for independent control.
Range Sensor Data and Environmental Mapping
Lidar, sonar, and stereo vision cameras provide distance measurements to surrounding objects. This data often comes in the form of point clouds or depth maps, where each point represents a vector from the sensor to an object surface. To perform obstacle avoidance or environmental mapping, these vectors need to be processed. For instance, to detect obstacles directly in the drone’s flight path, the vectors representing detected objects are projected onto the drone’s intended velocity vector. If the projection of an object vector falls within a certain threshold along the flight path, it indicates an imminent collision. In 3D mapping, multiple range readings from different angles can be projected onto a common ground plane or a 3D grid to build a comprehensive model of the environment, enabling the drone to identify navigable spaces and potential hazards.
Predicting Collisions and Planning Avoidance Maneuvers
When an obstacle is detected, the drone’s system needs to quickly calculate the “time to collision” and plan an avoidance maneuver. This involves predicting the drone’s future trajectory and the obstacle’s potential movement. Vector projection is used to determine the closest point of approach between the drone’s projected path and the obstacle’s projected path. By projecting the relative velocity vector of the drone with respect to the obstacle onto the vector connecting their current positions, the system can estimate if and when they will intersect. Based on this, new path vectors are calculated that steer the drone clear of the obstacle, often involving lateral or vertical shifts that are themselves vector projections of the desired avoidance motion.
Advanced Applications in Autonomous Flight Systems
As drone technology advances towards greater autonomy, vector projection continues to be a foundational mathematical tool enabling complex behaviors and robust performance.
Multi-Sensor Fusion
Autonomous drones often fuse data from multiple sensors—GPS, IMUs (Inertial Measurement Units containing accelerometers and gyroscopes), magnetometers, barometers, and vision systems—to achieve a more accurate and reliable understanding of their state and environment than any single sensor could provide. Vector projection is a core technique in various sensor fusion algorithms, such as Kalman filters or Extended Kalman filters. These algorithms project measurements from different sensor modalities onto a common state space, weighting their contributions based on their respective uncertainties. For example, GPS provides good long-term position data but can drift; IMUs provide high-frequency, short-term data but accumulate error. By projecting and combining these complementary vector measurements, a fusion algorithm can generate a more precise estimate of the drone’s position, velocity, and orientation.
Real-Time State Estimation
Knowing a drone’s precise state (position, velocity, acceleration, orientation, angular rates) in real-time is critical for autonomous flight. Vector projection is utilized within state estimation algorithms to update these parameters. For instance, an estimated velocity vector can be projected forward in time based on observed acceleration vectors to predict the next position. When a new sensor measurement arrives (e.g., a GPS update), its difference from the predicted state (innovation vector) is projected onto the estimated uncertainty covariance matrices to optimally correct the state estimate. This iterative process, heavily reliant on vector projections, allows drones to maintain a continuous, accurate model of their dynamic state even in challenging conditions.
Predictive Control Systems
Advanced autonomous drones employ predictive control systems that anticipate future states and actively plan control inputs to achieve desired outcomes. For example, Model Predictive Control (MPC) uses a mathematical model of the drone’s dynamics to predict its behavior over a future time horizon. It then calculates a sequence of control inputs (e.g., motor thrust vectors) that minimize a cost function (e.g., deviation from target path, energy consumption), subject to constraints (e.g., maximum motor speed). Vector projection is integral here for evaluating the impact of different control input vectors on the drone’s predicted trajectory and for decomposing desired complex maneuvers into achievable thrust and torque components for each propeller. This forward-looking approach ensures smoother, more efficient, and more robust autonomous flight.

The Unseen Mathematical Backbone of Flight
In summary, vector projection is not merely an abstract mathematical concept taught in textbooks; it is an active, indispensable tool operating behind the scenes of every modern drone flight. From the initial calibration of its sensors to the execution of complex autonomous missions, vector projection provides the mathematical framework for breaking down complex physical realities into manageable, actionable components. It allows flight technology to precisely interpret sensor data, accurately navigate space, maintain unwavering stability, and intelligently avoid obstacles. Without the ability to deconstruct vectors into their relevant directional components, the advanced capabilities that define contemporary flight technology, particularly in drones, would be significantly limited, underscoring vector projection as a foundational mathematical backbone for the future of aerial innovation.