
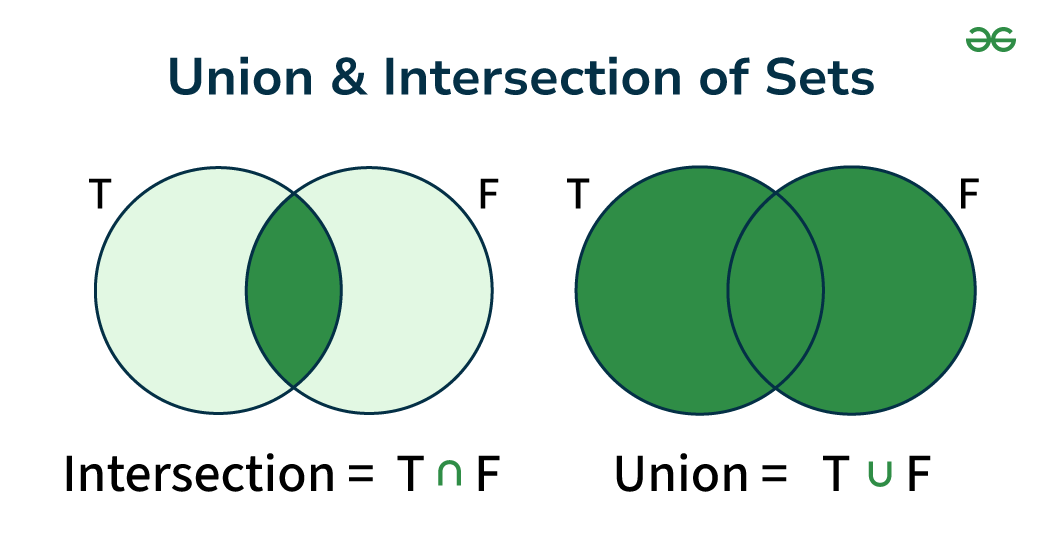
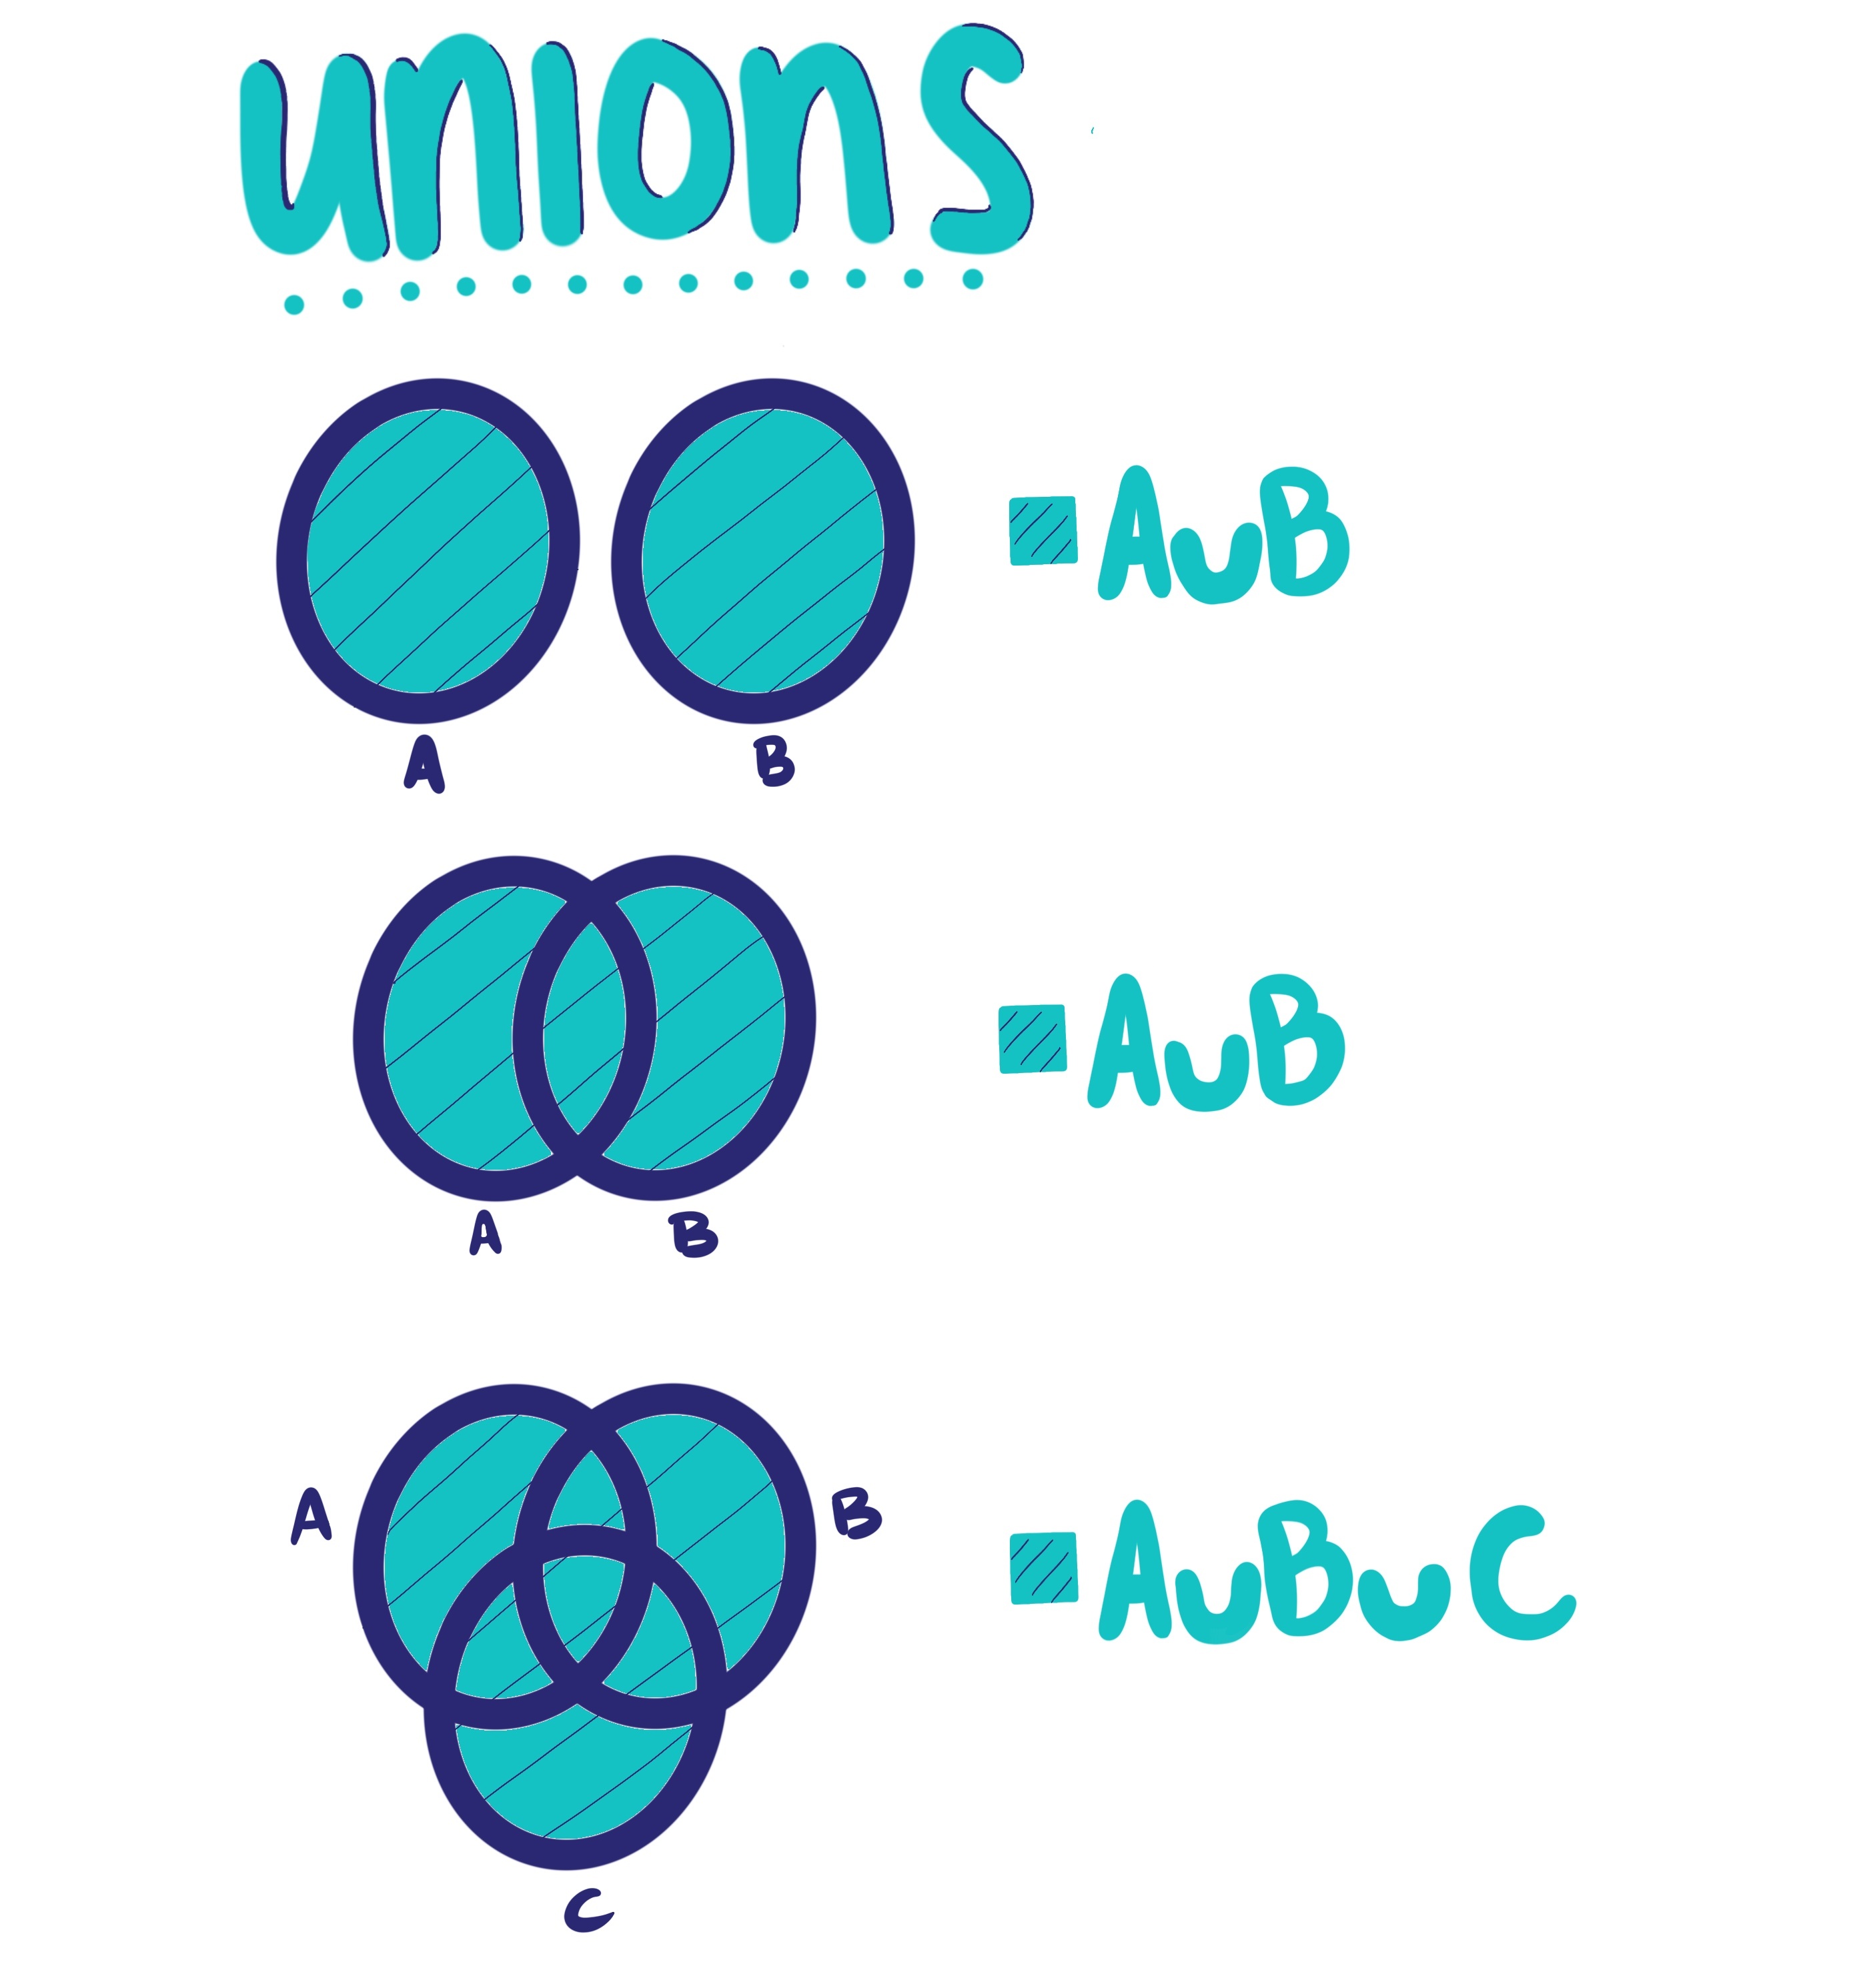
In its purest mathematical sense, a union is a fundamental operation in set theory. When we talk about the union of two or more sets, we refer to a new set that contains all the distinct elements that are present in at least one of the original sets. Symbolically, if we have two sets, A and B, their union is denoted as A ∪ B. This operation is not merely an abstract concept confined to textbooks; its underlying principle of combining disparate elements into a cohesive, comprehensive whole is profoundly relevant to the intricate world of drone technology and innovation. Within the dynamic landscape of modern Unmanned Aerial Vehicles (UAVs), particularly in their advanced functionalities, the concept of a “union” manifests across data fusion, system integration, and algorithmic design, driving the intelligence and autonomy that define cutting-edge drone applications.
The Fundamental Concept of Union and Its Technological Parallel
At its core, the mathematical union is about aggregation – taking individual, separate collections and synthesizing them into a single, unified collection. This principle is not only intuitive but essential for handling complexity in various systems. Imagine two lists of characteristics for a drone: one lists its propulsion components (motors, propellers) and another lists its sensors (GPS, IMU, camera). The “union” of these characteristics describes the drone’s entire hardware complement. Extending this analogy, in drone technology, we often deal with multiple streams of data, various sensor inputs, and diverse software modules that must be integrated to function as a single, intelligent entity. The successful “union” of these components is what elevates a simple flying machine into a sophisticated autonomous system capable of complex tasks. This conceptual bridge allows us to understand how seemingly abstract mathematical principles find concrete application in engineering challenges.
Sets and Their Combination in Drone Systems
Consider the “sets” of information a drone continuously processes. One set might be the location data from a Global Positioning System (GPS) receiver. Another set could be the orientation and acceleration data from an Inertial Measurement Unit (IMU). Individually, each set provides valuable but incomplete information. GPS gives position, but often with some drift and latency, and no immediate orientation. IMU provides precise short-term orientation and acceleration, but drifts over time without external correction. The “union” of these data sets, through sophisticated sensor fusion algorithms like a Kalman filter, produces a far more accurate and robust understanding of the drone’s position, velocity, and attitude. This fused data, richer and more reliable than its individual components, then becomes the foundation for navigation, stabilization, and control – a perfect illustration of how the principle of union creates a more powerful and complete outcome.
Data Unions in Advanced Flight Technology
Modern drones rely heavily on the intelligent integration of diverse data sources to achieve their sophisticated capabilities. This integration can be seen as forming “unions” of data, where multiple streams of information are combined to create a unified and more complete picture of the drone’s environment and its state. The robustness and reliability of a drone’s flight depend critically on how effectively these data unions are formed and processed.
GPS and IMU Data Union for Precise Navigation
As touched upon, the classic example of data union in drone flight technology is the combination of GPS and IMU data. The GPS system provides absolute positional coordinates, while the IMU (consisting of accelerometers, gyroscopes, and magnetometers) provides relative motion and orientation data. The “union” of these two data sets is not a simple concatenation but a sophisticated fusion process. Algorithms continuously evaluate the strengths and weaknesses of each data source—GPS for long-term accuracy, IMU for high-frequency short-term changes—and blend them to produce an optimal estimate of the drone’s state. This fused data set, a powerful union of positional and inertial information, is what enables highly accurate waypoint navigation, precise hovering, and stable flight paths even in challenging conditions where individual sensors might falter.
Environmental Data Integration for Obstacle Avoidance
Beyond internal state estimation, drones form data unions about their external environment. Advanced obstacle avoidance systems, crucial for autonomous flight in complex terrains, are prime examples. These systems might integrate data from several types of sensors:
- Ultrasonic sensors: Provide short-range distance measurements.
- Lidar (Light Detection and Ranging): Generates precise 3D maps of the environment.
- Stereo cameras: Offer visual depth perception.
- Thermal cameras: Detect heat signatures, useful in low-light conditions.
Each sensor provides a unique “set” of data about potential obstacles. The drone’s onboard processing unit performs a continuous “union” of these diverse data streams. It correlates the ultrasonic readings with the lidar point cloud, cross-references these with visual data from stereo cameras, and perhaps even integrates thermal information. This multi-sensory union builds a comprehensive, real-time 3D model of the drone’s surroundings, allowing it to detect and classify obstacles, predict potential collisions, and dynamically adjust its flight path for safe navigation. Without this powerful data union, the drone’s ability to operate autonomously in dynamic and cluttered environments would be severely limited.
Algorithmic Unions for Autonomous Functionality
The principle of union extends beyond raw data fusion into the realm of algorithms and intelligent decision-making. Autonomous drone functions often involve the integration, or “union,” of multiple computational models, rule sets, and decision trees to achieve complex behaviors. This algorithmic union allows drones to exhibit intelligent responses to dynamic situations, adapting their actions based on a confluence of inputs and predetermined logic.
AI Follow Mode: Uniting Vision and Control
Consider an AI Follow Mode, where a drone autonomously tracks a moving subject. This complex functionality is the result of a sophisticated algorithmic union. One “set” of algorithms focuses on computer vision—identifying and tracking the target within the camera’s field of view, calculating its relative position and movement vector. Another “set” of algorithms governs flight control—translating the target’s movement into precise commands for the drone’s propulsion and stabilization systems.
The “union” here is the seamless integration of these two distinct algorithmic domains. The vision algorithms continuously feed updated target position data to the flight control algorithms, which then execute the necessary maneuvers to maintain optimal distance and angle. Furthermore, this union might include another set of algorithms for obstacle avoidance, ensuring the drone does not collide with environmental features while tracking. The robustness of the AI follow mode stems from this intelligent union of perception, planning, and execution algorithms, allowing for dynamic and intelligent tracking.
Mapping and Remote Sensing: Combining Diverse Datasets
In mapping and remote sensing applications, drones are deployed to gather vast amounts of geospatial data. This data is often heterogeneous, including high-resolution RGB imagery, multispectral data (for vegetation health analysis), thermal imagery (for heat signatures or water stress), and LiDAR point clouds (for precise 3D elevation models). The creation of comprehensive maps or analytical reports requires a “union” of these diverse datasets.
Post-flight processing involves sophisticated software that registers and aligns all these different data types into a single, unified geospatial model. For instance, RGB images are georeferenced and stitched together to form orthomosaics. This orthomosaic is then combined with multispectral data, where each pixel from the RGB image finds its corresponding spectral values. LiDAR data is also merged to create a dense 3D representation that can be overlaid with visual and spectral information. This multi-layered “union” of data provides an incredibly rich and insightful view of an area, far surpassing what any single data type could offer. From precision agriculture to urban planning and environmental monitoring, the power lies in this comprehensive data union, enabling advanced analysis and decision-making.
The Union of Technologies in Advanced UAV Design
The concept of a “union” in drone technology is not confined to software or data alone; it is intrinsically woven into the very fabric of hardware design and system architecture. The development of advanced UAVs often involves bringing together a union of disparate technologies – propulsion systems, communication modules, power management, and specialized payloads – to form a highly optimized and functional platform.
System Integration for Enhanced Performance
Every drone is a testament to the principle of technological union. Consider a professional cinematic drone. It comprises a union of:
- Aerodynamic Frame: Designed for stability and efficiency.
- High-Performance Motors and Propellers: Selected for thrust, efficiency, and quiet operation.
- Advanced Flight Controller: The brain, integrating sensor data and executing commands.
- Stabilized Gimbal and High-Resolution Camera: A precise mechanical and optical union for smooth, high-quality imaging.
- Long-Range, Low-Latency Communication System: Ensuring reliable control and video transmission.
- Intelligent Battery Management System: Optimizing power delivery and monitoring.
The performance of such a drone is not merely the sum of its parts; it is the synergistic outcome of the successful “union” of these technologies. Each component is chosen and integrated to complement the others, creating a system where the whole is far greater than the individual elements. For example, the precise control algorithms of the flight controller work in union with the responsive motors to achieve incredibly stable flight, which in turn allows the gimbal to achieve perfect stabilization for cinematic shots. This intricate dance of interconnected technologies is what defines state-of-the-art drone design.

Future Implications: Orchestrating Complex Unions
As drone technology continues to evolve, the complexity and sophistication of these “unions” will only increase. Future drones will likely feature even tighter integration of AI and machine learning across all subsystems, creating a grander union of intelligent agents working in concert. Imagine a swarm of drones, each operating autonomously but forming a collective “union” to achieve a common goal, sharing data, coordinating movements, and adapting to dynamic environments as a single, distributed intelligence.
This could involve the union of ground-based sensor networks with aerial platforms for enhanced situational awareness, or the fusion of satellite imagery with real-time drone data for hyper-local environmental monitoring. The mathematical concept of a union – bringing disparate elements together to form a more complete and powerful whole – will remain a guiding principle for engineers and innovators pushing the boundaries of what drones can achieve, creating increasingly intelligent, autonomous, and capable aerial systems. The future of drone technology is, in essence, an ongoing exploration of more sophisticated and effective unions across hardware, software, data, and algorithms.