
A self-driving car, also known as an autonomous vehicle (AV), driverless car, or robotic car, represents one of the most significant technological leaps in modern history. Far more than just a car that drives itself, it embodies a complex symphony of advanced computing, artificial intelligence, sophisticated sensors, and intricate algorithms designed to perceive its environment, make decisions, and navigate without human intervention. At its core, a self-driving car is an intelligent system engineered to automate the driving task, transforming personal mobility and reimagining the future of transportation.
The Core Concept of Autonomous Mobility
The idea of a car that operates independently has captivated engineers and innovators for decades. Today, this vision is moving from science fiction to a tangible reality, driven by exponential advancements in computing power and data processing. Autonomous mobility isn’t merely about convenience; it’s about fundamentally reshaping safety, efficiency, and accessibility in personal and public transportation. These vehicles are designed to perform all dynamic driving tasks, from steering and acceleration to braking and navigating complex traffic scenarios, relying on a confluence of high-tech components and intelligent software.

Defining Autonomy: Levels of Self-Driving
The industry categorizes autonomous vehicles into six distinct levels, established by the Society of Automotive Engineers (SAE International), illustrating a clear progression from minimal assistance to full automation:
- Level 0 (No Automation): The driver is solely responsible for all driving tasks.
- Level 1 (Driver Assistance): Features like adaptive cruise control or lane keeping assist provide minor support, but the driver maintains full control and responsibility.
- Level 2 (Partial Automation): The vehicle can control both steering and acceleration/deceleration simultaneously under specific conditions, but the driver must monitor the environment and be ready to take over at any moment. This includes systems like “Super Cruise” or “Autopilot.”
- Level 3 (Conditional Automation): The vehicle can perform all driving tasks under certain conditions and monitor the environment, allowing the driver to disengage from active driving. However, the system will request the driver to intervene if it encounters situations it cannot handle.
- Level 4 (High Automation): The vehicle can perform all driving tasks and monitor the driving environment under specific operational design domains (ODDs), such as geofenced areas or certain weather conditions. Human intervention is not required within these domains, and the vehicle can safely pull over if the driver fails to respond to a takeover request.
- Level 5 (Full Automation): The vehicle can operate completely autonomously under all driving conditions, in all environments, without any human intervention. There is no need for a steering wheel or pedals, as the vehicle handles every aspect of driving.
Beyond Human Control: The Vision of Fully Autonomous Vehicles
The ultimate goal of self-driving technology lies in achieving Level 5 autonomy, where the vehicle operates completely independent of human input. This represents a paradigm shift, moving beyond mere driver assistance to full machine control. The vision includes vehicles that can navigate urban landscapes, highways, and rural roads, responding to dynamic changes in traffic, weather, and road conditions with a level of consistency and safety that is difficult for human drivers to match. This transformation promises to unlock new possibilities for personal freedom, logistical efficiency, and urban planning, fundamentally altering how we interact with transportation.
Enabling Technologies: The Pillars of Autonomy
The capabilities of a self-driving car are built upon an intricate web of advanced technologies working in unison. These pillars of autonomy allow the vehicle to perceive its surroundings, process vast amounts of data, predict outcomes, and execute precise maneuvers. Without these sophisticated systems, the concept of a truly autonomous vehicle would remain firmly in the realm of theoretical possibility.
Artificial Intelligence and Machine Learning
At the heart of any self-driving car lies a powerful artificial intelligence system, extensively trained using machine learning algorithms. AI enables the vehicle to learn from vast datasets of real-world driving scenarios, identifying patterns, objects, and potential hazards. Deep learning, a subset of machine learning, plays a crucial role, particularly in image recognition and object classification from sensor data. The AI system processes information from multiple sensors, understanding the complex interplay of traffic, pedestrians, cyclists, and road signs. It predicts the behavior of other road users, makes split-second decisions, and continuously refines its understanding of the driving environment, acting as the “brain” that orchestrates all other components.
Sensor Fusion: Perceiving the World
Self-driving cars rely on an array of sophisticated sensors to create a comprehensive, real-time 360-degree model of their environment. This “perception stack” includes:
- Cameras: Provide high-resolution visual data, crucial for detecting lane markings, traffic lights, road signs, and classifying objects like pedestrians and vehicles.
- LiDAR (Light Detection and Ranging): Emits pulsed laser light to measure distances and create detailed 3D maps of the surroundings, providing precise spatial information regardless of lighting conditions.
- Radar (Radio Detection and Ranging): Uses radio waves to detect the speed and distance of objects, particularly effective in adverse weather conditions like fog or heavy rain, where optical sensors may be limited.
- Ultrasonic Sensors: Short-range sensors used for parking and low-speed maneuvers, detecting nearby obstacles.
The data from these diverse sensors is then “fused” together by the AI system. Sensor fusion integrates the strengths of each sensor type while mitigating their individual weaknesses, creating a robust and redundant perception of the environment. This redundancy is critical for safety and reliability, ensuring that the vehicle can accurately “see” its surroundings even if one sensor is compromised or in challenging conditions.
High-Definition Mapping and Localization
Beyond real-time sensor data, self-driving cars utilize highly detailed, pre-built high-definition (HD) maps. Unlike standard GPS maps, HD maps provide centimeter-level accuracy for road geometry, lane boundaries, traffic signs, and even the precise location of road furniture. These maps are continuously updated and serve as a fundamental reference point for the vehicle.
Localization is the process by which the self-driving car determines its exact position on this HD map. Using GPS, inertial measurement units (IMUs), and matching real-time sensor data (like LiDAR point clouds or camera features) against the HD map, the vehicle can pinpoint its location with extreme precision. This accurate localization is vital for precise lane keeping, turn execution, and anticipating upcoming road features.
Real-time Decision Making and Path Planning
With a clear understanding of its environment and its precise location, the self-driving car’s AI system must then make real-time decisions and plan its trajectory. This involves:
- Behavior Prediction: Anticipating the future movements of other vehicles, pedestrians, and cyclists based on their current state and historical patterns.
- Path Planning: Generating a safe, efficient, and comfortable path to the destination, considering traffic laws, road conditions, and dynamic obstacles. This involves continuous recalculation and optimization of the vehicle’s speed, acceleration, and steering angle.
- Motion Control: Executing the planned path by sending precise commands to the vehicle’s actuators (steering, brakes, accelerator).
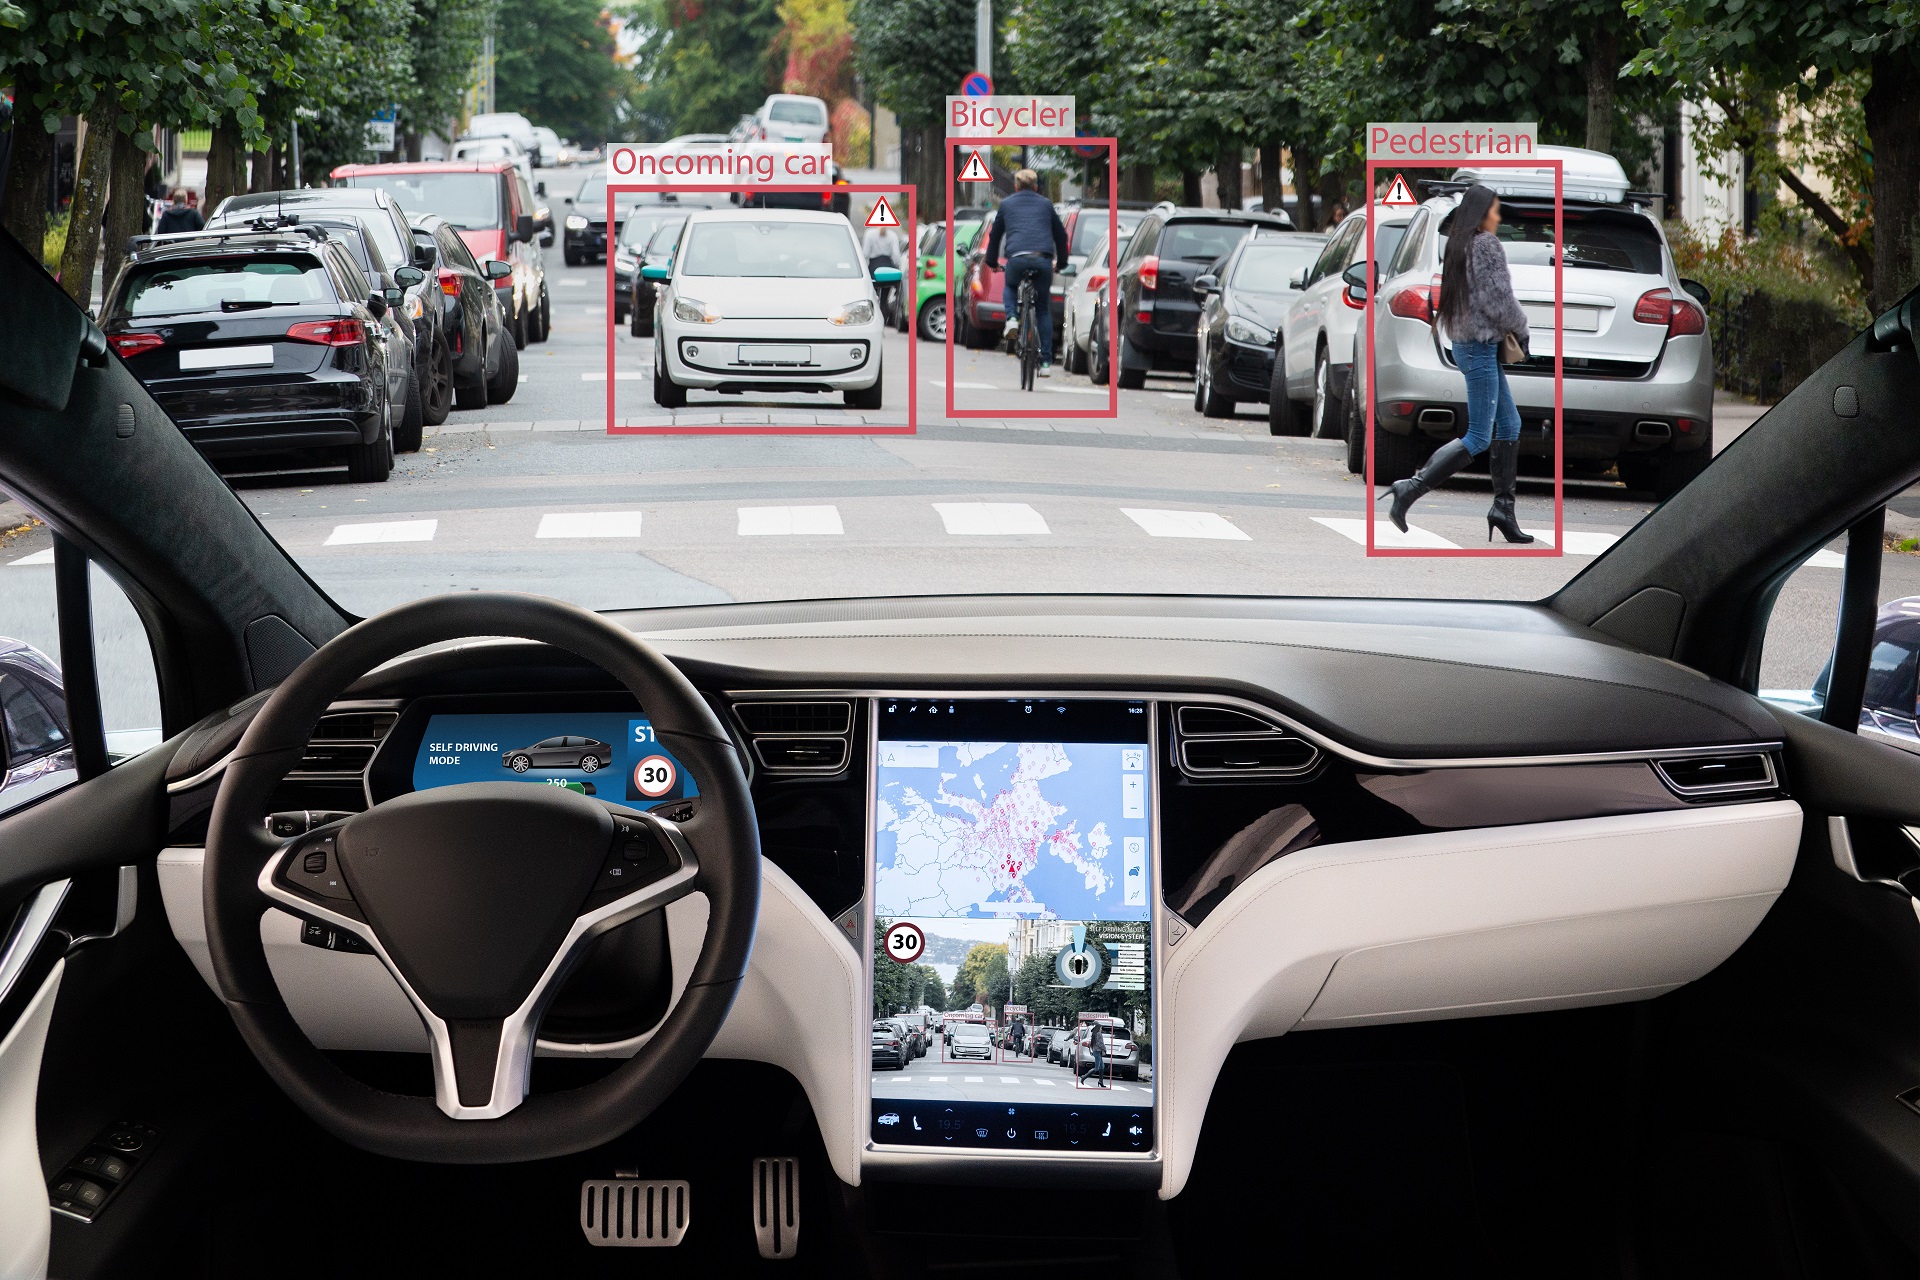
This entire cycle of sensing, perceiving, localizing, predicting, planning, and acting happens continuously, many times per second, ensuring the vehicle can react instantaneously to a rapidly changing environment.
The Transformative Potential of Autonomous Vehicles
The introduction of self-driving cars promises to usher in a new era of transportation, bringing with it profound societal and economic benefits. The technological innovation inherent in these vehicles extends far beyond the mechanics of driving, touching upon safety, efficiency, and accessibility.
Enhanced Safety and Reduced Accidents
One of the most compelling promises of autonomous vehicles is a dramatic reduction in road accidents. Human error—due to factors like distraction, fatigue, impairment, or aggressive driving—is responsible for over 90% of all traffic collisions. Self-driving cars, by contrast, operate with unwavering attention, never get tired, are not susceptible to emotional influences, and react faster than humans. Their sophisticated sensors and AI systems can perceive threats beyond human visual or auditory range, leading to more consistent and safer driving. This could save millions of lives and prevent countless injuries globally, alleviating the immense human and economic cost of road accidents.
Improved Efficiency and Traffic Flow
Autonomous vehicles have the potential to significantly improve traffic flow and reduce congestion. By communicating with each other (vehicle-to-vehicle or V2V) and with infrastructure (vehicle-to-infrastructure or V2I), AVs can coordinate their movements, optimize speeds, and maintain tighter platooning distances, effectively increasing road capacity. Intelligent routing algorithms can guide vehicles to avoid congested areas, dynamically adjusting routes in real-time. This improved efficiency translates into shorter travel times, reduced fuel consumption, and lower emissions, leading to a more sustainable and pleasant urban environment.
Accessibility and Urban Mobility Redefined
Self-driving cars can revolutionize mobility for individuals who currently face significant transportation barriers. The elderly, people with disabilities, and those who cannot obtain a driver’s license due to age or health conditions will gain unprecedented independence and access to transportation. Furthermore, the rise of autonomous ride-sharing fleets could reduce the need for personal car ownership, leading to fewer vehicles on the road, less demand for parking spaces, and more efficient use of urban land. This transformation could redefine urban planning, allowing cities to repurpose land currently dedicated to parking lots and wide roads for public spaces, parks, or housing.
Economic and Societal Impacts
The economic implications of self-driving cars are vast. Industries such as logistics, ride-sharing, and freight transport stand to gain immense efficiencies from automated operations, leading to reduced labor costs, optimized delivery routes, and 24/7 service capabilities. The insurance industry will undergo significant changes as the responsibility for accidents shifts from drivers to manufacturers and software providers. On a societal level, the time previously spent driving can be repurposed for work, leisure, or rest, enhancing productivity and quality of life. The technology also presents new opportunities for innovative business models and services that integrate seamlessly with autonomous mobility.
Challenges and the Road Ahead
Despite the immense potential, the journey to widespread autonomous vehicle deployment is fraught with significant challenges that require ongoing innovation, robust policy frameworks, and careful public engagement.
Regulatory and Legal Frameworks
One of the most complex hurdles is establishing comprehensive regulatory and legal frameworks for autonomous vehicles. Questions surrounding liability in the event of an accident, data privacy, and cybersecurity standards for AV systems need clear answers. Governments worldwide are grappling with how to create consistent and adaptable regulations that foster innovation while ensuring public safety. The definition of an “operator” and the requirements for licensing and testing autonomous systems are also crucial considerations.
Public Acceptance and Trust
Public perception and trust are paramount for the successful integration of self-driving cars. High-profile accidents, even if rare, can significantly erode public confidence. Building trust requires transparent communication about the technology’s capabilities and limitations, rigorous safety testing, and a clear understanding of how AVs handle edge cases. Educating the public about the benefits and safety advancements is key to overcoming skepticism and fostering acceptance.
Cybersecurity and Data Privacy
Autonomous vehicles are sophisticated computer systems on wheels, making them potential targets for cyberattacks. Protecting these systems from hacking, which could compromise vehicle control or data integrity, is a critical challenge. Moreover, AVs collect vast amounts of data about their occupants and the environment. Ensuring the privacy and secure management of this data is essential to prevent misuse and maintain consumer trust. Robust cybersecurity measures must be embedded into every layer of the vehicle’s architecture, from hardware to software.
Complex Edge Cases and System Reliability
While AVs excel in routine driving scenarios, handling “edge cases”—unusual or unforeseen situations that rarely occur but can be dangerous—remains a significant challenge. These might include unpredictable human behavior, unusual road debris, extreme weather conditions, or complex construction zones. Developing AI systems that can reliably perceive, understand, and safely react to the infinite variability of the real world requires continuous testing, advanced simulation, and ongoing algorithmic refinement. Ensuring the overall reliability and fault tolerance of these highly complex systems under all possible conditions is an enormous engineering feat.
The Future of Autonomous Driving
The path to fully autonomous driving is an evolving landscape of continuous innovation. As the technology matures, we can anticipate a future where self-driving vehicles are not just a novelty but an integral part of our daily lives. Further advancements in AI, sensor technology, and connectivity will undoubtedly enhance the capabilities and safety of these systems. The integration of Vehicle-to-Everything (V2X) communication will allow AVs to communicate not only with each other but also with traffic infrastructure, pedestrians’ smartphones, and the broader smart city ecosystem, creating a more cohesive and intelligent transportation network. The ongoing development and deployment of self-driving cars promise to redefine urban environments, individual mobility, and economic paradigms, forging a future where travel is safer, more efficient, and universally accessible.