
In the intricate world of flight technology, precision, reliability, and robust decision-making are paramount. Drones, with their complex array of sensors, navigation systems, and autonomous capabilities, rely heavily on sophisticated mathematical tools to interpret data, understand uncertainty, and operate safely. Among these tools, the Probability Density Function (PDF) stands out as a fundamental concept, offering a powerful way to model and analyze continuous variables critical to drone flight. Far from being an abstract statistical concept, PDFs are integral to everything from pinpointing a drone’s exact location to predicting the lifespan of its components.

The Core Concept of Probability Density
At its heart, a Probability Density Function (PDF) is a function whose value at any given point in a sample space can be interpreted as providing a relative likelihood that the value of the random variable would equal that sample point. For continuous random variables—those that can take on any value within a given range (e.g., a drone’s altitude, temperature, or GPS error)—the PDF is the cornerstone for understanding how these values are distributed.
Unlike discrete probability distributions, where a Probability Mass Function (PMF) gives the exact probability for specific outcomes, a PDF does not directly give the probability of a specific point. For a continuous variable, the probability of any single exact value is technically zero. Instead, the PDF allows us to calculate the probability that a random variable falls within a range of values. This is done by integrating the PDF over that range, effectively calculating the area under the curve of the function between two points. The total area under any PDF curve must always sum to 1, representing 100% probability that the variable will take on some value within its possible range.
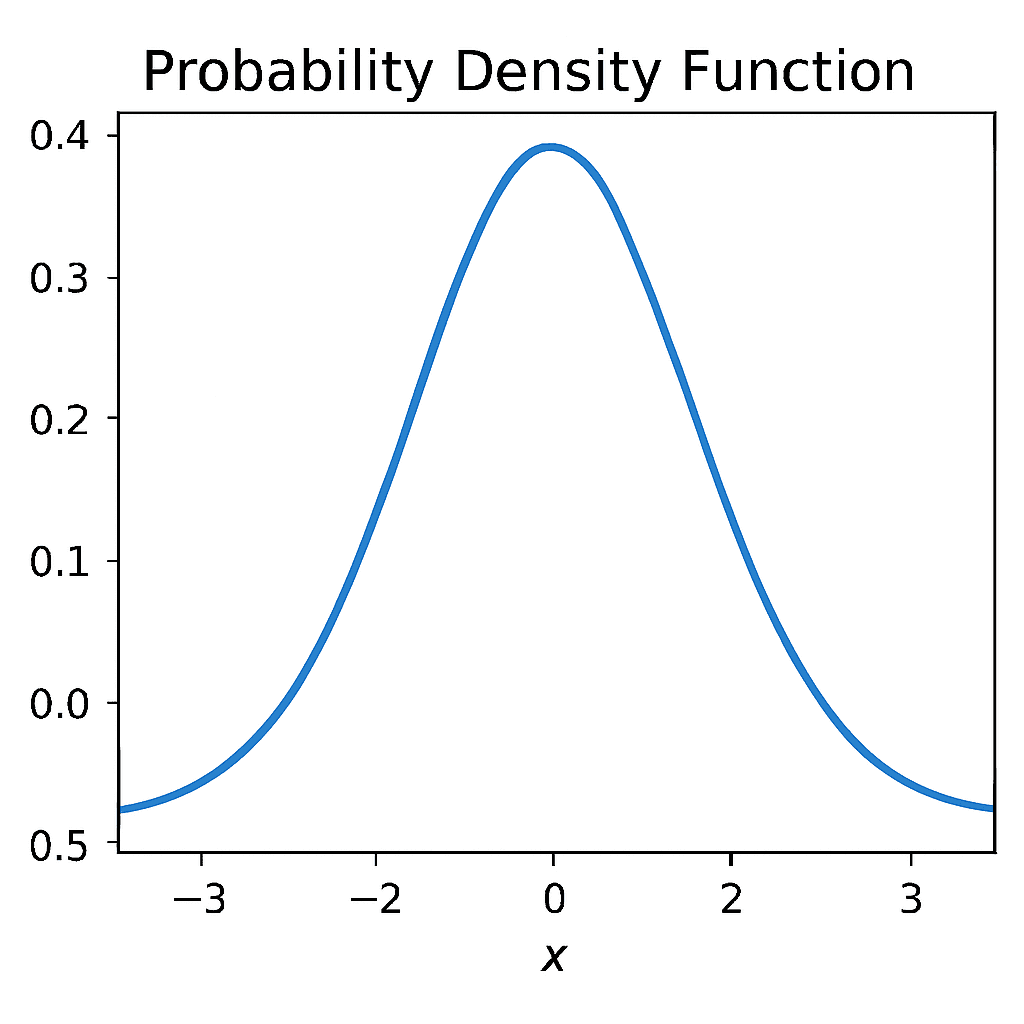
Visually, a PDF is represented by a curve where the height of the curve at any point indicates the relative density of the probability. Taller sections of the curve mean that values in that region are more likely to occur. Common examples include the normal (Gaussian) distribution, often seen as a bell curve, which is frequently used to model errors and sensor noise due to its pervasive appearance in natural phenomena and measurement processes.
PDF’s Role in Drone Navigation and GPS
Accurate navigation is the bedrock of drone operation, allowing for precise flight paths, stable hovering, and safe returns. GPS (Global Positioning System) is a primary navigation sensor, but it is not infallible. The signals from satellites are subject to various disturbances, leading to inherent positional errors. This is where the Probability Density Function becomes indispensable.
Understanding GPS Positional Error
A drone’s GPS receiver constantly processes signals from multiple satellites to determine its latitude, longitude, and altitude. However, factors such as atmospheric conditions, multi-path reflections (signals bouncing off buildings), satellite geometry, and receiver noise all introduce uncertainty. This uncertainty means that the reported GPS position is not the drone’s absolute true position but rather an estimate.
PDFs are used to model this positional error. For instance, a 2D Gaussian PDF (often represented as an ellipse of uncertainty) can describe the distribution of horizontal position errors. The center of the ellipse would be the reported GPS coordinate, and the spread of the ellipse (defined by standard deviations) would indicate the likelihood of the true position being within a certain distance of that reported point. For example, a “95% confidence ellipse” means there’s a 95% probability that the drone’s true position lies within that elliptical boundary. Understanding this PDF allows flight controllers to quantify the reliability of GPS data and to account for its limitations in critical flight phases.
Filtering and Estimation with Sensor Fusion
Modern drone flight technology rarely relies on a single sensor. Instead, it employs sensor fusion techniques, combining data from GPS, Inertial Measurement Units (IMUs—accelerometers and gyroscopes), barometers, and other sensors to achieve a more robust and accurate estimate of the drone’s state (position, velocity, orientation). Algorithms like Kalman Filters and Extended Kalman Filters (EKF) are fundamental to this process.
These filters are essentially probabilistic estimators. They use PDFs to model the noise and uncertainty associated with each sensor reading, as well as the uncertainty in the drone’s dynamic model (how it moves based on control inputs). At each time step, the filter predicts the drone’s next state based on its previous state and control commands, then updates this prediction using new sensor measurements. Crucially, the update step weighs the sensor readings based on their estimated accuracy, which is defined by their associated PDFs. A sensor with a tighter, narrower PDF (less noise, higher precision) will have more influence on the final state estimate than a sensor with a wider, flatter PDF (more noise, lower precision). By continuously refining these probability distributions, Kalman filters provide an optimal estimate of the drone’s true state, leading to superior navigation, stabilization, and control performance compared to using individual sensors alone.
Enhancing Sensor Data Interpretation

Beyond navigation, PDFs play a vital role in processing and interpreting data from all onboard sensors, ensuring the drone can accurately perceive its environment and maintain stable flight.
Noise Modeling for Flight Controllers
Every sensor on a drone, from accelerometers and gyroscopes to barometers and magnetometers, produces readings that contain some level of inherent noise. This noise is random fluctuation that can obscure the true signal, leading to erratic behavior if not properly managed. PDFs are the primary tool for modeling this sensor noise.
For example, an accelerometer reading, intended to measure acceleration, will include a component of random error. This error often follows a Gaussian (normal) distribution, meaning that small errors are much more likely than large errors. By characterizing the noise distribution with a PDF, flight controllers can effectively distinguish between actual changes in the drone’s motion and mere sensor noise. This allows for the design of noise-reduction filters that intelligently smooth sensor data, improving the accuracy of attitude estimation (roll, pitch, yaw) and ensuring stable flight. Without a proper understanding of sensor noise PDFs, a drone’s stabilization system would constantly overcompensate for non-existent movements, leading to an unstable and inefficient flight.
Anomaly Detection and Predictive Maintenance
PDFs are not just for understanding normal operation; they are also crucial for identifying deviations. By establishing a PDF that describes the expected range and distribution of sensor readings under normal operating conditions, any significant departure from this distribution can be flagged as an anomaly.
For instance, if a motor’s current draw or temperature sensor reading suddenly falls outside the expected PDF parameters during flight, it could indicate an impending failure. Similarly, a battery’s voltage discharge curve can be modeled with a PDF, and deviations from this model can signal a faulty cell or degradation. This concept extends to predictive maintenance, where the “health” of various components (motors, ESCs, batteries) can be tracked over time. By using PDFs to model the probability of component failure as a function of operational hours or cycles, drone operators can schedule maintenance proactively, replacing parts before they catastrophically fail, thus enhancing safety and operational reliability. This approach minimizes unexpected downtime and prevents costly damage that could arise from in-flight component failure.
Obstacle Avoidance and Risk Assessment
In increasingly complex flight environments, robust obstacle avoidance is essential for safe autonomous drone operation. PDFs contribute significantly to how drones perceive and react to their surroundings.
Probabilistic Obstacle Mapping
Traditional obstacle avoidance systems often create binary maps: an area is either clear or contains an obstacle. However, sensor data from LiDAR, radar, or ultrasonic sensors is rarely perfectly precise. There’s always some degree of uncertainty regarding the exact position, size, and even existence of an detected object. This is especially true in adverse weather conditions or cluttered environments.
Probability Density Functions allow for the creation of “probabilistic obstacle maps.” Instead of a binary decision, each point in the drone’s surrounding environment is assigned a probability density value indicating the likelihood of an obstacle being present at that location. For example, a LiDAR sensor might report a distance with an associated PDF describing the uncertainty in that measurement. By fusing these probabilistic measurements over time and from different viewpoints, the drone can build a more nuanced and accurate representation of its environment. This probabilistic approach enables more sophisticated path planning algorithms that can assess different flight paths not just on distance, but also on the probability of collision, allowing for safer decision-making in high-risk scenarios.
Risk Management in Autonomous Flight
PDFs are also fundamental to the broader concept of risk assessment in autonomous flight. Every decision made by an autonomous drone, from choosing a flight path to executing a landing, involves potential risks. These risks can stem from sensor uncertainty, environmental unpredictability (e.g., sudden wind gusts), or system failures.
By leveraging PDFs, autonomous systems can quantify these risks. For example, if a drone is navigating through a narrow corridor, the PDFs modeling the uncertainty in its own position (from GPS and IMU) and the uncertainty in the corridor’s boundaries (from obstacle detection sensors) can be combined to calculate the probability of colliding with a wall. The drone can then choose a path that minimizes this probability, or if the probability exceeds a certain threshold, it might decide to abort the mission or seek human intervention. This probabilistic approach to risk management empowers drones to operate with a higher degree of safety and reliability, pushing the boundaries of what autonomous flight can achieve in challenging and dynamic environments.