
The median in a triangle is a fundamental geometric concept, connecting a vertex to the midpoint of the opposite side. While seemingly a basic building block of Euclidean geometry, its underlying principles – specifically the identification of a central point or line of equilibrium – resonate deeply within the advanced technological landscape of drones and autonomous systems. Understanding the role of central tendencies and geometric balancing points, exemplified by the median and its intersection point, the centroid, is crucial for developing robust navigation, stabilization, and mapping capabilities in modern aerial platforms.
Geometric Foundations for Autonomous Systems
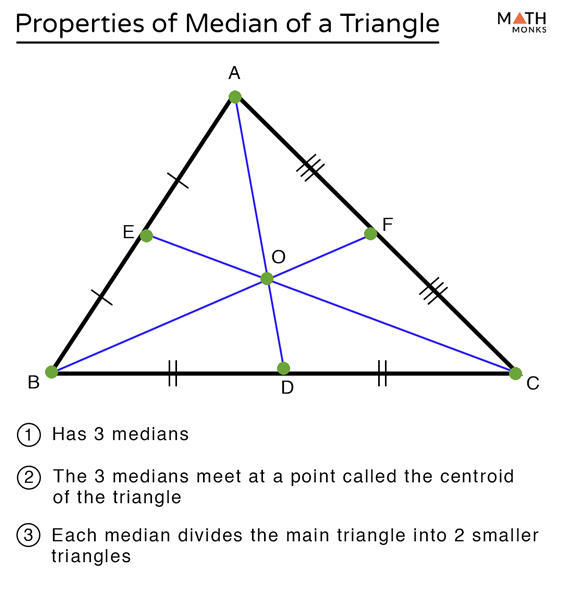
At its core, a median in a triangle represents a line of symmetry or balance in a specific sense. A triangle has three medians, and they famously intersect at a single point called the centroid. This centroid is significant because it represents the geometric center of the triangle, or more specifically, the center of mass if the triangle were a uniform, two-dimensional plate. This concept of a ‘center’ or ‘balance point’ is not confined to static shapes but is a critical idea that informs the design and operation of dynamic systems like drones.
The Concept of a Median and Centroid
To elaborate, consider a triangle ABC. A median from vertex A connects A to the midpoint of side BC. Similarly, medians from vertices B and C connect to the midpoints of sides AC and AB, respectively. These three medians always converge at the centroid (often denoted G). The centroid divides each median in a 2:1 ratio, with the longer segment being from the vertex to the centroid. Its coordinates are the average of the coordinates of the three vertices: G = ((xA+xB+xC)/3, (yA+yB+yC)/3). This mathematical elegance provides a powerful tool for locating a representative “average” or “balance point” within a triangular region.
The importance of the centroid extends beyond simple geometry. In physics, for a uniform triangular lamina, the centroid is precisely its center of gravity. This translates directly to engineering principles where understanding the center of mass is paramount for stability and control. For drones, especially in the realm of Tech & Innovation, these geometric insights are not merely theoretical curiosities but practical necessities.
Beyond Simple Triangles: Applying Central Tendencies in Drone Design
While drones aren’t typically shaped like flat triangles, the principles derived from the median and centroid are generalized and applied in various forms. The notion of finding a central, balanced, or representative point within a defined spatial region or data set is a recurring theme in drone technology. Whether it’s balancing the physical mass of the drone for stable flight, aggregating sensor data from a distributed network, or optimizing flight paths through complex environments, the underlying mathematical drive is to locate an optimal center. These “central points” are not always centroids of physical triangles but can be statistical medians, means, or geometric centroids of more complex polygons or 3D volumes defined by data points or operational parameters. The elegance of the median’s definition—connecting to a midpoint—underscores the importance of understanding bisecting lines and points of equal distribution in systems.
Medians in Drone Navigation and Mapping
The application of median-like concepts becomes particularly clear in autonomous navigation and sophisticated mapping operations. Drones equipped with advanced AI and sensors must interpret spatial data, define regions of interest, and make decisions based on optimized geometric parameters.
Optimal Sensor Placement and Data Aggregation
Consider a scenario where a drone’s sensor suite is designed to cover a specific area, or where multiple drones are deployed for collaborative mapping. If three critical points define a region of interest (e.g., targets for monitoring, boundaries of a survey area), the centroid of the triangle formed by these points often serves as an optimal location for a primary sensor, a data aggregation node, or a central waypoint for a survey mission. By placing resources at such a geometrically balanced point, data acquisition can be optimized, ensuring comprehensive coverage and minimizing redundancy. This is analogous to finding the ‘center’ of an operation, even if the “triangle” is conceptual, formed by the positions of other drones or critical data points.

Furthermore, in remote sensing, raw data often contains noise or outliers. Algorithms sometimes use median filtering, a non-linear digital filtering technique, which replaces each pixel’s value with the median of the pixel values in its neighborhood. While not directly about “a median in a triangle“, it speaks to the broader concept of using the median (a measure of central tendency) to derive robust information, which is a key aspect of advanced image processing for drone-collected data.
Path Planning and Centroidal Voronoi Tessellations
In autonomous flight, efficient path planning is paramount. Drones need to navigate complex 3D environments, avoiding obstacles while achieving mission objectives. Advanced algorithms for path planning, especially in multi-agent systems or for covering irregular areas, often leverage geometric partitioning techniques like Voronoi tessellations. A specific variant, Centroidal Voronoi Tessellations (CVT), is highly relevant. In a CVT, each Voronoi region has its generator point (the point to which all points in the region are closest) coinciding with the centroid of that region.
This concept is profoundly powerful for drone swarm management and area coverage. Imagine multiple drones tasked with monitoring a large area. By continuously adjusting their positions to become the centroids of their respective Voronoi cells, the drones can achieve optimal distribution and coverage, minimizing overlap and maximizing efficiency. Here, the “centroid” is the geometric average of all points within a specific sub-area, ensuring a balanced and uniform distribution, a direct extension of the principles embodied by the median in a simple triangle.
Stabilization and Balance: The Kinematics of Flight
The stability of any flying object, especially a nimble drone, hinges on its center of gravity. Misplaced weight or an unbalanced design can lead to instability, requiring more energy for corrective maneuvers and potentially causing flight failure.
Center of Gravity and Flight Stability
For drones, the physical center of gravity (CG) is the point where the entire weight of the drone appears to act. For stable flight, the drone’s design ensures that the CG is precisely located relative to its aerodynamic center and thrust vectors. If we conceptualize the drone’s major components (motors, battery, camera, flight controller) as points in space, their collective center of mass is the drone’s CG. Calculating this involves weighted averages, a direct analogue to how a centroid represents the average position of vertices or the center of mass for a uniform object. Engineers meticulously design the drone chassis and arrange components to place the CG in an optimal position, often aiming for a geometric “balance point” to ensure inherent stability. This critical balance directly minimizes the energy required for stabilization by the flight controller and contributes to smooth, predictable flight characteristics, especially important for precision tasks or aerial filmmaking.
Future Innovations: Leveraging Geometric Principles
As drone technology evolves, the integration of complex geometric and mathematical principles will only deepen. From swarm intelligence to hyper-precise remote sensing, understanding spatial relationships and optimal points of reference will remain at the forefront of innovation.

Advanced Algorithms for Swarm Robotics and Collaborative Mapping
In the future of drone technology, swarm robotics will play a significant role. Imagine hundreds or thousands of drones autonomously coordinating to perform tasks. Efficient coordination in a swarm relies heavily on understanding spatial relationships and maintaining relative positions. Algorithms for swarm formation, collision avoidance, and collective decision-making frequently utilize concepts similar to the centroid. Drones might dynamically calculate the ‘center of the swarm’ (a collective centroid) and adjust their positions relative to it, or a leader drone might position itself at the centroid of a dynamically changing operational area.
For collaborative mapping, multiple drones combine their sensor data to create highly detailed maps. Identifying optimal “sampling centroids” within smaller triangular or polygonal sub-regions helps ensure comprehensive data collection without redundancy. Furthermore, in areas with sparse data points, interpolation techniques often rely on geometric proximity and “average” values, again drawing from the spirit of central tendency that the median and centroid exemplify. The future of autonomous systems is intrinsically linked to sophisticated geometric understanding, transforming abstract mathematical concepts into tangible flight capabilities and operational efficiencies.