
In the rapidly evolving landscape of unmanned aerial systems (UAS), the term “mainframe” might evoke images of colossal, vintage computers from a bygone era. However, in the context of modern “Tech & Innovation” surrounding drones, the concept of a mainframe has transformed. It no longer strictly refers to a single, monolithic piece of hardware, but rather embodies the robust, centralized, and often distributed computational infrastructure that powers the most sophisticated drone capabilities, from intelligent flight modes to massive-scale data processing. It is the unseen, high-performance computing backbone that enables the advanced functions we now take for granted in autonomous flight, remote sensing, and AI-driven aerial operations.

The Computational Core of Advanced Drone Operations
Modern drones are far more than just flying cameras; they are sophisticated robotic platforms capable of complex tasks. This sophistication demands immense processing power, not just onboard the drone, but also in supporting ground systems, cloud platforms, and data centers. The “mainframe” in this contemporary sense represents these powerful computing environments designed to handle the critical, large-scale, and often real-time computational demands generated by advanced drone ecosystems. Without such a robust core, features like AI follow mode, truly autonomous flight, and detailed geospatial mapping would be either impossible or severely limited in their scope and accuracy. This computational core ensures the reliability, scalability, and performance necessary for next-generation aerial technology.
Powering AI Follow Mode and Autonomous Flight
The seemingly effortless execution of an AI Follow Mode, where a drone intelligently tracks a subject, or the precision of fully autonomous flight plans, belies a staggering amount of real-time data processing. For AI follow mode, the “mainframe” comes into play by providing the advanced machine learning models and computational horsepower for object recognition, predictive tracking algorithms, and dynamic path adjustments. While some initial processing occurs on the drone’s edge computing unit, the continuous refinement of AI models, complex environmental analysis, and the synthesis of multiple data streams often rely on more powerful, server-side “mainframe” resources. These backend systems process vast libraries of visual and sensor data to train and optimize the AI, allowing the drone to make intelligent decisions in dynamic environments.
Autonomous flight systems represent an even greater computational challenge. Beyond basic waypoint navigation, true autonomy involves real-time obstacle avoidance, dynamic route optimization based on changing conditions, simultaneous localization and mapping (SLAM), and even collaborative multi-drone operations. Each of these functions generates and consumes incredible volumes of data. The “mainframe” here acts as a central nervous system, processing sensor fusion from LiDAR, radar, cameras, and GPS, running complex probabilistic algorithms to build and maintain an accurate understanding of the environment, and executing sophisticated control logic. This often involves cloud-based computing architectures that serve as distributed mainframes, providing on-demand scalability and access to high-performance GPUs and CPUs to crunch numbers far beyond the capacity of an onboard flight controller. These systems can simulate millions of flight scenarios, analyze potential risks, and pre-compute optimal flight paths, pushing updates and intelligence to the drones in the field.
Data Processing for Mapping and Remote Sensing
The utility of drones in mapping, surveying, and remote sensing applications has revolutionized industries from agriculture to construction. However, the raw data collected by these drones—gigabytes, often terabytes, of high-resolution imagery, LiDAR point clouds, and multispectral data—is virtually unusable in its raw form. This is where the modern “mainframe” concept becomes indispensable.
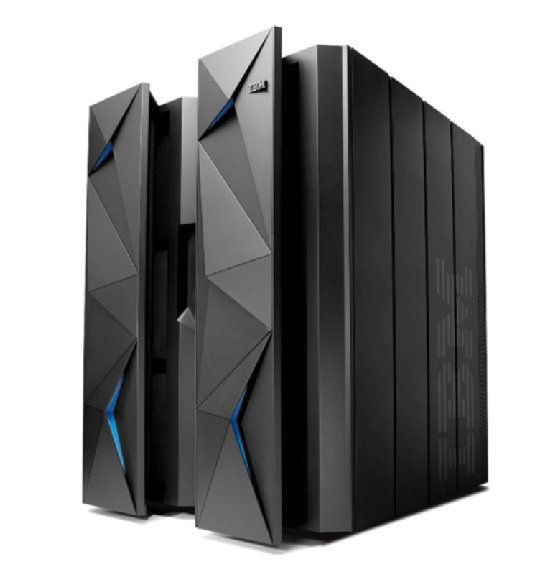
Processing these massive datasets into actionable intelligence requires extraordinary computational resources. Photogrammetry software, for instance, must stitch thousands of overlapping images, correct for distortions, generate dense point clouds, create digital elevation models (DEMs), and ultimately render highly accurate 2D maps and 3D models. LiDAR data similarly demands powerful processing to classify points, remove noise, and create precise topographical maps or volumetric analyses. Multispectral and hyperspectral data, used for crop health analysis or environmental monitoring, requires complex spectral unmixing and index calculations.
These tasks are computationally intensive, often involving parallel processing and specialized hardware accelerators. Cloud-based “mainframes” provide the necessary scalability, allowing users to upload vast quantities of raw drone data for automated processing. These platforms act as a central processing hub, orchestrating powerful virtual machines and distributed computing frameworks to transform raw sensor outputs into precise, georeferenced, and insightful deliverables. Without such high-performance backends, the time and cost associated with processing this data manually or on less capable systems would render many drone-based mapping and sensing projects impractical.
Ensuring Reliability and Scalability in Drone Ecosystems
One of the defining characteristics of traditional mainframes was their unparalleled reliability, availability, and serviceability (RAS). In the context of modern drone operations, especially those involving critical infrastructure inspection, logistics, or public safety, these attributes remain paramount. The “mainframe” concept, whether realized through a single powerful server or a distributed cloud architecture, must provide the bedrock of dependability for drone ecosystems.
Reliability translates to continuous uptime for mission-critical applications. If a drone delivery service relies on a central system for route optimization and fleet management, that system cannot afford downtime. Modern “mainframes” achieve this through redundancy, automatic failover mechanisms, and robust data integrity checks. Data generated by drones—whether flight logs, sensor readings, or operational parameters—is invaluable. Secure storage, robust backup systems, and efficient data recovery protocols, all hallmarks of a mainframe-like approach, are essential to protect this information and ensure operational continuity.
Scalability is equally vital. As drone fleets grow and the volume of data they generate expands exponentially, the underlying computational infrastructure must be able to adapt without significant overhaul or performance degradation. A scalable “mainframe” can dynamically allocate resources to handle peak loads, support a growing number of simultaneous drone operations, and process increasing quantities of sensor data. This elasticity, often provided by cloud computing models, allows businesses and organizations to expand their drone programs confidently, knowing that the computational backend can keep pace with their evolving needs.
The Future: Distributed Mainframes and Edge Computing
The evolution of the “mainframe” in drone technology is moving towards a sophisticated hybrid model, blending the power of centralized, cloud-based processing with the agility of edge computing. While the centralized “mainframe” handles heavy analytical tasks, AI model training, and long-term data storage, edge computing brings processing power closer to the source—the drone itself.
Edge devices, like powerful onboard processors and dedicated AI chips, enable drones to perform immediate, real-time computations such as local obstacle detection, basic object recognition, and immediate decision-making without constant reliance on a remote server. This reduces latency, improves responsiveness, and allows for operations in areas with limited connectivity.
However, the “distributed mainframe” or cloud infrastructure still plays a crucial role. It acts as the orchestrator, managing fleets, optimizing flight paths across multiple drones, processing large-scale mapping projects, and continuously updating the AI models that empower the edge devices. The intelligence gathered by individual drones is sent back to the central “mainframe” for aggregation, analysis, and refinement, leading to improved algorithms and more intelligent future operations. This creates a powerful feedback loop where localized intelligence from the edge informs and enhances the global intelligence of the mainframe, driving continuous innovation in autonomous flight, remote sensing, and all aspects of advanced drone technology.