
The Fundamental Nature of Magnetic Moment
At the heart of many advanced flight technologies, particularly in the realm of unmanned aerial vehicles (UAVs), lies a deep understanding of fundamental physical phenomena. One such concept, critical for precise navigation and stabilization, is the magnetic moment. Often described as the measure of an object’s tendency to align with an external magnetic field, a magnetic moment is an intrinsic property possessed by various entities, from subatomic particles to macroscopic magnets and even current-carrying loops. It quantifies the strength and orientation of a magnetic source.
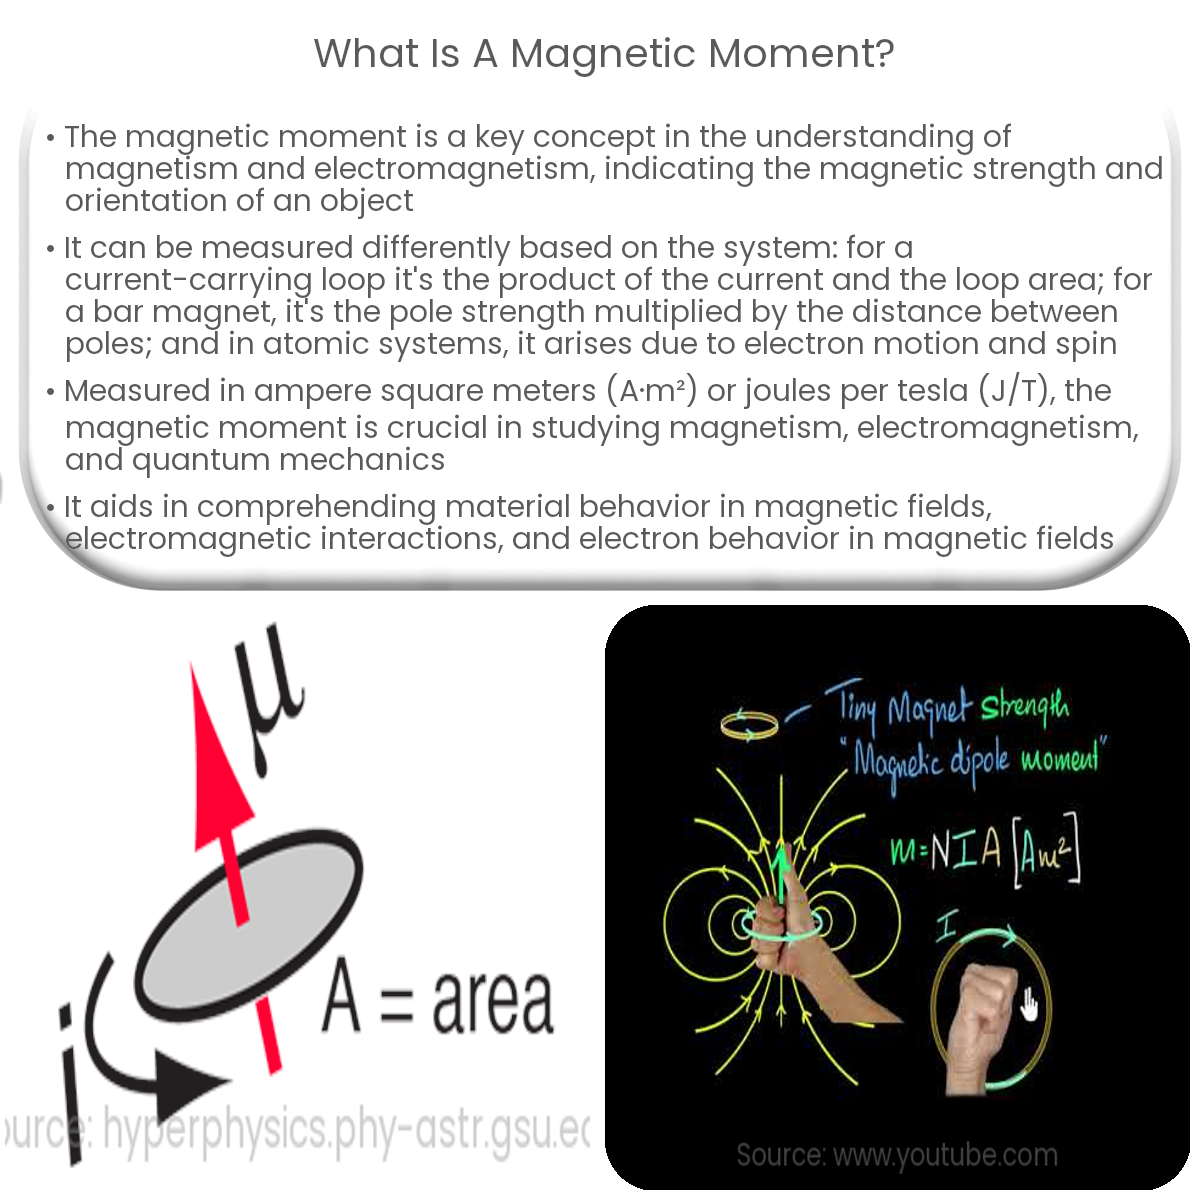
Imagine a tiny bar magnet. It has a north pole and a south pole, and it naturally aligns itself with the Earth’s magnetic field, pointing approximately north. The magnetic moment of this bar magnet is a vector quantity that points from its south pole to its north pole, with its magnitude representing the strength of the magnetic field it produces or its susceptibility to an external field. This inherent property dictates how a material or system responds to magnetic forces, forming the bedrock for technologies that leverage magnetism.

Defining Magnetic Dipole Moment
More formally, a magnetic moment is often referred to as a magnetic dipole moment, as it effectively describes the behavior of a magnetic dipole – the simplest magnetic source with two poles. For a current loop, the magnitude of the magnetic moment is the product of the current flowing through the loop and the area enclosed by the loop, with its direction determined by the right-hand rule (perpendicular to the loop’s plane). For fundamental particles like electrons, the magnetic moment arises from their intrinsic spin and orbital angular momentum, a quantum mechanical phenomenon that gives rise to the magnetism observed in materials.
In the context of drone flight, while we are not directly measuring the magnetic moment of individual electrons, we are measuring the cumulative effect of these moments creating macroscopic magnetic fields, such as the Earth’s geomagnetic field, and how the drone’s sensors interpret them. Understanding the source and behavior of magnetic moments is crucial for developing robust navigation systems that rely on these magnetic interactions.
Origins in Quantum Mechanics
While the practical application for drone flight technology focuses on macroscopic manifestations, the fundamental origin of magnetic moments traces back to quantum mechanics. Electrons, protons, and neutrons all possess intrinsic magnetic moments due due to their spin. The orbital motion of electrons around atomic nuclei also generates magnetic moments. These microscopic moments, when aggregated and aligned within a material, give rise to macroscopic magnetism. For ferromagnetic materials used in electronic components, these aligned magnetic moments can create significant localized magnetic fields, which become a source of interference for sensitive navigation sensors on a drone. Conversely, the Earth itself acts as a massive magnet, generating a global magnetic field due to the movement of molten iron in its outer core, providing a natural reference frame for drone navigation.
Measurement and Detection in Flight Systems
The ability to detect and measure magnetic fields, and by extension, understand the local magnetic environment, is paramount for modern flight technology. Drones, in particular, rely heavily on this capability for accurate navigation and attitude estimation.
Magnetometers: The Drone’s Compass
The primary sensor responsible for detecting magnetic fields on a drone is the magnetometer. Often integrated into a drone’s Inertial Measurement Unit (IMU) alongside accelerometers and gyroscopes, the magnetometer acts as the drone’s digital compass. It measures the strength and direction of the local magnetic field along three orthogonal axes (X, Y, Z). By measuring these components, the drone’s flight controller can determine its orientation relative to the Earth’s magnetic north, providing a crucial heading reference.
Without a magnetometer, a drone would struggle to maintain a consistent heading or navigate accurately in GPS-denied environments. While GPS provides global position, it doesn’t directly provide orientation. Gyroscopes track angular velocity, but they are prone to drift over time. The magnetometer offers a stable, long-term reference for yaw (heading) that corrects the drift accumulated by the gyroscopes, forming a vital part of sensor fusion algorithms.
How Magnetometers Sense Magnetic Fields

Magnetometers operate on various principles, but common types in drones include Hall-effect sensors or magnetoresistive sensors. Hall-effect sensors produce a voltage proportional to the magnetic field passing perpendicularly through them. Magnetoresistive sensors change their electrical resistance in the presence of a magnetic field. Regardless of the specific mechanism, the core function remains the same: convert the magnetic field strength and direction into an electrical signal that the drone’s flight controller can process.
These sensors are incredibly sensitive, capable of detecting minute changes in magnetic fields. This sensitivity is a double-edged sword: it allows for precise heading determination, but also makes them susceptible to interference from other magnetic sources. Every electronic component, motor, and power cable on the drone generates its own small magnetic field (its own magnetic moment, in a sense) when current flows through it. These internal fields can easily overwhelm or distort the Earth’s relatively weak magnetic field, leading to incorrect heading readings.
Magnetic Moment’s Crucial Role in Drone Flight Technology
The practical application of understanding magnetic moments within flight technology extends far beyond simple compass readings. It is integral to sophisticated navigation, robust stabilization, and reliable autonomous operations.
Enhancing Navigation and Orientation
In drone navigation, magnetometers are indispensable for providing absolute heading information. While accelerometers and gyroscopes can provide short-term relative orientation (how much the drone has rotated from its last known position), they suffer from cumulative error, known as “drift.” Gyroscopes, for instance, cannot distinguish between actual rotation and bias errors over time. This drift means that without a stable external reference, a drone would quickly lose its sense of direction.
The Earth’s magnetic field acts as that stable external reference. By continually measuring the geomagnetic field, the magnetometer helps to correct the yaw drift from the gyroscopes, providing a consistent and reliable direction. This sensor fusion, combining data from accelerometers, gyroscopes, and magnetometers (and often GPS), is processed by Kalman filters or similar algorithms to generate highly accurate and robust estimates of the drone’s attitude (pitch, roll, and yaw) and position. Without this magnetic reference, precision flight maneuvers, waypoint navigation, and maintaining a stable camera perspective would be significantly more challenging, if not impossible.
Mitigating Magnetic Interference
One of the significant challenges in integrating magnetometers into drone flight systems is managing magnetic interference. As mentioned, the drone itself is a source of magnetic fields. Motors, ESCs (Electronic Speed Controllers), power distribution boards, and even battery current flows create their own varying magnetic moments. These “soft iron” and “hard iron” distortions can severely corrupt magnetometer readings, leading to an inaccurate heading.
“Hard iron” interference refers to permanent magnetic fields generated by magnetized components (like magnets in motors or speakers) or currents that flow consistently in one direction. “Soft iron” interference refers to temporary distortions of an external magnetic field by permeable materials (like steel screws or chassis components) that concentrate or deflect magnetic field lines.
Flight technology engineers employ several strategies to mitigate this:
- Placement: Magnetometers are often placed as far as possible from known sources of interference, such as on an external mast or boom.
- Shielding: While difficult for low-frequency magnetic fields, some shielding can be employed.
- Compensation Algorithms: Sophisticated software algorithms run calibration routines that map the drone’s internal magnetic interference. During calibration, the drone is typically rotated through all axes to allow the magnetometer to record the varying interference patterns. This data is then used to create a compensation model that subtracts the drone’s own magnetic signature from the raw magnetometer readings, leaving a cleaner measurement of the Earth’s field.
Calibration for Precision
Calibration is not a one-time event; it’s a recurring necessity to ensure the accuracy of the magnetometer. Environmental magnetic anomalies (e.g., large metal structures, power lines) and even changes in the drone’s own magnetic field over time (due to component wear, temperature changes, or adding/removing accessories) can necessitate re-calibration. Modern flight controllers often include built-in calibration routines that guide the user through specific drone movements (e.g., rotating the drone slowly around its axes) to collect the necessary data for compensation. Proper calibration ensures that the drone’s internal magnetic moments do not unduly influence its perception of the Earth’s magnetic field, leading to precise and reliable navigation.
Beyond Navigation: Future Implications
While the primary role of magnetic moments and their detection in drones today is centered on navigation and stabilization, the deeper understanding of magnetism continues to inspire future innovations in flight technology. Research areas include more advanced magnetic field mapping for specific environmental awareness, potentially using arrays of magnetometers for more precise localization in complex urban or indoor environments where GPS is unreliable. Furthermore, the principles of magnetic fields could be explored for novel propulsion systems or even for manipulating drone components with greater precision. As drone technology evolves, the fundamental principles governing magnetic moments will undoubtedly remain a cornerstone of progress.