
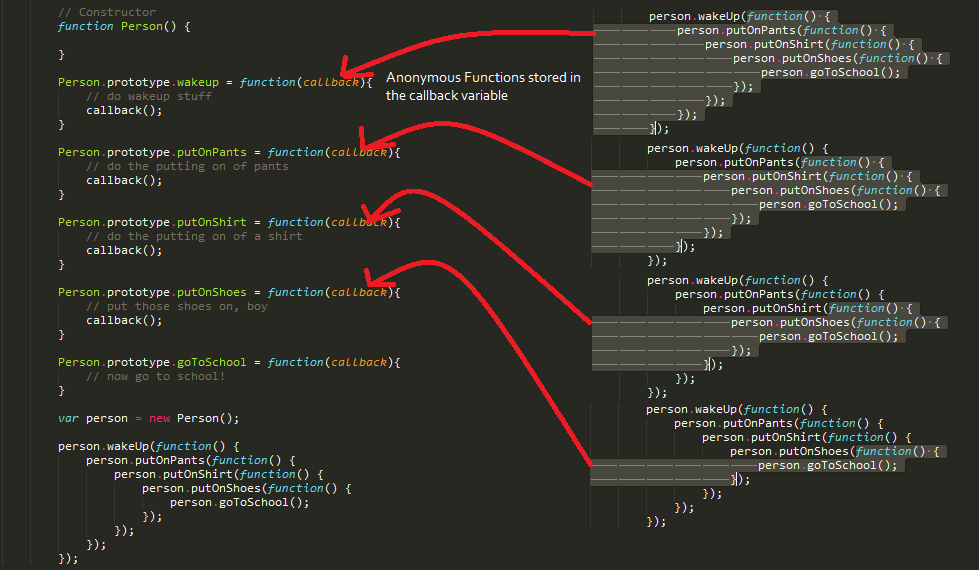
In the intricate and rapidly evolving landscape of drone technology, particularly within the realm of Tech & Innovation, software architecture plays a foundational role in enabling features like autonomous flight, AI-powered follow modes, advanced mapping, and sophisticated remote sensing. Central to building such responsive, efficient, and modular systems is a fundamental programming concept: the callback function. At its core, a callback function is a piece of executable code that is passed as an argument to another function, intended to be executed at a later time or when a specific event occurs. Unlike a typical function call where execution is immediate and sequential, a callback defers its invocation, allowing for non-blocking operations and event-driven paradigms crucial for real-time drone control and data processing.

Imagine a drone’s flight controller, constantly monitoring various sensors: accelerometers, gyroscopes, GPS, and obstacle detection lidar. If the main flight control loop had to poll each sensor continuously and process its data synchronously, it would become inefficient and potentially unresponsive, especially in critical situations requiring immediate action. This is where callback functions shine. Instead of polling, a sensor’s data acquisition module can be set up to call back a predefined function once new data is available or a threshold is met. This asynchronous nature ensures that the drone’s primary flight operations remain uninterrupted while specific events are handled by dedicated, timely responses, making the system significantly more robust and agile.
The Core Concept: Event-Driven Programming in Drone Systems
The architecture of modern drone software is heavily influenced by event-driven programming, a paradigm where the flow of execution is determined by events such as sensor inputs, user interactions, or system messages. Callback functions are the cornerstone of this paradigm, allowing different components of a drone’s software to communicate and react to changes without tight coupling.
Decoupling and Flexibility in Flight Control
In a sophisticated drone system, various subsystems operate somewhat independently yet need to interact. The navigation system calculates flight paths, the stabilization system maintains attitude, and the payload system manages cameras or other sensors. If these systems were tightly coupled, a change in one could necessitate changes across multiple others, making development and maintenance complex. Callback functions facilitate loose coupling. For instance, the stabilization system might offer a callback mechanism where, upon detecting an abnormal tilt, it triggers a registered function in the safety system to initiate an emergency landing sequence. This modularity means that the stabilization system doesn’t need to know the specifics of the emergency landing, only that it needs to notify something when a critical event occurs. This separation of concerns is vital for managing the complexity of drone software, allowing for flexible updates and integration of new features.
Asynchronous Operations: Sensors and Data Streams
Drone operations are inherently asynchronous. GPS modules output location data at a certain frequency, an obstacle avoidance sensor might send warnings only when an object is detected within a specified range, and the remote controller transmits commands whenever a pilot moves a stick. Waiting synchronously for each of these events would stall the entire system. Instead, the main flight controller can register callback functions for each type of input. When new GPS coordinates arrive, the registered update_position callback is invoked. When a critical obstacle proximity alert is received, the trigger_avoidance_maneuver callback is executed. This allows the drone to process multiple inputs concurrently without blocking the main execution thread, leading to more responsive control and safer operation. High-throughput data streams, like those from thermal cameras or LiDAR sensors used in mapping, particularly benefit from callbacks. Instead of waiting for an entire dataset to accumulate before processing, chunks of data can trigger callbacks for incremental processing, reducing latency and improving real-time analysis capabilities.
Callback Functions in Autonomous Navigation and AI
The cutting edge of drone technology, particularly in autonomous navigation and AI-driven features, relies extensively on sophisticated event handling mechanisms powered by callback functions. These mechanisms enable drones to react intelligently and instantly to their dynamic environments.
Obstacle Detection and Avoidance Triggers
Autonomous drones must navigate complex environments, avoiding static and dynamic obstacles. This capability is almost entirely built upon callback functions. An obstacle detection sensor (e.g., ultrasonic, lidar, stereo vision) constantly scans the environment. When it detects an object violating predefined safety parameters, it doesn’t halt the entire system. Instead, it triggers a callback function, perhaps named onObstacleDetected(). This callback then initiates the drone’s avoidance algorithms: calculating a new trajectory, hovering, or ascending. The beauty here is that the main navigation loop can continue executing, while the specific onObstacleDetected() function is executed only when truly needed, ensuring timely and efficient response without wasting processing power on constant polling.
AI Follow Mode and Subject Tracking
AI-powered follow modes are a prime example of callback functions in action. When a drone is tasked with following a subject, its computer vision system continuously processes video frames to identify and track the target. As the subject moves, its position relative to the drone changes. Instead of a rigid, predefined script, the tracking algorithm employs callback functions. When the vision system detects a significant shift in the subject’s position, it triggers a repositionDrone() callback. This function, in turn, calculates the necessary adjustments to the drone’s attitude, velocity, and altitude to maintain the desired distance and angle from the subject. This event-driven approach allows for fluid, real-time adjustments, making the follow mode remarkably natural and responsive, even as the subject’s movement becomes erratic.
Path Planning and Dynamic Adjustments
In complex autonomous missions like package delivery or infrastructure inspection, drones follow meticulously planned paths. However, real-world conditions are rarely static. Weather changes, unexpected obstacles appear, or the mission objective might be updated mid-flight. Callback functions enable dynamic path adjustments. For instance, a weather monitoring module might have a callback onWindGustDetected() that, when triggered, informs the path planning system to re-evaluate the current trajectory for stability. Similarly, if a new high-priority target is identified during a search and rescue mission, a rerouteMission() callback can be invoked, prompting the drone to immediately prioritize the new objective and calculate an optimal path to it. This adaptability, facilitated by callbacks, makes autonomous operations robust and resilient to unforeseen circumstances.
Enhancing Remote Sensing and Mapping Efficiency
Remote sensing and mapping missions demand high data throughput and precise coordination between hardware and software. Callback functions significantly enhance the efficiency and responsiveness of these operations, from data acquisition to user interaction.
Real-time Data Processing and Image Stitching
Drones equipped with high-resolution cameras or specialized sensors generate vast amounts of data. For applications like real-time mapping or agricultural analysis, this data needs to be processed as quickly as possible. Instead of waiting for an entire mission’s worth of images to be captured before beginning post-processing, callback functions can enable incremental processing. As each image frame is captured, a processImage() callback can be triggered. This function might initiate tasks such as geotagging, initial color correction, or even partial stitching. For large-scale mapping, where individual images need to be precisely aligned and stitched into a seamless mosaic, callbacks can notify the stitching engine as soon as a new batch of overlapping images is available, allowing it to start processing without delay. This concurrent processing significantly reduces the overall time from data capture to usable map products.
User Interface Responsiveness in Ground Control Stations
The ground control station (GCS) is the primary interface for pilots and operators to interact with the drone. A responsive GCS is critical for effective mission planning, monitoring, and intervention. Callback functions are extensively used in GCS software to handle user input and display real-time drone telemetry. When an operator clicks a button to upload a new flight plan, a uploadFlightPlan() callback is executed. When the drone sends updated telemetry data (e.g., battery level, altitude, speed), an updateTelemetryDisplay() callback refreshes the corresponding UI elements. This event-driven architecture ensures that the GCS remains fluid and responsive, providing immediate feedback to the operator and accurately reflecting the drone’s status without the interface freezing or lagging due to intensive background operations.
Implementing Callbacks: Design Patterns and Best Practices
While the concept of callback functions is straightforward, their effective implementation in complex drone systems requires adherence to certain design patterns and best practices to ensure robustness, maintainability, and performance.
Event Listeners and Publishers
A common design pattern for implementing callbacks is the “Observer” pattern, often realized through event listeners and publishers. In this model, an “event publisher” (e.g., a sensor module, the flight controller) emits events, and multiple “event listeners” (functions or objects) can register their interest in these events by providing a callback function. When an event occurs, the publisher iterates through its registered listeners and invokes their respective callback functions. For example, a “battery monitoring” module (publisher) might emit a “low battery” event. Multiple modules—the GCS display, an emergency landing system, and a mission planner—could register callbacks to react to this event, ensuring coordinated responses without the publisher needing explicit knowledge of all its dependents.
Error Handling and Robustness
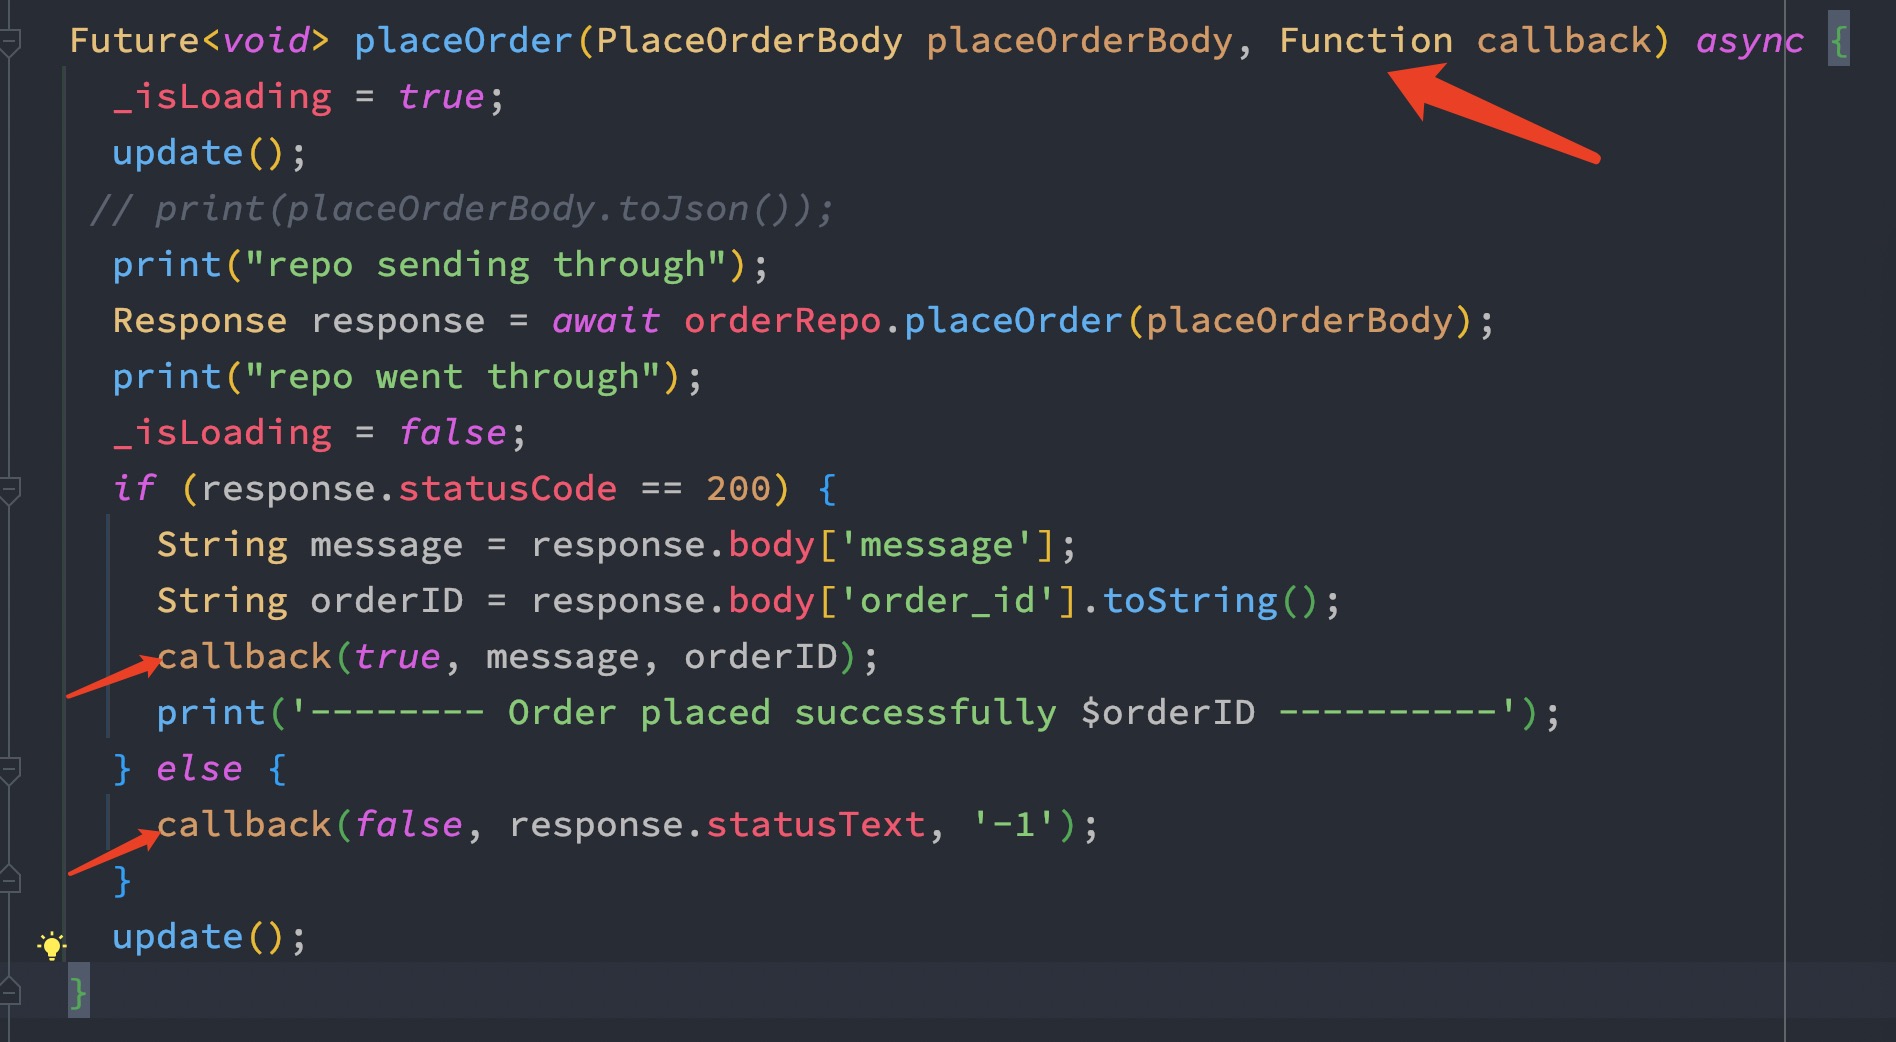
In real-time, mission-critical systems like drones, robust error handling is paramount. When using callback functions, it’s crucial to consider how errors within a callback are managed. An unhandled exception in one callback could potentially destabilize the entire system. Implementations often include mechanisms to safely catch exceptions within callbacks, log errors, and notify relevant system components. Furthermore, it’s good practice to provide callbacks with enough context to perform their task correctly, including error codes or status messages if an underlying operation fails. This ensures that the system can degrade gracefully or take corrective action rather than crashing.
Performance Considerations in Embedded Systems
Drones are embedded systems with finite processing power and memory. While callbacks enhance responsiveness, poorly implemented callbacks can introduce performance bottlenecks. Executing overly complex or long-running operations within a callback function can block the main event loop or tie up critical resources, defeating the purpose of asynchronous processing. Best practices dictate that callback functions should be lean and execute quickly. If a callback needs to perform intensive computation, it should ideally offload that work to a separate thread or a dedicated background process, signaling its completion via another callback, thus maintaining the responsiveness of the main system.
The Future of Drone Autonomy with Advanced Callback Architectures
As drone technology continues to push the boundaries of autonomy, AI integration, and complex environmental interaction, the sophistication of callback architectures will only grow. Future drone systems will likely feature more granular event types, more intelligent filtering of events, and dynamic registration/deregistration of callbacks based on mission context or real-time conditions. Imagine a drone that dynamically loads and unloads specialized callback functions for different stages of a complex mission (e.g., inspection callbacks during a survey phase, then delivery callbacks during a payload drop phase). This dynamic flexibility, built upon the fundamental utility of callback functions, will be instrumental in developing drones that are not just autonomous, but truly adaptive, intelligent, and capable of operating in increasingly complex and unpredictable environments, defining the next generation of Tech & Innovation in aerial robotics.