
The question “what is -76/3 equal to” might initially seem like a straightforward arithmetic problem, divorced from the technical intricacies of aerial robotics. However, within the context of advanced drone operations, particularly those involving complex navigation, autonomous flight planning, and precise data acquisition, understanding numerical relationships, even seemingly negative ones, is foundational. This exploration delves into the mathematical resolution of -76/3 and then extrapolates its relevance to the sophisticated technological landscape of modern drones, encompassing navigation, sensor data processing, and autonomous system development.
The Arithmetic Foundation: Deciphering -76/3
At its core, the expression -76/3 represents a division operation where a negative number (-76) is divided by a positive number (3). The result of dividing a negative number by a positive number is always negative.
The Calculation Process
To arrive at the numerical value, we perform the division:
$76 div 3$
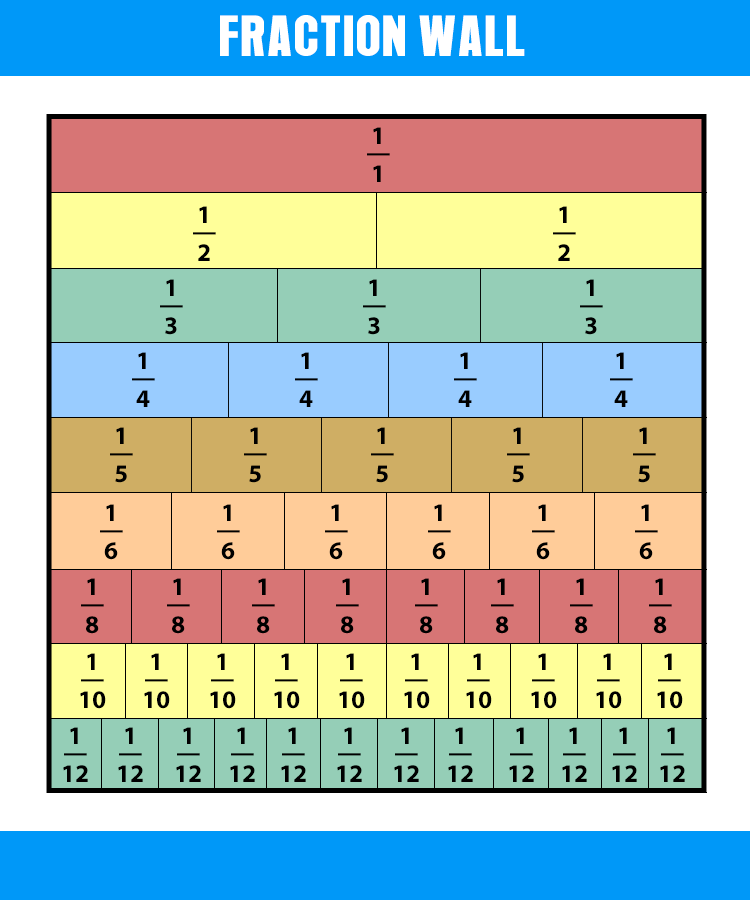
This division does not yield a whole number, indicating that 76 is not perfectly divisible by 3. We can express the result as either a mixed number, an improper fraction, or a decimal approximation.
Expressing as a Mixed Number
First, we find out how many times 3 goes into 76.
$76 div 3 = 25$ with a remainder.
To find the remainder:
$3 times 25 = 75$
$76 – 75 = 1$
So, 76 divided by 3 is 25 with a remainder of 1. As a mixed number, this would be $25 frac{1}{3}$.
Since our original number was negative (-76), the mixed number representation is $-25 frac{1}{3}$.
Expressing as an Improper Fraction
The expression -76/3 is already an improper fraction because the absolute value of the numerator (76) is greater than the denominator (3). The negative sign can be placed before the fraction, before the numerator, or before the denominator; the value remains the same:
$-frac{76}{3}$
or
$frac{-76}{3}$
or
$frac{76}{-3}$ (though this is less conventional for positive denominators).
Expressing as a Decimal
To express -76/3 as a decimal, we perform the division $76 div 3$.
$76 div 3 approx 25.333…$
The ‘3’ repeats infinitely. This is a recurring decimal.
Therefore, $-76 div 3 = -25.333…$ or $-25.overline{3}$.
So, -76/3 is equal to $-25 frac{1}{3}$ or approximately -25.333.
Relevance to Drone Navigation and Sensor Data
While the abstract value of -76/3 itself might not directly appear in a drone’s operational parameters, the principles of precise numerical representation, dealing with negative values, and understanding fractional quantities are fundamental to several core drone technologies.
Coordinate Systems and Vector Representation
Drones operate within three-dimensional coordinate systems (X, Y, Z axes) to define their position, orientation, and trajectory. These coordinates can often be negative. For instance, if a drone’s home point is designated as the origin (0,0,0), any position west of the home point might be represented by a negative X-coordinate, any position south by a negative Y-coordinate, and any position below the takeoff point by a negative Z-coordinate.
Positional Data
When a drone’s GPS or inertial navigation system reports its position, these values are inherently tied to a reference frame. If the drone deviates significantly from its home point or navigates in directions designated as “negative” within that frame, negative numerical values will be encountered. For example, a waypoint coordinate might be X=-15.2 meters, Y=-30.5 meters, Z=-5.0 meters. The processing of these coordinates involves precise arithmetic, including dealing with negative magnitudes.
Velocity and Acceleration Vectors

Similarly, velocity and acceleration are vector quantities that have both magnitude and direction. In the drone’s internal flight control system, these are represented using components along the X, Y, and Z axes. A negative component along an axis indicates movement or acceleration in the opposite direction of that axis’s positive definition. For instance, a negative X-velocity component means the drone is moving westward if positive X is eastward. Understanding the precise numerical values of these components is crucial for calculating future positions and ensuring stable flight.
Sensor Data Processing and Calibration
Drones are equipped with a multitude of sensors – IMUs (Inertial Measurement Units), barometers, magnetometers, and external sensors like LiDAR or cameras. These sensors generate raw data that must be processed, filtered, and interpreted.
IMU Data Interpretation
An IMU measures angular rate and specific force (acceleration). Its output often includes raw accelerometer and gyroscope readings. These readings, when translated into meaningful physical quantities, can be positive or negative, representing acceleration in different directions or rotation rates. For example, a negative accelerometer reading along the Z-axis would indicate deceleration or an upward force being applied to the drone. The integration of these readings over time to estimate velocity and position requires careful handling of all numerical values, including negatives.
Calibration and Error Correction
Sensor calibration is a critical process that involves removing biases and scaling errors. This process often involves mathematical models and algorithms that adjust raw sensor readings. These adjustments can sometimes result in negative offsets or scaling factors that are applied to the data. Ensuring that these calculations are performed accurately, even when dealing with potential negative outcomes, is vital for maintaining the drone’s operational integrity. The concept of a “negative error” might arise, indicating that the sensor is consistently reading higher than the true value.
Implications for Autonomous Flight and Mission Planning
The precision and accuracy demanded by autonomous flight and sophisticated mission planning are heavily reliant on robust mathematical models and accurate numerical computations.
Trajectory Optimization and Pathfinding
Autonomous drones must plot efficient and safe trajectories through complex environments. This involves pathfinding algorithms that consider obstacles, predefined flight envelopes, and energy efficiency. The mathematical representations of these paths often involve functions and algorithms that can produce negative values as intermediate steps or as part of defining boundaries.
Obstacle Avoidance Algorithms
When a drone detects an obstacle, its control system must calculate a new path to avoid collision. This might involve determining the shortest path around an object, which could involve navigating through regions defined by negative coordinates relative to the drone’s current heading or reference frame. The calculation of avoidance vectors and new waypoint sequences relies on precise arithmetic operations.
Mission Parameters and Constraints
Many drone missions are defined by specific parameters and constraints. These can include flight altitudes, speed limits, and operational zones. Sometimes, these parameters might be defined in relation to a mission origin, leading to the necessity of understanding negative coordinate values for defining exclusion zones or negative altitudes for descents below a reference plane. For example, a mission might specify a “negative altitude” constraint for operations in a canyon or ravine.
Data Analysis and Interpretation in Tech & Innovation
In sectors like remote sensing, mapping, and environmental monitoring, drones collect vast amounts of data. The analysis and interpretation of this data often involve sophisticated algorithms that work with numerical values, including those that can be negative.
Remote Sensing Data
Thermal imaging, for instance, measures infrared radiation, which corresponds to temperature. While most objects have positive temperatures, some scientific contexts might involve reference points or differences that can lead to negative values when calculating temperature differentials or anomalies relative to a baseline. Spectroscopy, another remote sensing technique, can also yield data that requires interpretation of negative spectral responses in certain bands, indicating absorption or other phenomena.
AI and Machine Learning Integration
The integration of AI and machine learning into drone operations for tasks like object recognition, anomaly detection, or predictive maintenance involves training models on large datasets. These datasets often contain numerical features, and the mathematical operations within these AI models, including weight adjustments and activation functions, frequently involve negative numbers. Understanding how a model processes negative inputs or produces negative outputs is key to its effective deployment.
Conclusion: The Ubiquity of Mathematical Principles
In conclusion, while the direct calculation of -76/3 might seem like a purely academic exercise, its underlying mathematical principles – the nature of negative numbers, division, and the representation of quantities – are deeply embedded in the sophisticated technologies that power modern drones. From the precise navigation required for autonomous flight to the intricate processing of sensor data and the development of advanced AI capabilities, a solid understanding of mathematical concepts, including those involving negative values, is indispensable for innovation and reliable operation in the dynamic field of aerial technology. The ability to accurately compute and interpret values like -76/3, and their conceptual equivalents in flight dynamics and data analysis, forms a crucial part of the technological foundation upon which the future of drone applications is built.