
The Metaphorical “Lung Collapse” in Flight Technology
In the intricate world of unmanned aerial vehicles (UAVs) and advanced flight systems, the concept of a “collapsed lung” serves as a powerful metaphor for a critical system failure. Just as a lung is vital for respiration and life support in an organism, certain core components and functionalities are indispensable for stable, controlled, and autonomous flight. When these critical systems experience a sudden and severe malfunction—a “collapse”—the consequences can be catastrophic, leading to a loss of control, mission failure, or even a crash. Understanding these vulnerabilities and their immediate impact is paramount for engineers, operators, and regulatory bodies striving for safer and more reliable flight.

Understanding Critical System Vulnerabilities
Every advanced flight system is a complex interplay of hardware, software, and sensors, all working in concert to achieve a specific objective. At its core, a UAV relies on several “vital organs”: a flight controller (the brain), navigation systems (the inner ear and eyes), power distribution (the circulatory system), and propulsion (the muscles). A “collapsed lung” scenario, in this context, refers to the sudden and often unexpected failure of one of these critical components or subsystems that effectively cripples the entire operation. For instance, imagine a primary GPS module failing during an autonomous mission in an area without reliable secondary navigation, or a critical sensor providing entirely erroneous data. The system, like a body with a compromised lung, struggles to maintain its essential function, moving from a state of controlled stability to one of unpredictable instability. The interconnected nature of these systems means that a single point of failure can trigger a cascade, where one malfunction rapidly leads to others, escalating the crisis.
The Immediate Impact of Core System Failure
When a vital flight system “collapses,” the immediate impact is typically a sudden and dramatic departure from the intended flight path or operational state. A drone that was maintaining a precise altitude and heading might suddenly begin to drift, descend rapidly, or even tumble uncontrollably. For autonomous systems, this can manifest as a complete inability to execute programmed commands, with the flight controller struggling to reconcile conflicting or missing data. In manual flight, the pilot might experience a loss of responsive control, akin to trying to steer a vehicle with a sudden loss of power steering and brakes. The analogy of the lung is particularly apt here: without the ability to “breathe” (i.e., process and act upon vital flight data and execute control commands effectively), the system enters a state of crisis, fighting for its very operational existence. The goal of advanced flight technology is not just to perform tasks but to do so with unwavering reliability, meaning every effort must be made to prevent such critical failures and, failing that, to manage them effectively.
Diagnosing Critical System Malfunctions Mid-Flight
Detecting a “collapsed lung” in a UAV, or any critical system malfunction, is a sophisticated challenge that relies heavily on real-time data analysis and intelligent fault detection. Modern flight systems employ a suite of sensors and diagnostic routines designed to monitor the health and performance of all vital components. The ability to accurately identify which system has failed and to what extent, while the aircraft is still in the air, is crucial for initiating appropriate recovery actions.
Sensor Data Integrity and Redundancy
Flight controllers continuously ingest vast amounts of data from various sensors: inertial measurement units (IMUs) for attitude and acceleration, GPS modules for position and velocity, barometers for altitude, magnetometers for heading, and potentially vision sensors for optical flow and obstacle avoidance. The integrity of this data is paramount. A “collapsed lung” could be a sensor failure, where a primary IMU suddenly stops reporting, or a GPS module loses satellite lock, or a barometer begins providing wildly inaccurate altitude readings.
To counter such vulnerabilities, advanced flight technology incorporates redundancy. Instead of relying on a single sensor, critical systems might employ multiple identical or diverse sensors, and their outputs are constantly cross-referenced. If one sensor “collapses,” a voting system or a Kalman filter can detect the anomaly, discard the faulty data, and seamlessly switch to a healthy sensor or fuse data from multiple working sensors to derive a more reliable estimate. Without such redundancy, a single sensor failure can directly lead to a “system collapse,” leaving the flight controller with insufficient or erroneous information to maintain stable flight.
Navigation System Degradation and Failure
Navigation systems are arguably the most vulnerable to external factors and internal component failures. A GPS signal, while robust, can be lost due to urban canyons, heavy foliage, or intentional jamming/spoofing. When a GPS signal “collapses,” the UAV’s ability to precisely locate itself and follow a predetermined path is severely compromised. In such scenarios, advanced systems attempt to transition to alternative navigation methods, such as visual odometry (using cameras to track movement relative to ground features), or reliance on dead reckoning combined with IMU data.
However, if these secondary systems are also degraded or unavailable, the drone can enter a state of “flight drift” or “uncontrolled descent.” The navigation system effectively “loses its breath,” unable to provide accurate positional data. High-end systems may include inertial navigation systems (INS) that combine GPS with highly accurate IMU data, providing greater resilience against temporary GPS outages. Nevertheless, without periodic GPS corrections, even an INS will drift over time. The critical point is the transition from stable, accurate navigation to a state where the system is either guessing its position or has completely lost its bearings, leading to erratic flight behavior or a forced emergency landing.
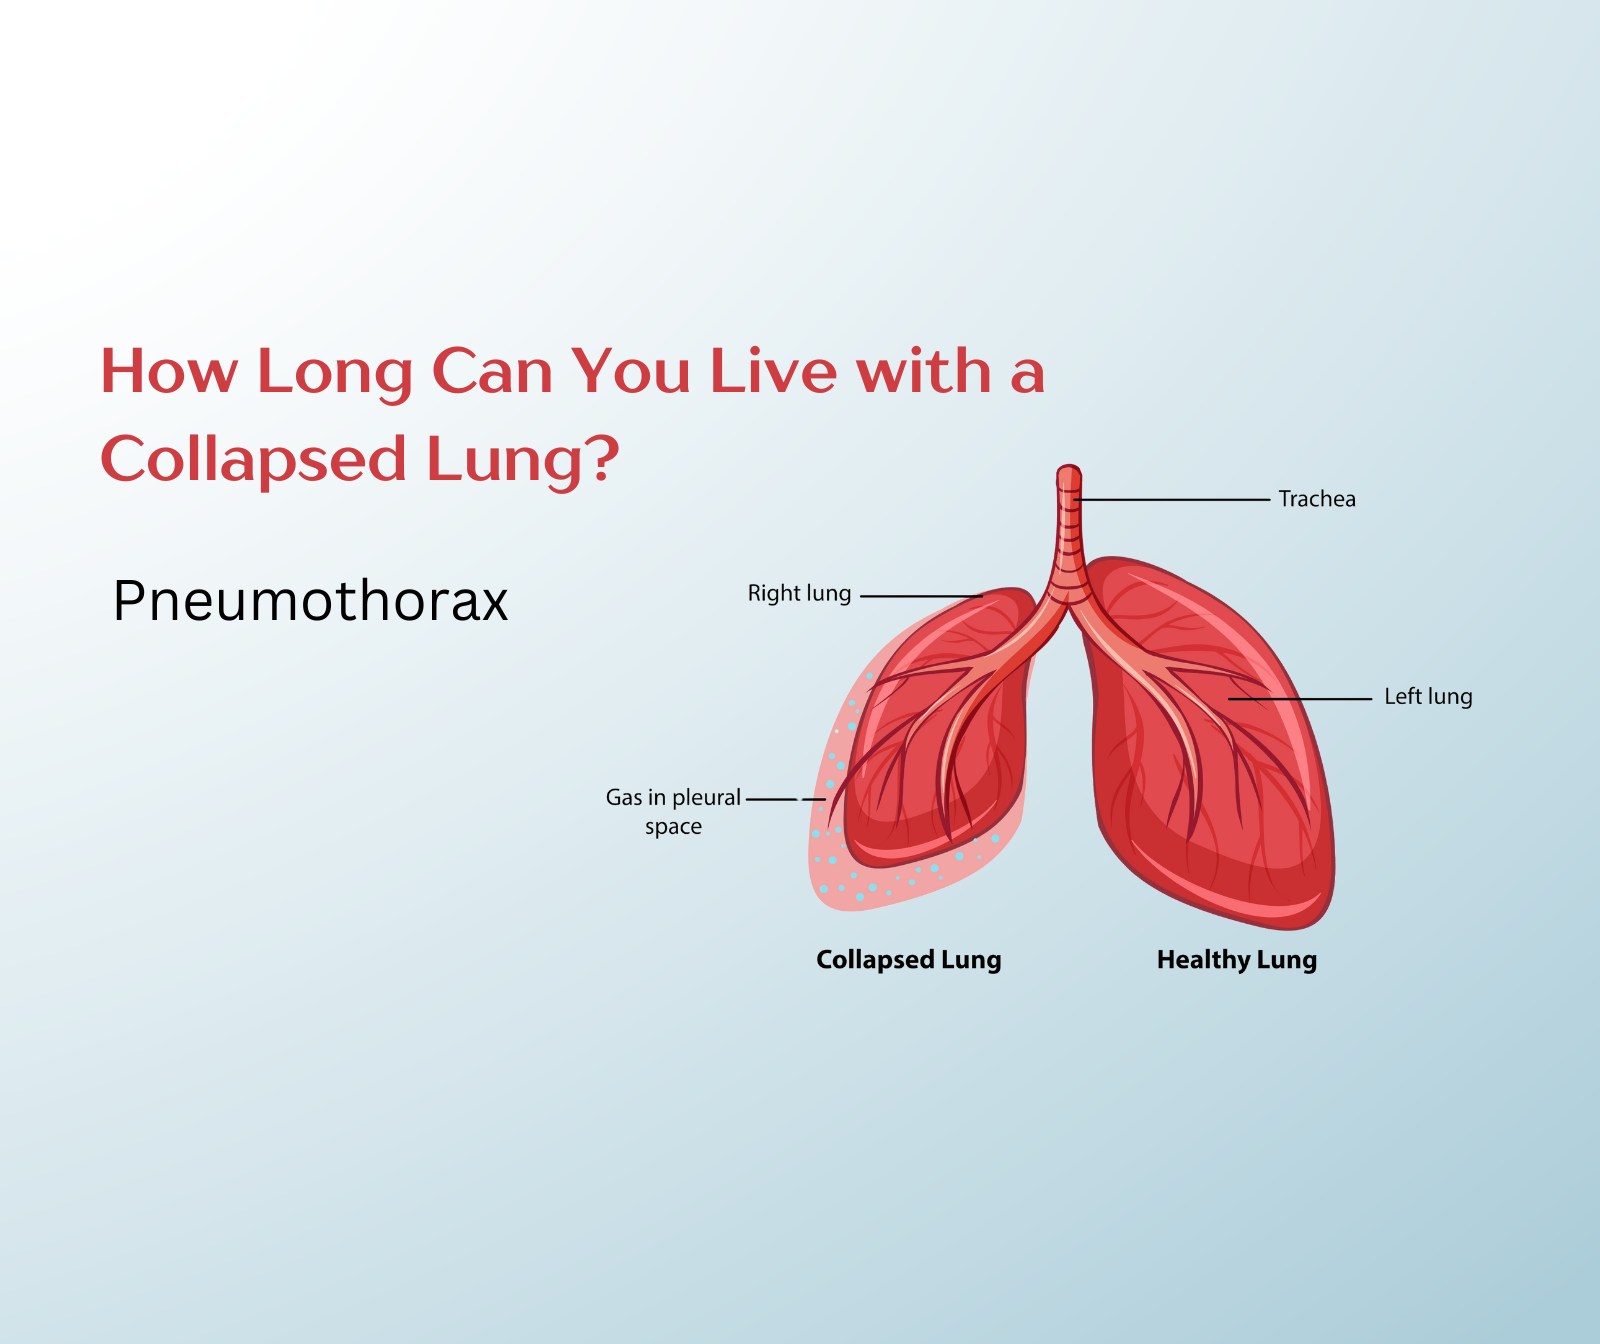
Stabilization System “Pneumothorax” and Control Loss
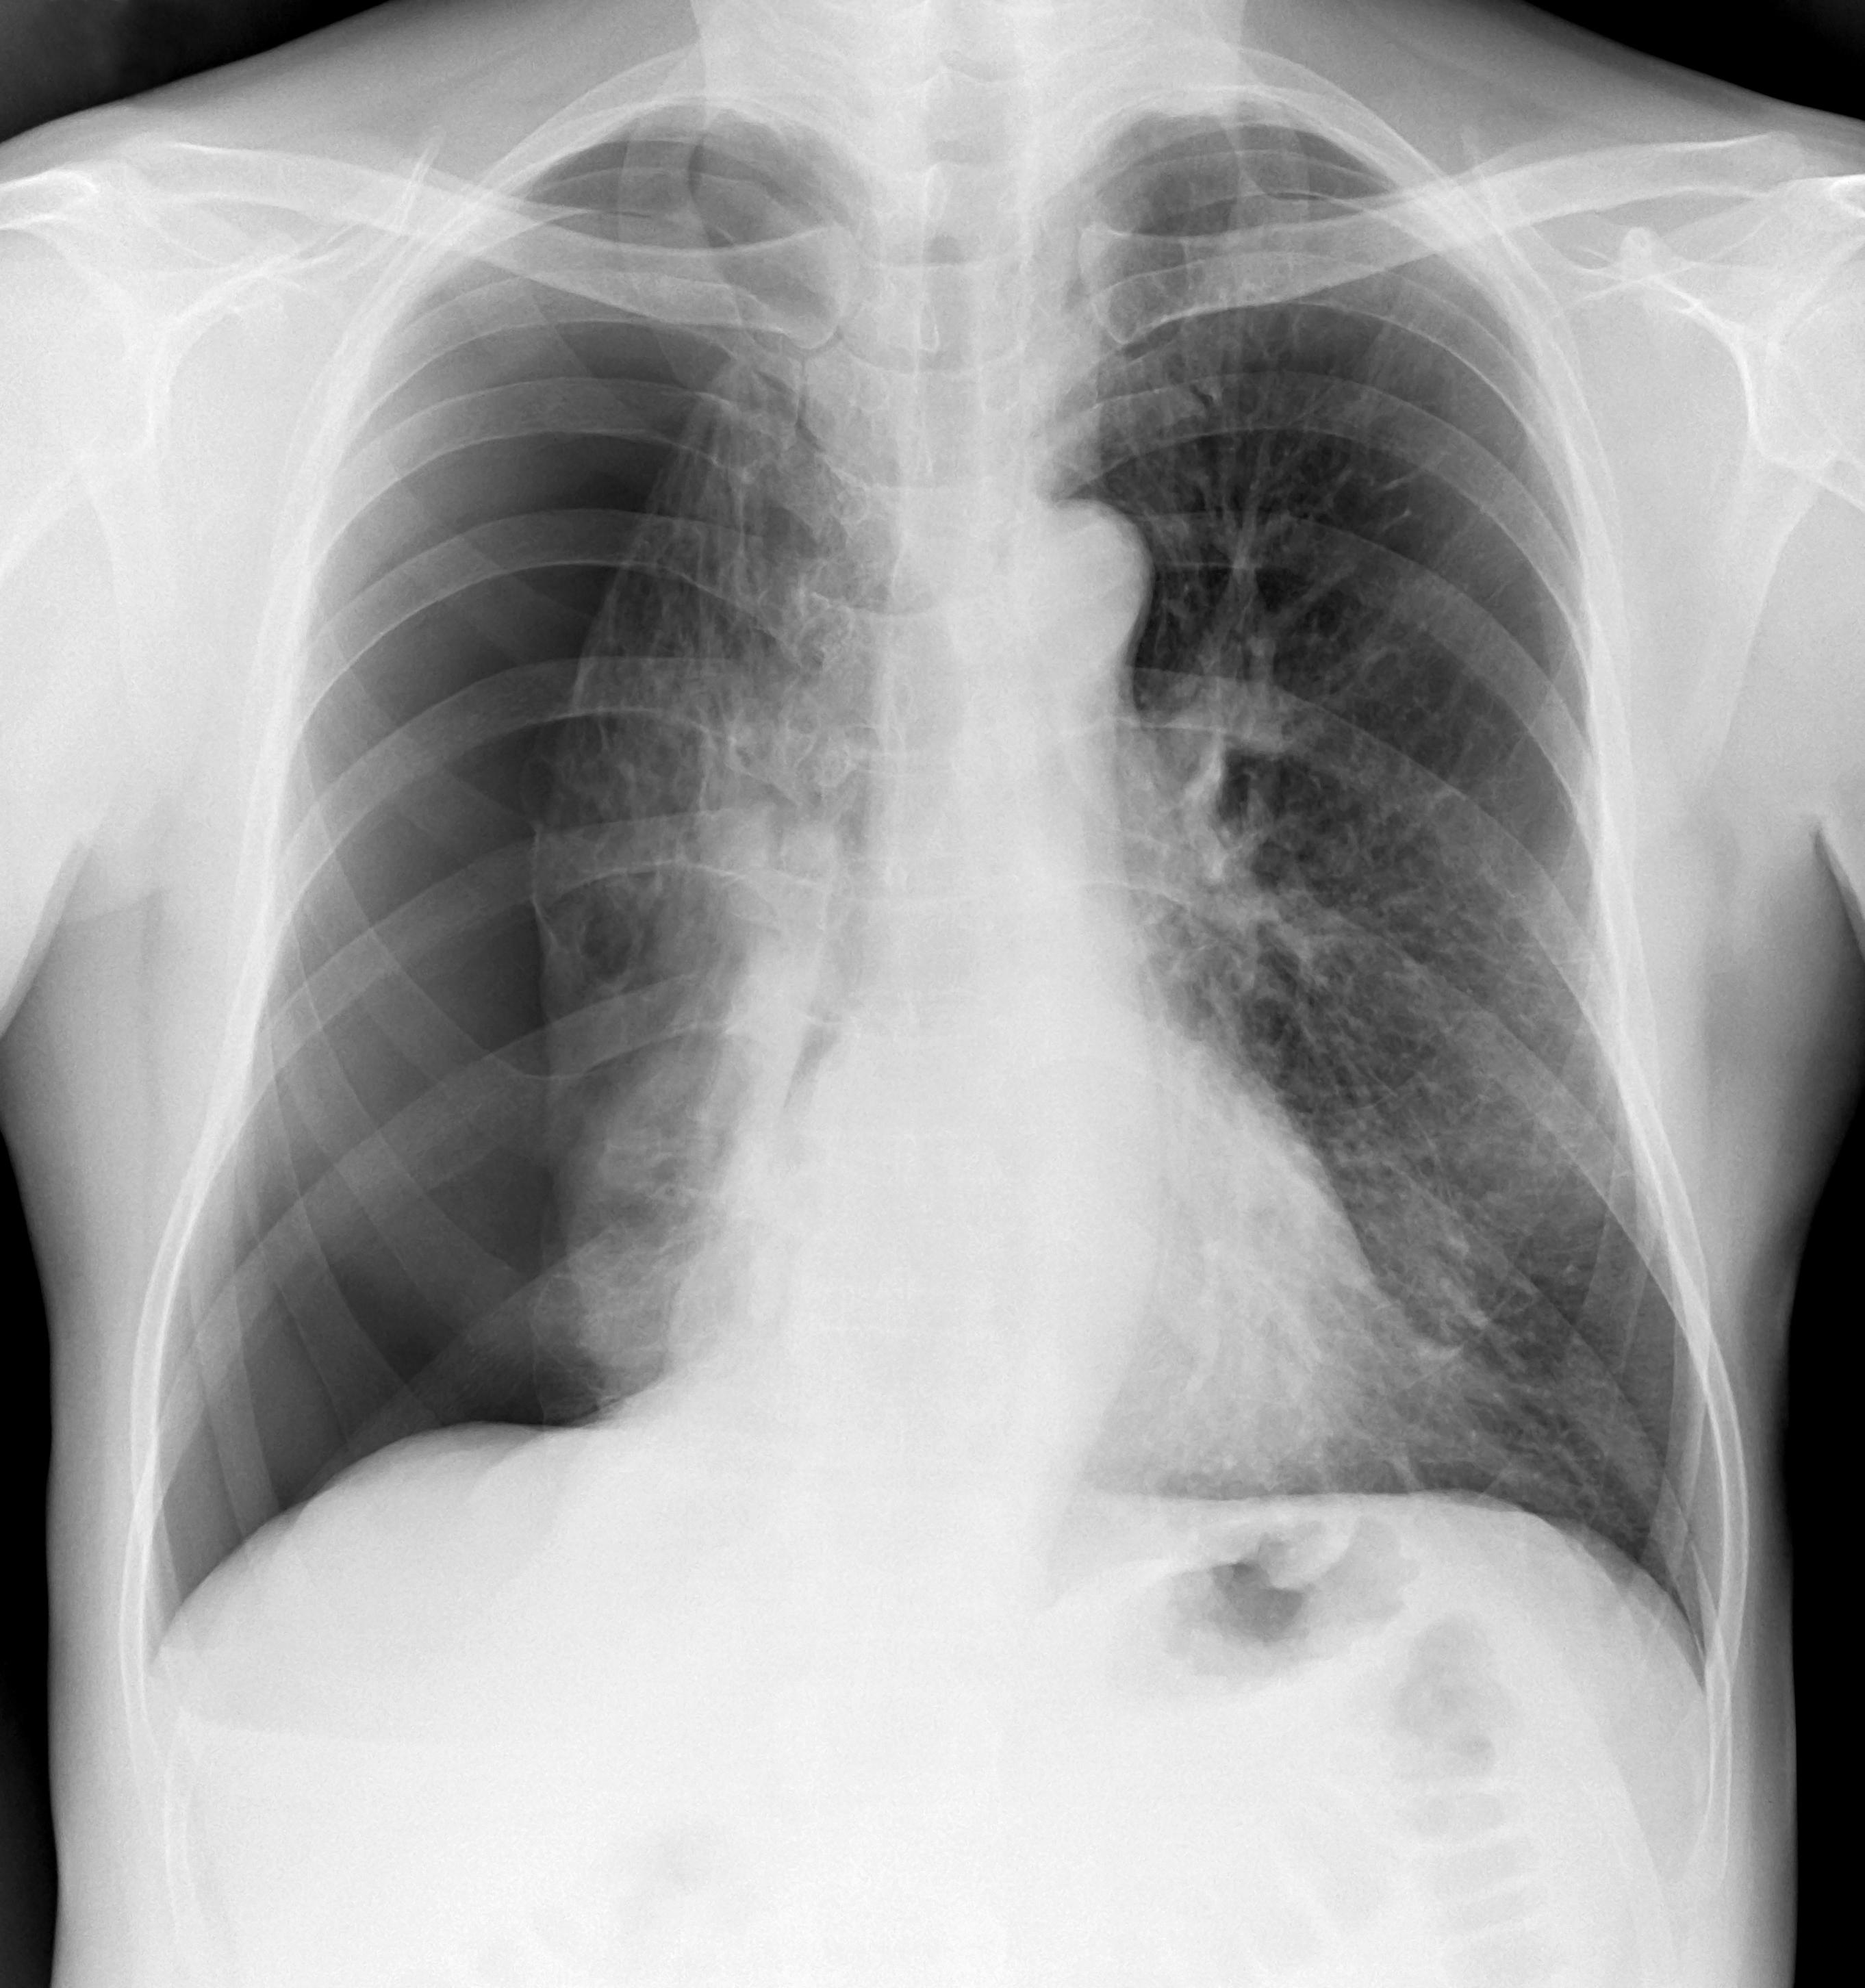
The core of any UAV’s stability lies in its flight control algorithms and the integrity of its propulsion system. When these elements suffer a severe malfunction—analogous to a “pneumothorax” where the lung loses its ability to expand and contract—the drone’s very ability to maintain controlled flight is jeopardized, leading to rapid instability and potential loss of the aircraft.
The Role of Flight Control Algorithms
Flight control algorithms, often based on PID (Proportional-Integral-Derivative) controllers, are continuously working to adjust motor speeds and propeller thrust to counteract external disturbances (like wind) and maintain the desired attitude, altitude, and heading. These algorithms depend on precise and timely feedback from IMU sensors (accelerometers and gyroscopes). If this feedback is compromised, or if the propulsion system itself fails, the algorithms become ineffective.
Consider what happens when a motor fails mid-flight, a propeller detaches, or an electronic speed controller (ESC) malfunctions. This creates an immediate and severe imbalance in thrust. For a multirotor, the loss of even one motor can be catastrophic, as the remaining motors struggle to compensate for the missing thrust and torque. The flight controller will attempt to maintain stability by rapidly adjusting the power to the remaining motors, but if the thrust asymmetry is too great, it will quickly lose control. This is the equivalent of the lung “collapsing” due to an external force, preventing it from functioning and leading to a rapid, uncontrolled descent. High-performance racing drones or industrial UAVs may have sophisticated firmware that attempts to perform emergency landings with a partial motor failure, but this capability is not universal and success is not guaranteed.
Loss of Communication and Command Control
Beyond physical component failures, a “collapsed lung” can also occur in the communication pathway between the ground control station and the UAV. Radio link failure, severe electromagnetic interference, or a malfunction in the drone’s receiver or controller can sever the command link. This means the pilot or autonomous system on the ground can no longer send critical commands or receive vital telemetry data.
In response to a loss of communication, most advanced UAVs are programmed with failsafe protocols. The most common is “Return-to-Home” (RTH), where the drone automatically ascends to a pre-set altitude and navigates back to its launch point using its last known GPS coordinates. Other failsafes might include auto-landing at the current position or hovering until the signal is re-established. However, if the RTH function itself relies on a compromised navigation system or if the drone loses power before it can execute the failsafe, the outcome can be a complete loss of the aircraft. The communication pathway, in this sense, is the “airway” that allows the ground to “breathe life” into the drone’s operations; its collapse leaves the drone isolated and often unable to recover its operational purpose.
Mitigating the Risk of “Pulmonary Failure” in UAVs
Preventing and mitigating critical system failures, or “pulmonary failure,” in UAVs is a multi-faceted endeavor that spans design, implementation, and operational practices. The goal is to build systems that are not only high-performing but also inherently resilient and capable of self-diagnosis and, where possible, self-recovery.
Proactive Design for Resilience
The first line of defense against system collapse is proactive design incorporating principles of redundancy and fault tolerance. Hardware redundancy involves duplicating critical components. For instance, high-reliability UAVs might feature dual or even triple redundant GPS modules, IMUs, and flight controllers. If one unit fails, another seamlessly takes over. Software fault tolerance complements this by employing voting systems where multiple redundant sensors or computations are compared, and a consensus is reached, discarding outlier data. Error detection and correction codes in communication protocols also ensure data integrity. Furthermore, robust power management and distribution systems, often with redundant power sources or isolated circuits, prevent a single electrical fault from cascading across the entire aircraft. These design choices are crucial in building a system that can withstand the failure of individual components without suffering a total “collapse.”
Advanced Monitoring and Predictive Analytics
Beyond inherent design, the continuous monitoring of UAV health is crucial. Modern flight systems generate extensive telemetry data, including motor temperatures, battery voltage, current draw, GPS signal quality, and sensor performance metrics. Advanced monitoring systems analyze this data in real-time, looking for anomalies that might indicate an impending “collapse.” Machine learning algorithms can be trained to recognize patterns associated with component wear, degradation, or pre-failure states, allowing for predictive maintenance. This enables operators to identify potential issues before they escalate into critical failures, much like detecting early signs of respiratory distress before a full lung collapse. Routine pre-flight checks, often automated, also play a vital role in verifying the functionality of all critical systems, ensuring that the “lungs” are healthy before takeoff.
Emergency Protocols and Autonomous Recovery
Despite all preventative measures, failures can still occur. Therefore, robust emergency protocols and autonomous recovery capabilities are essential. Intelligent failsafe modes go beyond simple Return-to-Home. These can include advanced path planning to avoid obstacles during an emergency return, or even “controlled crash” routines designed to minimize damage to the aircraft and surroundings if a full recovery is impossible. For fixed-wing drones, auto-rotation capabilities (using aerodynamic forces to spin the propeller and generate power during engine failure) can allow for a gliding landing. For multirotors, sophisticated algorithms might attempt to perform a controlled descent or even a rough landing with a partial motor failure. Geo-fencing and dynamic airspace management also serve as critical safety nets, defining operational boundaries that can prevent a compromised UAV from drifting into sensitive areas, thereby minimizing the collateral damage from an unrecoverable “pulmonary failure.” The ultimate goal is to equip UAVs with the intelligence and mechanisms to manage unforeseen challenges, ensuring that even when a critical system is compromised, the outcome is as safe and controlled as possible.