
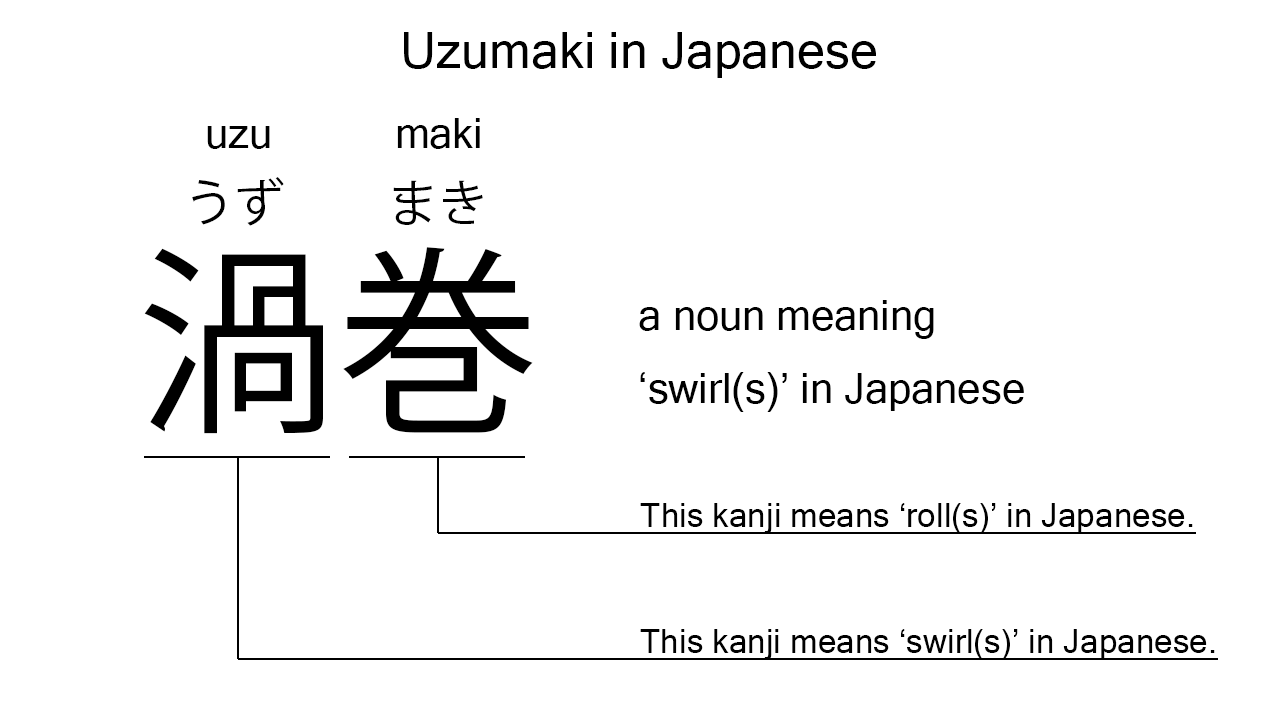
The Japanese term “Uzumaki” translates most commonly to “spiral,” “whirlpool,” or “vortex” in English. While widely recognized in popular culture, its underlying meaning holds profound implications across various scientific and engineering disciplines, including the intricate realm of flight technology. In the context of advanced aerial platforms like drones, the concept of “Uzumaki” transcends a mere pattern, representing fundamental principles of aerodynamics, navigation, stabilization, and innovative design that are critical to the performance and capabilities of unmanned aerial vehicles (UAVs). This exploration delves into how the essence of “Uzumaki”—the dynamic spiral and vortex—is integral to the evolution and operational prowess of modern flight technology.
The Intricate Geometry of “Uzumaki”: Spirals and Vortices in Flight Dynamics
At its core, “Uzumaki” refers to a curved pattern that emanates from a central point, constantly receding from or approaching it. This definition encompasses everything from the macroscopic grandeur of spiral galaxies and hurricanes to the microscopic helical structure of DNA. In the domain of flight technology, this concept is not merely abstract but directly relates to the movement of air, the design of components, and the very paths UAVs traverse.
Defining Uzumaki: Whirlpools, Vortices, and Helical Motion
A whirlpool is a swirling body of water, while a vortex is a mass of fluid (liquid or gas) that rotates around an axis. Both exemplify the “Uzumaki” principle. In aeronautics, understanding and manipulating vortices are paramount. The air flow over and around a drone generates various types of vortices, some beneficial, others detrimental. Helical motion, another manifestation of the spiral, describes the trajectory of propellers and the path a drone might take as it ascends or descends while circling. These natural and engineered spiral phenomena dictate much of a drone’s performance characteristics, from its lift and drag to its stability and maneuverability.
Ancient Principles and Modern Applications
The principles governing spirals and vortices have been observed and utilized by humans for millennia, from the design of Archimedes’ screw to the study of fluid dynamics. In contemporary flight technology, these ancient insights are re-contextualized with computational fluid dynamics (CFD) and advanced materials. Engineers rigorously analyze “Uzumaki” patterns in airflow to optimize propeller blade shapes, design aerodynamically efficient frames, and develop sophisticated control algorithms that can either exploit or mitigate vortex generation for superior flight performance. The ability to precisely model and predict these swirling airflows allows for the creation of drones that are more stable, energy-efficient, and capable of executing highly complex maneuvers.
Harnessing Uzumaki Principles in Drone Aerodynamics and Design
The “Uzumaki” concept is deeply embedded in the physical design and aerodynamic principles that govern how drones fly. From the very components that generate lift to the strategies employed to reduce drag, the spiral and vortex play a critical role.
Aerodynamic Efficiency and Propeller Design
Propellers are the most direct manifestation of “Uzumaki” in drone design. Each blade, as it rotates, cuts through the air, creating a helical path that generates thrust and lift. The shape, pitch, and number of propeller blades are meticulously engineered to optimize this helical interaction with the air, maximizing efficiency and minimizing noise. An inefficient propeller design can lead to excessive tip vortices, which are energy-sapping swirls of air that reduce thrust and increase power consumption. Advanced aerodynamic studies focus on sculpting blades that minimize these detrimental “Uzumaki” effects while maximizing the useful helical airflow. This involves intricate CFD simulations to fine-tune the airfoil profiles and ensure smooth, controlled air displacement, translating directly into longer flight times and greater payload capacity.
Vortex Generators and Flow Control
Beyond propellers, the “Uzumaki” principle is applied in more subtle ways to enhance drone stability and control. Vortex generators, small vanes strategically placed on the drone’s frame or wings, are designed to intentionally create small, controlled vortices. These micro-vortices energize the boundary layer of air flowing over the drone’s surfaces, preventing flow separation—a phenomenon where airflow detaches from the surface, leading to a sudden loss of lift and increased drag. By maintaining attached flow, vortex generators improve aerodynamic efficiency, enhance stability, especially at high angles of attack or during aggressive maneuvers, and allow for more predictable flight characteristics. This active manipulation of “Uzumaki” patterns in the airflow empowers drones to perform with greater agility and reliability in diverse conditions.
Uzumaki-Inspired Flight Paths and Navigation
The dynamic nature of the “Uzumaki” also lends itself to sophisticated flight path planning and navigation strategies for drones, particularly in applications requiring comprehensive area coverage or complex environmental interaction.
Spiral Search Patterns and Mapping
One of the most practical applications of “Uzumaki” in flight technology is the implementation of spiral search patterns. For applications such as search and rescue (SAR), environmental monitoring, or agricultural mapping, a drone can be programmed to fly in an expanding or contracting spiral. This ensures systematic and complete coverage of a defined area, minimizing redundant passes and maximizing the efficiency of data collection. GPS and advanced inertial navigation systems enable drones to execute these precise “Uzumaki” trajectories with high accuracy, ensuring that every square meter of a target zone is thoroughly scanned. This method is particularly effective for locating objects or anomalies within a concentrated area, gradually expanding its search radius.
Precision Maneuvering and Swarm Intelligence
Beyond broad area coverage, “Uzumaki” paths are crucial for precision maneuvering in complex environments. A drone might execute a tight spiral descent to inspect the interior of a confined space, or a helical ascent around a tall structure for detailed photogrammetry. These complex 3D paths require sophisticated flight controllers capable of coordinating multiple axes of movement simultaneously. In swarm robotics, where multiple drones operate cohesively, synchronized “Uzumaki” maneuvers can be employed for cooperative mapping, environmental sensing, or even creating dynamic aerial displays. The ability of a swarm to maintain relative positions while executing a collective spiral demonstrates advanced control algorithms and inter-drone communication, showcasing the cutting-edge of autonomous flight.
Stabilization and Control Systems for Dynamic Uzumaki Trajectories
Executing and maintaining “Uzumaki” flight paths demands highly responsive and precise stabilization and control systems. The inherent dynamic instability of complex fluid flows requires constant corrective action from the drone’s flight controller.
Counteracting Unwanted Vortices
While some vortices are intentionally generated for control, others are an unavoidable byproduct of flight and can introduce instability. Wake turbulence from other aircraft or even wind shear can create chaotic “Uzumaki” patterns in the air, buffeting the drone. Modern flight control systems employ advanced sensors—including gyroscopes, accelerometers, magnetometers, and barometers (IMU)—alongside GPS and often visual or lidar-based navigation, to detect these disturbances in real-time. Sophisticated algorithms then rapidly adjust motor speeds and propeller thrust vectors to counteract the effects of these unwanted vortices, ensuring the drone maintains its intended trajectory and stability even in turbulent conditions. This continuous feedback loop is critical for reliable operation.
Implementing Uzumaki-Inspired Flight Algorithms
Programming a drone to perform a smooth, consistent spiral involves complex algorithms that translate a desired 3D path into precise commands for each motor. These algorithms account for factors like the drone’s mass, inertia, aerodynamic properties, and the environment. PID (Proportional-Integral-Derivative) controllers, often augmented with model predictive control (MPC) or adaptive control techniques, are tuned to manage the drone’s pitch, roll, yaw, and altitude with exquisite precision. For “Uzumaki” flight, the controller must continuously calculate the correct combination of forces to maintain the desired radius and vertical velocity, smoothly transitioning between different segments of the spiral. The development of robust and efficient “Uzumaki”-specific flight algorithms is a key area of research, pushing the boundaries of autonomous flight capabilities.
The Future of Uzumaki in UAV Innovation
The fundamental concept of “Uzumaki” continues to inspire innovation in drone technology, promising more efficient, versatile, and intelligent aerial platforms.
Energy Efficiency and Biomimicry
Future drone designs will increasingly draw inspiration from nature’s efficient use of spirals and vortices. Biomimicry, the imitation of natural designs and processes, can lead to novel airframe shapes or propulsion systems that minimize energy consumption. For instance, studying how birds utilize thermals (which often involve spiraling air columns) to gain altitude with minimal effort could inform adaptive “Uzumaki” flight strategies for drones. Research into vortex-ring state dynamics could lead to propellers that operate more efficiently in varied airflows, reducing the power required for hovering and complex maneuvers. By understanding and replicating natural “Uzumaki” phenomena, engineers aim to unlock unprecedented levels of endurance and performance for UAVs.
Advanced Sensing and Dynamic Path Planning
The integration of more advanced sensors, such as high-resolution lidar, millimeter-wave radar, and sophisticated computer vision systems, will enable drones to perceive and react to their environment with greater nuance. This will facilitate truly dynamic “Uzumaki” path planning. Instead of pre-programmed spirals, drones will be able to autonomously generate and adapt spiral trajectories in real-time to navigate complex, unstructured environments, avoid dynamic obstacles, or track moving targets with extreme precision. Imagine a drone spiraling down a narrow, cluttered alleyway, dynamically adjusting its path to avoid sudden hazards. This level of autonomy, driven by AI and machine learning, will transform how drones operate in everything from logistics and inspection to urban search and rescue.

Integration with Environmental Interaction
The “Uzumaki” concept will also play a crucial role in how drones interact with their environment for data collection and analysis. For example, drones equipped with atmospheric sensors could perform targeted spiral ascents or descents to profile air quality or weather phenomena in a specific column of air, gathering detailed 3D data. Similarly, thermal imaging drones might execute spirals to map heat signatures in a volumetric space, aiding in wildfire detection or structural integrity assessments. The ability to precisely control and execute “Uzumaki” trajectories allows for the capture of richer, more contextually relevant data, opening new avenues for environmental understanding and remote sensing applications.
In summary, while “Uzumaki” simply means “spiral” or “whirlpool” in English, its scientific and technological implications in the realm of flight technology are vast. From shaping the air around propellers to guiding intricate flight paths, the principles encapsulated by this single Japanese word are fundamental to the design, control, and future innovation of unmanned aerial vehicles.