
In the dynamic landscape of modern technology and innovation, particularly across fields like artificial intelligence, autonomous flight, mapping, and remote sensing, mathematical symbols serve as the fundamental language. While often abstract in their pure form, these symbols become the bedrock upon which sophisticated algorithms and intelligent systems are built. Among the myriad of variables and notations, the lowercase ‘u’ frequently appears, carrying significant and diverse meanings depending on the context. Understanding these interpretations is crucial for anyone delving into the mathematical underpinnings of cutting-edge tech. Far from a mere arbitrary letter, ‘u’ often represents critical components that dictate the behavior, perception, and control of advanced technological systems.
The Ubiquitous Unit Vector: Guiding Autonomous Systems
One of the most pervasive and vital meanings of ‘u’ in mathematical applications, particularly within the realm of robotics, computer vision, and navigation for autonomous systems, is the unit vector. A unit vector is a vector with a magnitude (or length) of one, used exclusively to denote direction. Its power lies in its ability to strip away concerns of scale, focusing solely on orientation in space.
Defining Direction in 3D Space
In a three-dimensional Cartesian coordinate system, any direction can be represented by a vector. When we normalize this vector (divide it by its magnitude), we obtain a unit vector. For instance, if a drone is moving along a path described by a velocity vector $vec{V}$, the unit vector $hat{u} = frac{vec{V}}{|vec{V}|}$ points precisely in the direction of the drone’s movement, irrespective of its speed. This seemingly simple concept is profound because it allows algorithms to separate directional control from speed control, simplifying complex motion planning. Furthermore, unit vectors are fundamental for defining coordinate frames and transformations between them, which is indispensable for any system that operates in the physical world. For example, understanding a drone’s orientation relative to the ground, or a camera’s orientation relative to the drone itself, relies heavily on unit vectors defining the axes of these different reference frames.
Application in Drone Navigation and Mapping
In the context of drone technology and mapping, unit vectors are indispensable. When a drone navigates, its flight controller constantly computes its current position, velocity, and orientation. Unit vectors are used to:
- Define direction of travel: Path planning algorithms often calculate desired unit vectors for the drone’s movement to reach a specific waypoint.
- Represent sensor readings: For instance, a directional antenna or an optical flow sensor might provide readings that, when interpreted, yield unit vectors indicating relative motion or the direction to a target.
- Generate maps: In 3D mapping and photogrammetry, understanding the camera’s precise orientation at each image capture point is critical. This orientation is defined by a series of unit vectors representing the camera’s local axes. These vectors, along with positional data, are fed into algorithms to reconstruct accurate 3D models and point clouds.
- Waypoint Guidance: Autonomous navigation systems use unit vectors to calculate the required thrust and direction adjustments needed to steer the drone towards a target waypoint, ensuring it follows the planned trajectory with precision.
Role in Sensor Fusion and Stabilization
Modern drones and autonomous vehicles rely heavily on sensor fusion to achieve stable flight and accurate situational awareness. Data from accelerometers, gyroscopes, magnetometers, and GPS units must be integrated and interpreted. Unit vectors play a crucial role here:
- Attitude Estimation: Algorithms like the Mahony or complimentary filter use unit vectors to represent the drone’s attitude (roll, pitch, yaw) by tracking the orientation of its body frame relative to an earth-fixed frame. For example, a unit vector representing the ‘up’ direction of the drone’s body can be compared with the gravitational vector from the accelerometer to determine pitch and roll.
- Stabilization Systems: For a drone to remain stable in windy conditions or during rapid maneuvers, its flight controller must constantly adjust motor speeds based on real-time orientation data. Unit vectors derived from gyroscope and accelerometer readings inform the proportional-integral-derivative (PID) controllers about the current angular error, allowing for precise corrective actions.
- Obstacle Avoidance: Lidar and stereo vision systems generate point clouds representing the environment. Identifying potential collision paths often involves calculating unit vectors from the drone’s current position to points in the environment, then evaluating their proximity and trajectory.
‘u’ as the Control Input: Orchestrating Autonomous Flight
Another paramount interpretation of ‘u’ in mathematics, particularly within control theory and robotics, is as the control input to a system. In this context, ‘u’ represents the variable (or vector of variables) that an autonomous system can manipulate to influence its own behavior or state.
Foundations of Control Theory
Control theory is the engineering discipline that deals with the design of controllers to regulate the behavior of dynamic systems. A common representation of a system is given by differential equations, where the change in the system’s state ($x$) over time is a function of its current state and the control input ‘u’. For instance, $dot{x} = f(x, u)$, where ‘u’ is what the controller adjusts. In the case of a drone, ‘u’ could represent the collective thrust from its propellers, the differential thrust applied to individual motors for steering, or even higher-level commands like “move forward at 5 m/s.” The goal of a control system is to compute the optimal ‘u’ at each moment to achieve a desired system state, whether it’s maintaining altitude, following a path, or stabilizing against disturbances.
Manipulating Drone Dynamics
For a quadcopter drone, the physical control inputs are the individual speeds of its four motors. These motor speeds translate into forces and torques that govern the drone’s six degrees of freedom (three translational: x, y, z; and three rotational: roll, pitch, yaw).
- Thrust Control: The sum of the motor speeds directly affects the vertical thrust, controlling altitude. This collective thrust can be represented as one component of the control input vector ‘u’.
- Attitude Control: Differentially adjusting motor speeds creates torques that allow the drone to roll, pitch, and yaw. For example, increasing the speed of two motors on one side and decreasing the speed of the two opposite motors induces a roll. These differential speeds or the resulting torques are also components of the control input ‘u’.
- Trajectory Tracking: High-level control loops take desired position and velocity commands, translate them into desired attitude and thrust commands, which are then further broken down into the specific ‘u’ (motor speed adjustments) required by the lower-level flight controllers. This hierarchical control structure relies entirely on the precise computation and application of ‘u’.
AI and Adaptive Control Strategies
In advanced “Tech & Innovation” applications, particularly those involving AI follow mode or autonomous decision-making, ‘u’ as a control input becomes even more sophisticated.
- Model Predictive Control (MPC): This advanced control strategy uses a model of the system to predict its future behavior over a time horizon, then calculates a sequence of optimal control inputs ‘u’ that minimize a cost function (e.g., minimizing error, energy consumption, or time to target). As the drone moves, the prediction horizon shifts, and the process repeats. This allows for complex trajectory following and obstacle avoidance in dynamic environments.
- Reinforcement Learning (RL): In AI systems trained with RL, an agent (e.g., an autonomous drone) learns to choose optimal actions (control inputs ‘u’) in an environment to maximize a cumulative reward. The ‘u’ here represents the specific commands the drone’s “brain” decides to issue to its motors or actuators at any given moment. This is how autonomous flight behaviors like AI follow mode, where the drone intelligently tracks a subject, are often developed and refined.
- Adaptive Control: For systems operating in uncertain or changing environments (e.g., varying wind conditions), adaptive controllers continuously estimate the system’s parameters and adjust the control input ‘u’ accordingly to maintain desired performance. This ensures robust autonomous flight even when external conditions are unpredictable.
Beyond Vectors and Controls: Other Interpretations of ‘u’ in Tech
While unit vectors and control inputs are perhaps the most common interpretations of ‘u’ in the context of flight technology and autonomous systems, the variable can appear with other significant meanings depending on the specific mathematical model or domain.
Utility Functions in Decision Making
In the fields of artificial intelligence, robotics, and economic modeling, ‘u’ is often used to denote a utility function. A utility function quantifies the desirability or preference of an outcome, state, or action. In autonomous decision-making processes, particularly in planning and pathfinding for drones or autonomous vehicles, a utility function helps the AI evaluate potential choices. For example, when planning a reconnaissance mission, an AI might use a utility function to weigh factors like mission objective completion, energy consumption, risk of detection, and time efficiency. The AI then seeks to choose actions (a sequence of ‘u’ as control inputs or high-level decisions) that maximize this utility, leading to optimal mission execution. This is critical for intelligent navigation and resource allocation in remote sensing applications.
Unifying Set Operations for Data Management
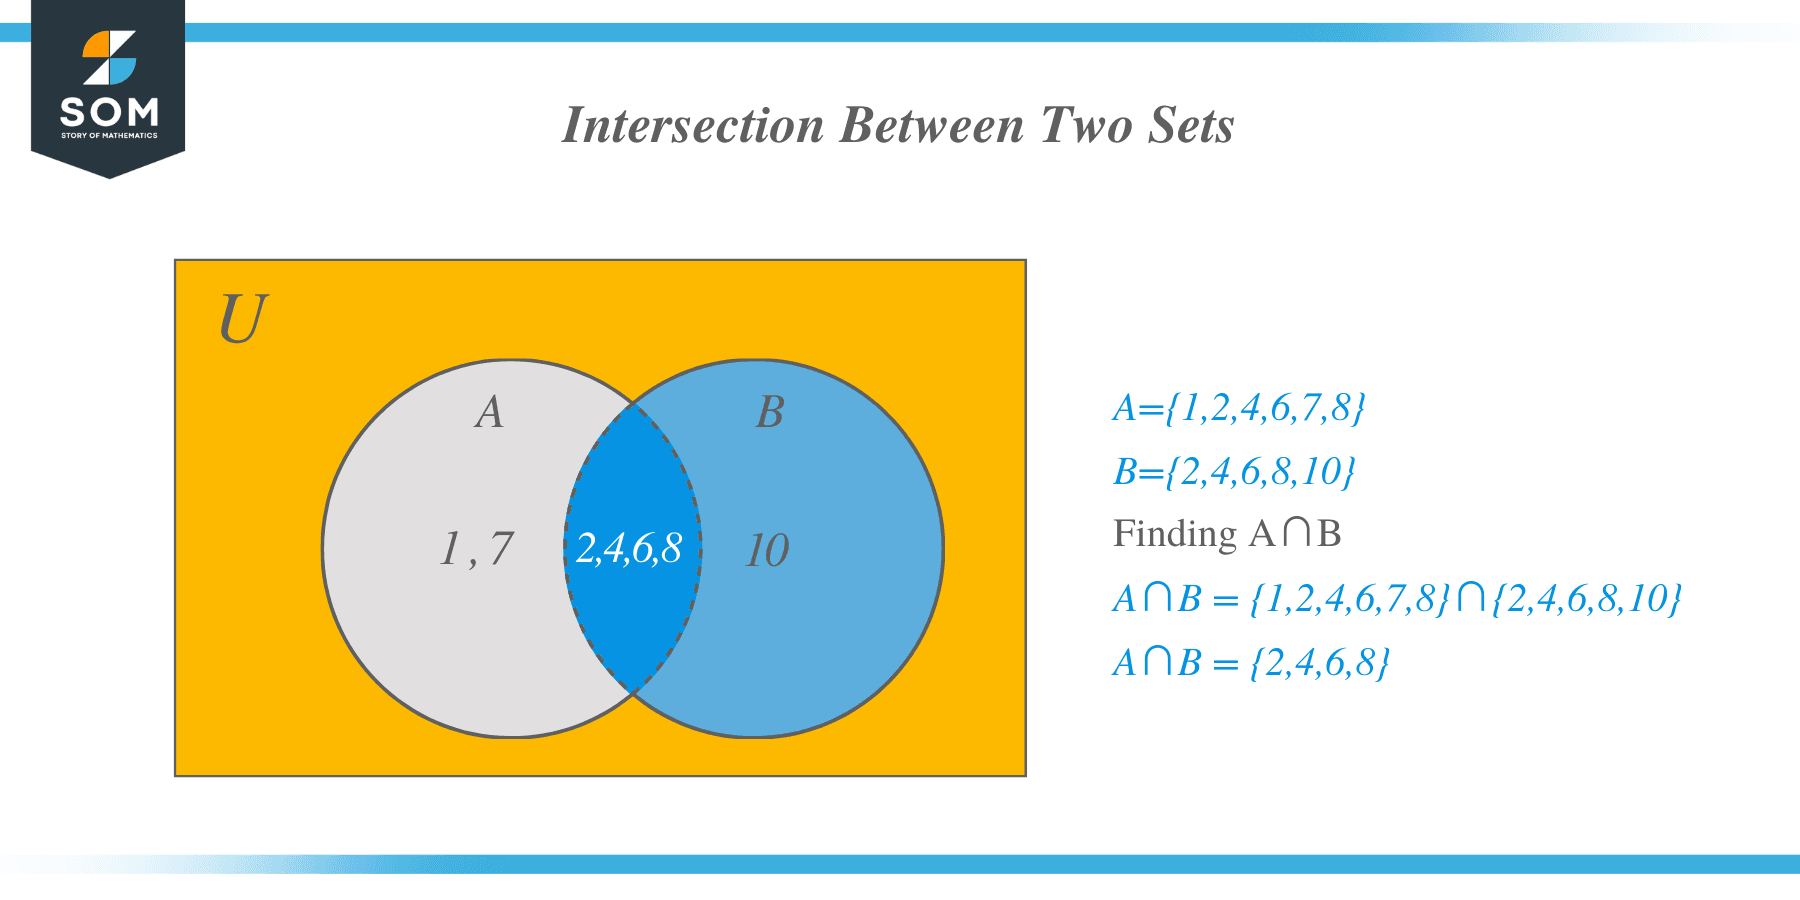
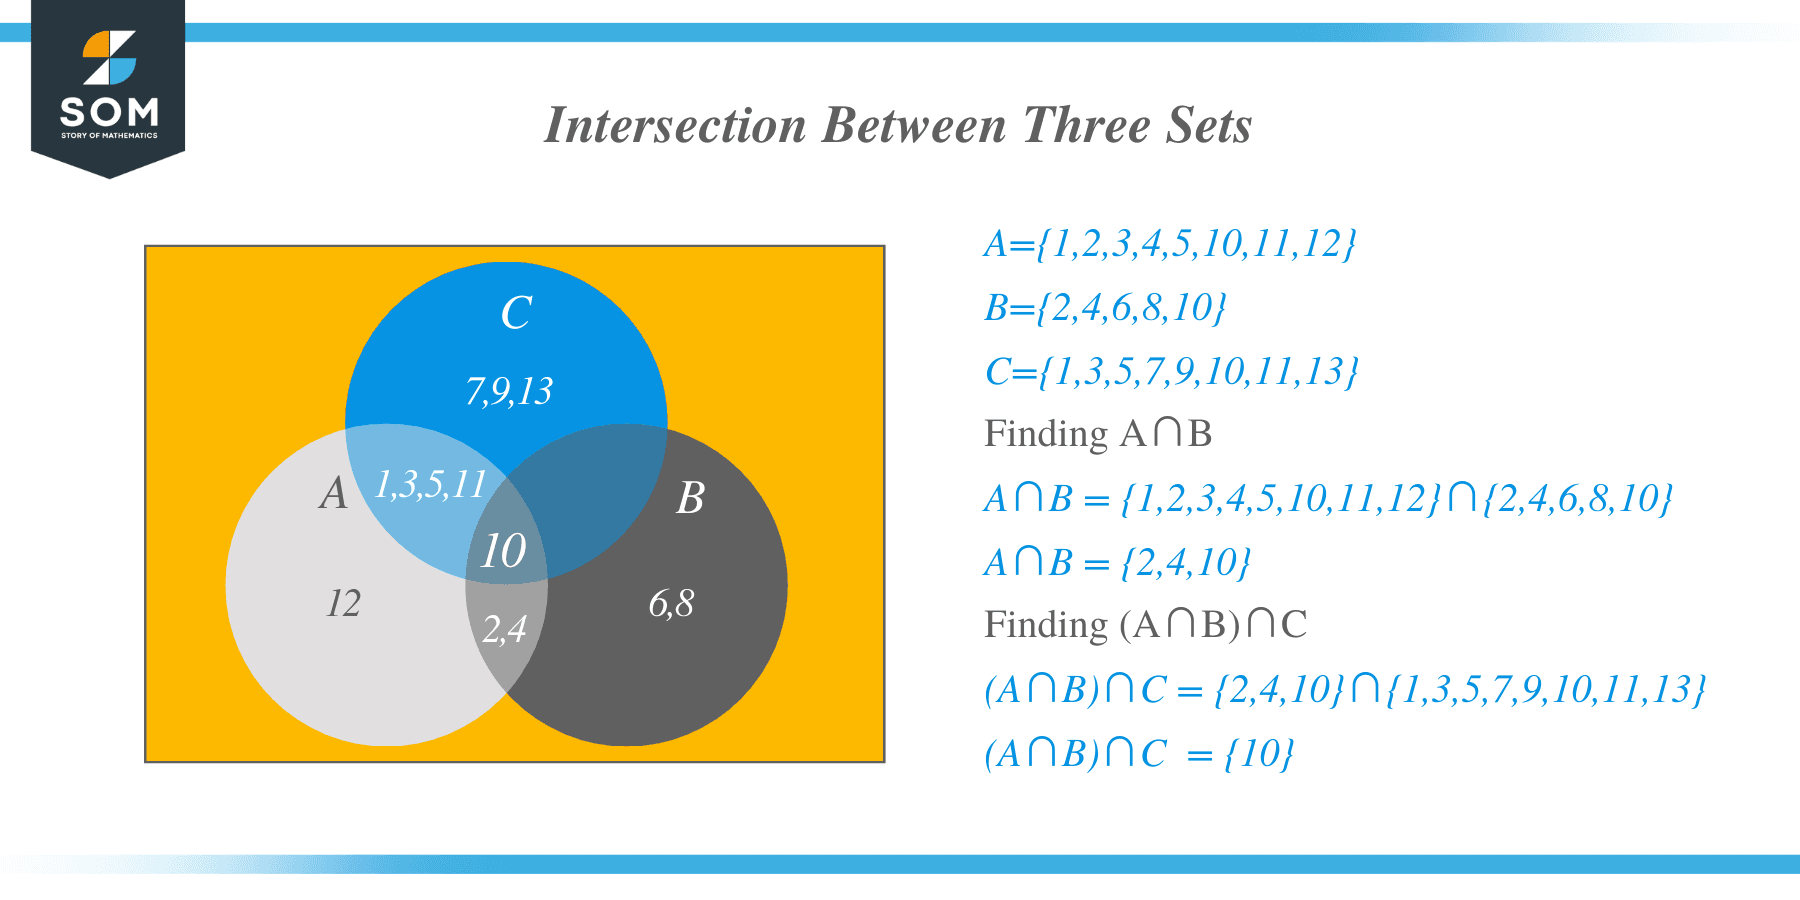
Although less frequent as a standalone variable ‘u’, the symbol ‘∪’ (U+222A) is universally recognized in mathematics as the union operator in set theory. While this might seem abstract, set theory is foundational to computer science and data management, which underpin many aspects of “Tech & Innovation.”
- Data Integration: In mapping and remote sensing, data from various sources (satellite imagery, drone-collected LiDAR, ground sensor data) often needs to be combined. Set union operations might be implicitly used when merging datasets, ensuring all unique data points or features from multiple sources are included in a combined representation.
- Feature Detection: Algorithms for object recognition or feature extraction might define sets of pixels or data points belonging to certain characteristics. Union operations could be used to combine overlapping features or expand regions of interest.
- Database Queries: Many database systems, which manage the vast amounts of data generated by drones and remote sensing platforms, support SQL operations that are direct analogs of set theory operations, including union, to combine results from different queries.
The Mathematical ‘u’ as a Pillar of Innovation
The seemingly simple letter ‘u’, when interpreted within its various mathematical contexts, reveals itself as a critical component in the design, development, and operation of advanced technological systems. Whether it’s precisely defining direction as a unit vector, orchestrating movement as a control input, guiding decisions through utility, or silently aiding in data management, ‘u’ underscores the indispensable role of mathematics in pushing the boundaries of what’s possible.
Precision, Reliability, and Efficiency
The rigorous mathematical definitions associated with ‘u’ provide the framework for building systems that are precise, reliable, and efficient. The ability to mathematically model a drone’s dynamics, predict its behavior, and then apply finely tuned control inputs ‘u’ allows for complex maneuvers, stable hovering, and accurate payload delivery. Similarly, using unit vectors for navigation ensures that autonomous systems can understand and act upon their orientation in 3D space with high fidelity, vital for safe and effective autonomous flight and accurate mapping.

The Future of Autonomous Systems
As autonomous flight, AI follow mode, advanced mapping, and remote sensing capabilities continue to evolve, the underlying mathematical principles represented by symbols like ‘u’ will only grow in importance. Future innovations will demand even more sophisticated control algorithms, more nuanced decision-making processes, and more robust methods for interpreting vast quantities of data. A deep understanding of what ‘u’ signifies in its various mathematical roles is not just an academic exercise but a practical necessity for engineers, scientists, and innovators striving to create the next generation of intelligent technologies that seamlessly interact with and understand our world. The abstract beauty of mathematics, encapsulated in a single letter, directly translates into the tangible power of technological advancement.