The equation y = mx + b, a fundamental pillar of linear algebra, describes a straight line in a two-dimensional coordinate system. While it appears simple, its underlying principles – particularly the concept represented by ‘m’ – are profoundly influential across numerous scientific and engineering disciplines, including the sophisticated realm of flight technology. Within the context of modern drones and aerial systems, ‘m’ transcends its basic definition as the “slope” and emerges as a critical indicator of dynamic behavior, predictive capability, and precise control, fundamentally shaping how unmanned aerial vehicles (UAVs) navigate, stabilize, and interpret their environment. It represents a rate of change, a gradient, or a sensitivity, providing the mathematical backbone for many complex processes that enable safe and effective drone operations.
The Mathematical Foundation of Flight: Understanding y=mx+b
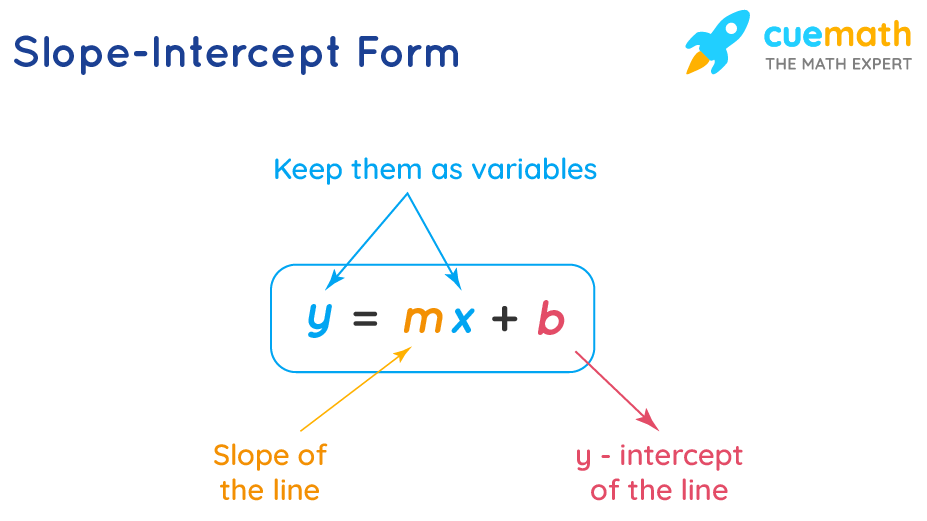
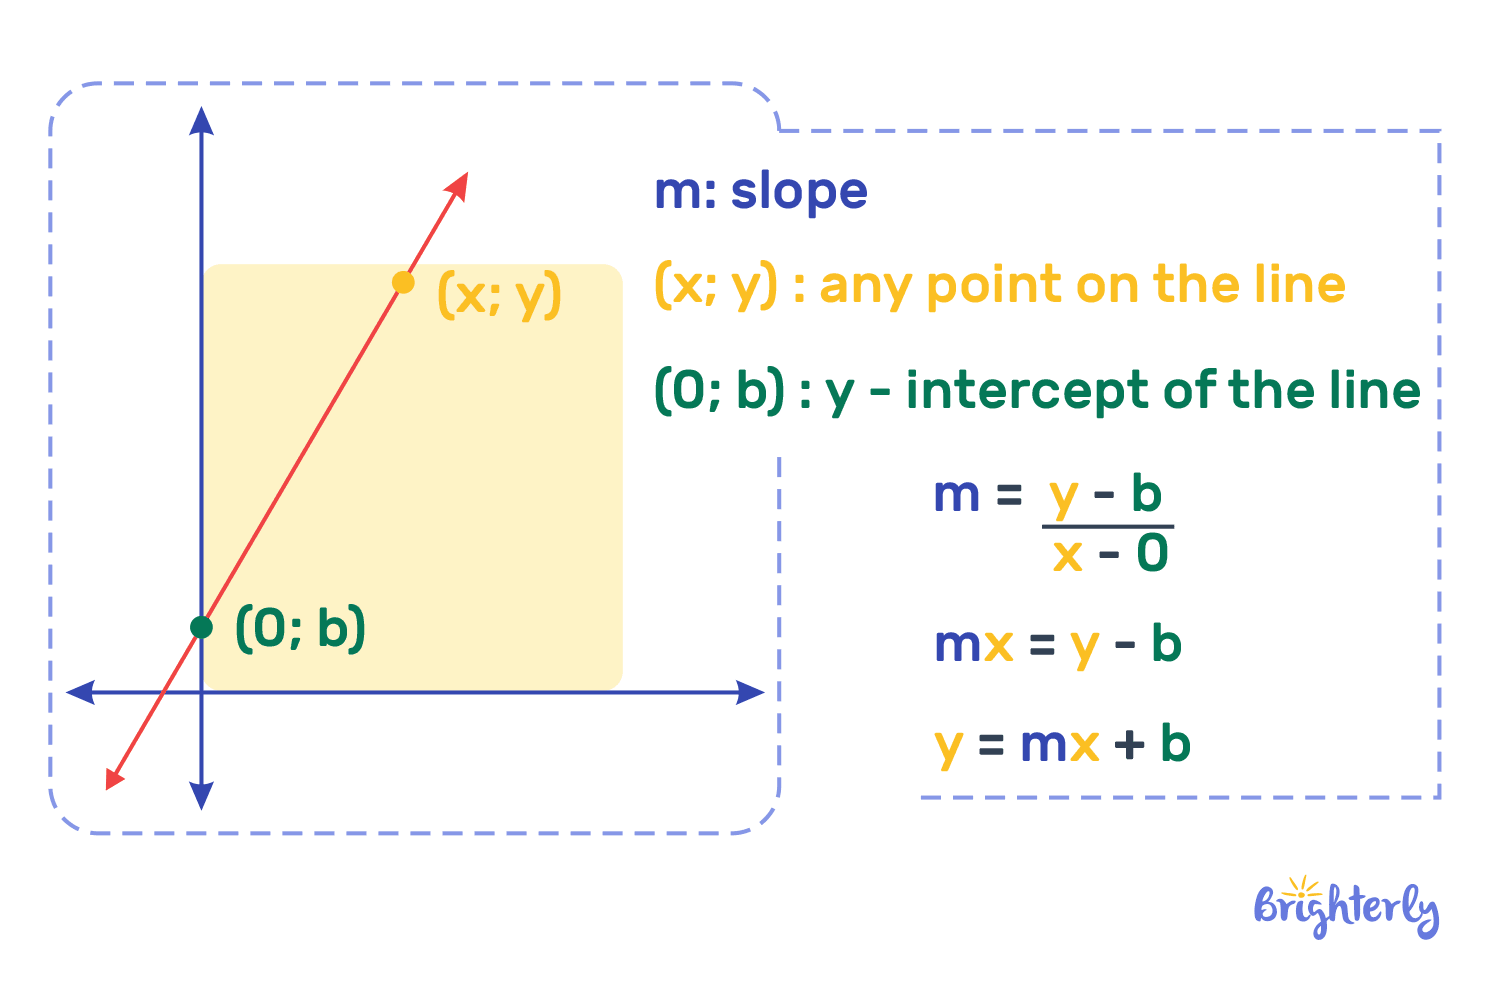
At its core, y = mx + b models a linear relationship where ‘y’ is a dependent variable, ‘x’ is an independent variable, ‘b’ is the y-intercept (the value of y when x is 0), and ‘m’ is the slope of the line. In practical flight technology, this slope ‘m’ is rarely a static value; instead, it dynamically represents the rate at which one variable changes with respect to another. This rate of change is paramount for understanding a drone’s state and predicting its future behavior.
Consider an aircraft’s climb rate: if ‘y’ represents altitude and ‘x’ represents time, then ‘m’ would signify the vertical speed (meters per second or feet per minute). A positive ‘m’ indicates ascent, a negative ‘m’ indicates descent, and an ‘m’ of zero signifies level flight. Similarly, for horizontal movement, if ‘y’ is displacement and ‘x’ is time, ‘m’ directly corresponds to velocity. Beyond simple movement, ‘m’ can represent more abstract rates: the rate of battery drain per minute of flight, the rate of change of an error signal in a control loop, or the sensitivity of a sensor’s output to a physical input. The ubiquitous nature of ‘m’ in describing these dynamic relationships makes linear models, and by extension the principles of y = mx + b, indispensable to every facet of drone flight technology.
Navigating the Skies: Slope in Path Planning and Trajectory
For a drone to execute a predefined mission, it must accurately follow a planned flight path. This path, especially for autonomous operations, is often broken down into a series of waypoints, and the transitions between these waypoints are frequently modeled using linear segments, making the ‘m’ crucial for defining the drone’s trajectory.
Defining Waypoints and Flight Paths
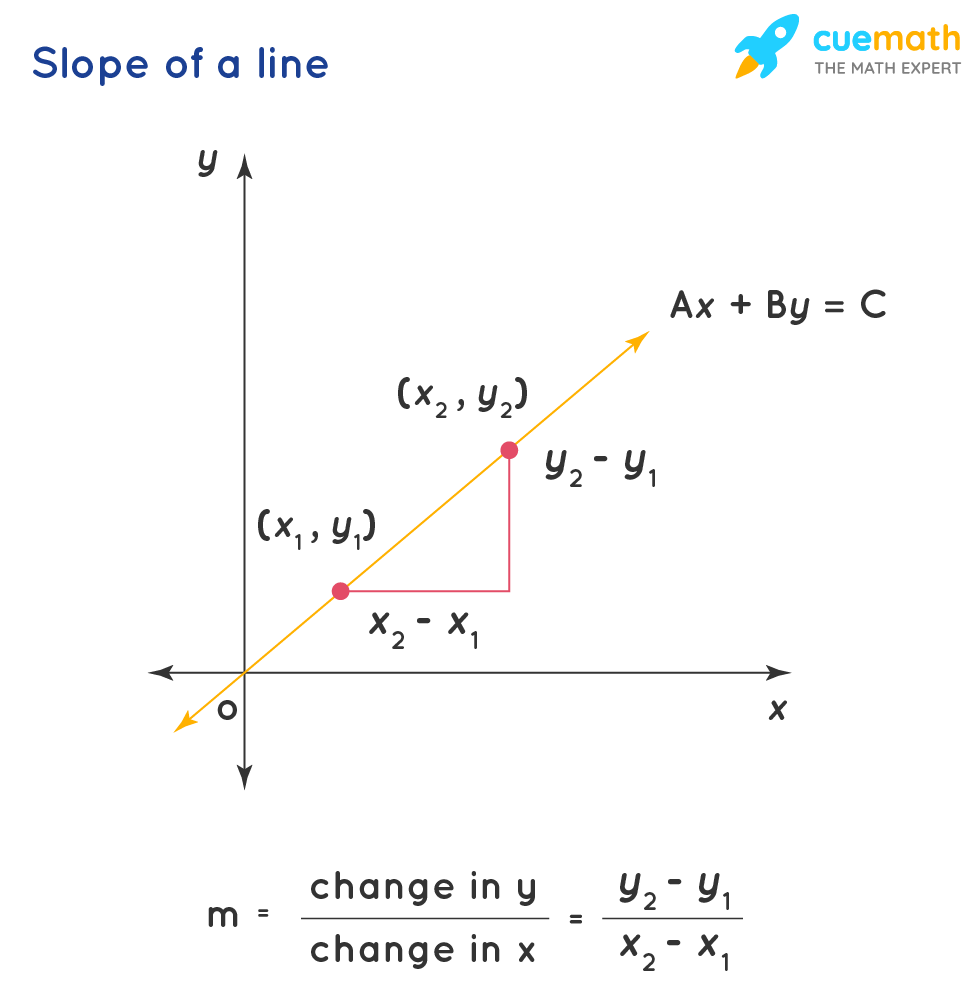
When a drone is tasked with moving from point A to point B, the path can be simplified into a straight line. Here, ‘m’ comes into play to define the exact gradient of this path in both horizontal and vertical dimensions. If point A is at (x1, y1, z1) and point B is at (x2, y2, z2), the slope ‘m’ in the xy-plane (ground speed) would involve (y2-y1)/(x2-x1), while the slope in the z-direction (climb/descent rate) would be (z2-z1) over the horizontal distance or time taken. These slopes dictate the drone’s required velocities along each axis to smoothly transition between waypoints. For multi-waypoint missions, the drone’s flight controller continuously calculates and adjusts its speed and attitude to maintain the target ‘m’ values for each segment, ensuring precise and efficient movement across the mission area.
Predictive Trajectories and Collision Avoidance
Beyond simple waypoint navigation, the concept of ‘m’ is vital for predictive modeling, particularly in collision avoidance systems. By knowing a drone’s current position and its velocity (which is essentially a derivative, or ‘m’, of position over time), the flight computer can project the drone’s future path. If another object (static or moving) is detected, its trajectory can also be analyzed. The system then calculates potential interception points based on the ‘m’ values of both trajectories. If a collision is predicted, the drone’s flight controller can initiate evasive maneuvers by calculating a new ‘m’ for its flight path, defining a new slope for ascent, descent, or lateral movement to steer clear of the obstacle. This real-time calculation and adjustment of ‘m’ is fundamental to safe autonomous flight in complex environments.
Stabilization and Control: The Dynamic Role of ‘m’
Perhaps one of the most critical applications of ‘m’ in flight technology is within the drone’s stabilization and control systems. Maintaining stable flight in the face of varying environmental conditions (like wind gusts) or executing precise maneuvers requires constant adjustments based on the rate of change of the drone’s orientation and position.
Proportional-Integral-Derivative (PID) Control Loops
Modern drones rely heavily on PID controllers to maintain stability and execute commands. A PID controller works by continuously calculating an “error” value as the difference between a desired setpoint (e.g., desired attitude, altitude, or position) and the current measured value. The controller then applies corrections based on three terms: Proportional (P), Integral (I), and Derivative (D).
The Derivative (D) term directly utilizes the concept of ‘m’. It measures the rate of change of the error over time. If the error is rapidly increasing (a large positive ‘m’), the D-term will apply a strong counteracting force to slow down that change, preventing overshoot and dampening oscillations. Conversely, if the error is decreasing rapidly, the D-term will reduce the correction to prevent undershoot. Essentially, ‘m’ here acts as a predictor, anticipating future error based on its current rate of change and applying pre-emptive corrections. This predictive quality is what allows drones to react quickly and smoothly to disturbances or command inputs, preventing jerky movements and maintaining a stable platform.
Responding to Disturbances
When a drone encounters a wind gust, it experiences an external force that pushes it off its desired trajectory or attitude. Sensors on board detect this deviation, and more importantly, they detect the rate at which the drone is being pushed off course. This rate of change is the ‘m’ value that feeds into the PID controller’s derivative term. By responding to the rate of deviation, rather than just the deviation itself, the drone can apply corrective forces that are proportional to how quickly it’s being displaced, effectively counteracting the disturbance and returning to a stable state much faster and more smoothly than if it only reacted to the absolute error. This dynamic response to ‘m’ is what gives drones their characteristic agile and stable flight performance.
Sensor Interpretation and Predictive Performance
For any flight technology system, the ability to accurately interpret sensor data is paramount. Sensors continuously provide raw data that must be processed and understood to inform the flight controller. The concept of ‘m’ plays a crucial role here, both in converting raw sensor outputs into meaningful physical quantities and in enhancing the accuracy and reliability of these readings.
Gyroscopes, Accelerometers, and IMUs
An Inertial Measurement Unit (IMU) typically comprises gyroscopes and accelerometers, providing fundamental data for drone flight. Gyroscopes measure angular rates (e.g., degrees per second of roll, pitch, and yaw). These measurements are direct representations of ‘m’—the rate of change of angle over time. Accelerometers, on the other hand, measure acceleration, which is the rate of change of velocity over time (another ‘m’). By integrating these ‘m’ values over time, the drone’s flight controller can determine its current orientation (attitude) and estimate its velocity and position. Accurate ‘m’ values from these sensors are thus foundational for basic drone control and navigation.
Calibrating Sensors and Filtering Noise
Sensors are rarely perfect; they exhibit biases, drifts, and noise. Linear models, often expressed as y = mx + b, are frequently used for sensor calibration. For instance, the raw output of a sensor (y) might be linearly related to the actual physical quantity (x) with ‘m’ representing the sensor’s sensitivity or gain, and ‘b’ being its offset. Calibrating a sensor involves determining these ‘m’ and ‘b’ values to convert raw readings into accurate physical measurements.
Furthermore, advanced filtering techniques like Kalman filters, widely used in drone navigation, heavily rely on predicting the system’s future state based on its current state and its rates of change (‘m’). By modeling how sensor readings (y) are expected to change over time (x) or under certain conditions, these filters can effectively reduce noise and improve the accuracy of the estimated attitude and position, even when individual sensor readings are noisy or incomplete. The ‘m’ in this context represents the expected dynamics of the system, allowing the filter to differentiate between genuine changes and random fluctuations.
Energy Consumption Modeling
While less direct, ‘m’ can also contribute to predictive performance related to a drone’s endurance. By analyzing flight logs, engineers can model the rate of battery consumption (y) against various flight parameters like speed, payload, or motor RPM (x). A simplified linear model, y = mx + b, can yield an ‘m’ value representing the average consumption rate under specific conditions. This allows flight planning software to estimate remaining flight time more accurately, helping pilots and autonomous systems manage energy resources effectively and plan return-to-home procedures before critical power levels are reached.
In essence, the seemingly simple ‘m’ from y = mx + b is a powerful mathematical concept that underpins the complexity and sophistication of modern flight technology, enabling everything from stable hovering to complex autonomous missions. Its representation of a rate of change is vital for understanding, predicting, and controlling the dynamic world of drones.