
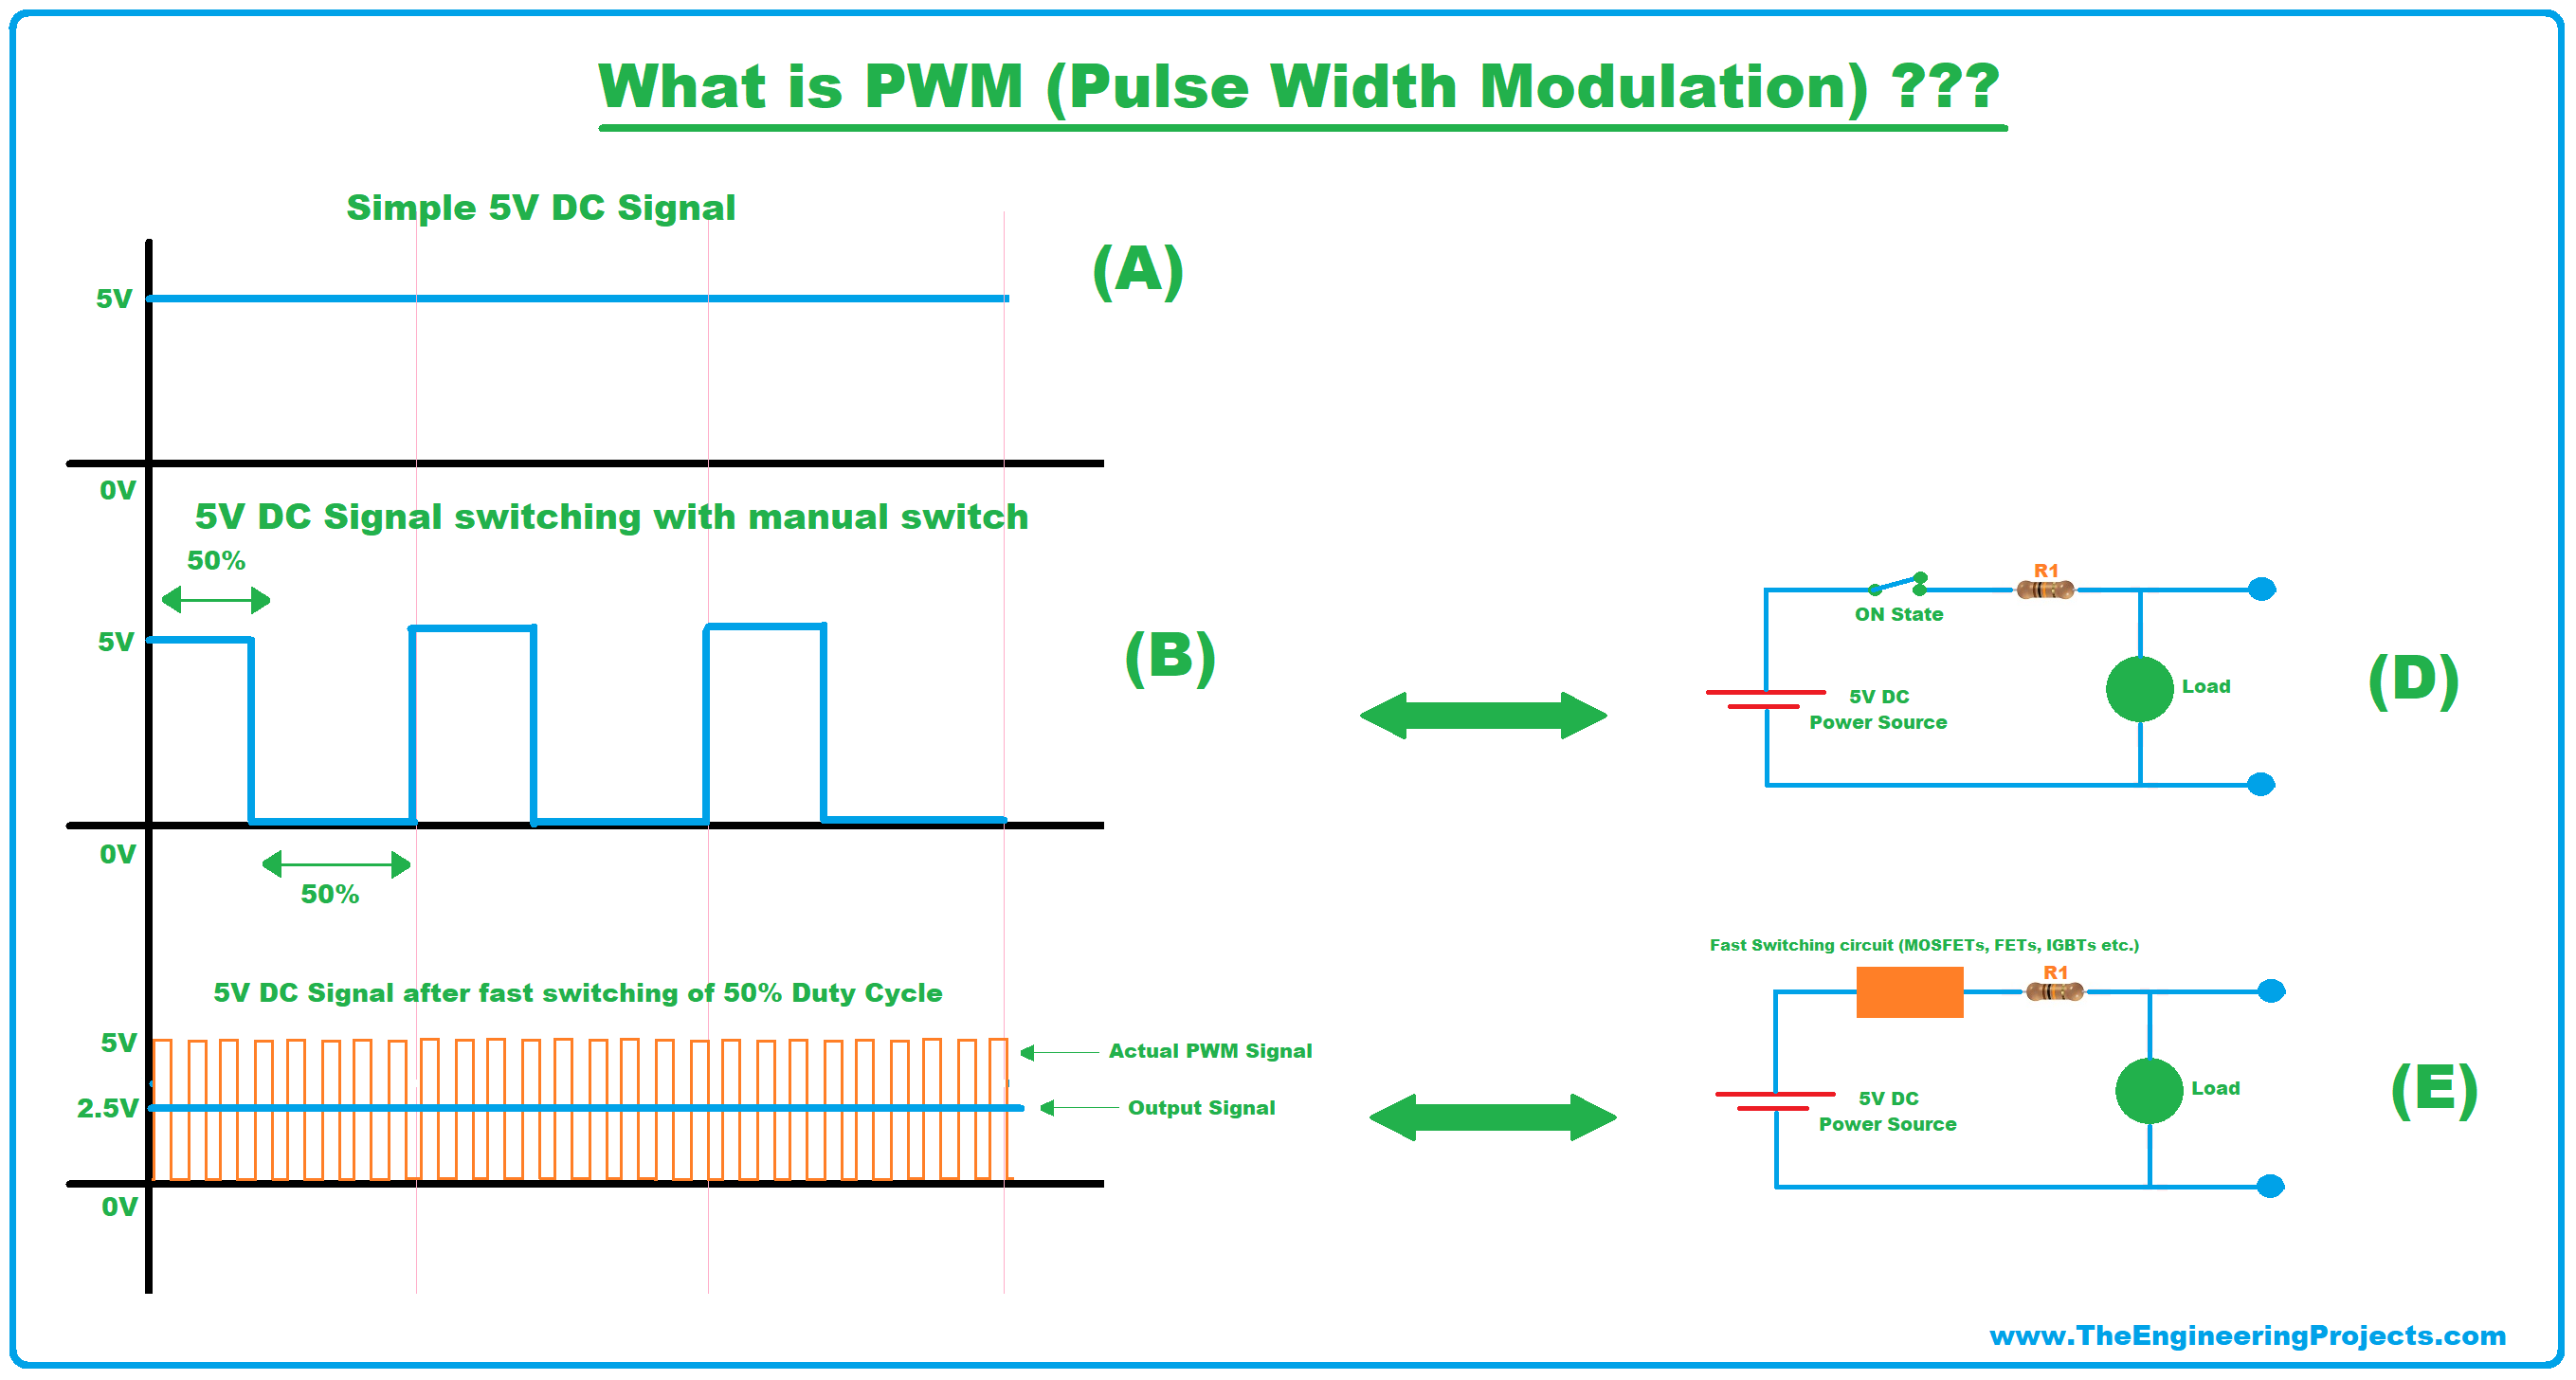
Pulse Width Modulation (PWM) is a fundamental technique used in a wide array of electronic systems, and its application within the realm of drones is both pervasive and critical. While the acronym itself is straightforward – Pulse Width Modulation – understanding its function and implications is key to comprehending how many drone components operate, from motor control to servo actuation. In essence, PWM allows for the control of the average power delivered to a device by rapidly switching a signal on and off. By varying the proportion of time the signal is “on” versus “off” within a fixed period, we can effectively control the output.
The Core Principle of PWM
At its heart, PWM is a digital method for achieving analog-like results. Imagine trying to dim a light bulb. In a simple analog system, you might use a variable resistor to reduce the voltage and current flowing to the bulb. This method, however, is inefficient as the excess energy is dissipated as heat in the resistor. PWM offers a far more efficient alternative.
Understanding the Pulse
A digital signal, by its nature, is either high (on) or low (off). PWM takes advantage of this by sending a series of these pulses. The crucial aspect is the width of these pulses, which dictates the duration the signal remains in the “on” state within a defined cycle.
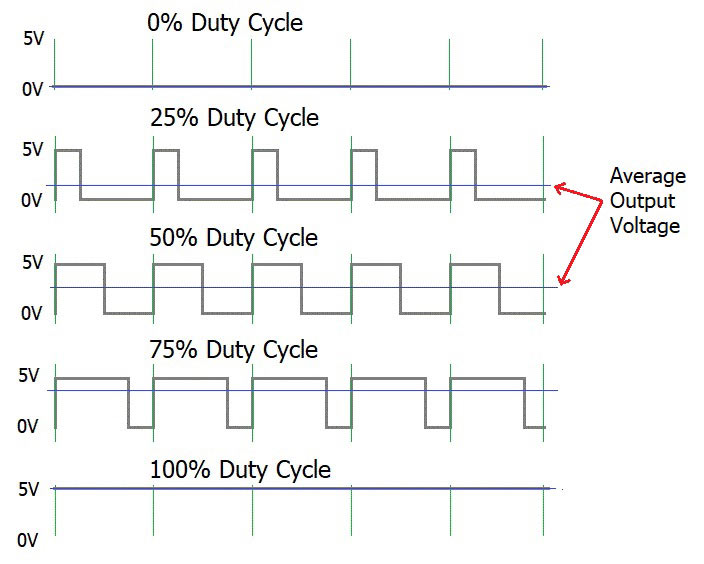
- Duty Cycle: This is the most important parameter in PWM. It’s expressed as a percentage and represents the ratio of the “on” time to the total period of the signal. A 0% duty cycle means the signal is always off, delivering no power. A 100% duty cycle means the signal is always on, delivering full power. A 50% duty cycle means the signal is on for half of the time and off for the other half, effectively delivering half of the maximum power.
High-Frequency Switching
The “modulation” in Pulse Width Modulation refers to the manipulation of this pulse width. The “pulse” part indicates that the signal is a series of discrete on-off states. For PWM to be effective, especially in applications like motor control, these pulses must be generated at a very high frequency, often in the kilohertz (kHz) range. This rapid switching is crucial for several reasons:
- Smooth Output: When applied to a motor, for instance, the rapid on-off cycles trick the motor’s inductance into averaging out the power delivery. The motor doesn’t perceive the individual pulses but rather a continuous current that varies in strength according to the duty cycle. This results in smooth rotational speed control, rather than jerky movements.
- Efficiency: Because the switching elements (like transistors) are either fully on or fully off, they spend very little time in an intermediate state where they would dissipate significant power as heat. This makes PWM an exceptionally efficient method for power control compared to linear voltage regulation.
PWM in Drone Motor Control
The most prominent application of PWM in drones is undoubtedly in the control of brushless DC (BLDC) motors. These motors are the workhorses of modern multirotors, providing the thrust necessary for flight. Each motor is typically connected to an Electronic Speed Controller (ESC), and it’s the ESC that receives and interprets PWM signals.
How ESCs Use PWM
An ESC’s primary function is to take a control signal and translate it into the appropriate power delivery to the BLDC motor. The drone’s flight controller generates a PWM signal for each motor, indicating the desired speed.
- Signal Interpretation: The flight controller sends a PWM signal to the ESC, typically with a pulse width that corresponds to the desired motor speed. For example, a longer pulse width might signify a higher speed, while a shorter pulse width indicates a lower speed.
- Three-Phase Commutation: BLDC motors have three windings (phases). The ESC sequentially energizes these windings to create a rotating magnetic field, which in turn spins the motor. The timing and duration of energizing each phase are precisely controlled, often using PWM. The PWM signal from the flight controller dictates the rate at which these phases are switched and the power delivered to each phase, thereby controlling the motor’s RPM.
- Frequency and Resolution: The PWM frequency used for motor control is typically in the range of 400 Hz to 20 kHz or even higher. Higher frequencies can lead to smoother motor operation and faster response times, but they also place greater demands on the ESC’s processing power and the flight controller’s output. The resolution of the PWM signal (how many distinct duty cycle levels are available) also affects the fineness of motor speed control.
Advantages in Motor Control
The adoption of PWM for motor control in drones is due to several key advantages:
- Precise Speed Regulation: PWM allows for very fine control over motor RPM, which is essential for stable flight and precise maneuvering.
- High Efficiency: As mentioned, PWM is highly efficient, meaning less battery power is wasted as heat. This translates to longer flight times and less strain on components.
- Compact and Lightweight: ESCs designed for PWM control are generally compact and lightweight, which is a critical consideration for drone design where every gram matters.
- Responsiveness: The rapid switching enabled by PWM allows for quick adjustments to motor speed in response to changes in attitude or control inputs.
PWM for Servo Actuation
Beyond motor control, PWM is also the standard method for controlling servos. Servos are commonly used in drones for various functions, such as tilting cameras, deploying landing gear, or even actuating control surfaces on fixed-wing drones.
Servo Control Mechanism
RC (Radio Control) servos are designed to move to a specific angular position and hold that position. This is achieved through a feedback mechanism within the servo itself, driven by an incoming PWM signal.
- Position Encoding: The PWM signal sent to a servo typically has a pulse width that directly corresponds to the desired angular position. A standard servo signal might have a pulse width ranging from 1 millisecond (ms) to 2 ms, with 1.5 ms representing the center position.
- Internal Feedback Loop: Inside the servo, a small motor is driven by a pulse width modulated signal. This motor is connected to a potentiometer that measures the current position of the servo horn. A control circuit compares the incoming PWM signal (representing the target position) with the position reported by the potentiometer. If the positions don’t match, the control circuit adjusts the PWM signal to the servo motor, causing it to move until the target position is reached.
- Frequency: The typical PWM frequency for servo control is around 50 Hz (a period of 20 ms). This is much lower than the frequency used for motor control, as servos are mechanical devices with inherent inertia and do not require such rapid updates.
Applications in Drone Servos
The precise positional control offered by PWM makes it ideal for:
- Gimbal Stabilization: Servos controlled by PWM are fundamental to camera gimbals, allowing them to pan, tilt, and roll independently of the drone’s movement to keep the camera steady or frame a specific subject.
- Variable Pitch Propellers: In some advanced drone designs, servos are used to adjust the pitch of propellers, offering greater control over thrust and efficiency.
- Payload Deployment: Servos can be used to release payloads or trigger mechanisms on a drone.
Other Applications and Considerations
While motor and servo control are the most prominent uses, PWM finds its way into other aspects of drone technology.
Lighting and Indicator Control
LEDs on drones, used for navigation, status indication, or even aesthetic purposes, can also be controlled using PWM. By varying the duty cycle of the PWM signal to the LEDs, their brightness can be adjusted. This is particularly useful for managing power consumption, as brighter lights naturally draw more current.
Data Transmission (Less Common)
In some niche applications or during development, PWM signals might be used for simple data transmission between microcontrollers or components, although more robust serial communication protocols are generally preferred for complex data exchange.
PWM Signal Generation
Generating PWM signals in drones typically involves dedicated hardware modules within microcontrollers or specialized ICs.
- Hardware Timers: Most microcontrollers used in flight controllers and ESCs feature built-in hardware timers capable of generating precise PWM outputs. These timers can be configured with a specific period and duty cycle, offloading the task from the main CPU and ensuring high accuracy and stability.
- Software PWM: While possible, generating PWM entirely in software is generally less desirable for critical applications like motor control. Software PWM is susceptible to timing variations caused by other processes running on the microcontroller, which can lead to inconsistent performance and reduced efficiency. However, for less critical functions like dimming LEDs, software PWM might be sufficient.
Challenges and Best Practices
Despite its ubiquity, effective use of PWM requires attention to certain details:
- Noise: High-frequency switching can generate electromagnetic interference (EMI). Proper filtering, shielding, and grounding are essential to prevent noise from affecting other sensitive electronics on the drone, such as the flight controller’s sensors.
- Timing Jitter: Variations in the PWM pulse width (jitter) can lead to inconsistent motor speeds or servo positions. Using hardware timers and ensuring proper power supply stability are key to minimizing jitter.
- Signal Integrity: For long signal traces, ensuring the integrity of the PWM signal is important. Impedance matching and proper termination can help prevent signal degradation.
In conclusion, the seemingly simple acronym PWM – Pulse Width Modulation – underpins the sophisticated control systems that enable modern drones to fly, maneuver, and perform their diverse tasks. From the powerful thrust of its motors to the precise articulation of its camera gimbal, PWM is the invisible force that translates digital commands into physical motion, making it a cornerstone of drone technology.