
The Interquartile Range (IQR) is a vital statistical measure that provides a concise summary of the variability or spread of a dataset. While other measures like the range offer a broad overview, the IQR hones in on the middle 50% of the data, making it less susceptible to outliers and more representative of the typical dispersion. In the realm of drone technology, understanding and applying the IQR can unlock deeper insights into flight performance, sensor accuracy, and operational consistency, ultimately leading to more reliable and effective aerial operations.
Understanding the Fundamentals of IQR
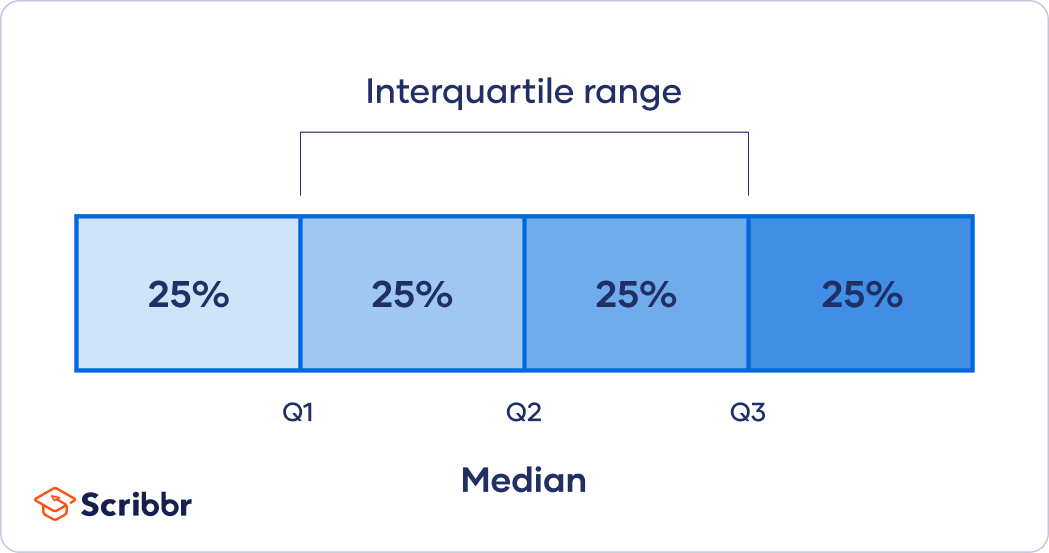
At its core, the IQR is the difference between the third quartile (Q3) and the first quartile (Q1) of a dataset. To grasp this, we first need to define quartiles. Quartiles divide a sorted dataset into four equal parts.

Defining Quartiles
- Q1 (First Quartile): This is the median of the lower half of the dataset. It represents the value below which 25% of the data falls.
- Q2 (Second Quartile): This is the overall median of the dataset, representing the value below which 50% of the data falls.
- Q3 (Third Quartile): This is the median of the upper half of the dataset. It represents the value below which 75% of the data falls.
Calculating the IQR
The calculation is straightforward:
$$IQR = Q3 – Q1$$
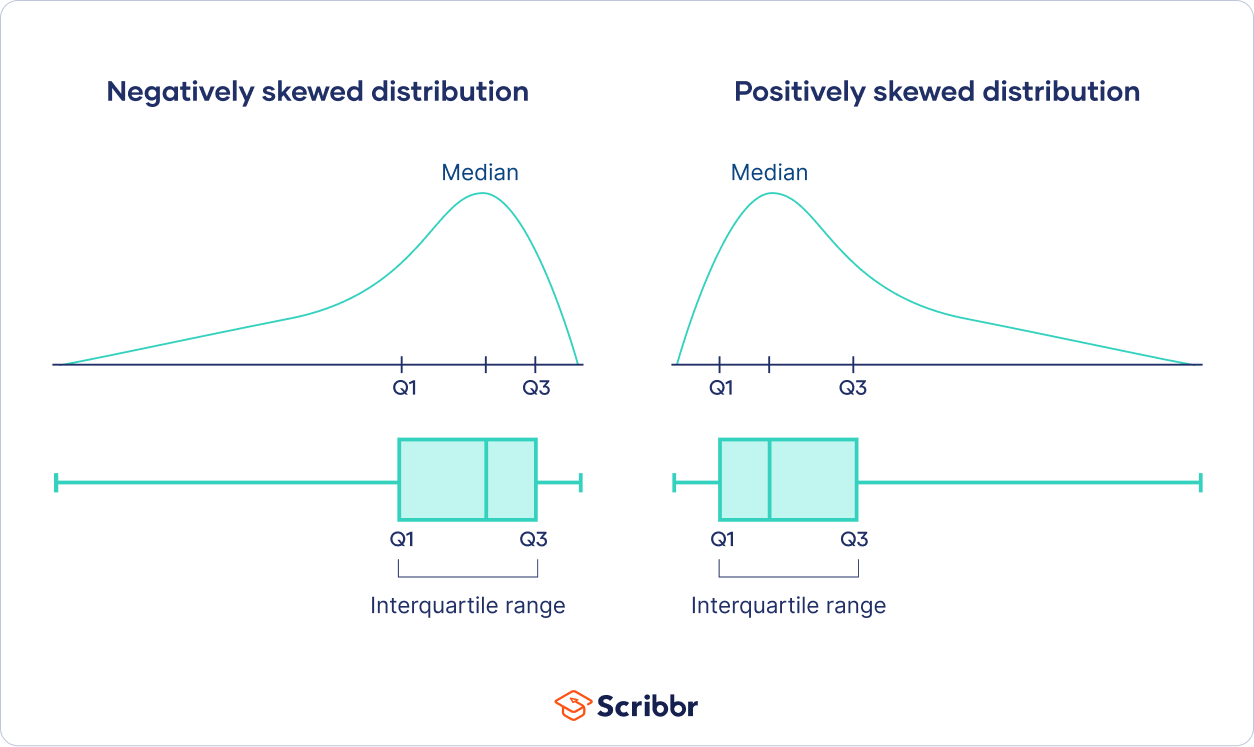
The resulting IQR value quantifies the spread of the central 50% of your data. A smaller IQR indicates that the middle portion of your data is tightly clustered, suggesting consistency. Conversely, a larger IQR implies a wider spread in the middle 50% of the data, suggesting greater variability.
Why IQR is Superior to Range
The standard range, calculated as the maximum value minus the minimum value, can be heavily influenced by extreme data points – outliers. For instance, if a drone’s altitude readings show a range from 50 meters to 200 meters, but 99% of the readings are between 90 and 110 meters, the range of 150 meters is misleading about the typical altitude performance. The IQR, focusing on the central data, would provide a much more accurate picture of the drone’s typical altitude stability. This robustness makes the IQR a preferred metric for analyzing performance characteristics in dynamic systems like drones.
Applications of IQR in Drone Flight Performance
The variability in drone flight can stem from numerous factors, including environmental conditions, sensor noise, control system responses, and mechanical inconsistencies. The IQR offers a powerful tool to quantify and understand this variability, enabling engineers and operators to identify areas for improvement and ensure mission success.
Analyzing Altitude Stability
Maintaining a precise altitude is crucial for many drone operations, from aerial surveying and inspection to payload delivery. Variations in altitude can be caused by wind gusts, atmospheric pressure changes, or imperfections in the drone’s barometric or GPS altitude sensors.
- Monitoring Sensor Drift: By calculating the IQR of altitude readings over a period of stable flight, one can assess the inherent variability of the altitude measurement system. A consistently low IQR suggests stable altitude holding, while a fluctuating or high IQR might indicate sensor issues or inadequate compensation for environmental factors.
- Evaluating Autopilot Performance: The IQR can be used to compare the altitude stability of different autopilot algorithms or firmware versions. By flying the same mission profile under identical conditions and comparing the IQRs of altitude data, the performance of each system can be quantitatively assessed.
- Detecting Anomalies: A sudden increase in the IQR of altitude readings during a flight could signal a developing issue, such as a malfunctioning motor or a sensor problem, prompting immediate investigation.
Assessing Horizontal Position Accuracy and Drift
Similar to altitude, maintaining a stable horizontal position is critical, especially for tasks requiring precise spatial positioning, like photogrammetry or guided navigation. GPS accuracy, wind, and control system responsiveness all contribute to horizontal position variability.
- Quantifying GPS Noise: While GPS inherently has some error, the IQR of position coordinates (e.g., latitude, longitude) over a stationary period can reveal the level of noise or instability in the GPS receiver’s output. A tighter IQR suggests a more reliable GPS lock and less position jitter.
- Evaluating Navigation System Responsiveness: During controlled flight maneuvers or when holding a specific waypoint, the IQR of position data can indicate how well the navigation system is correcting for disturbances. A low IQR implies precise and rapid corrections, while a high IQR might suggest sluggish control responses or persistent drift.
- Mapping Flight Path Consistency: For autonomous missions involving complex flight paths, the IQR of deviations from the planned path can quantify the path’s fidelity. This is particularly useful in applications like agricultural spraying or pipeline inspection, where precise coverage is paramount.
Understanding Gimbal and Camera Stabilization
The quality of aerial footage is heavily dependent on stable camera platforms. While gimbals are designed to counteract drone movements, their effectiveness can be assessed using IQR on stabilization data.
- Quantifying Jitter: The IQR of tilt, pan, or roll angles reported by the gimbal’s internal sensors during flight can directly measure the amount of residual camera shake or jitter. A low IQR indicates smooth, stable footage, while a high IQR suggests the gimbal is struggling to compensate for vibrations or external forces.
- Assessing Response to Maneuvers: During aggressive drone maneuvers, the IQR of gimbal angles can reveal how well the stabilization system is keeping the camera steady. A consistently low IQR throughout various flight dynamics signifies superior stabilization performance.
- Identifying Vibration Sources: If the IQR of gimbal data increases significantly, it might point to an increase in vibrations originating from the drone’s motors or airframe, prompting a maintenance check.
IQR in Drone Sensor Data Analysis
Beyond basic flight parameters, drones are equipped with a suite of sensors that collect diverse data. The IQR is invaluable for understanding the consistency and reliability of these sensor readings.
Thermal Imaging Consistency
Thermal cameras capture infrared radiation, providing temperature maps of the environment. For applications like infrastructure inspection (e.g., identifying hot spots in electrical equipment) or search and rescue, the consistency of temperature readings is crucial.
- Analyzing Temperature Fluctuation: For a specific, uniformly emitting object in a thermal image, the IQR of pixel values within its detected area can indicate the stability of the temperature reading. A low IQR means the detected temperature is consistent across the object, suggesting accurate measurement. A high IQR might point to sensor noise, environmental interference, or an inconsistent target.
- Assessing Emissivity Correction: When dealing with different materials and their varying emissivity, understanding the IQR of readings from known uniform surfaces can help calibrate or validate emissivity correction algorithms.
LiDAR Point Cloud Density and Uniformity
LiDAR sensors generate dense point clouds, essential for creating detailed 3D models and performing measurements. The distribution and consistency of these points are critical for accuracy.
- Evaluating Point Density Variation: Within a scanned area, the IQR of the number of LiDAR points per unit area can highlight regions of sparser or denser coverage. A low IQR in this metric suggests a uniform point cloud density, which is generally desirable for consistent data capture. A higher IQR might indicate areas where the scanner’s performance degraded due to range, angle, or atmospheric conditions.
- Analyzing Range Measurement Consistency: For static targets, the IQR of distance measurements from the LiDAR can reveal the precision of the sensor. A tight IQR indicates highly repeatable and precise range measurements.
Multispectral and Hyperspectral Data Integrity
These advanced sensors capture images across numerous narrow spectral bands, used in precision agriculture, environmental monitoring, and research. Consistency across these bands is vital for analysis.
- Assessing Band-to-Band Consistency: For a uniform surface, the IQR of reflectance values across different spectral bands can reveal the stability of the sensor’s response. This helps identify potential calibration issues or the influence of atmospheric conditions on specific wavelengths.
- Monitoring Vegetation Health Indicators: In agriculture, indices derived from multispectral data (e.g., NDVI) can have their variability assessed using IQR. A low IQR in NDVI readings over a healthy crop canopy indicates uniform health, while a higher IQR might suggest variability in nutrient uptake, water stress, or pest infestation.
IQR in Drone Operational Reliability and Safety
Beyond performance metrics, the IQR contributes significantly to assessing the overall reliability and safety of drone operations.
Battery Performance Consistency
Understanding how battery capacity and discharge rates vary is essential for mission planning and safety.
- Analyzing Voltage Sag: During flight, the IQR of battery voltage readings can reveal the extent of voltage sag under load. A larger IQR might indicate that the battery’s internal resistance is high, or that the drone is drawing power erratically.
- Predicting Remaining Flight Time: By analyzing the IQR of power consumption over time, more robust predictions of remaining flight time can be made, accounting for typical operational variability rather than relying on simple average consumption.
Motor Performance and Vibration Analysis
Motor health is paramount for flight stability and safety. Consistent motor performance means predictable torque and RPM.
- Assessing RPM Variability: The IQR of motor RPM readings can indicate the smoothness of motor operation. A high IQR might suggest motor imbalance, bearing wear, or control system inconsistencies.
- Detecting Vibration Signatures: By analyzing the IQR of vibration sensor data (accelerometers or gyroscopes) at specific motor speeds, anomalies that might indicate developing mechanical issues can be identified before they lead to catastrophic failure.
Flight Controller Output Consistency
The flight controller is the brain of the drone, sending commands to the motors. The consistency of these commands is crucial for stable flight.
- Evaluating Control Signal Stability: The IQR of the raw control signals sent to the Electronic Speed Controllers (ESCs) can reveal the level of “nervousness” or instability in the flight controller’s output. A low IQR indicates smooth, stable commands, while a high IQR might suggest oscillations or erratic behavior that could lead to flight instability.
By applying the principles of the Interquartile Range to these diverse aspects of drone technology, operators and manufacturers can move beyond simple averages and ranges to gain a more nuanced and reliable understanding of performance, identify potential issues proactively, and ultimately enhance the safety and effectiveness of aerial systems. The IQR provides a statistical lens through which to view the variability inherent in complex technological systems, turning raw data into actionable intelligence for innovation and operational excellence.