
In the rapidly evolving world of drone technology and innovation, the concept of “interdependence” is not merely a buzzword but a fundamental principle that underpins the most advanced capabilities we see today, from autonomous flight to sophisticated mapping and remote sensing. At its core, interdependence describes a relationship where two or more components, systems, or entities are mutually reliant on each other. In the context of drone innovation, this means that the performance, intelligence, and functionality of one aspect are intricately tied to and often contingent upon the proper functioning, data, and outputs of others. It signifies a complex web of mutual reliance, where the whole is far greater than the sum of its individual parts, enabling drones to perform tasks that were once in the realm of science fiction.

The Foundation of Modern Drone Capabilities
The journey from basic remote-controlled aircraft to intelligent, autonomous platforms is a testament to the power of interdependence. Early drones were essentially flying camera platforms, with minimal interaction between their flight systems and their payload. Today, innovation thrives on the seamless integration and mutual reliance of diverse technologies, creating a unified operational entity.
Beyond Standalone Systems
Gone are the days when a drone’s camera operated in isolation from its flight controller, or its navigation system functioned without feedback from its environment sensors. Modern drone innovation demands a holistic approach where individual systems – such as GPS modules, Inertial Measurement Units (IMUs), cameras, LiDAR sensors, flight control algorithms, and Artificial Intelligence (AI) processing units – are no longer standalone. Instead, they form a cohesive ecosystem. For instance, an AI follow mode doesn’t just “see” an object; it relies on high-precision GPS data for positioning, IMU data for stable flight, and sophisticated flight control algorithms to execute maneuvers that keep the target in frame. The failure or degraded performance of any one of these interdependent systems directly impacts the overall capability, highlighting their critical mutual reliance.
The Synergy of Hardware and Software
Interdependence in drone tech is a profound synergy between hardware and software. High-fidelity sensors (hardware) collect raw data, but it is the sophisticated algorithms and AI (software) that process, interpret, and act upon this data. Conversely, cutting-edge software requires equally advanced hardware to execute complex computations in real-time. An example is the relationship between a high-resolution thermal camera (hardware) and advanced image processing algorithms (software) used for remote sensing in agriculture. The camera provides the thermal signatures, but the software analyzes these patterns to identify crop stress, measure plant health, and recommend precise irrigation or fertilization. Neither component can deliver the full innovative capability without the other; their interaction is fundamentally interdependent.
Interdependence in Autonomous Flight
Autonomous flight represents one of the most compelling demonstrations of interdependence in drone technology. Achieving true autonomy – where a drone can make decisions, navigate complex environments, and complete missions without direct human intervention – requires an intricate dance between numerous interdependent systems.
Sensor Fusion as a Cornerstone
At the heart of autonomous flight is sensor fusion, a prime example of interdependence. Drones employ a myriad of sensors: GPS for global positioning, IMUs (accelerometers and gyroscopes) for orientation and motion, barometers for altitude, magnetometers for heading, vision cameras for object detection and visual odometry, and LiDAR or ultrasonic sensors for obstacle avoidance and distance measurement. Each sensor provides a piece of the puzzle, but none offers a complete picture alone. Sensor fusion algorithms, therefore, are designed to combine data from multiple, diverse sensors to achieve a more accurate, robust, and comprehensive understanding of the drone’s state and environment than any single sensor could provide. For instance, GPS provides absolute position but can drift; IMUs offer precise relative motion but accumulate error over time. By fusing their data, the drone achieves both accurate absolute positioning and stable, drift-corrected motion tracking. This mutual reliance is non-negotiable for safe and effective autonomous operations.
AI and Machine Learning: Data-Driven Decisions
The intelligence of autonomous drones stems largely from Artificial Intelligence and Machine Learning (AI/ML) algorithms, which are deeply interdependent with the sensory data they consume and the control systems they influence. AI models for object recognition, path planning, and anomaly detection are trained on vast datasets derived from real-world sensor inputs. Their ability to make informed decisions – such as identifying a moving target for AI follow mode, recognizing a hazardous object, or optimizing a flight path around dynamic obstacles – is directly interdependent with the quality and breadth of the data they receive from the drone’s sensor array. Furthermore, the AI’s output (e.g., a command to adjust speed or direction) becomes an input for the flight control system, which then executes the physical maneuver. This creates a continuous, interdependent feedback loop where perception informs decision-making, which in turn informs action, constantly refining the drone’s autonomous behavior.
Navigation and Control Loop Dynamics
The navigation and control systems of an autonomous drone are perhaps the most acutely interdependent elements. The navigation system, informed by sensor fusion and AI, determines the drone’s current position, orientation, and velocity relative to its mission objectives and environment. This information is then fed to the flight controller, which calculates the necessary motor commands and control surface adjustments to achieve the desired flight state (e.g., maintaining altitude, following a waypoint, or avoiding a collision). The flight controller’s actions, in turn, affect the drone’s physical state, which is then measured by the sensors, providing new inputs for the navigation system. This continuous, real-time control loop is a quintessential example of interdependence, where each stage is utterly reliant on the output of the preceding one and directly influences the input for the next, ensuring stable, precise, and autonomous flight.
Mapping and Remote Sensing: A Web of Reliance
Drone-based mapping and remote sensing applications are transformative tools for industries ranging from agriculture and construction to environmental monitoring and urban planning. These capabilities are built upon a sophisticated web of interdependent technologies that work in concert to acquire, process, and interpret spatial data.
Data Acquisition and Geo-referencing
Accurate mapping and remote sensing are profoundly interdependent on the precise acquisition and geo-referencing of data. High-resolution cameras, multispectral sensors, or LiDAR units capture imagery or point cloud data. However, this raw data is largely useless for mapping without precise location information. This is where GPS (or more advanced GNSS systems) and IMUs become critically interdependent with the sensors. The GPS provides the drone’s global coordinates, while the IMU measures its exact orientation (pitch, roll, yaw) at the moment each data point is captured. Sophisticated software then combines this information to “geo-reference” the data, meaning it accurately places each pixel or point in its real-world geographical location. Without this interdependent data fusion, mapping would be inaccurate or impossible, rendering the innovative application ineffective.
Processing Power and Algorithm Interplay
Once collected, the vast amounts of data generated by mapping and remote sensing drones require immense processing power and complex algorithmic interplay. Photogrammetry software, for example, relies on algorithms to stitch together thousands of overlapping images into a seamless 2D orthomosaic map or a 3D model. This process is highly interdependent, as the accuracy of the final map depends on the quality of individual images, the precision of their geo-referencing, and the sophistication of the algorithms used for feature matching and geometric reconstruction. Similarly, in remote sensing, specific algorithms are interdependent with the spectral data collected by multispectral or hyperspectral cameras to calculate indices like NDVI (Normalized Difference Vegetation Index) for plant health assessment. The algorithms are designed to extract specific information from the sensor data, and the data’s integrity directly impacts the algorithms’ output.
Real-time Feedback and Adaptive Planning
Innovative mapping and remote sensing often involve dynamic, real-time interdependence. For instance, in precision agriculture, a drone might conduct an initial survey to identify areas of plant stress. This data is immediately processed (often on-board via edge computing), and the results are fed back to the drone’s flight planning system. The system then adaptively modifies the drone’s subsequent flight path or payload settings to collect more detailed data from the stressed areas or even to trigger an on-board spraying mechanism. This closed-loop system showcases a high degree of interdependence between data acquisition, processing, decision-making (AI), and autonomous mission adaptation, delivering highly efficient and targeted solutions.
The Future of Interconnected Drone Innovation
The concept of interdependence will only deepen as drone technology continues to evolve, pushing the boundaries of what is possible. Future innovations will increasingly leverage even more complex, multi-layered interdependencies to achieve unprecedented levels of autonomy, efficiency, and intelligence.
Swarm Robotics and Collaborative Systems
One of the most exciting frontiers is swarm robotics, where multiple drones operate collaboratively as a single, interdependent system. In a drone swarm, individual units communicate and share information about their environment, tasks, and positions. The success of the collective mission—whether it’s large-scale mapping, search and rescue, or synchronized aerial displays—is entirely interdependent on the reliable communication, coordination algorithms, and mutual awareness between each drone in the swarm. A failure in one drone’s communication or navigation system could impact the behavior and safety of the entire group, underscoring the profound level of mutual reliance.
Edge Computing and Decentralized Intelligence
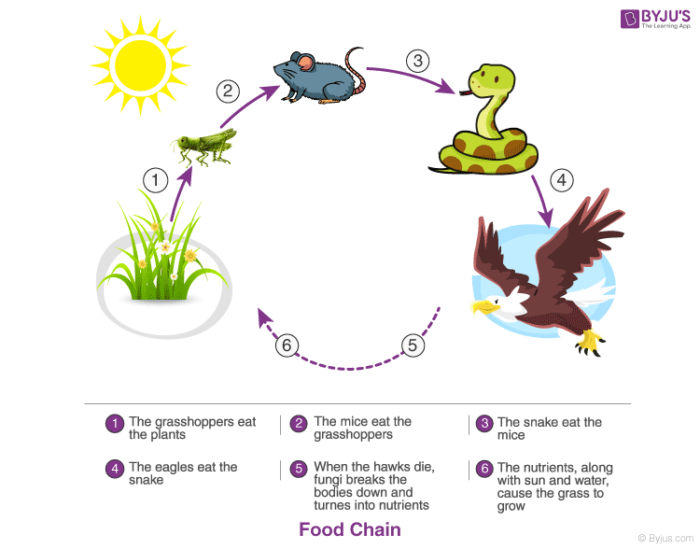
The move towards edge computing in drones signifies a growing interdependence between on-board processing power and cloud-based resources. Instead of sending all raw data to the cloud for processing, drones equipped with powerful edge processors can analyze data locally in real-time. This reduces latency and bandwidth requirements, enabling faster decision-making for autonomous operations. However, this local intelligence is still interdependent with periodic updates, machine learning model enhancements, and larger data aggregation tasks that typically occur in the cloud. The system operates as a decentralized intelligence network, where local processing capabilities are mutually reliant on central intelligence for continuous improvement and broader context.
Addressing Complexity and Ensuring Robustness
As the interdependence of drone systems grows, so does the complexity of their design and operation. Future innovations will focus not only on creating new interdependencies but also on managing them to ensure robustness and reliability. This involves developing advanced self-healing algorithms, fault-tolerant architectures, and sophisticated simulation environments that can predict and mitigate potential points of failure within these intricate interdependent networks. The ability of a drone system to autonomously detect, diagnose, and recover from failures in one of its interdependent components will be critical for unlocking new levels of safety and operational capability, especially in mission-critical applications. Understanding and mastering the dynamics of interdependence is, therefore, central to unlocking the full potential of drone technology and driving the next wave of innovation.