
While the human body’s experience of gout involves acute, debilitating inflammation in a joint, often the big toe—a “foot” ailment—the world of advanced flight technology presents its own analogous vulnerabilities. In the intricate ecosystem of an unmanned aerial vehicle (UAV), a “gout-like” condition can manifest as a localized, critical system anomaly, often concentrated in components responsible for ground interaction, sensory data acquisition, or fundamental flight control. Understanding what such a “gout” feels like in the “foot” of a drone—its base systems, sensors, and ground-facing technologies—is crucial for maintaining operational integrity, ensuring flight stability, and preventing catastrophic failure. This exploration delves into how localized critical failures impact drone flight technology, examining their manifestations, diagnostic challenges, and preventative measures.
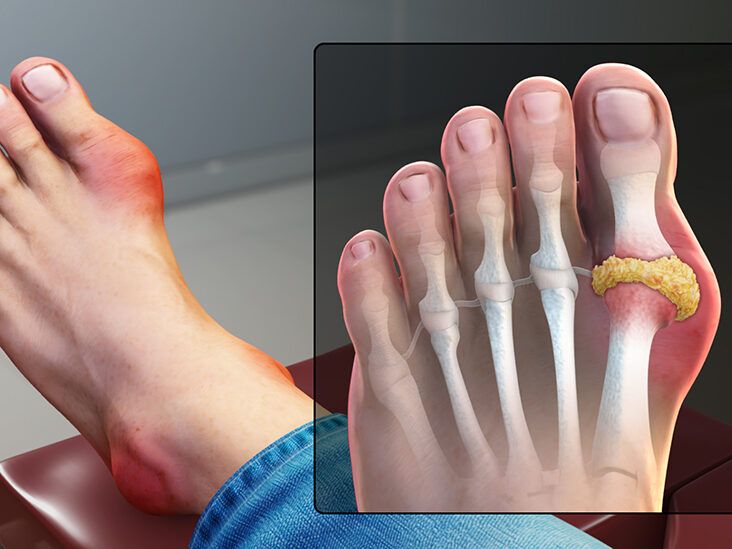
The Metaphor of Systemic Localized Failure in Drone Flight Technology
In the context of drone flight technology, the metaphor of “gout” describes an acute, sudden, and often severely debilitating malfunction localized within a critical subsystem or sensor. Just as human gout can incapacitate a limb, drone “gout” can compromise a fundamental aspect of flight, navigation, or control. The “foot” in this analogy represents the drone’s primary interface with its environment, its foundational sensory inputs, or its structural components that bear the brunt of interaction—such as landing gear, ground-facing altimeters, visual odometry cameras, or specific motor/ESC (Electronic Speed Controller) units at the base of its propulsion system. A localized failure in these areas can propagate rapidly, leading to erratic behavior, loss of stability, or even a crash.
Sensor Data Integrity and the “Inflammation” of Malfunction
The lifeblood of modern flight technology is data, primarily streamed from an array of sophisticated sensors. An inertial measurement unit (IMU), consisting of accelerometers and gyroscopes, provides critical attitude and velocity data. GPS modules offer positional fixes, while magnetometers supply heading information. Barometric altimeters determine altitude, and increasingly, ultrasonic or LiDAR sensors provide precise ground clearance measurements.
When one of these sensors develops “gout,” it’s akin to an acute inflammation of data integrity. This could manifest as:
- Spurious Readings: A ground-facing ultrasonic sensor might suddenly report wildly inaccurate distances, perhaps due to a physical obstruction, electromagnetic interference, or an internal fault. This influx of “inflamed” data can cause the flight controller to make erroneous altitude adjustments, leading to sudden dips or ascents.
- Intermittent Signal Loss: A GPS receiver might intermittently lose its fix or report position data with significantly degraded accuracy. If this happens while the drone is executing a precise navigation path or hovering, the flight controller’s attempts to maintain position without reliable data can result in erratic drift or unexpected movements.
- Bias Drift or Noise Spikes: An accelerometer within the IMU might develop an unexpected bias or suffer from sudden, localized spikes in noise. Such “painful” data points can mislead the flight controller about the drone’s true acceleration, causing overcorrection or instability, especially during dynamic maneuvers or rapid changes in velocity.
The “inflammation” here is the corruption or unreliability of data, localized to a specific sensor or subsystem. The flight controller, acting as the drone’s central nervous system, processes this “inflamed” data, attempting to reconcile it with other sensor inputs. If the discrepancy is too great, or if the faulty sensor is deemed critical, the system’s stability can be severely compromised.
Landing Gear and Ground Interaction: The Drone’s “Foot”
The literal “foot” of a drone often encompasses its landing gear, the motors and propellers that push against the air, and any sensors specifically oriented towards the ground. A “gout” in this literal “foot” can have immediate and dramatic consequences.
- Motor or ESC Failure: A localized fault in a single motor or its ESC, perhaps due to overheating, a short circuit, or a physical impact, is a prime example of a “gout-like” condition. If one motor suddenly loses power or provides inconsistent thrust, the entire propulsion system becomes imbalanced. The flight controller attempts to compensate by adjusting the other motors, but this can only go so far. The drone might yaw violently, lose altitude rapidly, or flip, akin to a human collapsing from sudden, sharp pain in their foot.
- Landing Gear Malfunction: For drones with retractable landing gear, a failure in the retraction or deployment mechanism can be critical. If the gear fails to deploy before landing, it risks severe damage to the drone’s underside, cameras, or payload. If it deploys unexpectedly in flight, it can drastically alter aerodynamic characteristics, requiring immediate, precise compensation from the flight controller.
- Ground Effect Sensor Degradation: Beyond simple altimeters, some advanced drones utilize downward-facing cameras for visual odometry, LiDAR for terrain mapping, or even force-sensing resistors in their landing struts for precise touchdown detection. A localized failure in these specialized “foot” sensors—such as a lens obstruction on a visual odometry camera or a faulty LiDAR module—can cripple autonomous landing capabilities or precise low-altitude maneuvers. The drone might “feel” disoriented near the ground, unable to accurately perceive its immediate environment for a gentle landing.
These localized failures, particularly at the drone’s “foot,” directly impact its ability to interact safely and predictably with its environment, undermining flight safety and operational efficacy.
Diagnosing “Gouty” Ailments in Flight Control Systems
Identifying and diagnosing these “gout-like” conditions in drone flight technology is a sophisticated challenge that relies on advanced telemetry analysis, predictive analytics, and system redundancy.
Anomalous Data Patterns and Predictive Analytics
Modern flight controllers are equipped with extensive logging capabilities, recording every sensor reading, motor command, and system status update. Diagnosing a “gout” begins with analyzing these logs for anomalous data patterns:
- Sensor Fusion Discrepancies: The flight controller employs algorithms like Kalman filters or complementary filters to integrate data from multiple sensors, estimating the drone’s true state. If a single sensor starts producing “gouty” data, the filter will detect a growing discrepancy between that sensor’s input and the converged estimate derived from other, healthy sensors. For instance, a barometer might suddenly disagree significantly with the altitude derived from GPS (if available) and IMU integration.
- Vibration Analysis: Localized mechanical failures, such as a failing motor bearing or a damaged propeller blade (part of the “foot”), often introduce specific vibration frequencies. Specialized sensors and software can monitor these vibration signatures, alerting operators to potential “gouty” mechanical issues before they escalate to catastrophic failure. Changes in the vibration spectrum associated with a specific motor can be an early warning of an impending “gout attack.”
- Performance Deviations: Minor, creeping “gout” might not immediately cause failure but could manifest as subtle performance degradations. For example, one motor consistently drawing more current than others at the same thrust output could indicate increased friction or reduced efficiency, a nascent localized “inflammation.” Predictive analytics, leveraging machine learning, can be trained on vast datasets of healthy flight data to identify these subtle deviations from normal operating parameters. By detecting early signs of abnormality, these systems can flag potential “gout” conditions before they become critical.
Real-time telemetry streaming further aids in diagnosis, allowing ground control stations to monitor key parameters and receive immediate alerts when thresholds are exceeded or patterns indicative of failure emerge.
Redundancy and Self-Healing Architectures
To mitigate the impact of localized “gout,” advanced drone platforms incorporate various levels of redundancy and self-healing mechanisms:
- Redundant Sensors: Critical sensors like IMUs and GPS units often have backups. If the primary unit exhibits “gout-like” symptoms (e.g., highly divergent readings, internal error flags), the flight controller can seamlessly switch to the redundant sensor. This provides an immediate failover, allowing the drone to continue its mission or initiate a safe return-to-home.
- Fault-Tolerant Flight Control: For multi-rotor drones, specific algorithms are designed to handle partial motor failure. If one motor (a “foot” component) completely fails, the flight controller can redistribute thrust to the remaining motors, allowing the drone to maintain controlled flight, albeit with reduced maneuverability. This “limping” capability prevents an immediate crash, giving the operator time to land safely.
- Adaptive Control Systems: These systems continuously monitor the drone’s performance and adapt their control laws to compensate for changes in aerodynamics, mass distribution, or component degradation. If a “gout” causes a subtle shift in thrust vectoring or control response, an adaptive controller can learn and compensate for this change, effectively “walking” around the pain point.
- Watchdog Timers and System Monitors: Critical software processes and hardware components are often monitored by watchdog timers. If a process hangs or a component stops responding, the watchdog can trigger a reset or switch to a backup, preventing a localized software “gout” from freezing the entire system.
Mitigating the Impact of Localized Critical Failures
Preventing and mitigating the “gout” in a drone’s “foot” requires a multi-faceted approach encompassing robust design, rigorous testing, and proactive maintenance.
Proactive Maintenance and Inspection Protocols
Regular and thorough inspections are paramount. Just as a physician might check a patient for signs of inflammation, drone operators must:
- Physical Checks: Inspect landing gear for cracks, bends, or wear. Examine propellers for nicks or imbalances. Verify that all connectors for sensors and motors are secure and free from corrosion, which can cause intermittent electrical “gout.”
- Software Updates: Ensure flight controller firmware and sensor drivers are up to date. Software bugs can be a source of “gout-like” issues, and updates often include patches for known vulnerabilities or improvements in sensor fusion algorithms.
- Calibration Routines: Perform routine sensor calibrations (IMU, magnetometer, ESCs) to ensure accuracy and consistency. Drift in calibration can lead to insidious “gout” that slowly degrades performance without immediate failure.
Environmental Awareness and Operational Planning
Understanding the operational environment can significantly reduce the risk of inducing “gout”:
- Electromagnetic Interference (EMI): Operating near power lines, radio transmitters, or industrial machinery can introduce EMI, which can cause “gout” in GPS, magnetometer, or radio telemetry modules. Pre-flight site surveys to identify potential interference sources are critical.
- Temperature Extremes and Humidity: Extreme temperatures can stress electronic components, leading to premature failure or inaccurate sensor readings. High humidity can lead to condensation and short circuits. Proper operational limits must be respected.
- Physical Obstacles and Impact Avoidance: Careful flight planning and the use of obstacle avoidance systems are crucial to prevent physical impacts that could damage motors, propellers, or critical ground-facing sensors—the drone’s “foot”—thereby inducing a sudden “gout” attack.
By adopting a comprehensive strategy that blends advanced diagnostic capabilities with diligent operational practices, the industry can better anticipate, detect, and respond to the “gout-like” conditions that threaten the reliability and safety of drone flight technology. While “gout” might be a painful human affliction, its metaphorical counterpart in drones represents a significant engineering challenge demanding continuous innovation and vigilance.