
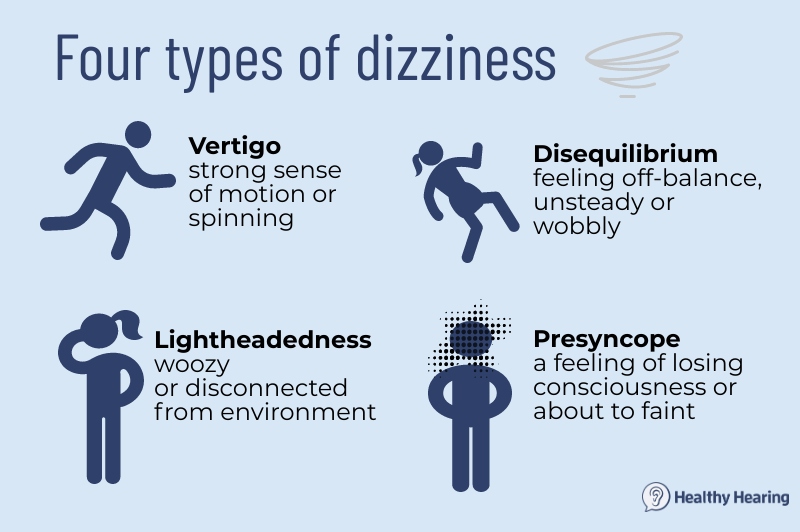
In human physiology, dizziness signifies a sense of lightheadedness, vertigo, or instability, often indicating a temporary loss of balance or spatial orientation. While drones, by their nature, do not possess biological sensory systems or neural networks to experience “dizziness” in the human sense, the concept translates remarkably well into the realm of flight technology as a profound loss of accurate spatial understanding and control. For an Uncrewed Aerial Vehicle (UAV), “dizziness” represents a critical state of disorientation, instability, or loss of navigational integrity, jeopardizing its mission, safety, and the integrity of its flight. Understanding what causes this technological “dizziness” and how advanced flight technology mitigates it is paramount for reliable and safe drone operations.
The Concept of Disorientation in Autonomous Flight
For a drone, maintaining a precise understanding of its position, attitude (roll, pitch, yaw), and velocity is fundamental to stable flight. Any significant deviation or inaccuracy in this self-perception can lead to disorientation, the technological equivalent of dizziness. This complex challenge is addressed by an array of sophisticated sensors and intelligent processing systems designed to provide a continuous and accurate spatial awareness.
Sensory Input and Spatial Awareness
A drone’s primary method for understanding its environment and position relies heavily on an intricate network of sensors. GPS modules provide latitude, longitude, and altitude data, while barometers measure atmospheric pressure to refine altitude estimates. Magnetometers (electronic compasses) determine heading relative to magnetic north, crucial for directional flight. Optical flow sensors, particularly useful at lower altitudes, track ground movement to calculate velocity and assist with position hold, much like how human eyes track movement to gauge speed. These individual inputs are critical, but their true power comes from their integration and fusion.
The Role of Inertial Measurement Units (IMUs)
At the heart of a drone’s stability and orientation system is the Inertial Measurement Unit (IMU). Comprising gyroscopes and accelerometers, the IMU continuously measures angular velocity and linear acceleration across three axes. Gyroscopes detect changes in orientation (roll, pitch, yaw), while accelerometers measure gravitational forces and any non-gravitational acceleration. The data from the IMU is vital for real-time attitude estimation. If an IMU is improperly calibrated, experiences sensor noise, or is subjected to extreme vibrations, its readings can become inaccurate, leading to a “dizzy” drone that drifts, tips, or struggles to maintain its desired orientation. Advanced flight controllers employ sophisticated algorithms, such as Kalman filters, to fuse IMU data with other sensor inputs, compensating for individual sensor errors and providing a more robust and accurate estimate of the drone’s state.
Navigational Malfunctions and Their Impact
Even with a perfectly functioning IMU, external factors can severely impact a drone’s ability to navigate, creating a form of “dizziness” where the aircraft loses its sense of absolute position or direction.
GPS Signal Degradation
Global Positioning System (GPS) is the backbone of most drone navigation, providing the primary means for outdoor positional awareness. However, GPS signals can be susceptible to various forms of degradation. “GPS spoofing” involves broadcasting fake GPS signals to trick a drone into reporting an incorrect position, potentially leading it off course or into restricted areas. “GPS jamming,” conversely, involves overwhelming legitimate GPS signals with noise, causing the drone to lose its fix entirely. Both scenarios can induce a severe form of “dizziness” where the drone no longer knows where it is in the world, forcing it to rely on less precise internal sensors or initiate emergency protocols. Building environments, dense foliage, or even solar flares can also weaken or obscure GPS signals, leading to decreased accuracy and a less reliable position lock.
Magnetic Interference with Compasses
The magnetometer, or compass, is crucial for maintaining the drone’s heading. However, magnetometers are highly sensitive to magnetic fields and can easily be influenced by external interference. Power lines, large metal structures, reinforced concrete, or even electromagnetic interference from the drone’s own internal components (motors, ESCs, power cables) can cause significant compass errors. A “dizzy” compass will provide incorrect heading information to the flight controller, causing the drone to yaw unpredictably, circle erratically, or struggle to fly in a straight line, especially during autonomous missions or when attempting precise maneuvers. Regular compass calibration, often performed before flight in a clear area, helps to mitigate these issues by establishing a baseline magnetic field environment.
Stabilization Systems Under Stress
The flight controller, acting as the drone’s “brain,” continuously processes sensor data to make rapid adjustments to motor speeds, thereby maintaining stability and executing commands. When this system is under stress, the drone exhibits signs of technological “dizziness.”
Flight Controller Algorithms and Error Correction
The algorithms embedded within the flight controller are designed to maintain a stable flight path by constantly comparing desired states (e.g., maintain altitude, fly forward) with actual states reported by sensors. Proportional-Integral-Derivative (PID) controllers are common, working to minimize errors between the target and actual values. If sensor data is erroneous, or if the PID gains are improperly tuned, the flight controller can struggle to stabilize the drone. Overly aggressive gains can lead to oscillations, where the drone “hunts” for stability, while overly weak gains can result in sluggish, unresponsive control. Both scenarios represent a form of “dizziness,” where the drone cannot efficiently correct its own movements and maintain a smooth, controlled trajectory.
Gimbal Systems and Visual Stabilization
While not directly impacting flight stability, the gimbal system, which stabilizes the camera, plays a vital role in the drone’s overall operational “clarity.” A well-stabilized gimbal ensures that the camera remains level and pointed steadily at its target, regardless of the drone’s movements or external factors like wind. If the gimbal’s stabilization system fails – perhaps due to mechanical issues, motor errors, or poor calibration – the resulting video footage will appear shaky, jittery, and “dizzying” to the viewer. This visual disorientation, though separate from flight stability, directly impacts the quality and usability of the data collected, effectively making the drone’s imaging capability “dizzy.” Advanced gimbals employ their own IMUs and sophisticated algorithms to counteract drone movements in real-time, ensuring smooth, professional-grade imagery.
Preventing “Dizzy” Flights: Redundancy and Advanced Sensors
To counteract the various causes of technological “dizziness,” modern flight technology incorporates multiple layers of redundancy and advanced sensor capabilities.
Multi-Sensor Fusion
Instead of relying on a single sensor type, advanced flight controllers employ multi-sensor fusion. This technique combines data from various sensors – GPS, IMU, barometer, magnetometers, optical flow sensors, and even radar or LiDAR for advanced models – to create a more robust and accurate estimate of the drone’s position and orientation. If one sensor provides noisy or erroneous data, the system can cross-reference it with other sensors and filter out the unreliable input. This redundancy makes the drone significantly more resilient to individual sensor failures or environmental interference, reducing the likelihood of critical “dizziness” and enhancing overall flight reliability.
Obstacle Avoidance and Environmental Awareness
Vision-based and ultrasonic obstacle avoidance systems contribute to preventing a type of “dizziness” related to spatial ignorance. By actively scanning the environment for obstacles, these systems allow the drone to perceive and react to its surroundings, much like a human avoiding collision. Without such systems, a drone might blindly fly into an object, causing a sudden, jarring disruption to its flight path that could be considered a form of severe physical “dizziness” or disorientation leading to a crash. Advanced systems use stereoscopic cameras, LiDAR, or radar to build a 3D map of the environment, enabling the drone to navigate complex spaces autonomously and avoid potential hazards that could otherwise induce catastrophic disorientation.
Recovery Mechanisms and Emergency Protocols
Despite all preventive measures, situations can arise where a drone might still experience a form of “dizziness” or critical disorientation. In such cases, robust recovery mechanisms are essential.
Return-to-Home Features
The Return-to-Home (RTH) feature is a critical safety protocol designed to guide the drone back to its take-off point autonomously. This function typically activates in scenarios such as low battery, loss of signal with the remote controller, or manual activation by the pilot. When triggered, the drone typically ascends to a preset safe altitude, navigates using its GPS to the home point, and then descends for an automated landing. For a drone that has become “dizzy” due to a loss of control signal or navigational uncertainty, RTH provides a lifeline, leveraging its last known good GPS coordinates to attempt a safe recovery, even if other forms of spatial awareness are compromised.
Autonomous Emergency Landings
In severe cases of disorientation or system failure where RTH is not feasible or safe (e.g., critical component failure, severe GPS jamming preventing navigation), some advanced drones are equipped with autonomous emergency landing capabilities. These systems might use downward-facing vision sensors or ultrasonic sensors to find a suitable clear landing spot below the drone, slowly descending to minimize damage. This is the ultimate failsafe for a “dizzy” drone that has lost its complete sense of position or control, prioritizing a controlled crash or soft landing over a freefall, thereby safeguarding the drone and mitigating potential harm to people or property on the ground.
In conclusion, while the term “dizziness” is anthropomorphic, its translation into the world of drone flight technology offers a powerful metaphor for understanding critical states of disorientation, instability, and loss of navigational integrity. From IMU errors and GPS degradation to compass interference and flight controller stress, various factors can induce this technological “dizziness.” However, continuous advancements in sensor fusion, redundant systems, obstacle avoidance, and sophisticated recovery protocols are constantly pushing the boundaries, making drones more resilient, intelligent, and less susceptible to losing their way in the vast expanse of the skies.