
The Foundational Role of Declarations in Modern Tech & Innovation
In the expansive and rapidly evolving landscape of technology and innovation, the concept of “declaration” is far more fundamental than it might initially appear. Far from being a mere statement, in the realm of computing and advanced systems, a declaration is a definitive act of establishing an element’s existence, type, properties, or intent. It’s the linguistic cornerstone upon which complex software architectures, intelligent algorithms, and sophisticated hardware interactions are built. For technologies like AI Follow Mode, autonomous flight, advanced mapping, and remote sensing in drones, declarations are not just good practice; they are indispensable.
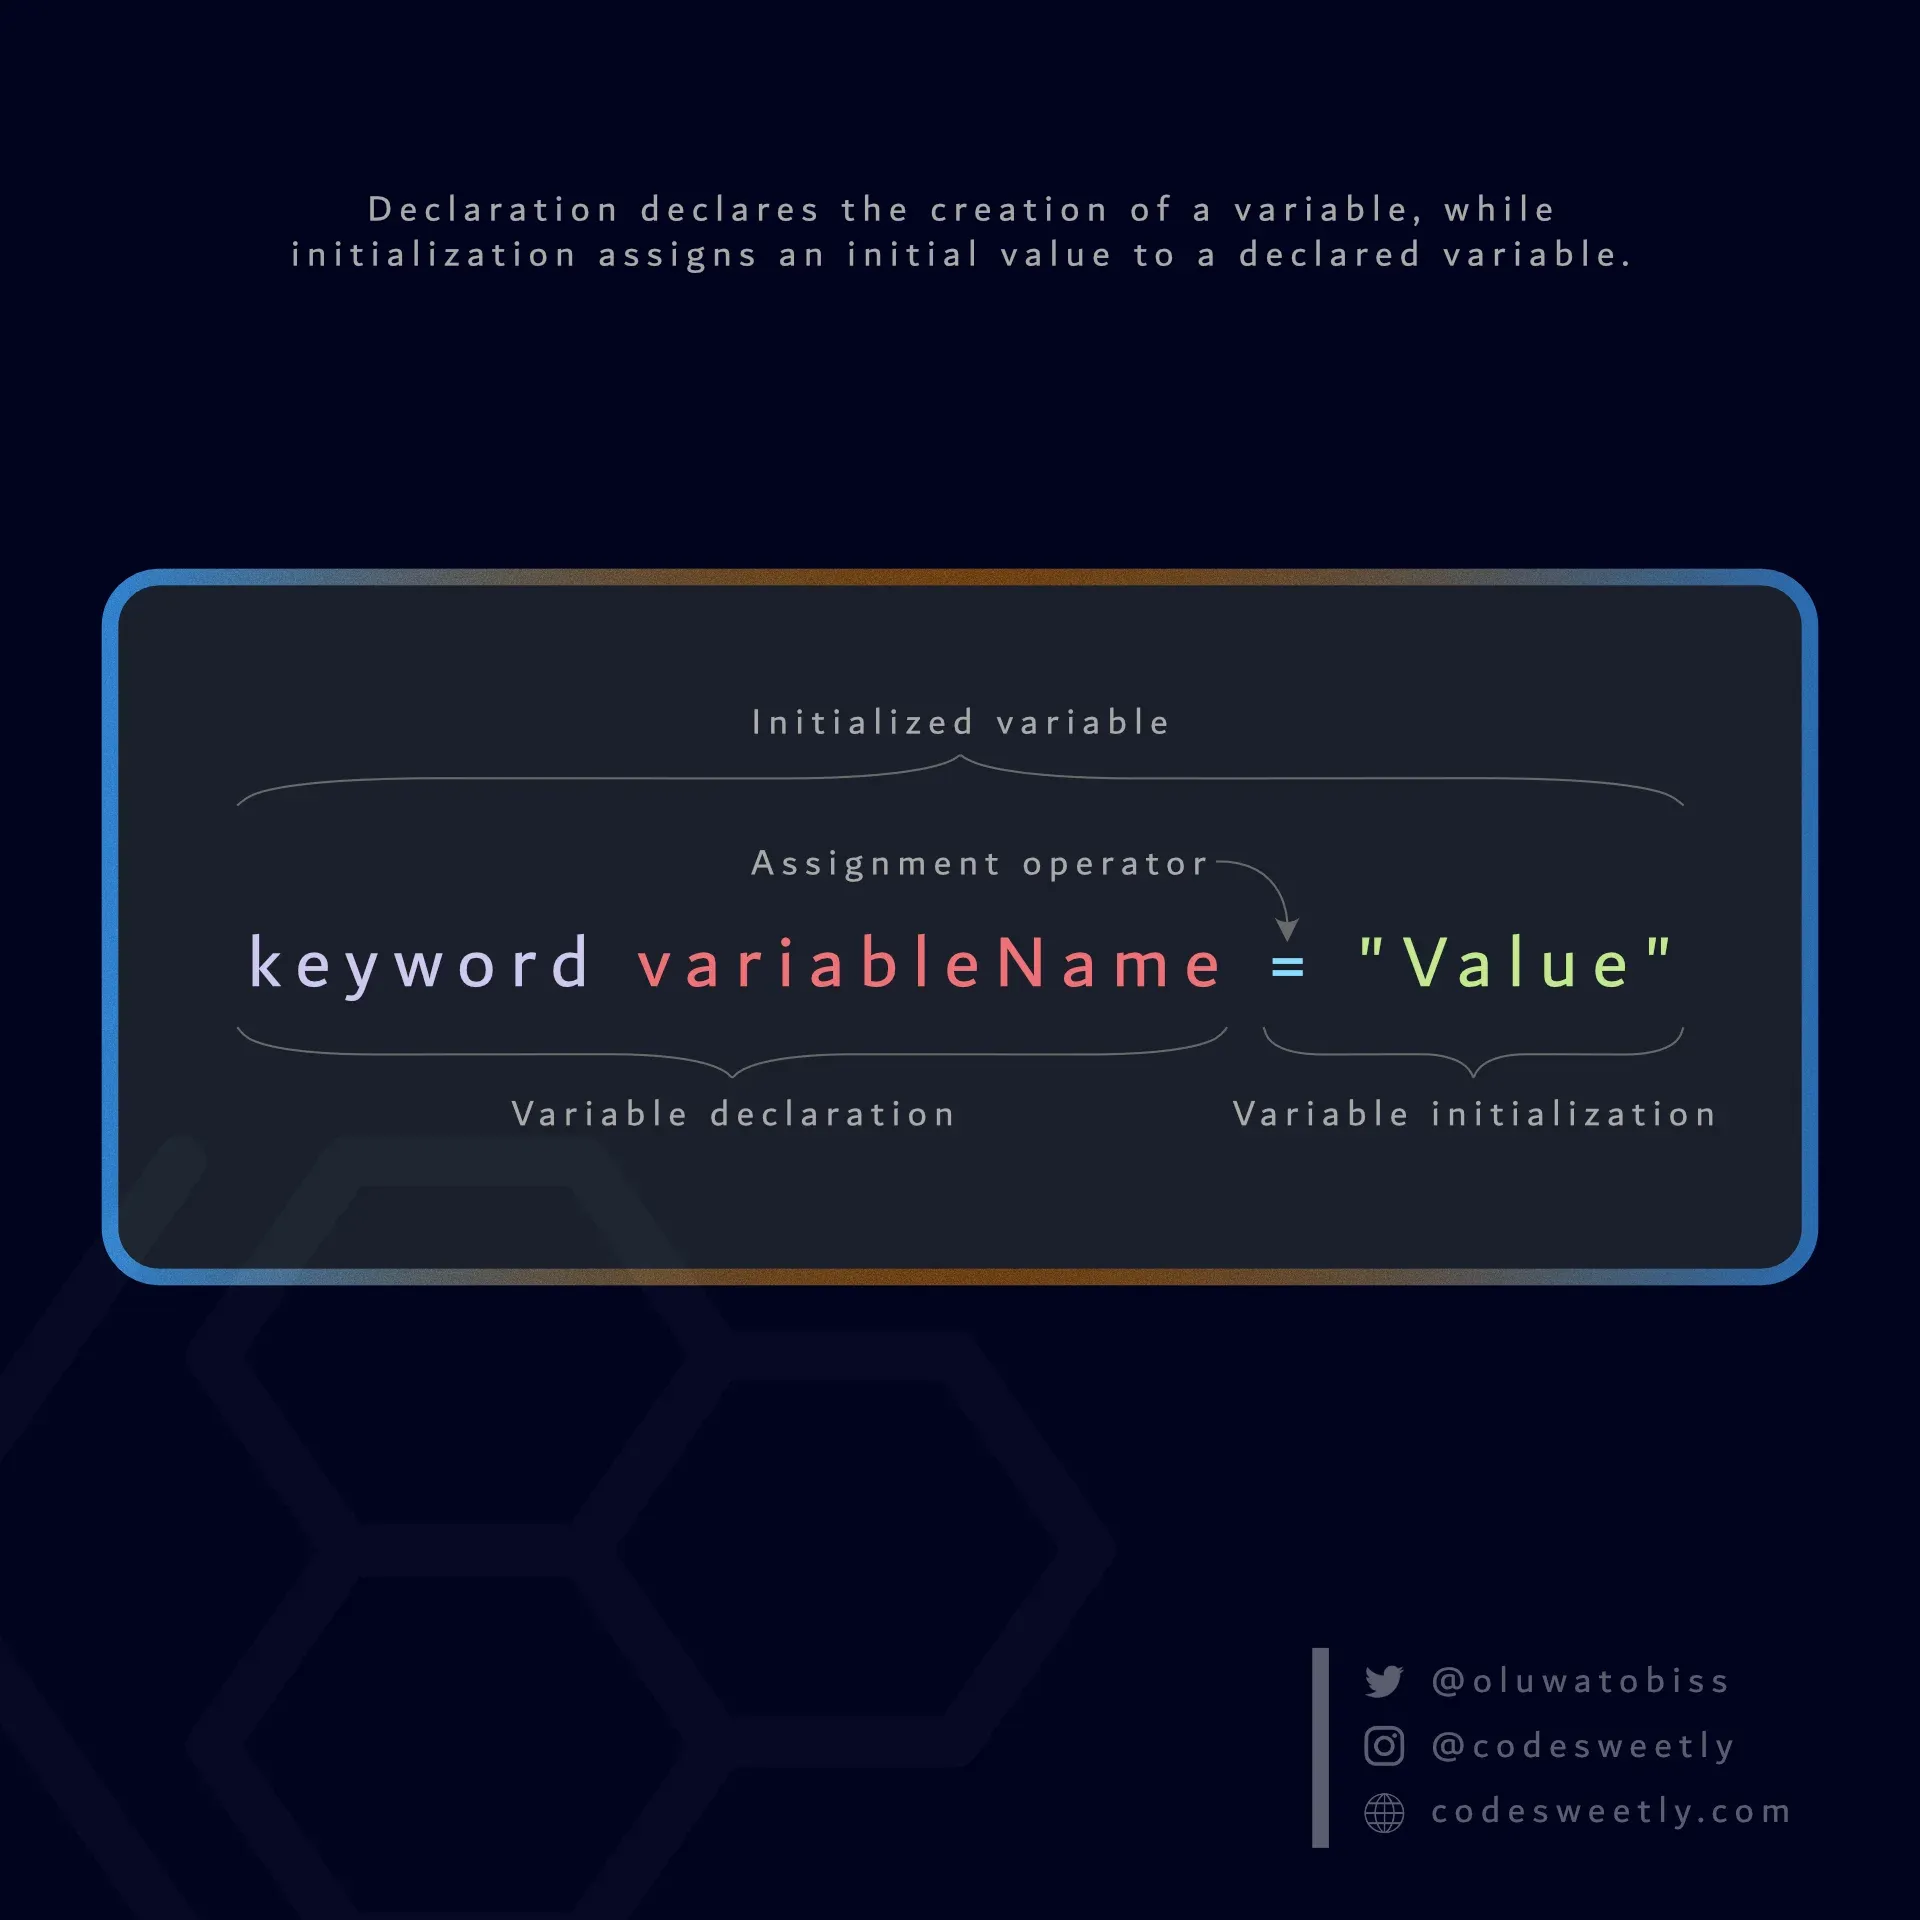
At its core, a declaration serves several critical purposes. It informs a system or compiler about the existence of an entity – whether it’s a variable, a function, a class, a data structure, or an interface. Crucially, it also defines the characteristics of that entity. For instance, declaring a variable dictates the type of data it can hold (e.g., a number, a string, a boolean), its scope (where it can be accessed), and often allocates the necessary memory. This foundational act is akin to laying out the blueprints before construction begins; without accurately declared components, the system cannot correctly allocate resources, interpret data, or execute logic.
In the context of innovation, declarations are the initial steps in translating abstract ideas into tangible, executable code and functionalities. Every advanced feature, from a drone autonomously navigating a complex environment to an AI system recognizing objects in real-time, begins with a series of precise declarations that define its constituent parts. These definitions enable the creation of robust, predictable, and scalable systems, allowing developers and engineers to manage complexity and build upon a solid, well-defined foundation.
Declarations in Autonomous Flight Systems: Crafting Intelligent Operations
Autonomous flight represents one of the pinnacle achievements in drone technology, enabling UAVs to perform complex missions without direct human intervention. The intelligence underpinning these capabilities is entirely predicated on meticulously crafted software, where declarations play a pivotal role in defining every aspect of the drone’s operational logic, sensor interpretation, and decision-making processes.
Variable and Function Declarations for Flight Logic
Consider a drone executing an autonomous waypoint mission or engaging in an AI Follow Mode. The internal software must manage myriad parameters: current altitude, desired speed, battery level, wind conditions, and target coordinates, among others. Each of these parameters must be declared as a variable within the flight control software. A declaration such as float currentAltitude; or Waypoint targetWaypoint; not only reserves memory but also specifies the data type, ensuring that the system expects and processes altitude as a floating-point number or a structured waypoint object, respectively. This precision is paramount for flight safety and reliability.
Similarly, every action the drone performs, from initiating takeoff to adjusting its pitch and roll, is governed by functions or methods. These functions must be declared before they can be called. A function declaration like void takeOff(float desiredAltitude); tells the compiler that there exists a function named takeOff that takes a single floating-point argument for the target altitude and doesn’t return any value. These declarations form the very grammar of the drone’s operational vocabulary, allowing the flight controller to orchestrate a sequence of actions into coherent, intelligent behavior. Without these explicit definitions, the software would be unable to recognize or utilize these operational building blocks.
Class and Object Declarations for Modular Drone Architectures
Modern autonomous flight systems are incredibly complex, integrating various hardware components (sensors, motors, GPS modules) and software sub-systems (navigation, perception, planning). To manage this complexity, engineers leverage object-oriented programming paradigms, where “classes” and “objects” are central. A class declaration serves as a blueprint for creating objects, encapsulating data (attributes) and behavior (methods) related to a specific entity.
For a drone, one might declare a Sensor class, which could then have subclasses for GPS_Sensor, LiDAR_Sensor, or IMU_Sensor. Each subclass would declare specific attributes like accuracy, calibrationOffset, or dataRate, along with methods such as readData() or calibrate(). When a drone system is initialized, actual “objects” are instantiated from these class declarations – for instance, GPS_Sensor primaryGPS = new GPS_Sensor();. This modular approach, entirely built upon class and object declarations, fosters reusability, simplifies maintenance, and allows for flexible scaling and integration of new components without redesigning the entire system. It enables a robust and maintainable architecture for advanced features like obstacle avoidance or dynamic path planning, where various sensor inputs and control outputs need to be seamlessly coordinated.
Data Declarations for Mapping, Remote Sensing, and AI Learning
The value of drones in mapping, remote sensing, and powering AI learning models stems from their ability to collect and process vast quantities of diverse data. The efficacy and accuracy of these applications are heavily reliant on how that data is declared, structured, and managed within the drone’s onboard systems and ground processing units.
Structuring Geospatial Data Declarations
For accurate mapping and 3D modeling, drones capture geospatial data that includes geographic coordinates (latitude, longitude, altitude), timestamps, and often associated metadata (e.g., camera orientation, sensor ID). Declarations are crucial for defining the precise structure of this data. A common approach involves declaring custom data structures or classes. For example, a Point3D structure might declare three float variables for x, y, and z coordinates, while a GeoPoint structure might declare double variables for latitude, longitude, and altitude.
For more complex datasets like point clouds (millions of 3D points representing a scene) or orthomosaics (stitched-together images), data declarations become even more sophisticated, often involving arrays or vectors of these basic structures. These declarations ensure that when the drone’s software captures a data point from a LiDAR sensor or GPS receiver, it knows exactly how to store it, what its components are, and how to interpret them during post-processing for generating detailed maps, digital elevation models, or volumetric analyses.
Sensor Data Declarations for Environmental Understanding
Drones often carry an array of sensors—RGB cameras, multispectral cameras, thermal cameras, LiDAR, and more—each producing distinct types of data. Proper declaration of these sensor outputs is vital for an AI system to correctly interpret the environment. For instance, a thermal sensor might output temperature values as unsigned short integers, while an RGB camera outputs pixel values as arrays of bytes for red, green, and blue channels.
Declaring the expected format and type of data for each sensor output allows the drone’s perception algorithms to correctly parse and utilize the information. This is particularly critical for AI applications like anomaly detection in crops (using multispectral data), identifying hot spots in industrial inspections (thermal data), or precise object recognition for delivery drones (RGB/depth data). Without explicit data declarations, the AI model wouldn’t know if a particular stream of numbers represents a temperature reading, a pixel intensity, or a distance measurement, rendering it incapable of intelligent processing.
Declarations in Machine Learning Models
In AI Follow Mode, autonomous navigation, and intelligent remote sensing, machine learning models are at the heart of decision-making. These models themselves are built upon intricate declarations. When designing a neural network, one declares its architecture: the number of layers, the type of each layer (e.g., convolutional, recurrent, fully connected), the number of nodes in each layer, and the activation functions. These declarations define the computational graph that processes input data and produces predictions or control signals.
Furthermore, the training data used to “teach” these AI models must also be declared. This includes declaring the structure of input features (e.g., image dimensions, sensor reading formats) and the corresponding labels (e.g., “person detected,” “waypoint reached,” “healthy plant”). Accurate data declarations are paramount for the machine learning algorithm to correctly ingest, process, and learn from the data, ultimately impacting the intelligence and reliability of the drone’s autonomous functions.
API Declarations: The Language of Interoperability and Expansion
The modern drone ecosystem is rarely a monolithic, self-contained system. Instead, it’s an intricate web of interconnected components, often spanning hardware, onboard software, ground control stations, cloud services, and third-party applications. Application Programming Interfaces (APIs) serve as the vital communication bridges between these disparate elements, and API declarations are the precise specifications that govern how these bridges are built and used.
Defining Communication Protocols with API Declarations
An API declaration essentially outlines a contract for how software components interact. For a drone, this might involve declarations for:
- Endpoints: Specific network addresses or URIs where requests can be sent (e.g.,
/api/v1/flight_status,/api/v1/mission_plan). - Data Formats: How data is structured when exchanged (e.g., JSON, XML, Protobuf) and the schema for each data type (e.g., a
FlightStatusobject must declarebatteryLevel: float,gpsLock: boolean,currentMode: string). - Methods/Operations: The specific actions that can be performed (e.g.,
GET /flight_statusto retrieve status,POST /mission_planto upload a new mission). - Authentication/Authorization: How access to the API is secured.
These explicit declarations enable seamless interaction. For example, a ground control station application, using the declared API, knows precisely how to request the drone’s current telemetry data and how to format a command to initiate a specific flight maneuver. This standardization, enforced by API declarations, is fundamental for reliable and predictable communication within complex drone systems.
Extending Drone Capabilities through Third-Party API Integrations
One of the most powerful aspects of well-declared APIs is their ability to facilitate the integration of third-party services and expand drone capabilities exponentially. By declaring a public or private API, drone manufacturers and developers allow other innovators to build applications and services that interact with their platforms.
Consider a drone mapping service: it might declare an API that allows users to upload raw imagery. This API would declare the required image format, metadata expectations, and the endpoint for submission. External weather services could also integrate via declared APIs to provide real-time atmospheric data to a drone’s flight planner, optimizing flight paths for efficiency or safety. Similarly, in remote sensing, an API might be declared to push collected data directly to a cloud-based AI processing pipeline for immediate analysis. This interconnectedness, driven by clear API declarations, fosters an ecosystem of innovation where drones become versatile platforms rather than isolated devices, continually gaining new functionalities and intelligence.
Declarative Programming Paradigms in Advanced Drone Applications
Beyond explicit variable and function declarations, the concept of “declarative” also extends to programming paradigms that are profoundly influencing how advanced drone applications are designed, particularly in autonomous flight and AI.
Shifting from Imperative to Declarative Approaches
Traditionally, much of software development has been “imperative,” meaning programmers explicitly describe how a program should achieve a task, step-by-step. In contrast, “declarative” programming focuses on what needs to be achieved, leaving the how to the underlying system or interpreter. For complex drone systems, this shift can significantly simplify development and enhance reliability.
For instance, an imperative approach for a drone might involve meticulously coding every motor adjustment and sensor reading to follow a specific path. A declarative approach would simply state: “fly to these waypoints,” and the underlying flight control system, designed with declarative principles, would automatically determine the precise sequence of low-level commands to achieve that declared goal.
Declarative Mission Planning and Goal-Oriented AI
In autonomous flight, mission planning often benefits greatly from declarative principles. Instead of writing verbose code for every single maneuver, a user or an AI system declares the desired mission objectives or states. For example, an operator might declare: “map this 10-hectare field with a ground sampling distance (GSD) of 2cm, maintaining an overlap of 80%.” The drone’s intelligent mission planner then translates these declared goals into a series of flight paths, altitudes, and camera triggers, autonomously handling the complex execution details.
Similarly, in AI Follow Mode, the user declares the intent: “follow me, keeping a distance of 10 meters.” The drone’s AI, utilizing its declared models and algorithms, continuously processes its environment (e.g., using computer vision to track the subject) and autonomously adjusts its flight path and speed to maintain the declared relationship, without requiring the user to specify individual thrust vector changes or gimbal adjustments. This goal-oriented approach, enabled by declarative statements, empowers more intuitive and robust autonomous operations.

Configuration as Declaration
Even seemingly simple configuration files play a declarative role in complex drone systems. Instead of hardcoding parameters like flight modes, sensor calibration values, or geofence boundaries directly into the source code, these are often declared in external configuration files (e.g., YAML, JSON).
For example, a drone’s configuration file might declare:
flight_modes:
  - name: "Acro"
    enabled: true
  - name: "PositionHold"
    enabled: true
    default_speed: 5.0 # m/s
sensor_calibration:
  imu:
    accelerometer_offset: [0.1, -0.05, 0.02]
These declarations explicitly state the desired operational characteristics of the drone. When the drone system starts, it reads these declarations and configures itself accordingly. This approach allows for flexible updates, easy customization, and simplified management of complex drone behaviors without requiring code changes or recompilations, making it a powerful form of “declaration” in practice for maintaining and deploying advanced drone technologies.