
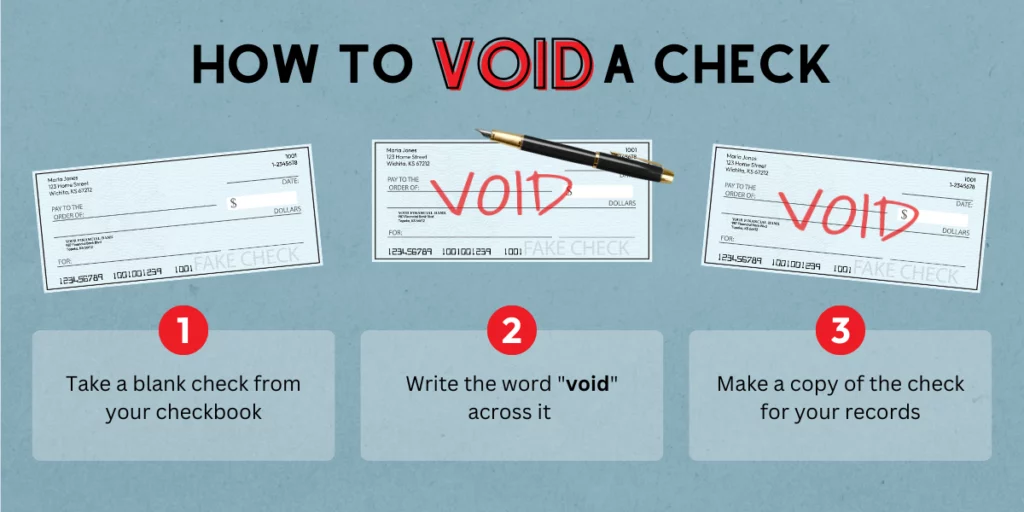
In the realm of advanced technology and innovation, particularly within the burgeoning landscape of autonomous systems like drones, the concept of a “voided check” takes on a profound, metaphorical significance. While traditionally rooted in financial instruments, where a voided check is rendered unusable and invalid, its application in sophisticated tech environments speaks to critical failures, bypassed safeties, or nullified data integrity. Understanding what constitutes a “voided check” in drone technology is crucial for developers, operators, and regulatory bodies striving for safety, reliability, and precision in autonomous flight. It encapsulates any instance where a critical verification, an essential data point, or a necessary system state is rendered invalid, ignored, or compromised, leading to potentially significant operational or safety implications.
The Metaphor of the Voided Check in Drone Systems: Redefining ‘Invalidation’ in Autonomous Tech
The financial analogy of a voided check—a document intentionally invalidated to prevent its use—serves as a powerful metaphor for understanding vulnerabilities and safeguards in complex drone systems. In this technological context, a “check” refers to any crucial validation, authentication, sensor reading, algorithmic decision point, or security protocol designed to ensure the safe and intended operation of an unmanned aerial vehicle (UAV). When such a “check” is “voided,” it signifies that this critical element has been rendered unreliable, overridden, corrupted, bypassed, or otherwise invalidated, directly impacting the system’s integrity and performance.
Consider the myriad “checks” performed by a modern drone: from the integrity of its GPS signal and accelerometer readings to the verification of its battery health, the adherence to geofence boundaries, and the successful execution of collision avoidance algorithms. Each of these represents a critical data point or a systemic safeguard. A “voided check” in this domain could manifest as a corrupted telemetry packet, a spoofed GPS signal providing false location data, an algorithm failing to properly validate an obstacle detection, or a cybersecurity breach that neutralizes safety protocols. The implications of such invalidations in systems where real-time accuracy, autonomous decision-making, and physical safety are paramount are far-reaching, potentially leading to operational failures, mission compromises, or even catastrophic accidents. It underlines the necessity of robust design, redundancy, and advanced error handling to identify, mitigate, and recover from any instance where a fundamental “check” is compromised.
Data Integrity and Sensor Validation: Preventing ‘Voided’ Information
The foundation of any intelligent drone system rests squarely on the integrity of its data. From navigation to payload operation, every autonomous function is a direct response to processed information. In this context, sensor readings and data packets are the primary “checks” that inform the drone’s understanding of its environment and operational status. Preventing these checks from being “voided” is a paramount concern in drone technology.
The Foundation of Reliable Flight
Reliable flight operations are directly correlated with the accuracy and consistency of sensor data. GPS modules provide positional awareness, Inertial Measurement Units (IMUs) track orientation and acceleration, LiDAR and radar sensors detect obstacles, and vision systems offer contextual awareness. Each of these data streams acts as a critical “check” on the drone’s current state and its interaction with the environment. If any of these foundational data streams are compromised, the drone’s ability to operate safely and effectively is immediately jeopardized.
Corruption and Spoofing
Data can become “voided” through various means. Environmental factors like electromagnetic interference can corrupt sensor readings, leading to erroneous data inputs. More maliciously, GPS spoofing attacks can feed false location data to a drone, causing it to deviate from its intended flight path or believe it is in a different location entirely. Sensor malfunctions, whether due to physical damage or software glitches, can also produce unreliable data that, if unchecked, can lead to critical errors. Identifying and neutralizing these “voided” data points is a continuous challenge for drone engineers.
Validation Algorithms
To counter the risk of “voided” data, sophisticated validation algorithms are employed. Redundancy is a common strategy, where multiple sensors provide the same type of information, allowing the system to cross-reference and identify discrepancies. Algorithms like Kalman filters combine data from various sensors with predictive models to estimate the true state of the drone, effectively filtering out noise and invalid readings. Sensor fusion techniques integrate data from disparate sources, creating a more robust and reliable overall picture. These techniques are designed to detect when a particular “check” (a sensor reading) is anomalous or “voided” and either correct it or disregard it in favor of more reliable information.
Edge Computing and Onboard Processing
The immediate validation of data at the source is critical. Edge computing and advanced onboard processing capabilities allow drones to perform complex data validation in real-time, minimizing latency and the risk of propagation of “voided” data. By processing and validating sensor inputs directly on the drone, systems can quickly identify and mitigate errors before they impact critical flight decisions, ensuring that only trusted information is used for autonomous operation.
Autonomous Decision-Making and Error Handling: What Happens When a ‘Check’ Fails?
Autonomous drones make complex decisions in real-time, relying on a continuous series of “checks” against predefined parameters and environmental inputs. When one of these algorithmic or conditional checks fails or is “voided,” the drone’s error handling capabilities become paramount to maintain safety and mission integrity.
Algorithmic Checks and Failsafes
Autonomous flight control systems are built upon a cascade of algorithmic “checks.” These include verifying battery levels against mission duration, ensuring the drone remains within designated geofence boundaries, confirming successful obstacle detection before proceeding, and validating the stability of flight trajectories. Each successful check permits the next step in the autonomous sequence, while a failed check should ideally trigger a predefined response. These are critical “go/no-go” points in the drone’s operational logic.
The ‘Voiding’ of a Conditional Check
A “voiding” of a conditional check occurs when a condition that should be met is somehow bypassed, ignored, or rendered irrelevant due to an unforeseen circumstance or a system flaw. For example, if a geofence check is erroneously disabled, or if a critical obstacle avoidance sensor is compromised without the flight controller registering the failure, a primary safety check has effectively been “voided.” This can lead to the drone operating outside its safe parameters, potentially causing collisions or unauthorized incursions.
Redundancy in Decision Logic
To mitigate the risks associated with “voided” conditional checks, drone systems incorporate multiple layers of decision logic and fallback protocols. Redundant checks mean that if one validation fails, another independent check can step in to prevent a dangerous action. For instance, a drone might have both active obstacle avoidance sensors and a pre-programmed no-fly zone map. If the active sensors are “voided,” the map data can still prevent flight into a known obstacle area. These secondary and tertiary checks provide essential safety nets, ensuring that the system can still make safe decisions even when primary validations are compromised.
Human Oversight and Intervention
Despite increasing autonomy, human oversight remains a crucial component in managing potential “voided check” scenarios. Operators monitor telemetry, video feeds, and system diagnostics for anomalies that might indicate a failing or “voided” check. In cases where automated error handling cannot resolve an issue, or when a critical safety check has been irrevocably voided, human intervention becomes necessary. This might involve initiating an emergency landing, overriding autonomous controls, or activating return-to-home functions to bring the drone to safety. The interface between human and machine must be intuitive, providing clear indicators when system “checks” are failing.
Cybersecurity Implications: Malicious ‘Voiding’ of System Safeties
As drones become more sophisticated, networked, and integrated into critical infrastructure, they become attractive targets for cyberattacks. The malicious “voiding” of system safeties through cyber intrusion represents one of the most significant threats to the integrity and reliability of autonomous drone operations.
Vulnerabilities in Connected Systems
Modern drones are increasingly connected to ground control stations, cloud services, and other networked devices, often relying on wireless communication protocols. This interconnectedness creates numerous attack vectors that can be exploited by malicious actors. From unsecured Wi-Fi connections to compromised ground control software, each link in the operational chain presents a potential point of entry for cyber threats aiming to disrupt or take control of drone systems.
Malicious Invalidation
Cyber threats can intentionally “void” critical security checks, authentication protocols, or safety parameters. This could involve spoofing authentication credentials to gain unauthorized control of a drone, injecting false commands to deviate its flight path, or disabling emergency procedures like return-to-home functions. For example, an attacker might “void” geofencing checks, allowing the drone to enter restricted airspace, or corrupt sensor data to cause a crash. The goal of such attacks is often to compromise the drone’s mission, gather sensitive data, or cause physical damage.
Protecting Against Sophisticated Attacks
Protecting against the malicious “voiding” of system safeties requires a multi-layered cybersecurity approach. Robust encryption protocols for all communication links are essential to prevent eavesdropping and command injection. Secure boot processes ensure that only trusted software is loaded, preventing tampering with the drone’s operating system. Intrusion detection systems monitor for unusual activity, alerting operators to potential breaches. Furthermore, adopting zero-trust architectures, where every device and user must be verified before accessing network resources, helps prevent unauthorized access and control.
The ‘Voided’ Authorization
Unauthorized access or control effectively “voids” legitimate operational parameters and authority. If a drone’s control is usurped, the attacker gains the ability to issue commands that override the intended flight plan, mission objectives, and safety limits. This “voided” authorization can lead to the drone being used for illicit purposes, such as surveillance, contraband delivery, or even kinetic attacks, highlighting the critical importance of strong authentication and access control mechanisms.
Designing for Robustness: Mitigating the Impact of Voided Checks
Mitigating the impact of “voided checks” is a core principle in the design and development of reliable and safe drone technology. This involves creating systems that are resilient to failures, capable of self-diagnosis, and equipped with protocols to recover or enter safe states when critical validations are compromised.
Redundant Hardware and Software
A fundamental strategy for mitigating “voided checks” is the implementation of redundancy. Hardware redundancy involves duplicating critical components, such as flight controllers, GPS modules, or power systems. If one component fails or its “check” is voided, a backup system can seamlessly take over. Software redundancy involves parallel processing of critical algorithms or maintaining backup copies of essential software states. This ensures that no single point of failure can entirely compromise a crucial function, providing a robust defense against system-level “voiding.”
Failsafe Protocols and Emergency Procedures
Every drone system must incorporate comprehensive failsafe protocols and emergency procedures. These are pre-programmed responses designed to automatically revert the drone to a safe mode of operation when critical “checks” are voided or fail. Common failsafes include “return-to-home” (RTH) when GPS signal is lost or battery levels are critically low, or “emergency landing” when multiple sensor failures are detected. These protocols act as final resorts, ensuring that even if primary validations are compromised, the drone can still achieve a controlled, safe termination of its flight.
Continuous Monitoring and Predictive Analytics
Utilizing AI and machine learning, drone systems can employ continuous monitoring and predictive analytics to detect anomalies and anticipate potential “voided check” scenarios before they become critical. Machine learning models can analyze telemetry data, sensor readings, and system logs in real-time to identify patterns indicative of impending component failure or software glitches. This predictive capability allows for proactive maintenance or the activation of preventive measures, effectively addressing potential “voided checks” before they fully manifest and impact operations.
Regulatory Frameworks and Best Practices
The development of robust regulatory frameworks and industry best practices plays a crucial role in mitigating the impact of “voided checks.” Standards for airworthiness, cybersecurity, and operational safety mandate specific levels of redundancy, failsafe mechanisms, and validation processes. Certifications ensure that drone systems meet these rigorous requirements, providing a baseline of reliability and resilience against various forms of invalidation. Adherence to these frameworks helps to ensure that drones are designed to withstand, detect, and recover from situations where critical “checks” are compromised, thereby enhancing overall safety and public trust in autonomous flight technology.