
In the realm of mathematics, a ray is a fundamental geometric concept, embodying simplicity yet serving as a cornerstone for complex theoretical structures and practical applications, particularly within modern tech and innovation. Far from a mere abstract idea, the precise definition and properties of a mathematical ray underpin critical technologies from autonomous navigation and advanced sensing to sophisticated AI algorithms and immersive simulations. Understanding its nature is key to appreciating how these innovations perceive, interact with, and model the world.
The Fundamental Geometric Concept
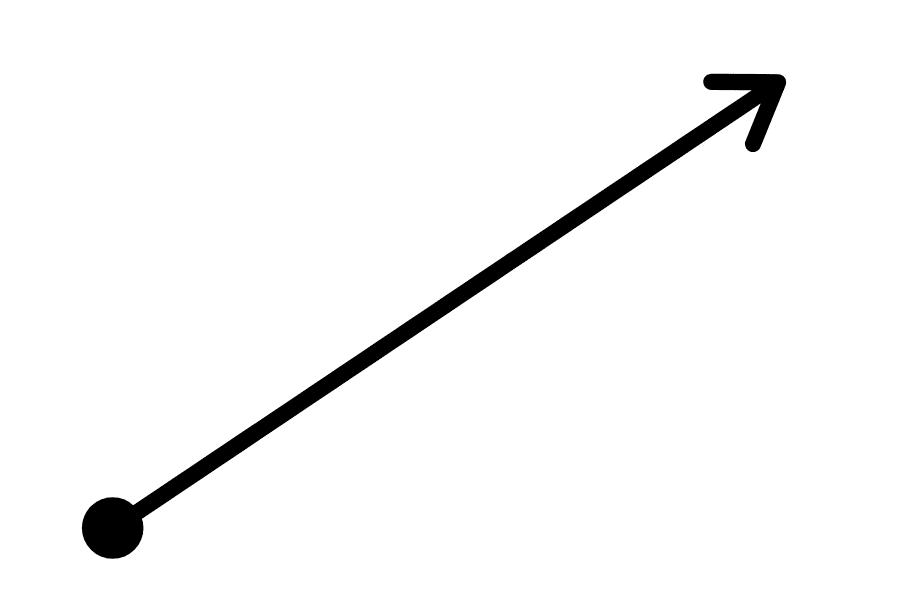
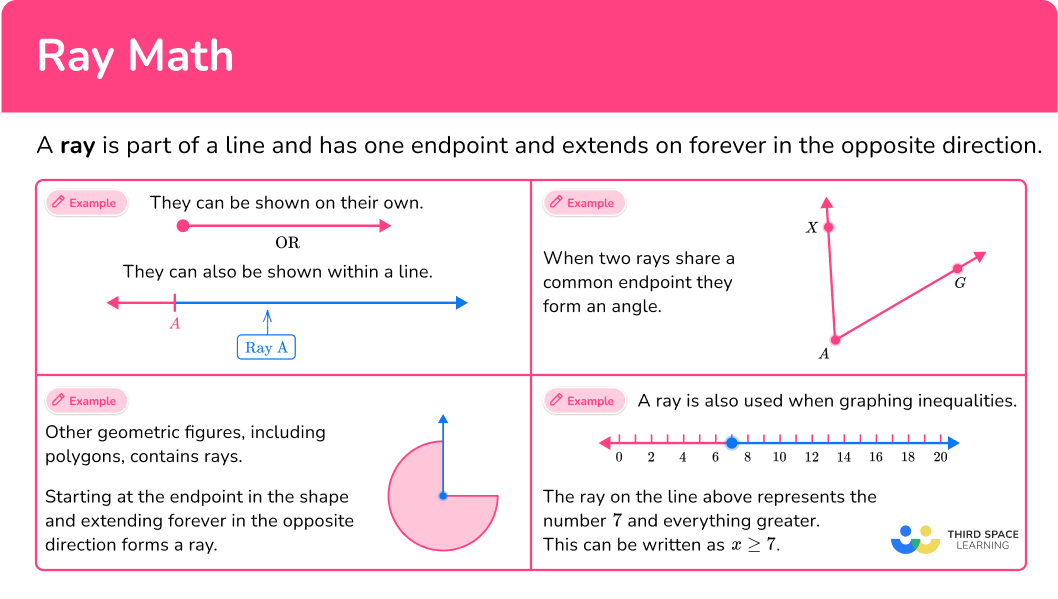
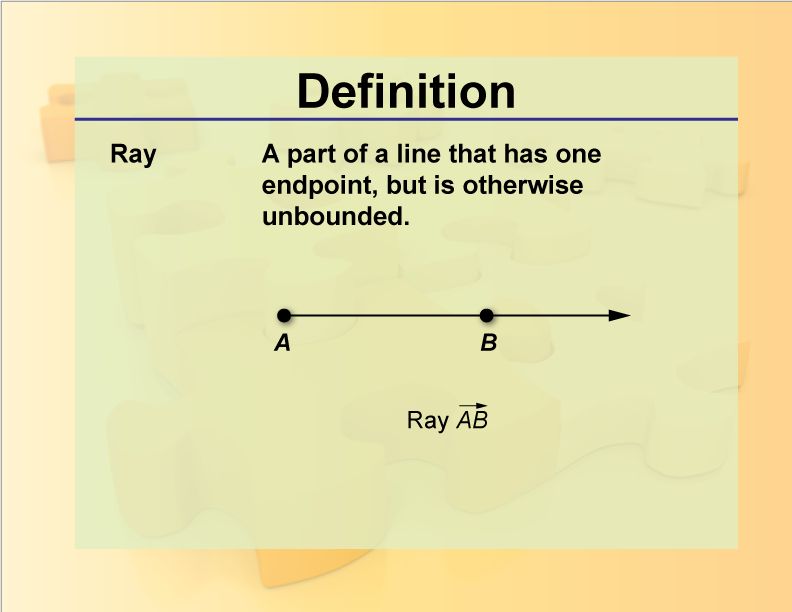
At its core, a ray in mathematics is elegantly simple: a portion of a line that originates from a specific point and extends infinitely in one direction. Unlike a line, which extends infinitely in two directions, or a line segment, which has two defined endpoints, a ray offers a unique combination of boundedness at one end and boundless extension at the other. This distinct characteristic makes it an indispensable tool for defining directions, paths, and fields of view in various computational and analytical contexts.
Definition and Representation
A ray is formally defined by an initial point, often called the endpoint or origin, and a direction. Imagine a beam of light emanating from a lighthouse; the lighthouse itself is the endpoint, and the beam represents the ray extending outwards into the distance. In a two-dimensional Cartesian coordinate system, a ray can be described by its starting coordinates $(x0, y0)$ and a vector $(Delta x, Delta y)$ that dictates its direction. Any point $(x, y)$ on the ray can then be expressed parametrically as $(x0 + tDelta x, y0 + tDelta y)$, where $t$ is a non-negative scalar ($t ge 0$). This parameter $t$ essentially scales the directional vector, tracing points further and further along the ray from its origin.
In three dimensions, the concept extends naturally. A ray originates from $(x0, y0, z0)$ and extends infinitely in the direction of a vector $(Delta x, Delta y, Delta z)$, with points on the ray given by $(x0 + tDelta x, y0 + tDelta y, z0 + tDelta z)$ for $t ge 0$. This mathematical description is powerful because it provides a precise, unambiguous way to represent a directed path in space, which is critical for computational models that simulate light, sound, or trajectories.
Rays in a Coordinate System
The mathematical representation of rays allows for rigorous computation. Whether it’s determining if two rays intersect, calculating the distance from a point to a ray, or projecting a point onto a ray, these operations are fundamental to many computational geometry problems. For instance, in 3D graphics, a ray from the camera’s perspective can be cast into a scene to determine which object it intersects first, thereby determining what is visible. In robotics, a ray can represent the line of sight from a sensor, enabling the robot to “see” its environment. The precise mathematical formulation ensures that these complex spatial relationships can be modeled and processed with high accuracy and efficiency.
Rays as the Building Blocks of Sensing and Perception
The intuitive concept of a ray – a directed path from an origin – finds profound practical application in advanced sensing technologies. Modern systems for autonomous flight, mapping, and remote sensing rely heavily on projecting and analyzing these mathematical “rays” in the physical world, using various forms of energy.
Lidar and the Power of Laser Rays
Lidar (Light Detection and Ranging) systems exemplify the direct application of mathematical rays. A Lidar unit emits millions of precisely timed laser pulses—each a narrow beam of light that can be conceptualized as a ray. These laser rays travel outwards, strike objects in the environment, and reflect back to the sensor. By measuring the exact time it takes for each ray to make this round trip, and knowing the speed of light, the Lidar system can calculate the precise distance to the object that reflected it.
When integrated into autonomous drones or vehicles, Lidar continuously sweeps these laser rays across the environment. The resulting data, a massive cloud of distance points, creates an incredibly detailed 3D map of the surroundings. This point cloud, effectively a composite of millions of ray intersections, is crucial for:
- High-precision mapping: Generating topographical maps, urban models, and environmental surveys with centimeter-level accuracy for remote sensing applications.
- Obstacle avoidance: Detecting impending collisions by tracking the distance and velocity of objects within the drone’s flight path.
- Localization: Helping autonomous systems understand their exact position within a known map by continuously matching current sensor data with pre-existing spatial information.
The ability to model these laser pulses as mathematical rays enables the algorithms to process, filter, and interpret vast amounts of spatial data efficiently.
Radar and Radio Wave Projections
Similar to Lidar, Radar (Radio Detection and Ranging) systems also utilize the ray concept, but with radio waves instead of light. Radar emits electromagnetic radio waves, which can be thought of as rays propagating through space. When these radio wave rays encounter an object, a portion of their energy is reflected back to the receiver. By analyzing the time delay, frequency shift (Doppler effect), and strength of the returned rays, Radar can determine an object’s distance, speed, and direction.
While Lidar excels at detailed short-to-medium range mapping, Radar offers robust performance in adverse weather conditions (fog, rain, snow) where optical sensors might struggle. For autonomous flight, Radar’s ability to penetrate these conditions makes it a vital component for long-range obstacle detection, air traffic management for UAVs, and ensuring safe operations in diverse environments, all predicated on the predictable propagation and reflection of its radio wave “rays.”
Acoustic Sensing and Sonar
Even acoustic sensing, such as sonar (Sound Navigation and Ranging), uses the principle of rays. Sonar systems emit sound waves (acoustic rays) into water or air. These sound rays travel, reflect off objects, and return to a hydrophone or microphone. By measuring the time-of-flight, sonar can map underwater topography, detect submerged objects, or even profile atmospheric conditions. The mathematical modeling of sound propagation often treats sound waves as rays, simplifying complex wave mechanics into manageable geometric problems for localization and mapping.
Ray Tracing in Simulation and Visualization
Beyond direct sensing, the mathematical ray is indispensable in the digital domain, particularly in simulation and visualization. Ray tracing is a powerful rendering technique that simulates the path of light, enabling the creation of highly realistic digital environments and the rigorous testing of autonomous systems.
Rendering Realistic Environments for Training
For autonomous drones and AI systems, training often involves extensive simulation. Ray tracing plays a pivotal role in generating these virtual worlds. By simulating how light rays would interact with virtual objects—bouncing, reflecting, refracting—ray tracing algorithms produce photorealistic images. This capability is critical for:
- Autonomous flight simulation: Creating highly accurate digital twins of real-world environments where drones can practice complex maneuvers, obstacle avoidance, and mission profiles without physical risk. The realism generated by ray tracing helps AI models generalize better to real-world scenarios.
- Virtual reality (VR) and augmented reality (AR) for operators: Providing immersive training experiences for drone pilots and ground control crews, allowing them to visualize flight paths, sensor data, and emergency procedures in a lifelike setting.
Simulating Sensor Performance
Ray tracing isn’t just for visuals; it’s a powerful tool for simulating the performance of real-world sensors like Lidar, Radar, and cameras. In a simulated environment:
- Virtual Lidar: Algorithms can project “virtual laser rays” into a 3D model of the scene, calculating intersection points and return times to generate synthetic Lidar point clouds. This allows engineers to test and refine Lidar processing algorithms, evaluate sensor placement, and validate object detection models before deploying physical hardware.
- Virtual Radar: Similarly, virtual radio rays can be used to simulate radar reflections, accounting for material properties, weather effects, and multi-path interference. This helps in developing robust radar-based navigation and collision avoidance systems for drones operating in challenging conditions.
- Camera Simulation: Simulating how light rays pass through a virtual camera lens to form an image helps in testing computer vision algorithms under various lighting, weather, and motion conditions, enhancing the robustness of AI for object recognition and tracking.
Autonomous Navigation and Path Planning with Rays
The core task of autonomous flight is to navigate safely and efficiently from one point to another. Mathematical rays are fundamental to defining paths, detecting obstacles, and making real-time decisions.
Defining Obstacle Avoidance Vectors
In autonomous navigation, a drone continuously constructs a “local map” of its immediate surroundings using sensor data (Lidar, Radar, cameras). Within this map, potential collision points or no-fly zones can be identified. Algorithms then use rays to represent possible flight directions. By projecting hypothetical “movement rays” from the drone’s current position, and checking for intersections with detected obstacles, the system can determine safe trajectories. A ray that intersects an obstacle within a certain safety margin is deemed unsafe, prompting the drone to calculate alternative paths by adjusting the direction of its projection rays. This real-time ray casting and intersection testing forms the backbone of sophisticated obstacle avoidance systems.
Optimizing Flight Paths
Beyond immediate collision avoidance, rays are used in global path planning. When an autonomous drone needs to travel a long distance, it needs an optimal path. Algorithms can use ray-like vectors to explore possible routes in a pre-mapped 3D environment, considering factors like energy consumption, flight time, and regulatory no-fly zones. These “exploratory rays” help identify the most efficient and safest sequence of waypoints, forming a complete flight plan. Furthermore, in dynamic environments, drones can use “predictive rays” to estimate the future positions of moving objects (like other aircraft or ground vehicles), adjusting their own trajectories to maintain safe separation.
AI, Computer Vision, and the Mathematics of Light
The field of Artificial Intelligence, especially in computer vision for autonomous systems, draws heavily on the principles of how light rays interact with objects and cameras. Understanding this mathematical basis allows AI to interpret 2D images and reconstruct 3D environments.
Depth Perception and 3D Reconstruction
Humans perceive depth because our two eyes see slightly different perspectives. Computer vision mimics this using stereo cameras, where two cameras separated by a known distance capture images of the same scene. The disparity between corresponding points in these two images is mathematically related to the 3D position of the object. This relationship is derived from the geometry of light rays emanating from a point in 3D space and projecting onto two separate image planes. AI algorithms process these “projection rays” to reconstruct a 3D point cloud, similar to Lidar, but derived from passive optical sensors. This technique is critical for drones to build a detailed understanding of their environment for navigation and interaction.
Object Detection and Scene Understanding
When an AI system detects an object in an image, it’s essentially working backward from the light rays that formed the image. The AI has learned patterns of pixels that correspond to specific object types (e.g., a person, a tree, another drone). Advanced computer vision models, particularly those based on neural networks, implicitly encode an understanding of perspective and geometry that is rooted in how light rays project 3D objects onto a 2D sensor. For instance, understanding that objects appear smaller when further away, or that parallel lines converge at a vanishing point, are principles derived from the mathematics of rays and perspective projection. This allows AI-powered drones to accurately identify and track objects, estimate their distances, and comprehend the overall scene structure, enabling intelligent decision-making for autonomous operations and complex remote sensing tasks.
In conclusion, while a ray might appear to be a simple line segment extending to infinity in a math textbook, its conceptual and computational power forms an invisible but indispensable backbone for the most advanced technological innovations. From guiding laser pulses in Lidar to simulating complex environments and enabling AI to ‘see’ and ‘understand’ the world, the humble mathematical ray is a profound enabler of the future of tech and innovation.