
Defining Critical Thresholds in Autonomous Systems
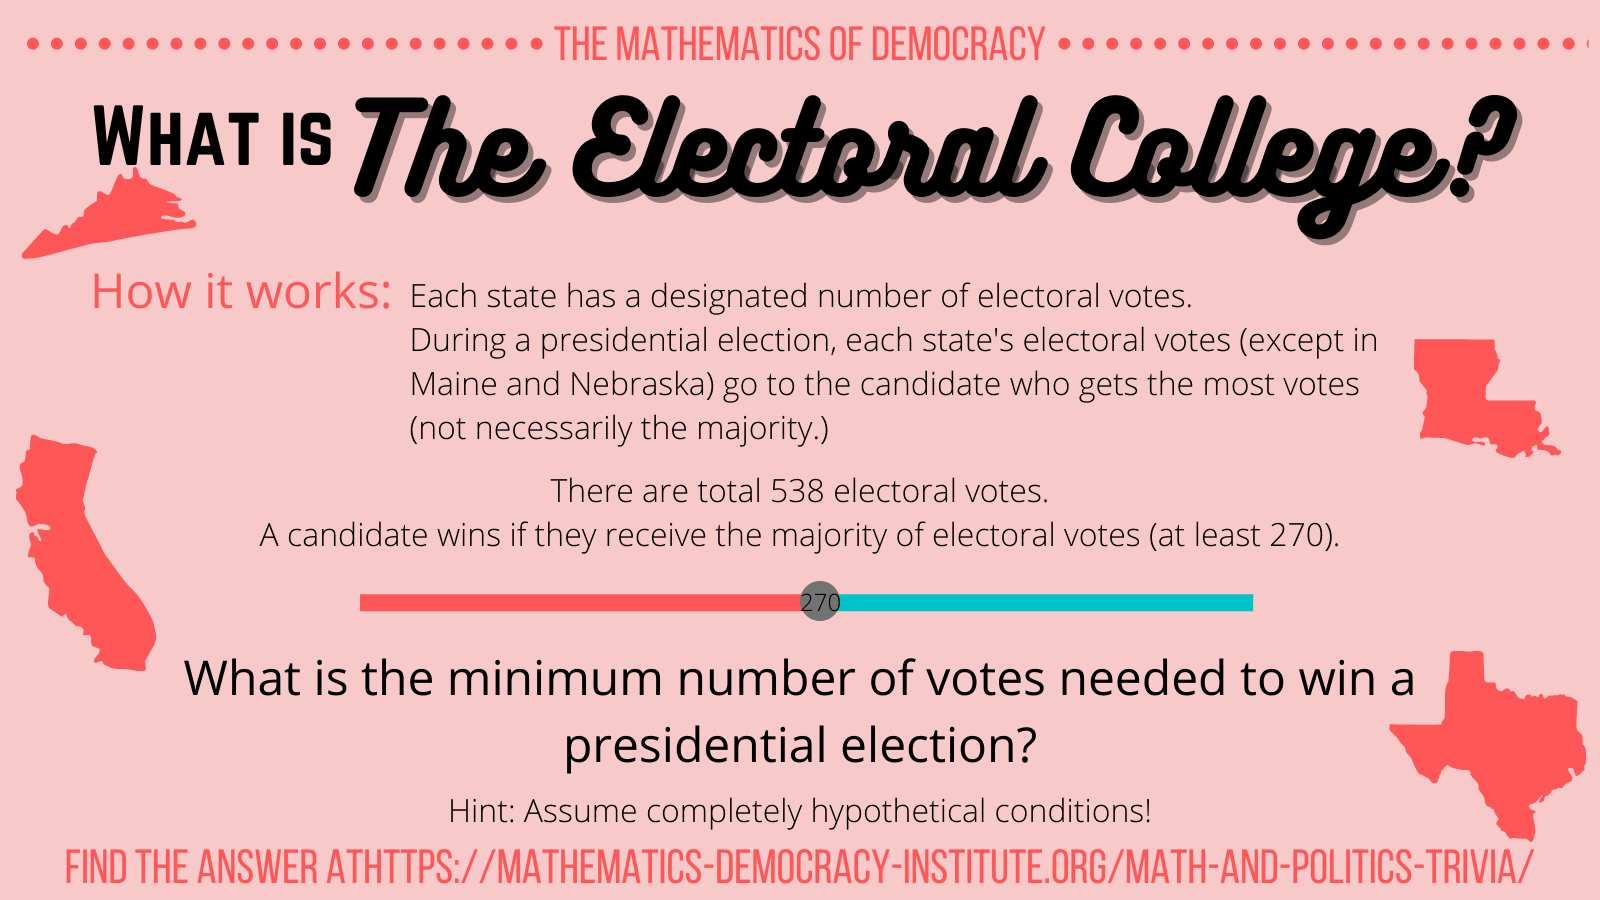
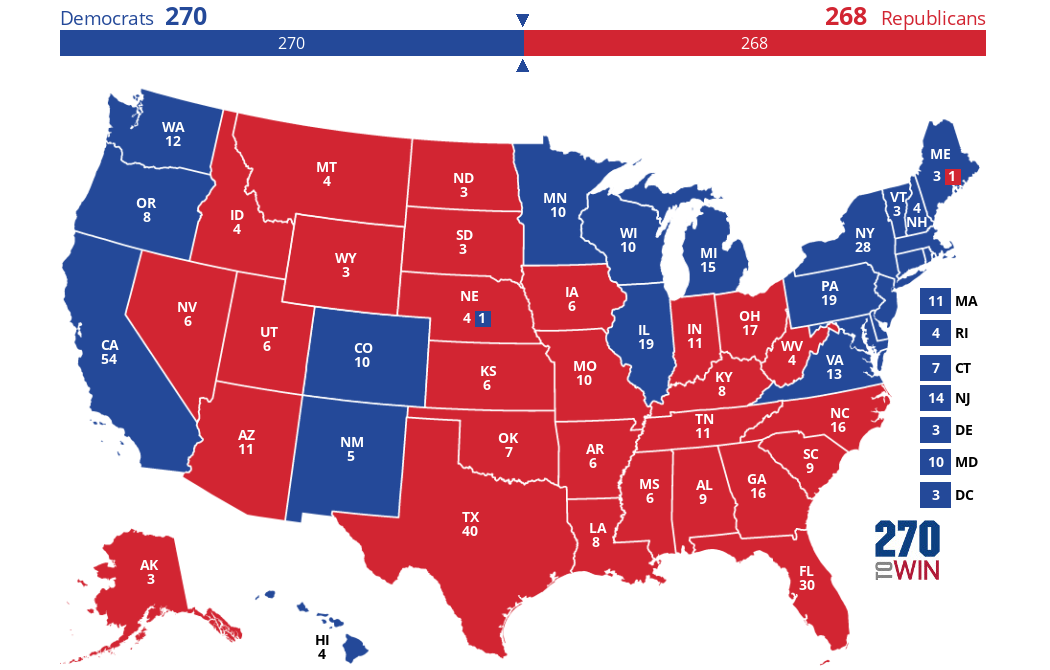
In the rapidly evolving landscape of Tech & Innovation, particularly concerning autonomous flight and advanced drone operations, understanding critical thresholds is paramount. Just as complex human systems rely on definitive markers for decision-making, sophisticated AI-driven platforms must establish clear mandates for action. The concept of “270 electoral votes,” while traditionally associated with civic processes, serves as a compelling analogy and, in some advanced computational frameworks, a literal representation of a decisive majority required for an autonomous system to proceed with a given task or validate a critical operational parameter. It symbolizes the point at which an aggregate of weighted data inputs reaches a conclusive state, signifying robust consensus or optimal pathway selection.
Data Aggregation and Decision Matrices
The foundation of any autonomous system’s ability to “collect electoral votes” lies in its data aggregation capabilities. Modern UAVs, equipped with an array of sophisticated sensors—from LiDAR and multispectral cameras to inertial measurement units (IMUs) and GPS receivers—continuously gather vast quantities of information about their environment. This raw data, much like individual opinions or preferences in a human election, must be processed, weighted, and analyzed.
A “decision matrix” within an autonomous system functions as the computational equivalent of an electoral map. Each sensor input, each algorithmic evaluation of environmental conditions, and each prediction from a machine learning model contributes a “vote.” However, not all votes are equal. Some data sources might carry more weight due to their accuracy, reliability, or relevance to the immediate mission objective. For instance, an obstacle detection sensor’s input might carry a higher weight when navigating a confined space compared to a general telemetry sensor. The system dynamically assigns these weights, effectively giving “more electoral votes” to critical data streams that directly influence safety, efficiency, or mission success. The collective processing of these weighted inputs leads to a cumulative “vote count,” guiding the drone towards a specific action, flight path adjustment, or mission phase transition. Achieving the “270 electoral votes” signifies that the system has garnered sufficient, validated, and weighted data to confidently execute its next step.
The Role of Remote Sensing in ‘Casting Votes’
Remote sensing technologies are the eyes and ears of autonomous systems, crucial for “casting votes” in this digital electoral process. High-resolution cameras, thermal imagers, and hyperspectral sensors collect granular data from afar, providing comprehensive situational awareness. For a drone engaged in environmental monitoring, for example, data points gathered on vegetation health, soil moisture levels, or heat signatures contribute distinct “electoral votes” towards determining the health status of a target area.
In applications like precision agriculture, remote sensing data from different spectral bands might collectively “vote” on the optimal time for irrigation or pesticide application. If 270 such “votes” (representing a robust consensus across various spectral indices and temporal analyses) indicate a specific stress level in crops, the autonomous spraying drone might initiate its task. This intricate interplay of data points, meticulously collected and processed, ensures that autonomous decisions are not based on singular inputs but on a well-rounded, validated perspective of the operational environment, akin to a mandate granted by a diverse electorate.
AI Follow Mode and Consensus Building for Operational Mandates
AI Follow Mode, a hallmark of advanced drone autonomy, exemplifies the dynamic consensus-building process required for smooth and responsive operation. When a drone in AI Follow Mode tracks a moving subject, it’s constantly “polling” various internal systems and external sensors to maintain its position and trajectory relative to the target. The “270 electoral votes” concept here translates into the continuous validation required for the drone to commit to a specific following pattern, speed, or altitude, effectively granting an “operational mandate.”
Predictive Analytics and Weighted Outcomes
The intelligence behind AI Follow Mode, and indeed much of autonomous flight, relies heavily on predictive analytics. Machine learning algorithms analyze historical flight data, environmental conditions, and the subject’s movement patterns to forecast future states. Each successful prediction, each validated motion vector, contributes to the “electoral vote” count. If the system’s predictive models consistently align with real-time sensor data, these “votes” accumulate, reinforcing the drone’s confidence in its current following strategy.
Conversely, discrepancies or unexpected changes in the subject’s movement or environmental factors might “revoke” some votes or introduce “dissenting opinions,” causing the system to re-evaluate. The “weighted outcomes” approach ensures that highly accurate, low-latency data from critical sensors (like optical flow or GPS differential data for subject tracking) are assigned greater electoral weight than potentially noisy or less reliable inputs. Achieving the “270 electoral votes” signifies that the system has reached a statistically robust confidence level, allowing it to smoothly and reliably execute its follow function without hesitation or error, effectively winning the mandate to proceed. This continuous election ensures seamless adaptation and precision in dynamic environments.
Achieving Operational ‘Mandates’
Beyond mere tracking, the concept of achieving an “operational mandate” extends to more complex autonomous missions. Consider a swarm of drones collaborating on a search and rescue operation or mapping a large disaster zone. Each drone acts as an independent entity contributing its unique data and processing power. For the swarm to coalesce on a common strategy – for instance, prioritizing a specific search area or deploying assets in a particular configuration – a collective decision must be reached. This collective decision is the “operational mandate,” and reaching it often involves a distributed “electoral” process.
Individual drones might “vote” for a certain strategy based on their local sensor readings and algorithmic assessments. These votes are then shared and aggregated across the swarm. A threshold of “270 electoral votes,” or a similar pre-defined consensus metric, would trigger the collective action. This ensures that the swarm operates not on the command of a single, potentially fallible unit, but on a robust, distributed consensus. Such a mandate allows the swarm to commit to coordinated actions, allocate resources efficiently, and adapt to changing conditions with a high degree of reliability and redundancy. It’s the digital equivalent of a unified directive, essential for complex, multi-agent autonomous operations.
Mapping Complex Environments for Strategic Outcomes
The precision and efficiency of modern mapping and remote sensing operations conducted by UAVs hinge on the systematic collection and interpretation of geospatial data. In this context, “what does 270 electoral votes mean” can be directly applied to the validation of mapping completeness, the assurance of data quality, and the strategic planning of flight paths in intricate or ‘contested’ aerial territories.
Navigating ‘Swing States’ in Drone Operations
Consider the challenge of mapping a vast, complex urban environment or an agricultural area with varied terrain and intermittent signal obstructions. These areas can be thought of as “swing states” in a drone’s mapping mission—regions where data collection might be ambiguous, challenging, or require multiple passes to ensure accuracy. To achieve a complete and reliable map, the autonomous system cannot rely on a single data pass or a lone sensor’s perspective. Instead, it must meticulously gather and cross-reference information from multiple vantage points, different sensor types, and even varying flight altitudes.
Each successful data capture, each validated georeference point, each clear image segment, contributes an “electoral vote” towards the overall map’s integrity. When the system encounters areas with high variability (our “swing states”), it might automatically schedule additional passes or deploy supplementary sensors to gather more “votes.” The threshold of “270 electoral votes” in this scenario represents the system’s confidence that all critical data points have been sufficiently covered, verified, and integrated, particularly in these challenging zones. It ensures that the final map product is not just complete on the surface but also possesses the depth, accuracy, and detail required for subsequent analysis or decision-making, effectively winning the “election” for a comprehensively mapped territory.
Real-time Data ‘Elections’ for Optimal Flight Paths
The calculation of optimal flight paths in dynamic environments is a continuous “election” where real-time data “votes” for the most efficient and safest trajectory. Autonomous navigation systems for drones perpetually evaluate numerous factors: wind conditions, remaining battery life, obstacle proximity, no-fly zones, and the mission’s primary objectives. Each of these factors generates weighted inputs, or “votes,” that influence the drone’s next move.
For instance, an emergent weather pattern indicating strong headwinds might “cast votes” for a lower altitude flight path, while dwindling battery power might “vote” for a more direct, energy-conserving route back to base. In congested airspace, the live feed from obstacle avoidance sensors would contribute heavy “votes” towards deviation maneuvers. The system continuously tallies these “votes” from a multitude of internal and external data streams. Reaching the critical “270 electoral votes” signifies that a definitive, optimal flight path has been identified and validated by the collective intelligence of the drone’s navigational AI. This robust consensus prevents indecision, enhances safety, and ensures that the drone always adheres to the most strategically sound trajectory, adapting in real-time to maintain its operational “mandate” through constant internal data elections. This dynamic decision-making process is the essence of sophisticated autonomous flight, turning complex data into decisive action.