
The Unseen Actuators of Aerial Grace: Interpreting “Smooth Muscles” in Drone Flight
In the intricate biological systems of the human body, smooth muscles perform essential, often involuntary, functions that ensure the seamless operation of internal organs and systems. They contract and relax with a fluid, adaptive precision, maintaining homeostasis and enabling vital processes without conscious effort. When we transpose this concept to the realm of advanced flight technology, specifically drones, the question “what do smooth muscles do?” takes on a fascinating, metaphorical significance. In this context, “smooth muscles” represent the sophisticated, often unseen, technological systems and algorithms that enable drones to achieve remarkable stability, fluid movement, and autonomous functionality, mimicking the effortless efficiency of biological systems.
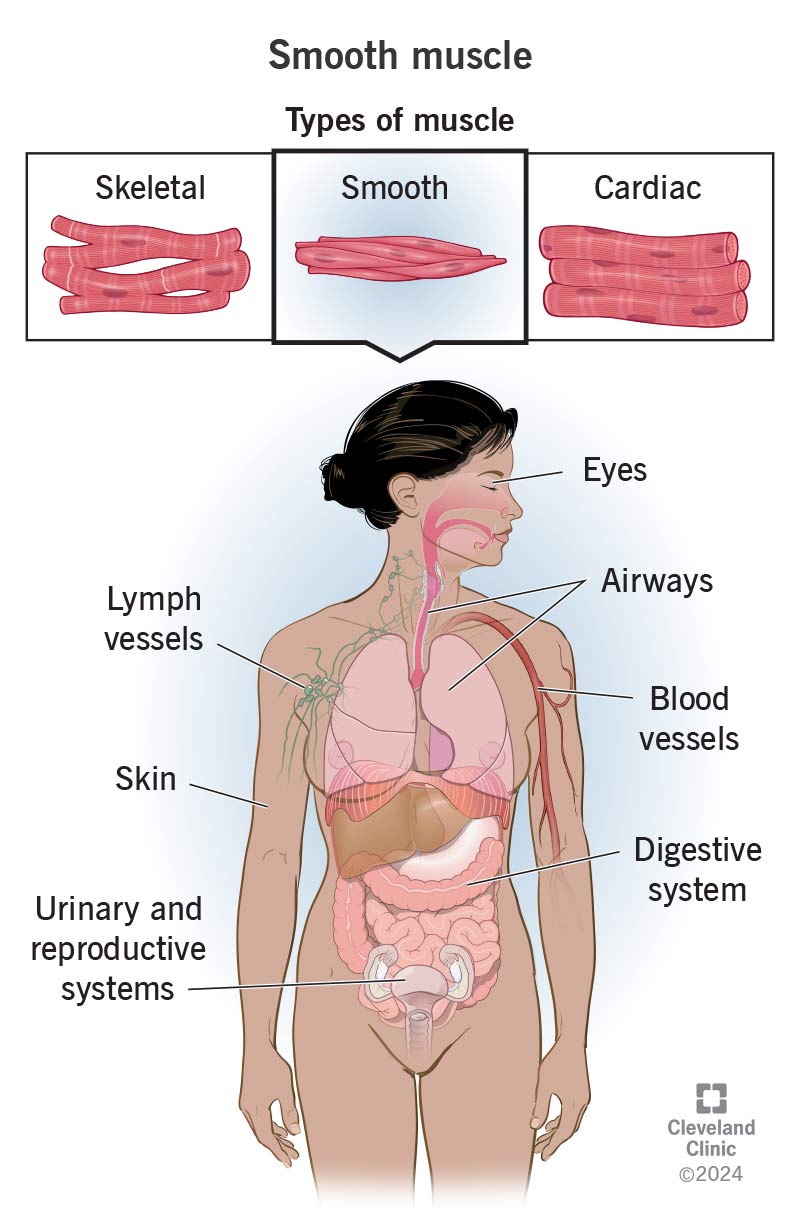
These “smooth muscles” of a drone are not physical contractile tissues, but rather an interconnected network of sensors, processors, and control algorithms that work tirelessly in the background. They are the core components of flight technology that allow a multi-rotor aircraft to hover steadfast against a gust of wind, follow a complex trajectory with precision, or execute a cinematic pan with buttery smoothness. They impart an organic, almost lifelike grace to machines that are inherently rigid and mechanical, ensuring that every flight operation, from takeoff to landing, is executed with controlled, adaptive, and often automated precision. Understanding these systems is key to appreciating the sophistication embedded in modern drone flight. They are the silent orchestrators of aerial stability, navigation, and responsiveness, empowering drones to perform tasks ranging from intricate aerial cinematography to critical infrastructure inspection with unparalleled dexterity.
Stabilization Systems: The Core of Aerial Fluidity
The most fundamental aspect of a drone’s “smooth muscle” capability lies in its stabilization systems. These are the primary mechanisms that counteract external disturbances and maintain a steady, level flight attitude, preventing uncontrolled drifts or erratic movements. Without robust stabilization, a drone would be virtually unflyable, tumbling erratically with every slight change in air current or motor thrust.
Inertial Measurement Units (IMUs) and Gyroscopes
At the heart of any sophisticated drone stabilization system is the Inertial Measurement Unit (IMU). This critical component is a marvel of miniaturized engineering, typically comprising a combination of gyroscopes and accelerometers. Gyroscopes measure the drone’s angular velocity and orientation (roll, pitch, yaw), detecting any rotational movement around its axes. Accelerometers, on the other hand, measure linear acceleration, providing data on the drone’s translational movement and helping to determine its inclination relative to gravity.
The data streaming from these sensors is incredibly high-frequency and precise. It provides the flight controller with a real-time, dynamic understanding of the drone’s current orientation and how it is changing in three-dimensional space. This continuous feedback loop is analogous to the proprioceptive senses in biological organisms, constantly informing the system about its body’s position and movement.
Flight Controllers and PID Loops
The raw data from the IMU is fed directly into the drone’s flight controller, which acts as the “brain” orchestrating the smooth muscular actions. The flight controller’s primary task in stabilization is to process this sensor data and translate it into precise commands for the drone’s motors and propellers. It achieves this through complex control algorithms, most notably the Proportional-Integral-Derivative (PID) control loop.
The PID controller constantly calculates the “error” – the difference between the drone’s desired state (e.g., level hover, steady forward flight) and its actual state as reported by the IMU.
- Proportional (P) component: Reacts to the current error, applying a corrective force proportional to its magnitude. A larger error elicits a stronger immediate response.
- Integral (I) component: Accounts for past errors, helping to eliminate steady-state errors and long-term drift. It “remembers” consistent deviations and applies a cumulative correction.
- Derivative (D) component: Predicts future errors based on the rate of change of the current error. This allows the system to damp oscillations and prevent overshooting the target, resulting in a much smoother, more responsive correction.
Together, the IMU and the PID-tuned flight controller work in exquisite synchronicity, making thousands of micro-adjustments per second to motor thrust. This continuous, rapid, and adaptive feedback mechanism is precisely what allows a drone to maintain an incredibly stable position, resist external forces like wind, and execute fluid movements, embodying the essence of “smooth muscle” functionality in flight technology.
Navigation and Pathfinding: Orchestrating Effortless Trajectories
Beyond mere stabilization, the “smooth muscles” of a drone also enable sophisticated navigation and pathfinding capabilities. These systems allow drones to maintain specific positions, follow pre-programmed routes, and execute complex maneuvers with precision and grace, freeing the pilot from constant manual adjustments and allowing for truly autonomous or semi-autonomous operations.
GPS and GNSS Integration
Global Positioning System (GPS) and other Global Navigation Satellite Systems (GNSS) like GLONASS, Galileo, and BeiDou are foundational to a drone’s ability to operate smoothly within a larger spatial context. By receiving signals from multiple satellites, the drone’s onboard GNSS receiver can triangulate its precise geographical coordinates (latitude, longitude, and altitude) with high accuracy.
This positional data is crucial for:
- Position Hold: Allowing the drone to maintain a fixed position in 3D space, even in windy conditions, without continuous pilot input. This is analogous to a biological system holding a posture effortlessly.
- Waypoint Navigation: Enabling the drone to follow a pre-defined sequence of geographical points, flying a precise, smooth path between them. This allows for automated surveys, mapping missions, and cinematic flight paths that would be impossible to achieve manually with such consistency.
- Return-to-Home (RTH): A critical safety feature that guides the drone back to its takeoff point autonomously, often along the most efficient and safest route, demonstrating inherent “smooth” decision-making for recovery.

The seamless integration of GNSS data with the IMU and flight controller ensures that the drone not only knows where it is but can also smoothly adjust its flight path to reach its intended destination, making constant, subtle corrections to stay on course.
Vision Positioning Systems (VPS) and Optical Flow
While GNSS provides global positioning, it can be less accurate or even unavailable indoors or in areas with poor satellite reception. This is where Vision Positioning Systems (VPS) and optical flow technology become vital, providing localized “smooth muscle” intelligence for precision positioning, especially at low altitudes.
VPS typically employs downward-facing cameras and sometimes ultrasonic sensors. The camera captures images of the ground texture, and intelligent algorithms analyze the “optical flow” – how these patterns move across the camera’s field of view. By tracking changes in these visual patterns, the drone can accurately determine its horizontal movement and maintain a steady hover even without GPS. Ultrasonic sensors complement this by providing precise altitude measurements.
This combination allows drones to:
- Indoor Stability: Maintain precise indoor positioning, crucial for inspection tasks or flying in GPS-denied environments.
- Precision Landing: Execute exceptionally smooth and accurate landings, often within a few centimeters of a target.
- Low-Altitude Maneuvering: Perform intricate movements close to the ground with enhanced stability and control, vital for detailed photography or object tracking.
These vision-based systems provide a high-resolution, localized “sense” of the environment, enabling the drone’s flight controller to make extremely fine-tuned, “smooth” adjustments, reflecting the adaptive precision of biological smooth muscles in highly specific tasks.
Adaptive Control and Obstacle Avoidance: Responsive “Muscles” for Dynamic Environments
The “smooth muscle” metaphor extends further into a drone’s capacity for adaptive control and intelligent obstacle avoidance. These advanced features allow drones to interact safely and efficiently with dynamic environments, making real-time, fluid adjustments to their flight path to maintain mission parameters without abrupt changes or collisions.
Sensor Fusion and Environmental Mapping
Modern drones are equipped with an array of perception sensors that provide a comprehensive understanding of their surroundings. This typically includes:
- Stereo Cameras: Mimicking human binocular vision to perceive depth and distance.
- Time-of-Flight (ToF) Sensors: Emitting light pulses and measuring the time it takes for them to return, offering precise distance measurements.
- Ultrasonic Sensors: Using sound waves for proximity detection, especially at close range.
- Millimeter-Wave Radar: Providing robust obstacle detection in challenging conditions like fog or darkness.
The data from these disparate sensors is not processed in isolation but rather through a process called sensor fusion. Advanced algorithms combine and interpret the inputs from multiple sensor types to create a unified, robust, and real-time 3D map of the drone’s environment. This holistic perception allows the drone to identify obstacles, assess their distance and movement, and understand the navigable space around it with remarkable clarity. This environmental awareness is crucial for smooth, safe, and intelligent operation, much like how biological systems perceive and react to their surroundings.
Predictive Algorithms and Real-time Adjustments
With a comprehensive environmental map, the drone’s flight controller employs sophisticated predictive algorithms to anticipate potential collisions and plot safe, “smooth” alternative paths. These algorithms continuously analyze the drone’s current trajectory relative to detected obstacles and predict future positions.
When an obstacle is detected, the drone’s “smooth muscles” – its flight control and navigation systems – engage in an adaptive response:
- Dynamic Path Planning: Instead of simply stopping or rerouting abruptly, the drone can intelligently adjust its flight path to smoothly circumnavigate the obstacle, maintaining its overall mission objectives. This might involve a gentle ascent, a subtle shift to the side, or a calculated descent, all executed without jarring movements.
- Collision Avoidance: In situations where a direct collision is imminent, the system can autonomously brake, hover, or perform an evasive maneuver with precision. The goal is always to perform these actions as smoothly and safely as possible, minimizing disturbance to the flight or captured data.
- Intelligent Follow Modes: When tracking a moving subject (e.g., in cinematic applications), the drone’s adaptive control ensures it maintains a consistent distance and angle, intelligently anticipating the subject’s movement and making smooth, continuous adjustments rather than jerky corrections.
This ability to perceive, predict, and react with fluid, intelligent adjustments epitomizes the “smooth muscle” functionality in drone flight technology. It transforms the drone from a rigid machine into an adaptable, responsive, and almost intuitively moving aerial platform, capable of operating in complex and dynamic environments with remarkable grace and safety.

Future of “Smooth Muscle” Technology: Evolving Autonomous Capabilities
The trajectory of drone flight technology is continually moving towards greater autonomy and more seamless, “smooth” operation. The capabilities we see today, from precise GPS-based navigation to intelligent obstacle avoidance, represent significant milestones in emulating the adaptive efficiency of biological systems. However, the future promises even more sophisticated “smooth muscle” technology.
Advanced artificial intelligence (AI) and machine learning (ML) are at the forefront of this evolution. These technologies are enabling drones to learn from experience, adapt to novel environments, and make even more nuanced, predictive flight decisions. Expect to see:
- Enhanced Semantic Understanding: Drones that can not only detect obstacles but also categorize them (e.g., distinguishing between a tree, a building, or a person) and react with context-appropriate, smooth maneuvers.
- Predictive Environmental Modeling: AI-powered systems that can build highly detailed, dynamic models of complex environments in real-time, allowing for even more optimized and fluid path planning through challenging terrains.
- Human-Machine Teaming: Drones that can interpret complex human commands and intentions more intuitively, executing actions with a fluid responsiveness that feels like an extension of the operator’s will.
- Energy-Optimized Smoothness: Algorithms that continuously optimize flight paths and motor outputs not just for stability but also for maximum energy efficiency, extending flight times while maintaining graceful movement.
Ultimately, the goal is to create drones that operate with an increasing level of “smoothness”—meaning not just physical stability, but also intelligence, responsiveness, and adaptability that approaches the effortless functionality of biological systems. The “smooth muscles” of future drones will perform even more complex tasks with greater autonomy, precision, and a fluidity that continues to redefine what is possible in the skies.