
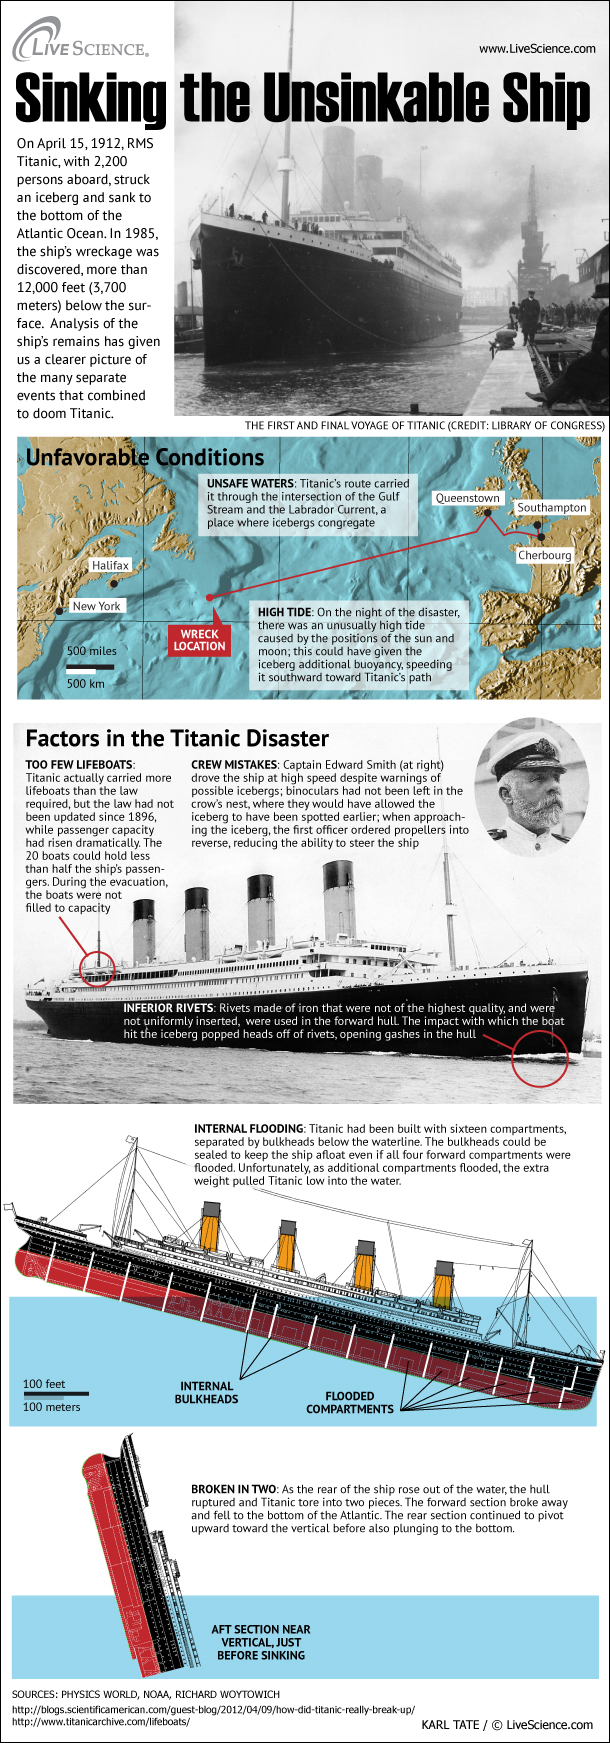
The RMS Titanic, a marvel of engineering for its time, met its tragic end in the frigid waters of the North Atlantic in the early hours of April 15, 1912. This date is etched into history as a stark reminder of human vulnerability in the face of nature and the limitations of early 20th-century technology. While the exact moment of its submersion passed more than a century ago, the legacy of the Titanic continues to profoundly influence advancements in maritime safety, navigation, and, critically, the realm of modern Tech & Innovation, particularly in autonomous flight, mapping, and remote sensing. Had the world possessed the sophisticated tools and methodologies available today, the narrative surrounding the Titanic’s fateful voyage, from prevention to investigation, would have been drastically different.

Autonomous Exploration and Deep-Sea Mapping
The Titanic’s resting place, nearly 12,500 feet (3,800 meters) beneath the ocean surface, remained undiscovered for over 70 years, a testament to the challenges of deep-sea exploration without modern autonomous systems. Today, the very principles that define autonomous flight in the air—precision navigation, sensor-driven data acquisition, and robust stabilization—are routinely applied to the underwater domain through Autonomous Underwater Vehicles (AUVs) and Remotely Operated Vehicles (ROVs). These systems represent a critical facet of Tech & Innovation, enabling mapping and exploration of environments previously inaccessible or too dangerous for human intervention.
The Imperative of Remote Sensing in Hostile Environments
The deep ocean, much like extraterrestrial space or hazardous terrestrial zones, is a hostile environment characterized by extreme pressure, perpetual darkness, and near-freezing temperatures. This mirrors the complex operational challenges that drive the development of advanced autonomous flight technologies for aerial drones. For the Titanic’s wreck site, remote sensing via AUVs and ROVs equipped with an array of sophisticated sensors has been indispensable. These “autonomous underwater flyers” can systematically survey vast areas, enduring conditions that would crush conventional submersibles, collecting data that paints a comprehensive picture of the wreck and its surrounding debris field. The ability of these systems to execute pre-programmed missions or respond to remote pilot commands, all while maintaining precise depth and trajectory, showcases the direct application of autonomous flight principles in a non-aerial context.
Advanced Sonar and Lidar Technologies for Seafloor Mapping
A cornerstone of modern deep-sea exploration and mapping is the evolution of sonar and, increasingly, underwater lidar technologies. Multi-beam sonar systems, mounted on AUVs or ROVs, emit multiple sound pulses in a fan-shaped pattern, measuring the time it takes for these pulses to return. This creates highly detailed, high-resolution bathymetric maps of the seafloor, far exceeding the capabilities of the single-beam echo sounders of yesteryear. Such systems could have precisely mapped the seabed for potential hazards long before 1912. For wreck detection, side-scan sonar provides acoustic images of the seafloor, revealing subtle features and anomalies that indicate submerged objects.
When the Titanic wreck was finally located in 1985, these nascent technologies played a pivotal role. Today, advanced iterations of these sensors, integrated with autonomous platforms, allow for the creation of intricate 3D models of the wreck, down to individual rivets and fragile artifacts. Lidar, typically an aerial technology, is also being adapted for shallow underwater use, offering even finer resolution optical mapping in clearer waters. For the deep, dark ocean where the Titanic rests, specialized underwater cameras and powerful lighting systems, guided by highly stable autonomous platforms, provide visual data that complements the sonar maps, allowing for detailed condition assessment and environmental monitoring without disturbing the site. These mapping and remote sensing capabilities are fundamental to understanding deep-sea environments and managing historical sites like the Titanic.
Precision Navigation and Positioning
The precision with which modern autonomous vehicles operate is a direct outcome of advanced navigation and positioning systems. While GPS is the standard for aerial drones, underwater vehicles rely on a combination of Inertial Navigation Systems (INS), Doppler Velocity Logs (DVL), and acoustic positioning systems. INS systems track the vehicle’s position, orientation, and velocity using accelerometers and gyroscopes, independent of external references. DVLs measure the vehicle’s speed relative to the seabed or water column, providing accurate velocity data. For absolute positioning, acoustic systems like Ultra-Short Baseline (USBL) or Long Baseline (LBL) are used, which triangulate the AUV’s position relative to transponders placed on the surface or seabed.
These technologies enable AUVs to “fly” highly accurate survey patterns, ensuring complete coverage of an area and precise georeferencing of all collected data. This level of navigational accuracy would have been unimaginable in 1912, where rudimentary celestial navigation and dead reckoning were the primary methods. Today, such precision not only facilitates the discovery and detailed mapping of wrecks but also enables continuous monitoring of changes over time, tracking the degradation of materials or the movement of debris.
AI-Powered Analysis and Predictive Modeling
Beyond merely collecting data, the true power of modern Tech & Innovation lies in its ability to process, analyze, and learn from vast datasets. Artificial Intelligence (AI) and machine learning algorithms are transforming how we understand complex environments, predict potential hazards, and manage autonomous systems, offering insights that could have altered the Titanic’s fate.

Data Fusion and Interpretation for Wreck Analysis
AI plays a crucial role in fusing disparate data sources—from sonar scans and optical imagery to environmental sensor readings—into coherent, actionable information. For the Titanic wreck, AI algorithms can automatically identify structural degradation, categorize debris, and even track the slow but relentless process of biodeterioration caused by rusticles. By analyzing changes in 3D models generated over decades, AI can reveal patterns of collapse or erosion, informing preservation efforts and scientific studies on deep-sea ecosystems. This capability transforms raw sensor data into rich, interpretive insights, providing a dynamic understanding of a static historical site. Such analytical depth was, of course, entirely absent in the immediate aftermath of the 1912 disaster.
Predictive Collision Avoidance and Route Optimization
Perhaps the most impactful application of AI in the context of preventing a disaster like the Titanic’s would be in predictive modeling and autonomous navigation. Modern maritime navigation systems, increasingly augmented by AI, integrate real-time data from radar, sonar, satellite imagery (for ice floes), and other vessels’ Automatic Identification System (AIS) transponders. AI algorithms can then analyze this torrent of information to identify potential collision courses, predict the movement of hazards (like icebergs), and recommend optimal, safe routes in real-time.
Had such AI-powered predictive capabilities been available in 1912, coupled with effective communication systems, the Titanic’s bridge officers would have had an unparalleled awareness of the ice field’s extent and density. Autonomous navigation systems, whether for large vessels or dedicated ice-monitoring AUVs, could have identified the fatal iceberg with ample time for evasion or alerted the crew to extreme danger. This proactive hazard detection and route optimization is a direct evolution of “autonomous flight” principles, applied to ensure safe passage in complex environments.
Environmental Monitoring and Material Degradation Analysis
Autonomous sensor networks, often deployed by AUVs, now continuously monitor marine environments, collecting data on ocean currents, temperature, salinity, and biogeochemical processes. AI algorithms can process this data to understand its impact on submerged structures. For the Titanic, this means analyzing how environmental factors accelerate or decelerate the wreck’s decay, which areas are most vulnerable, and how marine life interacts with the structure. This level of environmental intelligence contributes not only to historical preservation but also to broader scientific understanding of deep-sea ecosystems and the long-term effects of human structures in the ocean.
The Evolution of Disaster Response and Recovery Through Innovation
The response to the Titanic disaster was characterized by a lack of coordinated search and rescue capabilities and limited technology for locating survivors or the wreck. Today, Tech & Innovation, particularly in autonomous flight and remote sensing, offers revolutionary improvements in disaster response, search, and recovery operations.
Rapid Deployment of Autonomous Search Systems
In the event of a modern maritime incident, AUVs and aerial drones (UAVs) can be rapidly deployed to survey vast oceanic areas for debris, life rafts, or submerged objects. AUVs equipped with side-scan sonar and magnetometers can quickly map the seafloor to locate a missing vessel, while aerial drones with thermal cameras can scan the surface for survivors. This rapid, wide-area search capability dramatically reduces response times and increases the chances of successful recovery or rescue, a stark contrast to the days when ships merely hoped to stumble upon distress signals or wreckage. The ability of these autonomous platforms to operate for extended periods without human intervention further enhances their effectiveness in critical time-sensitive situations.
Telepresence and Remote Operation
The development of highly capable ROVs and advanced satellite communication has enabled “telepresence” for underwater operations. Experts can now pilot ROVs from land-based control centers thousands of miles away, guiding sophisticated robotic manipulators for precise sampling, repair, or documentation. This eliminates the need to expose human divers to hazardous deep-sea conditions and allows a global pool of experts to contribute to complex operations. For the Titanic wreck, telepresence allows scientists and historians worldwide to virtually “visit” and study the site, conducting detailed inspections and gathering data without ever leaving their labs. This remote operation capability is a key element of modern “autonomous flight” systems, extending human reach into extreme environments.
Lessons Learned and Future Safety Innovations
The sinking of the Titanic was a catastrophic turning point, leading to the establishment of the International Convention for the Safety of Life at Sea (SOLAS) and the International Ice Patrol. These human-driven regulatory and operational changes were crucial. However, modern Tech & Innovation now provides additional, unprecedented layers of proactive safety and reactive investigative capabilities. From autonomous systems that monitor ocean conditions and vessel integrity in real-time to AI-powered decision support for captains, the lessons of the Titanic continue to drive the evolution of technologies designed to ensure that such a tragedy never recurs. The relentless pursuit of innovation in autonomous flight, mapping, and remote sensing remains a testament to humanity’s enduring commitment to safety and exploration, profoundly shaped by the echoes of April 15, 1912.