
The Brain of Modern Drone Innovation
At the heart of every sophisticated drone lies a central processing unit (CPU), the computational engine responsible for executing instructions, performing complex calculations, and managing the myriad operations that define a drone’s capabilities. Far from being a mere component, the CPU is the “brain” that enables the cutting-edge technologies and innovations transforming the drone industry, from autonomous flight and AI-driven intelligence to advanced mapping and remote sensing. Without a powerful and efficient CPU, the intelligent features that characterize modern UAVs—such as AI follow mode, precise obstacle avoidance, real-time data analysis, and intricate flight path generation—would simply not be possible.
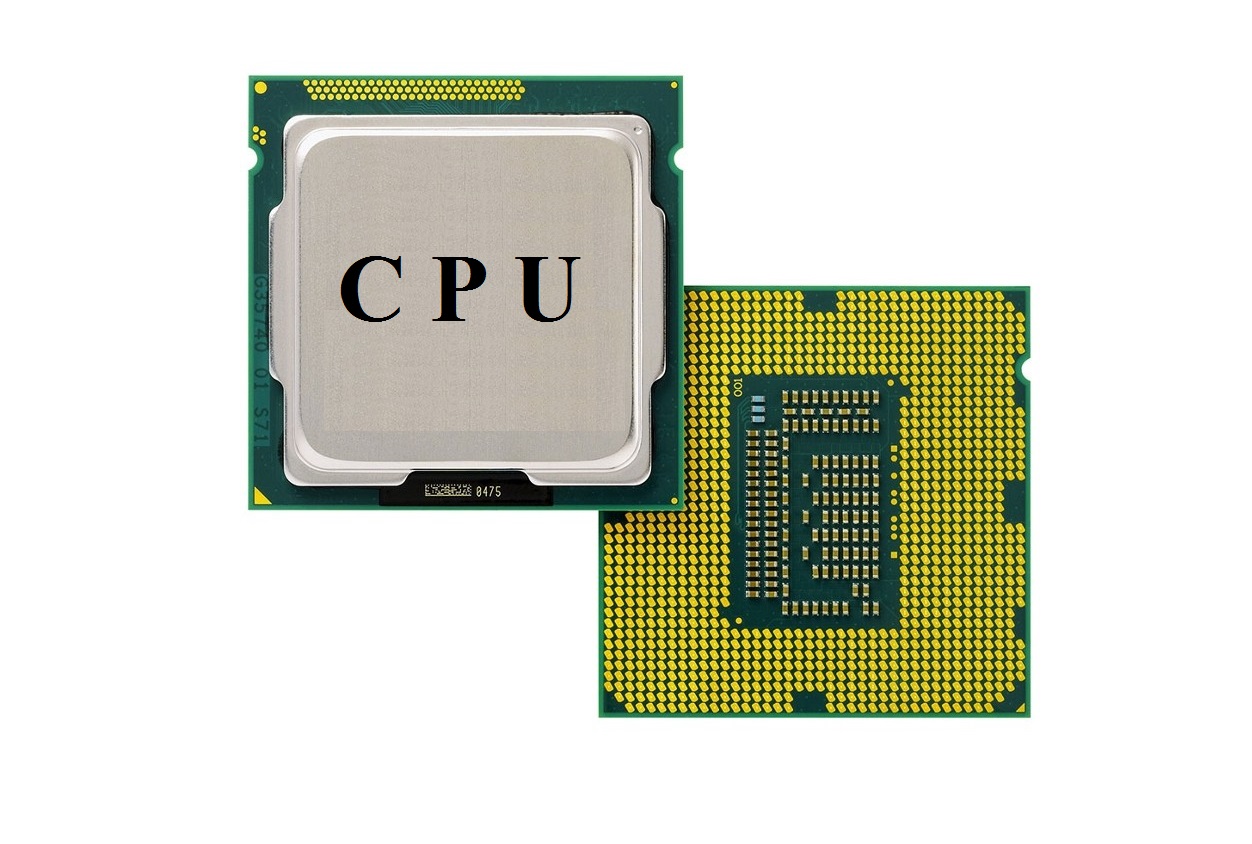
The evolution of drone technology has mirrored the advancements in CPU design. Early drones relied on relatively simple microcontrollers for basic flight stabilization and control. However, as ambitions grew towards more complex tasks like intelligent navigation, object recognition, and on-the-fly data processing, the need for more robust computing power became paramount. Today, high-performance CPUs, often working in conjunction with specialized co-processors like Graphics Processing Units (GPUs) or Neural Processing Units (NPUs), are foundational to pushing the boundaries of what drones can achieve in various applications, making them indispensable tools for a range of professional and industrial tasks. They are the bedrock upon which all the complex algorithms for perception, planning, and action are built and executed, dictating the responsiveness, accuracy, and overall intelligence of the drone system.
Powering Autonomous Flight and AI-Driven Intelligence
The promise of truly autonomous drones and intelligent flight modes rests squarely on the shoulders of the central processing unit. These advanced capabilities demand immense computational power to process vast amounts of data in real-time, interpret environmental cues, and make instantaneous decisions without human intervention.
Real-time Decision Making and Obstacle Avoidance
For a drone to navigate autonomously, it must constantly perceive its surroundings, understand its position within that environment, and predict potential hazards. This requires the CPU to rapidly ingest data from multiple sensors—including LiDAR, ultrasonic sensors, vision cameras, and inertial measurement units (IMUs). The CPU then executes intricate algorithms to fuse this data, construct a dynamic 3D map of the environment, identify obstacles, and calculate collision-free flight paths. This entire process, from sensor input to motor command, must occur within milliseconds to ensure the drone can react safely and effectively in dynamic conditions. A robust CPU handles the intensive calculations for predictive modeling, trajectory planning, and dynamic re-routing, making decisions that are critical for mission success and safety. The efficiency and speed of the CPU directly correlate with the drone’s ability to operate safely in complex, changing environments.
AI Follow Mode and Object Recognition
AI-powered features like “follow mode” and sophisticated object recognition are prime examples of CPU-intensive drone innovations. To track a moving subject, the drone’s camera streams live video data to the CPU, which then runs machine learning models (often convolutional neural networks) to detect, classify, and track the target object in real-time. This involves segmenting the object from the background, predicting its movement, and adjusting the drone’s flight path and camera angle accordingly. The CPU must not only process high-definition video frames at a high rate but also execute these complex AI inference models efficiently. This often necessitates specialized instructions sets or, in more advanced systems, offloading some tasks to a dedicated NPU or GPU, orchestrated by the main CPU. The ability of the CPU to perform these tasks on-board, without relying on a constant cloud connection, is crucial for responsive and reliable AI behavior, a concept known as “edge computing.”
Complex Algorithm Execution for Autonomy
Beyond basic control, modern autonomous drones rely on sophisticated algorithms for tasks such as simultaneous localization and mapping (SLAM), optimal path planning, and advanced mission execution. SLAM, for instance, allows a drone to build a map of an unknown environment while simultaneously tracking its own position within that map. This requires continuous processing of sensor data (e.g., visual odometry, LiDAR point clouds) to match features, calculate transformations, and refine positional estimates—a computationally demanding task that a powerful CPU orchestrates. Similarly, algorithms for optimizing flight paths based on factors like energy efficiency, time constraints, and coverage requirements place significant demands on the CPU to explore potential routes and select the most effective one, often adapting in real-time to new information or changing objectives.

Enabling Advanced Mapping and Remote Sensing
Drones have revolutionized mapping and remote sensing, providing unprecedented access to aerial data. The capacity to gather, process, and analyze this data effectively is largely due to the capabilities of the onboard central processing unit.
Data Acquisition and Pre-processing
In mapping and remote sensing missions, drones are typically equipped with an array of high-resolution cameras (RGB, multispectral, hyperspectral), LiDAR scanners, and thermal sensors. These sensors generate enormous volumes of raw data during a flight. The CPU plays a critical role in managing the high-bandwidth data streams from these multiple sensors, ensuring synchronized data capture, timestamping, and preliminary storage. For example, in photogrammetry, the CPU might perform initial image compression or basic geometric corrections before data is transmitted or stored, ensuring data integrity and optimizing subsequent processing. The efficiency with which the CPU can handle this data pipeline directly impacts the mission’s effectiveness and the quality of the final output.
Onboard Photogrammetry and SLAM for Real-time Mapping
Historically, aerial mapping data was processed offline on powerful ground stations. However, advancements in drone CPUs are increasingly enabling onboard photogrammetry and real-time mapping capabilities. For instance, a drone’s CPU can perform initial alignment of overlapping images, generate sparse point clouds, or even create rough 3D models of surveyed areas while still in flight. This immediate feedback allows operators to verify data coverage and quality, make on-the-spot adjustments, or assess the progress of a mission. For applications requiring rapid deployment and immediate insights, such as disaster response or construction monitoring, the CPU’s ability to facilitate real-time mapping through SLAM algorithms, merging visual and depth data to create dynamic 3D representations, is invaluable. This capability significantly reduces post-processing time and accelerates decision-making processes, marking a significant innovation in how geospatial data is utilized.
Geospatial Data Integration and Analysis
Beyond just processing images, the CPU is central to integrating various data types for comprehensive geospatial analysis. It combines GPS coordinates, IMU data (pitch, roll, yaw), and sensor readings to accurately tag and georeference every piece of acquired data. This ensures that the generated maps, 3D models, or remote sensing outputs are precisely located in space. Furthermore, for specialized remote sensing applications (e.g., agricultural analysis using multispectral imagery), the CPU can perform basic analytics on board, such as calculating vegetation indices (e.g., NDVI) in real-time. This immediate analysis can guide subsequent flight patterns or highlight areas of interest for more detailed inspection, demonstrating the CPU’s role not just in data acquisition but also in preliminary data interpretation and intelligent mission adaptation.
The Evolution of Drone Processors
The demands placed on drone CPUs are continually growing, leading to a fascinating evolution in processor technology tailored for aerial platforms. Early flight controllers often used microcontrollers from companies like STMicroelectronics (e.g., STM32 series) or NXP, which were perfectly adequate for basic PID (Proportional-Integral-Derivative) control loops to maintain stable flight. As drones became smarter, capable of more complex tasks, the industry saw a shift towards more powerful, general-purpose application processors.
Today, many advanced drones incorporate system-on-chips (SoCs) developed by companies like Qualcomm (Snapdragon series) or NVIDIA (Jetson series). These SoCs integrate not just powerful multi-core CPUs but also robust GPUs, specialized AI accelerators (NPUs or TPUs), memory controllers, and various communication interfaces onto a single chip. This integrated approach is crucial for drones, where space, weight, and power consumption are critical constraints. The CPU, as the orchestrator, leverages these co-processors to handle highly parallelizable tasks like image processing for computer vision (on the GPU) or neural network inference for AI (on the NPU/TPU), freeing the main CPU cores for critical flight control, operating system management, and complex decision-making algorithms.
The key factors driving the selection of a drone CPU include not just raw clock speed or core count, but also power efficiency (measured in Watts per instruction), thermal management capabilities, and the presence of specialized hardware accelerators. Future trends point towards even more highly integrated and specialized processors, with increasing emphasis on low-power AI acceleration and enhanced security features, enabling drones to perform even more complex autonomous tasks, manage larger datasets, and operate safely and reliably in increasingly diverse and challenging environments. The continuous innovation in CPU technology remains a cornerstone for unlocking the full potential of future drone applications across all facets of tech and innovation.