
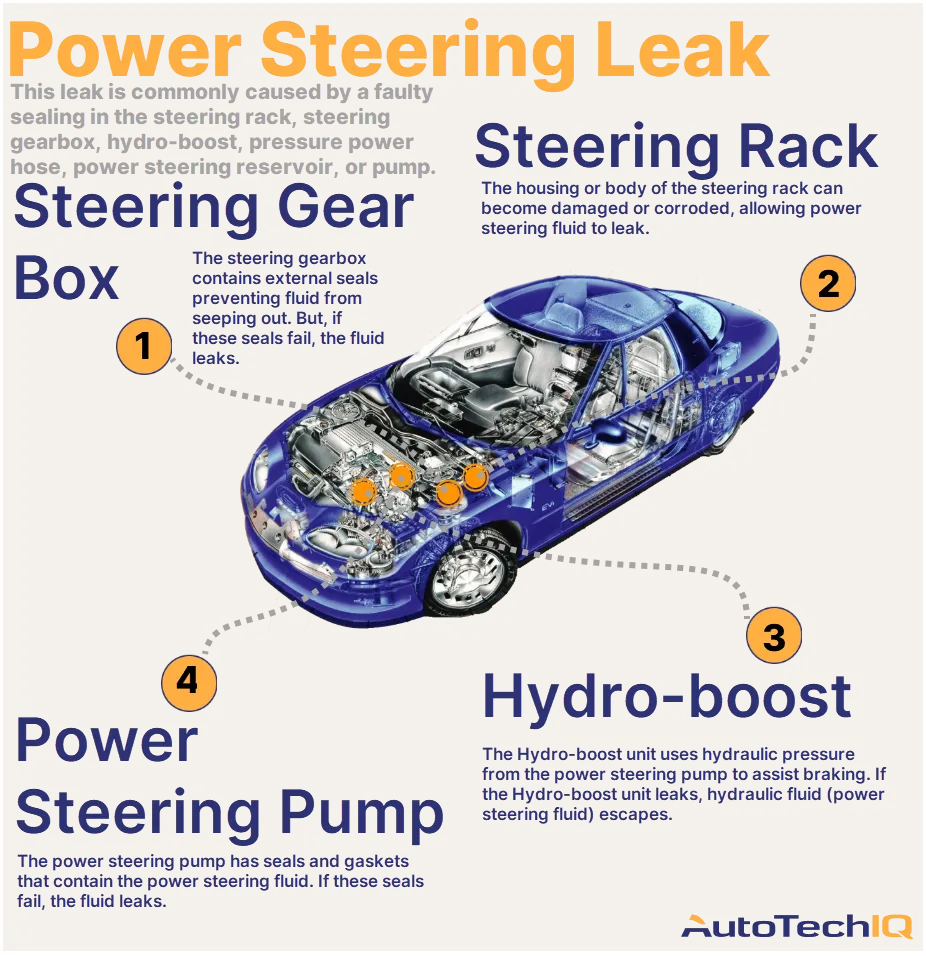
In the intricate domain of modern flight technology, where precision and stability are paramount, the concept of a “power steering fluid leak” might seem anachronistic at first glance. However, within the advanced control systems of unmanned aerial vehicles (UAVs), this term serves as a powerful metaphor for critical degradations in the integrity and seamless operation of assisted flight mechanisms. It signifies a compromise in the continuous flow of data, stable energy, and precise command signals that enable a drone’s sophisticated navigation and stabilization, akin to an automotive system losing its hydraulic medium. Understanding these “leaks” is fundamental to maintaining optimal drone performance, ensuring operational safety, and pushing the boundaries of autonomous flight.
Deconstructing “Power Steering” in Flight Technology
To grasp the implications of a “fluid leak,” it is essential to first understand what constitutes “power steering” in the context of flight technology. Unlike terrestrial vehicles, drones do not possess hydraulic power steering pumps. Instead, their “power steering” refers to the complex interplay of sensors, algorithms, and actuators that interpret pilot commands or autonomous directives, then translate them into precise, stabilized flight maneuvers. This system provides the ‘assist’ that makes flight smooth, responsive, and resilient to external disturbances.
The “Power” in Flight Systems
The “power” aspect encapsulates the computational processing power, electrical energy, and robust signal transmission networks required for real-time flight control. High-performance microcontrollers continuously execute complex algorithms, processing vast streams of data from inertial measurement units (IMUs), GPS modules, magnetometers, and other environmental sensors. This data is then used to calculate precise adjustments to motor speeds and propeller thrust. The uninterrupted supply of clean, stable electrical power from the battery management system to all components, especially flight controllers and communication modules, is absolutely critical. Any fluctuation or inefficiency here directly impacts the system’s ability to “steer” with authority.
The “Steering” Mechanism
The “steering” in drone flight technology refers to the active control loops that manage the drone’s attitude (roll, pitch, yaw) and position. This includes the stabilization systems that correct for wind gusts, prop wash, and inherent aerodynamic instabilities. It also encompasses advanced navigation systems that guide the drone along predefined paths, maintain altitude, and execute complex maneuvers, often with centimeter-level precision. This “steering” is highly dynamic, involving rapid adjustments based on sensor feedback and predictive models. When this intricate mechanism experiences a “leak,” it implies a loss of control fidelity, leading to erratic behavior, reduced responsiveness, or even complete system failure.
Analogous “Leaks” in Navigation and Stabilization
A “power steering fluid leak” in a drone’s flight system manifests as a breakdown in the integrity or efficacy of its core navigation and stabilization components. These are not physical fluid leaks but rather a degradation or interruption of the essential ‘flow’ of information or energy.
Sensor Data Integrity
The cornerstone of any sophisticated flight control system is accurate and reliable sensor data. IMUs, GPS receivers, barometers, and vision systems provide the raw input for the drone’s understanding of its position, orientation, and movement. A “leak” in sensor data integrity can arise from various sources:
- Drift and Noise: Sensors can exhibit inherent drift over time or be susceptible to electromagnetic noise, leading to erroneous readings. This “leak” can accumulate, causing the flight controller to make incorrect adjustments based on flawed input.
- Calibration Errors: Improper or outdated sensor calibration can introduce systemic biases. If the IMU isn’t correctly aligned with the drone’s physical axes, or if magnetometer readings are distorted by onboard electronics, the control algorithms will receive a “leaky” understanding of the drone’s true state.
- Data Latency and Loss: Delays in sensor data transmission to the flight controller, or outright loss of packets, can create gaps in the drone’s perception. This intermittent “leak” in real-time information can cause jerky movements or lead to instability as the system struggles to compensate for missing context.
Control Signal Degradation
After processing sensor data and computing necessary adjustments, the flight controller sends commands to the motor electronic speed controllers (ESCs). These signals dictate motor speed and, consequently, propeller thrust, which directly controls the drone’s movement. A “leak” in control signal integrity can manifest as:
- Interference: Electromagnetic interference (EMI) from other onboard components, external sources, or even faulty wiring can corrupt these delicate signals, leading to motors receiving incorrect commands. This can cause motors to spin erratically, reducing the “steering” precision.
- Wiring Issues: Frayed wires, loose connections, or poorly shielded cables within the propulsion system can introduce resistance or signal loss, analogous to a small, continuous “fluid leak” that reduces the efficiency and reliability of command transmission.
- ESC Malfunctions: Individual ESCs can fail or become unstable due to overheating, component degradation, or firmware issues, leading to inconsistent power delivery to motors. This asymmetry directly impacts the drone’s ability to maintain a stable attitude and respond correctly to “steering” inputs.
Power Delivery Fluctuations

Stable and consistent electrical power is the lifeblood of all flight technology. The battery, power distribution board (PDB), and voltage regulators work in concert to supply appropriate voltage and current to every component. A “power steering fluid leak” here implies:
- Battery Degradation: An aging or damaged battery may not be able to deliver consistent current under load, leading to voltage sags during demanding maneuvers. This momentary “leak” in power can starve critical components, causing computational errors or temporary loss of control authority.
- PDB or Regulator Failure: A faulty PDB or voltage regulator can introduce ripple or unstable voltage, which can wreak havoc on sensitive electronics, particularly sensors and the flight controller. This “leak” of clean power directly undermines the precision of the entire “power steering” system.
- Overcurrent and Short Circuits: While often catastrophic, even minor overcurrent situations or intermittent short circuits can cause localized power “leaks” that disrupt specific subsystems or introduce noise across the power rails, destabilizing the entire control loop.
Algorithmic and Software Vulnerabilities
Beyond hardware and electrical integrity, the sophisticated software and algorithms that govern drone flight are equally susceptible to “leaks” that compromise the “power steering” function. These are often harder to diagnose as they reside in the logical rather than physical domain.
Calibration Errors and Environmental Modeling
Even with perfect hardware, incorrect calibration of flight parameters or an inaccurate environmental model can lead to algorithmic “leaks.” For instance, if the drone’s mass or aerodynamic coefficients are incorrectly entered, the control algorithms will consistently miscalculate the required thrust or control surface deflections. Similarly, if the GPS module’s error model is flawed or not dynamically updated for local conditions, the navigation system’s position estimates will suffer a continuous “leak” of accuracy, manifesting as drift or inability to hold position.
Firmware Glitches and Software Drift
Firmware bugs, computational overflows, or subtle software drift can introduce insidious “leaks” into the control system. These might not cause outright crashes but can lead to a gradual degradation in flight performance. For example, a minor error in the PID (Proportional-Integral-Derivative) controller’s integral term calculation might lead to persistent oscillations, or an infrequent memory leak could gradually consume resources, slowing down critical processes and introducing control latency. These are analogous to a slow, internal “fluid leak” that subtly impairs performance over time.
Environmental and Hardware Stressors
External factors and physical wear can also contribute significantly to “power steering fluid leaks” in drone flight systems. These stressors can exacerbate existing vulnerabilities or create new points of failure.
Vibration and Physical Wear on Components
Drones, especially racing or heavy-lift models, are subjected to significant vibrations during flight. Prolonged exposure can loosen connections, cause component fatigue, or even dislodge sensitive micro-electromechanical systems (MEMS) within IMUs. This physical “leak” in structural integrity directly translates to noisy sensor data and unreliable control signal transmission. Propellers that are unbalanced or damaged can also induce destructive vibrations, acting as a constant, external source of “leakage” into the control system.
Electromagnetic Interference (EMI)
Operating environments rich in electromagnetic interference (EMI) can severely impact a drone’s “power steering.” High-voltage power lines, radio towers, or even other electronic devices can inject noise into communication links, GPS signals, and internal sensor buses. This external “leakage” directly corrupts the data that the flight controller relies on for stable and precise operation, leading to unpredictable behavior, GPS signal loss, or even temporary loss of control. Shielding, proper grounding, and careful component placement are crucial to mitigate this form of “leak.”
Temperature Extremes and Moisture Ingress
Modern electronics are sensitive to environmental conditions. Extreme temperatures, particularly cold, can affect battery performance, reducing its ability to provide stable power. High temperatures can cause components to overheat, leading to performance degradation or outright failure. Moisture ingress, whether from rain, fog, or condensation, can cause short circuits, corrode sensitive contacts, and disrupt signal paths, creating both intermittent and permanent “leaks” in the electrical and data infrastructure. The integrity of the enclosure and conformal coating on circuit boards are critical defenses against these insidious environmental “leaks.”
In conclusion, while the term “power steering fluid leak” is a conceptual bridge, it powerfully illustrates the multifaceted challenges in maintaining the flawless operation of advanced drone flight technology. From the subtle degradation of sensor data and the nuanced corruption of control signals to the robust delivery of power and the resilience of software, any compromise in these critical flows can manifest as a “leak” that undermines the precision and reliability of a UAV’s “power steering” capabilities. Proactive diagnostics, rigorous maintenance, and continuous innovation in system design are essential to plug these metaphorical leaks and ensure the continued advancement and safe operation of unmanned aerial systems.