
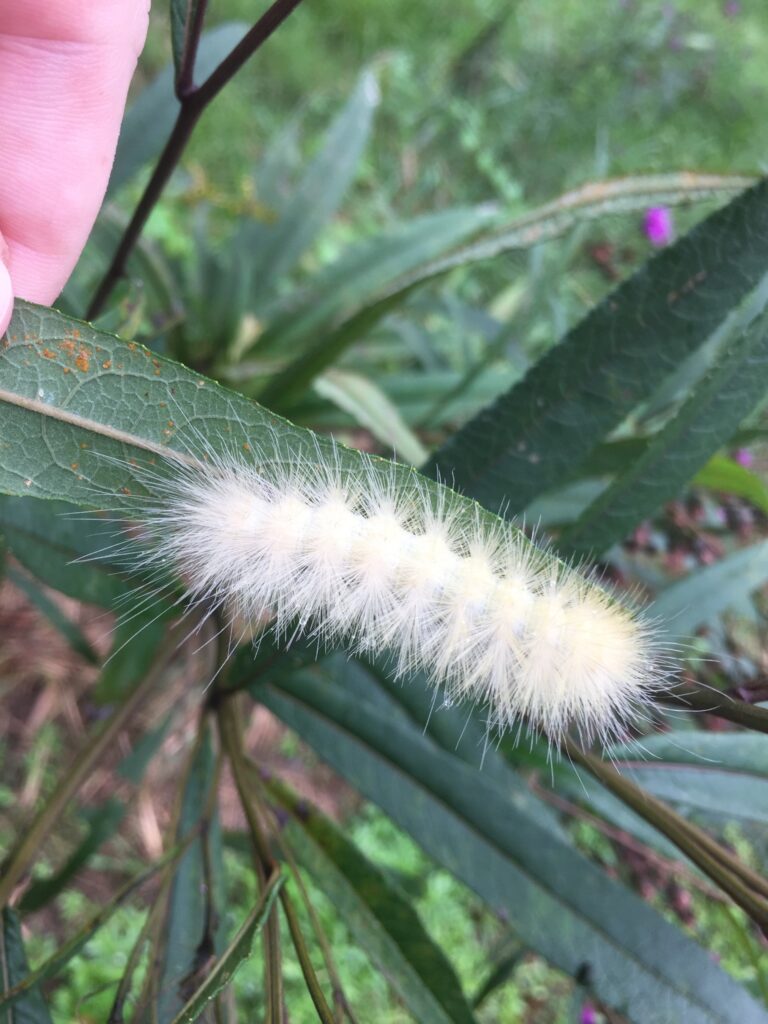
In the dynamic landscape of technological innovation, the seemingly innocuous question “What are white caterpillars?” prompts a delve far beyond entomology, into the cutting edge of biomimicry, autonomous micro-robotics, and advanced environmental sensing. Within the domain of Tech & Innovation, this query transforms into a conceptual framework, inspiring the development of systems that emulate the resilience, adaptability, and distributed intelligence observed in natural organisms. These “white caterpillars,” therefore, represent not just a biological species, but a potent metaphor for a new generation of diminutive, adaptable, and often camouflaged robotic or sensor platforms designed to navigate, perceive, and interact with complex environments. Engineers and researchers are increasingly looking to nature for solutions, and the characteristics of caterpillars—their segmented bodies, intricate locomotion, and often collective behaviors—offer profound insights into designing future-forward tech.
The Dawn of Bio-Inspired Micro-Robotics
The pursuit of increasingly smaller, more efficient, and more autonomous robotic systems often finds its muse in the natural world. “White caterpillars,” as a conceptual model, embody key attributes that developers strive for in micro-robotics: robust locomotion over varied terrain, inherent flexibility, and a capacity for complex behavioral patterns despite their small scale. This area of innovation focuses on translating biological principles into engineering solutions, leading to advancements that push the boundaries of what micro-drones and ground-based robotic platforms can achieve.
Mimicking Nature’s Design Principles
The segmented body plan of a caterpillar, with its remarkable ability to undulate and traverse diverse surfaces, presents a compelling blueprint for robotic locomotion. Engineers are developing “soft robots” that forgo rigid components in favor of flexible, deformable materials, allowing them to squeeze through tight spaces, absorb impacts, and adapt their shape to the immediate environment—much like a caterpillar navigating foliage. The “white” aspect can further inspire design choices, perhaps implying robots made from novel, lightweight, or even chameleon-like materials that can blend into specific surroundings for covert operations or sensitive data collection. The intricate muscle movements that propel a caterpillar forward, involving sequential contractions and relaxations, are being studied to create highly efficient, low-power actuators for future micro-bots, minimizing energy consumption and maximizing operational duration in the field.
Soft Robotics and Deformable Systems
Traditional robotics, built upon rigid components, often struggle with fragility and limited adaptability in unstructured environments. Soft robotics, conversely, embraces compliant materials and designs, enabling robots to exhibit unprecedented dexterity, safety in human interaction, and resilience to damage. Micro-drones and inspection robots inspired by the “white caterpillar” concept could feature bodies made from silicone, elastomers, or smart polymers that allow for flexible articulation. These systems might be designed to morph their shape for aerial flight, then reconfigure for ground traversal or even aquatic submersion, mimicking the versatile life cycle of some insects. Such deformable systems are critical for applications requiring interaction with delicate objects, navigation through irregular conduits, or deployment in hazardous zones where robust impact resistance is paramount.
Autonomous Navigation and Swarm Intelligence
The collective behaviors observed in many insect species, including certain caterpillars, offer a paradigm for developing sophisticated swarm intelligence in autonomous systems. The vision of numerous, small, autonomous “white caterpillars”—whether flying or crawling—working in unison to achieve complex objectives is a cornerstone of future drone and robotic innovation. These systems leverage advanced algorithms to enable coordination without centralized control, leading to scalable, resilient, and highly efficient operational capabilities.
Navigating Complex Environments
Micro-drones and ground robots face significant challenges in navigating environments that are unstructured, dynamic, or GPS-denied. Inspired by the seemingly effortless way caterpillars traverse intricate natural landscapes, engineers are developing advanced localization, mapping, and path-planning algorithms. Visual-inertial odometry (VIO), simultaneous localization and mapping (SLAM), and sophisticated sensor fusion techniques allow these miniature platforms to build internal representations of their surroundings and plan optimal routes in real-time. For “white caterpillar” robots, this might include specialized vision systems capable of discerning subtle environmental cues, or haptic sensors that provide tactile feedback for pathfinding over textured surfaces, much like a caterpillar’s proprioception.
Collaborative Micro-Robots
Swarm intelligence, where individual simple agents collectively perform complex tasks, is a revolutionary concept for autonomous systems. Imagine a swarm of “white caterpillar” micro-drones, each equipped with a specialized sensor, fanning out over a vast agricultural field to detect early signs of crop disease or pest infestation. Or a fleet of crawling “caterpillar” robots inspecting the internal structures of large infrastructure projects. These systems rely on decentralized communication protocols and simple behavioral rules that, when aggregated across many units, give rise to emergent intelligent behaviors. The advantages are manifold: redundancy (if one unit fails, others can compensate), scalability (easily deployable in varying numbers), and efficiency in covering large or complex areas.
Advanced Sensing and Data Acquisition
The ability of future drone and robotic systems to effectively perceive their environment is paramount, especially when inspired by the natural world’s subtle intricacies. For “white caterpillars,” this means developing miniaturized, highly sensitive sensor payloads capable of detecting phenomena that might be invisible or inaccessible to larger platforms. This focus on advanced sensing underpins the utility of these conceptual systems in diverse applications, from environmental monitoring to covert surveillance.

Miniaturized Sensor Payloads
The challenge of placing powerful sensing capabilities onto micro-platforms is immense. Yet, advancements in MEMS (Micro-Electro-Mechanical Systems) technology and nanoscale engineering are making this a reality. “White caterpillar” inspired robots could carry a suite of ultra-compact sensors: high-resolution optical cameras for detailed imaging, thermal cameras for heat signatures, multispectral sensors for environmental analysis (e.g., detecting plant stress or chemical spills), and even acoustic sensors for subtle sound detection. The “white” aspect could refer to their ability to capture data across the visible spectrum, or even beyond, into UV or infrared, providing a comprehensive “white light” view of the environment. These miniaturized payloads, integrated seamlessly into the robot’s design, enable precision data collection at scales previously unattainable.
Environmental Monitoring and Inspection
One of the most promising applications for “white caterpillar” drone and robot concepts lies in environmental monitoring and complex infrastructure inspection. Swarms of these micro-systems could be deployed to areas inaccessible to humans or larger drones—such as dense forest canopies, internal piping systems, or collapsed structures. They could monitor air quality, detect changes in biodiversity, identify structural weaknesses in bridges or pipelines, or even assist in search and rescue operations by navigating confined spaces. Their discreet nature, inspired by the “white caterpillar’s” often inconspicuous presence in nature, allows for minimal disturbance while maximizing data collection efficiency and reach.
Powering the Miniature Ecosystem
The operational longevity and independence of micro-robotic systems are fundamentally tied to innovations in power generation and management. For “white caterpillar” robots, overcoming the limitations of battery life is crucial for sustained missions and truly autonomous operation. This area of Tech & Innovation explores novel energy solutions that enable these miniature marvels to operate for extended periods, far from human intervention.
Energy Scavenging and Endurance
To achieve true autonomy, future micro-robots need to go beyond conventional battery power. Biomimicry extends to energy harvesting, where systems are designed to scavenge energy from their environment. This could include miniature solar cells integrated into the robot’s “skin,” capturing ambient light; piezoelectric materials that convert mechanical vibrations (from movement or wind) into electricity; or even thermal gradients to generate power. For “white caterpillar” robots, the design could incorporate materials that are highly efficient at absorbing solar energy while maintaining their visual characteristics, or kinetic energy harvesting systems that recharge batteries with every undulation or movement. Such advancements promise to dramatically extend the endurance of these platforms in the field.
Wireless Charging and Deployment Strategies
Beyond on-board energy scavenging, innovations in wireless power transfer are vital for replenishing energy in situ. Imagine a network of wireless charging nodes, perhaps integrated into environmental sensors or existing infrastructure, allowing “white caterpillar” robots to recharge simply by passing nearby. This enables long-term deployments where robots can return to designated charging stations as needed, forming a truly self-sustaining network. Furthermore, new deployment strategies are being explored, from drone-motherships that release and retrieve swarms of micro-robots, to sophisticated launch mechanisms that propel these tiny systems to their mission areas, ensuring their effective and efficient operation across vast and varied landscapes.
Future Frontiers: Impact and Applications
The conceptual framework of “white caterpillars” in Tech & Innovation unlocks a myriad of future applications, promising transformative impacts across various sectors. These miniature, adaptable, and intelligent systems represent a paradigm shift in how we approach monitoring, exploration, and intervention, offering capabilities that are currently unfeasible with existing technology.
Precision Agriculture and Ecosystem Management
In agriculture, swarms of “white caterpillar” micro-drones could revolutionize crop monitoring by conducting hyper-localized inspections for pests, diseases, and nutrient deficiencies with unprecedented detail. Their small size allows them to navigate dense foliage without causing damage, collecting precise data on individual plants. Similarly, for ecosystem management, these robots could monitor subtle changes in flora and fauna, track pollution spread, or assess environmental health in sensitive biomes without disturbing the natural habitat, leading to more targeted and sustainable interventions.

Infrastructure Inspection and Exploration
The ability of “white caterpillar” inspired robots to navigate confined, complex, and hazardous environments makes them ideal for infrastructure inspection. They could crawl through the internal structures of aircraft wings, inspect pipelines for micro-fractures, or survey the integrity of reactor vessels. In exploration, particularly in urban search and rescue, their capacity to squeeze into tight spaces and provide live video feeds could be life-saving. Furthermore, for planetary exploration, miniaturized, robust, and bio-inspired robots could explore geological features and subterranean environments with an agility that larger rovers cannot match, expanding our understanding of distant worlds. The “white caterpillar,” as a symbol of adaptability and resilience at a micro-scale, is poised to drive the next wave of technological breakthroughs.