
In the rapidly evolving landscape of unmanned systems, the term “traction tires” might initially conjure images of terrestrial vehicles rather than aerial drones. However, as the capabilities of drone technology expand to encompass diverse operational environments, particularly for autonomous ground vehicles (AGVs) often deployed in conjunction with or as extensions of aerial drone missions, the concept of specialized traction becomes profoundly relevant. Within the niche of Tech & Innovation, particularly concerning mapping, remote sensing, and autonomous navigation, “traction tires” refer to purpose-engineered wheel systems designed to maximize grip and stability for drone-rovers and hybrid unmanned systems operating on challenging, irregular, or slippery terrains. These components are critical enablers for robust autonomous movement, ensuring mission success where conventional mobility solutions would fail.

The Fundamental Role of Traction in Autonomous Ground Vehicles
For drone-rovers and other unmanned ground vehicles (UGVs) engaged in advanced applications like environmental monitoring, infrastructure inspection, or disaster response, reliable mobility across varied landscapes is paramount. Unlike aerial drones that navigate the skies, these ground-based counterparts depend entirely on their interface with the surface below. Traction tires are not merely wheels; they are sophisticated systems engineered to maintain optimal contact and propulsion, preventing slippage and ensuring directional control. This specialized design directly impacts the precision of data collection for remote sensing, the accuracy of autonomous mapping, and the overall reliability of complex missions in dynamic environments. Without superior traction, an advanced UGV equipped with cutting-edge sensors could be rendered immobile by mud, snow, loose gravel, or steep inclines, undermining its technological potential.
Advanced Tread Patterns for Diverse Terrains
The distinguishing characteristic of traction tires for drone-rovers lies in their meticulously designed tread patterns. Unlike the smooth or subtly patterned wheels of indoor robots, outdoor autonomous vehicles require aggressive, open, and self-cleaning treads. These patterns are not uniform; they are optimized for specific challenges:
- Mud and Loose Soil: Tires designed for muddy conditions feature deep, widely spaced lugs that can dig into soft terrain, providing a paddle-like effect for propulsion. The wide spacing helps to shed mud efficiently, preventing the tread from becoming clogged and losing its grip. This is vital for environmental mapping in wetlands or agricultural settings where soil conditions vary.
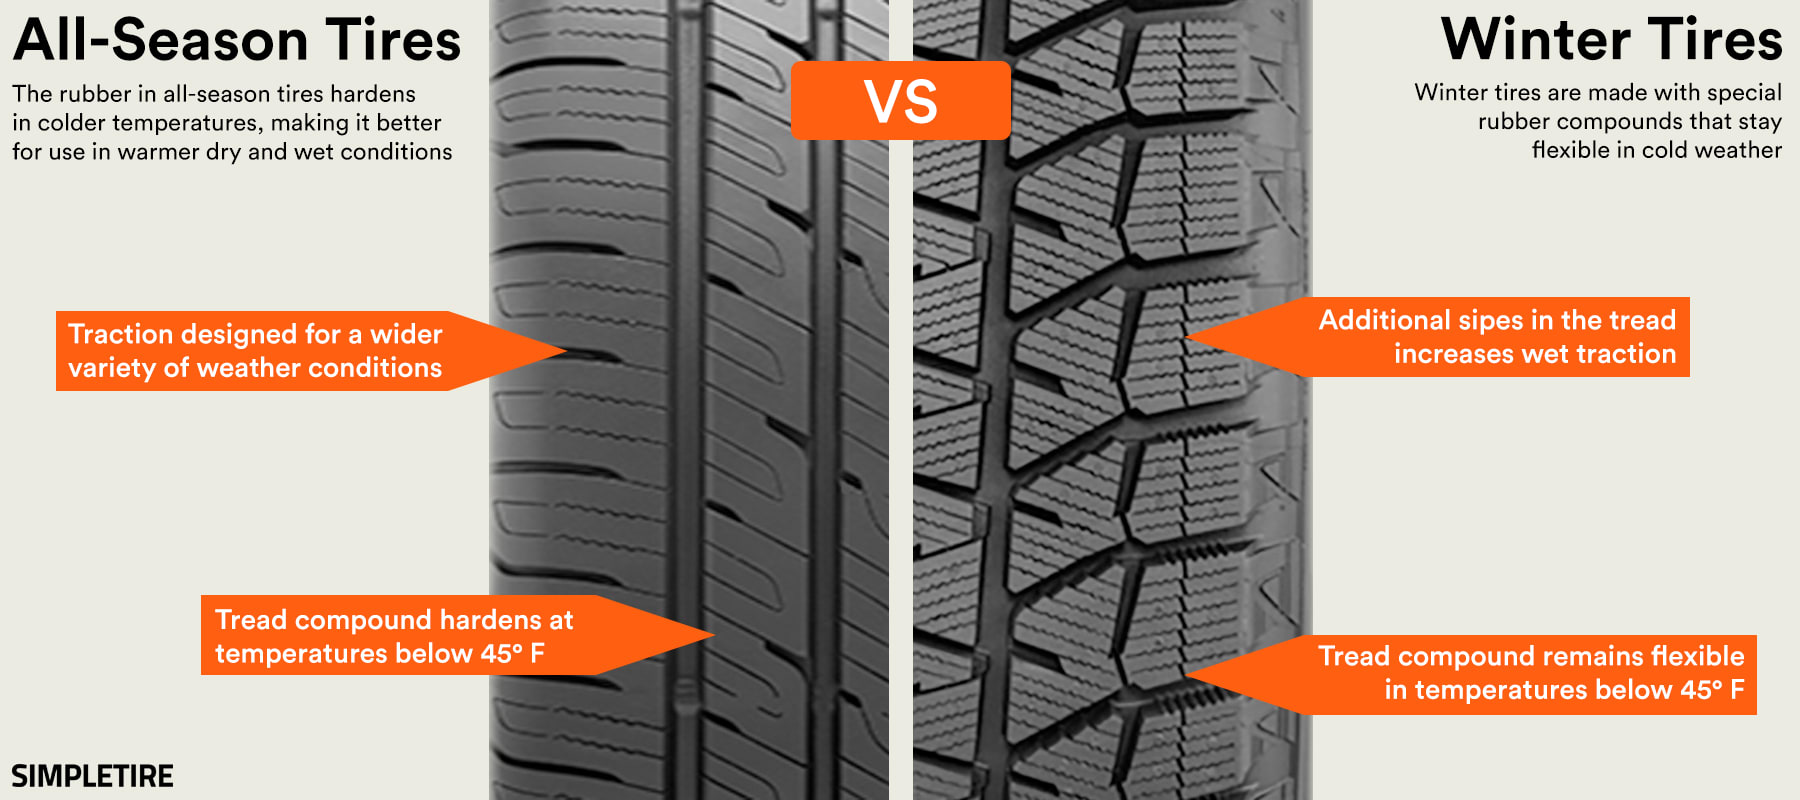
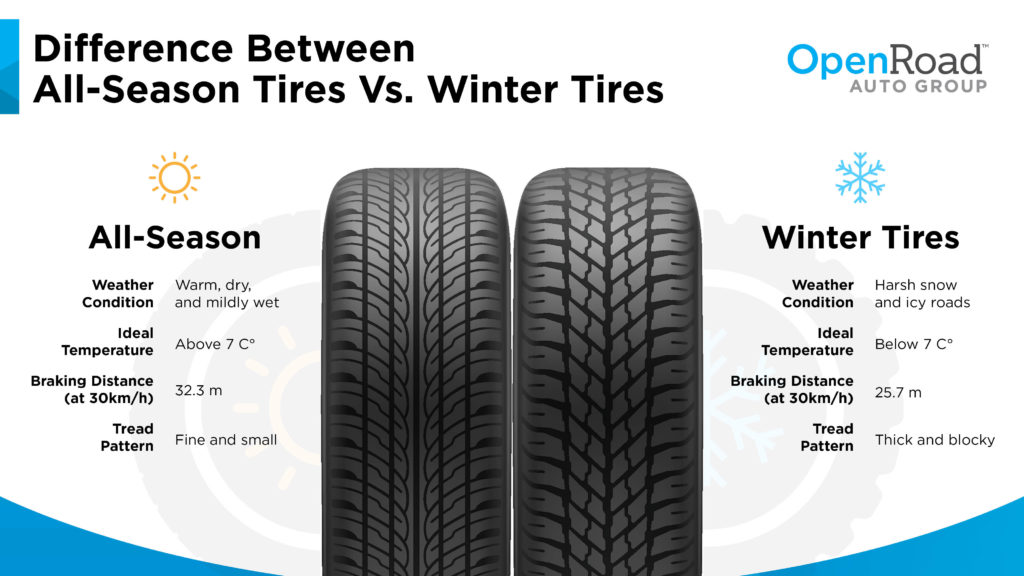
- Snow and Ice: For operations in cold climates, traction tires incorporate numerous sipes (small, thin slits) within the tread blocks, along with specialized block shapes. These sipes create biting edges that grip onto icy surfaces, while the overall tread pattern is designed to compress and release snow, maintaining contact rather than floating on top. This is crucial for arctic research or infrastructure inspection in winter conditions.
- Rocky and Uneven Surfaces: Traction tires for rocky environments often feature robust, chunky tread blocks with reinforced sidewalls to resist punctures and abrasions. The pattern emphasizes maximum surface contact area and flexibility to conform to irregular shapes, allowing the drone-rover to “crawl” over obstacles. This design supports geological surveying or urban search and rescue in debris-strewn areas.
- Multi-Terrain Capabilities: Some advanced designs aim for versatility, incorporating elements from various specialized patterns to offer balanced performance across a range of challenging conditions. These “all-terrain” traction systems are often preferred for missions where the ground conditions are unpredictable or highly variable, such as remote sensing across expansive, undeveloped regions.
Specialized Material Compounds for Extreme Conditions
Beyond tread patterns, the chemical composition and physical properties of the tire’s rubber compound are equally critical for performance. Traction tires for drone-rovers utilize specialized compounds engineered to endure and perform optimally under extreme conditions:
- Temperature Adaptability: Unlike standard rubber that can stiffen in cold or become excessively soft in heat, these compounds maintain elasticity and grip across a broad temperature range. This ensures consistent performance from scorching deserts to freezing tundras, essential for global autonomous deployments.
- Durability and Puncture Resistance: Missions in remote or hazardous environments demand tires that can withstand sharp rocks, debris, and abrasive surfaces without compromising structural integrity. High-strength polymers and sometimes even composite reinforcing materials are integrated into the rubber matrix to enhance resistance to cuts, tears, and punctures, thereby minimizing downtime and repair costs.
- Adhesion Properties: The compound’s formulation directly influences its ability to adhere to wet, icy, or slick surfaces. Advanced polymers with high friction coefficients are used to create a “sticky” effect, enhancing grip without excessive wear. This is particularly important for navigating steep, slippery inclines or crossing fluid-covered obstacles.
- Weight Optimization: Given that many drone-rovers are designed for long endurance or air-deployability by larger UAVs, the weight of their components is a significant factor. Tire compounds are developed to offer maximum performance with minimal mass, contributing to overall energy efficiency and payload capacity.
Integrating Traction Capabilities into Drone-Rover Design
The successful application of traction tires extends beyond their individual performance; it involves seamless integration into the overall design of the autonomous ground vehicle. This includes considerations for suspension systems, drive mechanisms, and sensor integration, all of which work in concert to leverage the tires’ grip for effective navigation and data acquisition. For innovations in autonomous mapping and remote sensing, the interaction between tire performance and system-level design is crucial for achieving high-fidelity results in previously inaccessible areas.
Enhancing Stability and Navigation for Remote Sensing
For remote sensing missions, precision is paramount. Drone-rovers equipped with advanced traction tires can maintain stable platforms for sensitive sensors (e.g., LiDAR, hyperspectral cameras, ground-penetrating radar) even when traversing uneven or slippery terrain. The enhanced grip prevents sudden slips or jolts that could skew sensor readings or corrupt data. Furthermore, consistent traction improves the accuracy of odometry data—the estimation of position based on wheel rotations. This is vital for dead reckoning, a navigation technique used when GPS signals are weak or unavailable, thereby improving the overall robustness of autonomous navigation algorithms. By reducing wheel slip, the estimated travel distance closely matches the actual distance, leading to more accurate mapping outputs and reliable path planning. This directly supports applications requiring centimeter-level accuracy for environmental monitoring or detailed infrastructure inspection.
Overcoming Obstacles in Autonomous Mapping Operations
Autonomous mapping requires not only precision but also the ability to access and comprehensively scan target areas, often necessitating traversal over significant obstacles or challenging gradients. Traction tires enable drone-rovers to:
- Ascend and Descend Steep Slopes: The superior grip allows UGVs to maintain control on steep inclines and declines, critical for mapping mountainous regions, mine sites, or sloped agricultural fields without losing stability or momentum.
- Navigate Irregular Surfaces: By conforming to the contours of rocks, roots, and debris, specialized tires allow the rover to articulate effectively over highly uneven terrain, ensuring that the sensor payload remains relatively level and functional.
- Ford Shallow Water or Mud Pits: With deep, self-cleaning treads and water-resistant compounds, some traction tires facilitate traversal through shallow water bodies or thick mud, expanding the operational envelope for wetland mapping or post-disaster assessment.
- Maneuver in Confined Spaces: While not directly a function of traction, the ability to maintain grip allows for precise, low-speed maneuvers in tight or hazardous spaces, where any slip could result in mission failure or damage to the robot. This is particularly valuable for indoor mapping or navigating complex industrial facilities.
Future Innovations in Drone-Rover Traction Technology
The future of traction tires for drone-rovers is poised for significant innovation, driven by advancements in materials science, artificial intelligence, and biomechanics. As autonomous systems become more intelligent and versatile, their ground mobility solutions will also evolve to offer unprecedented adaptability and performance.
- Adaptive Tread Systems: Imagine tires that can actively change their tread pattern or stiffness based on real-time feedback from terrain sensors. This could involve deformable tire structures, electrorheological fluids, or pneumatic systems that allow the UGV to instantly optimize traction for mud, rock, or ice without human intervention. This capability would revolutionize multi-environment autonomous operations.
- Biomimetic Designs: Inspiration from nature, particularly how animals navigate diverse terrains, will lead to biomimetic tire designs. This could include treads that mimic the gripping patterns of gecko feet for climbing vertical surfaces, or the digging mechanisms of moles for subterranean exploration.
- Sensor-Integrated Tires: Future traction tires might embed sensors directly within their structure to provide real-time data on ground conditions, tire wear, and slip ratios. This data could feed into the UGV’s AI navigation system, allowing for predictive traction adjustments and more robust path planning, enhancing both efficiency and safety.
- Sustainable and Lightweight Materials: The drive towards more sustainable and energy-efficient autonomous systems will push the development of new, lightweight, and eco-friendly tire materials. This will reduce the overall energy consumption of drone-rovers and minimize their environmental footprint, while still maintaining superior traction and durability.
The concept of traction tires, when contextualized within the realm of autonomous ground vehicles complementing or extending aerial drone operations, represents a critical area of innovation. These specialized wheel systems are not just accessories but fundamental components that unlock advanced capabilities in mapping, remote sensing, and autonomous navigation across the globe’s most challenging environments.