
In the rapidly evolving landscape of drone technology and innovation, the ability to execute multiple tasks simultaneously is not just a convenience; it’s a fundamental requirement for advanced functionalities like autonomous flight, real-time data processing, and sophisticated AI algorithms. At the heart of this concurrent processing lies the concept of “threads in programming.” Understanding what threads are and how they operate is crucial for appreciating the underlying engineering that powers the next generation of intelligent aerial systems.
The Foundations of Concurrent Execution
Threads represent a lightweight unit of execution within a program, allowing a single application to perform several operations concurrently. Unlike separate programs, which run in their own isolated memory spaces, threads within the same process share resources, enabling more efficient communication and data sharing. This inherent capability for parallelism is a cornerstone of modern software development, particularly for applications demanding high performance and responsiveness, such as those found in complex drone systems.
Processes vs. Threads
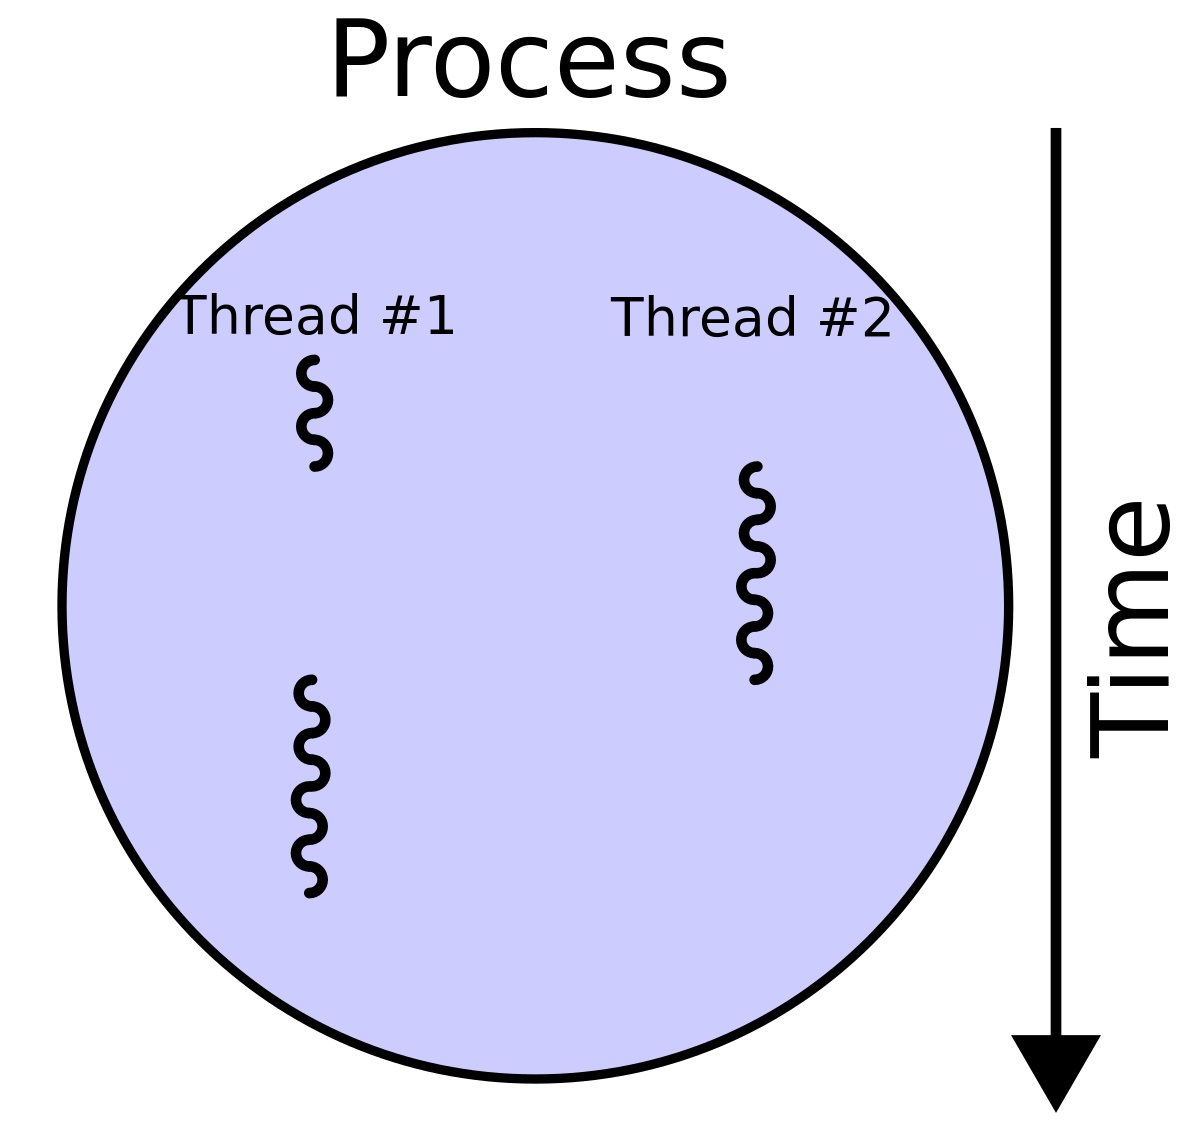
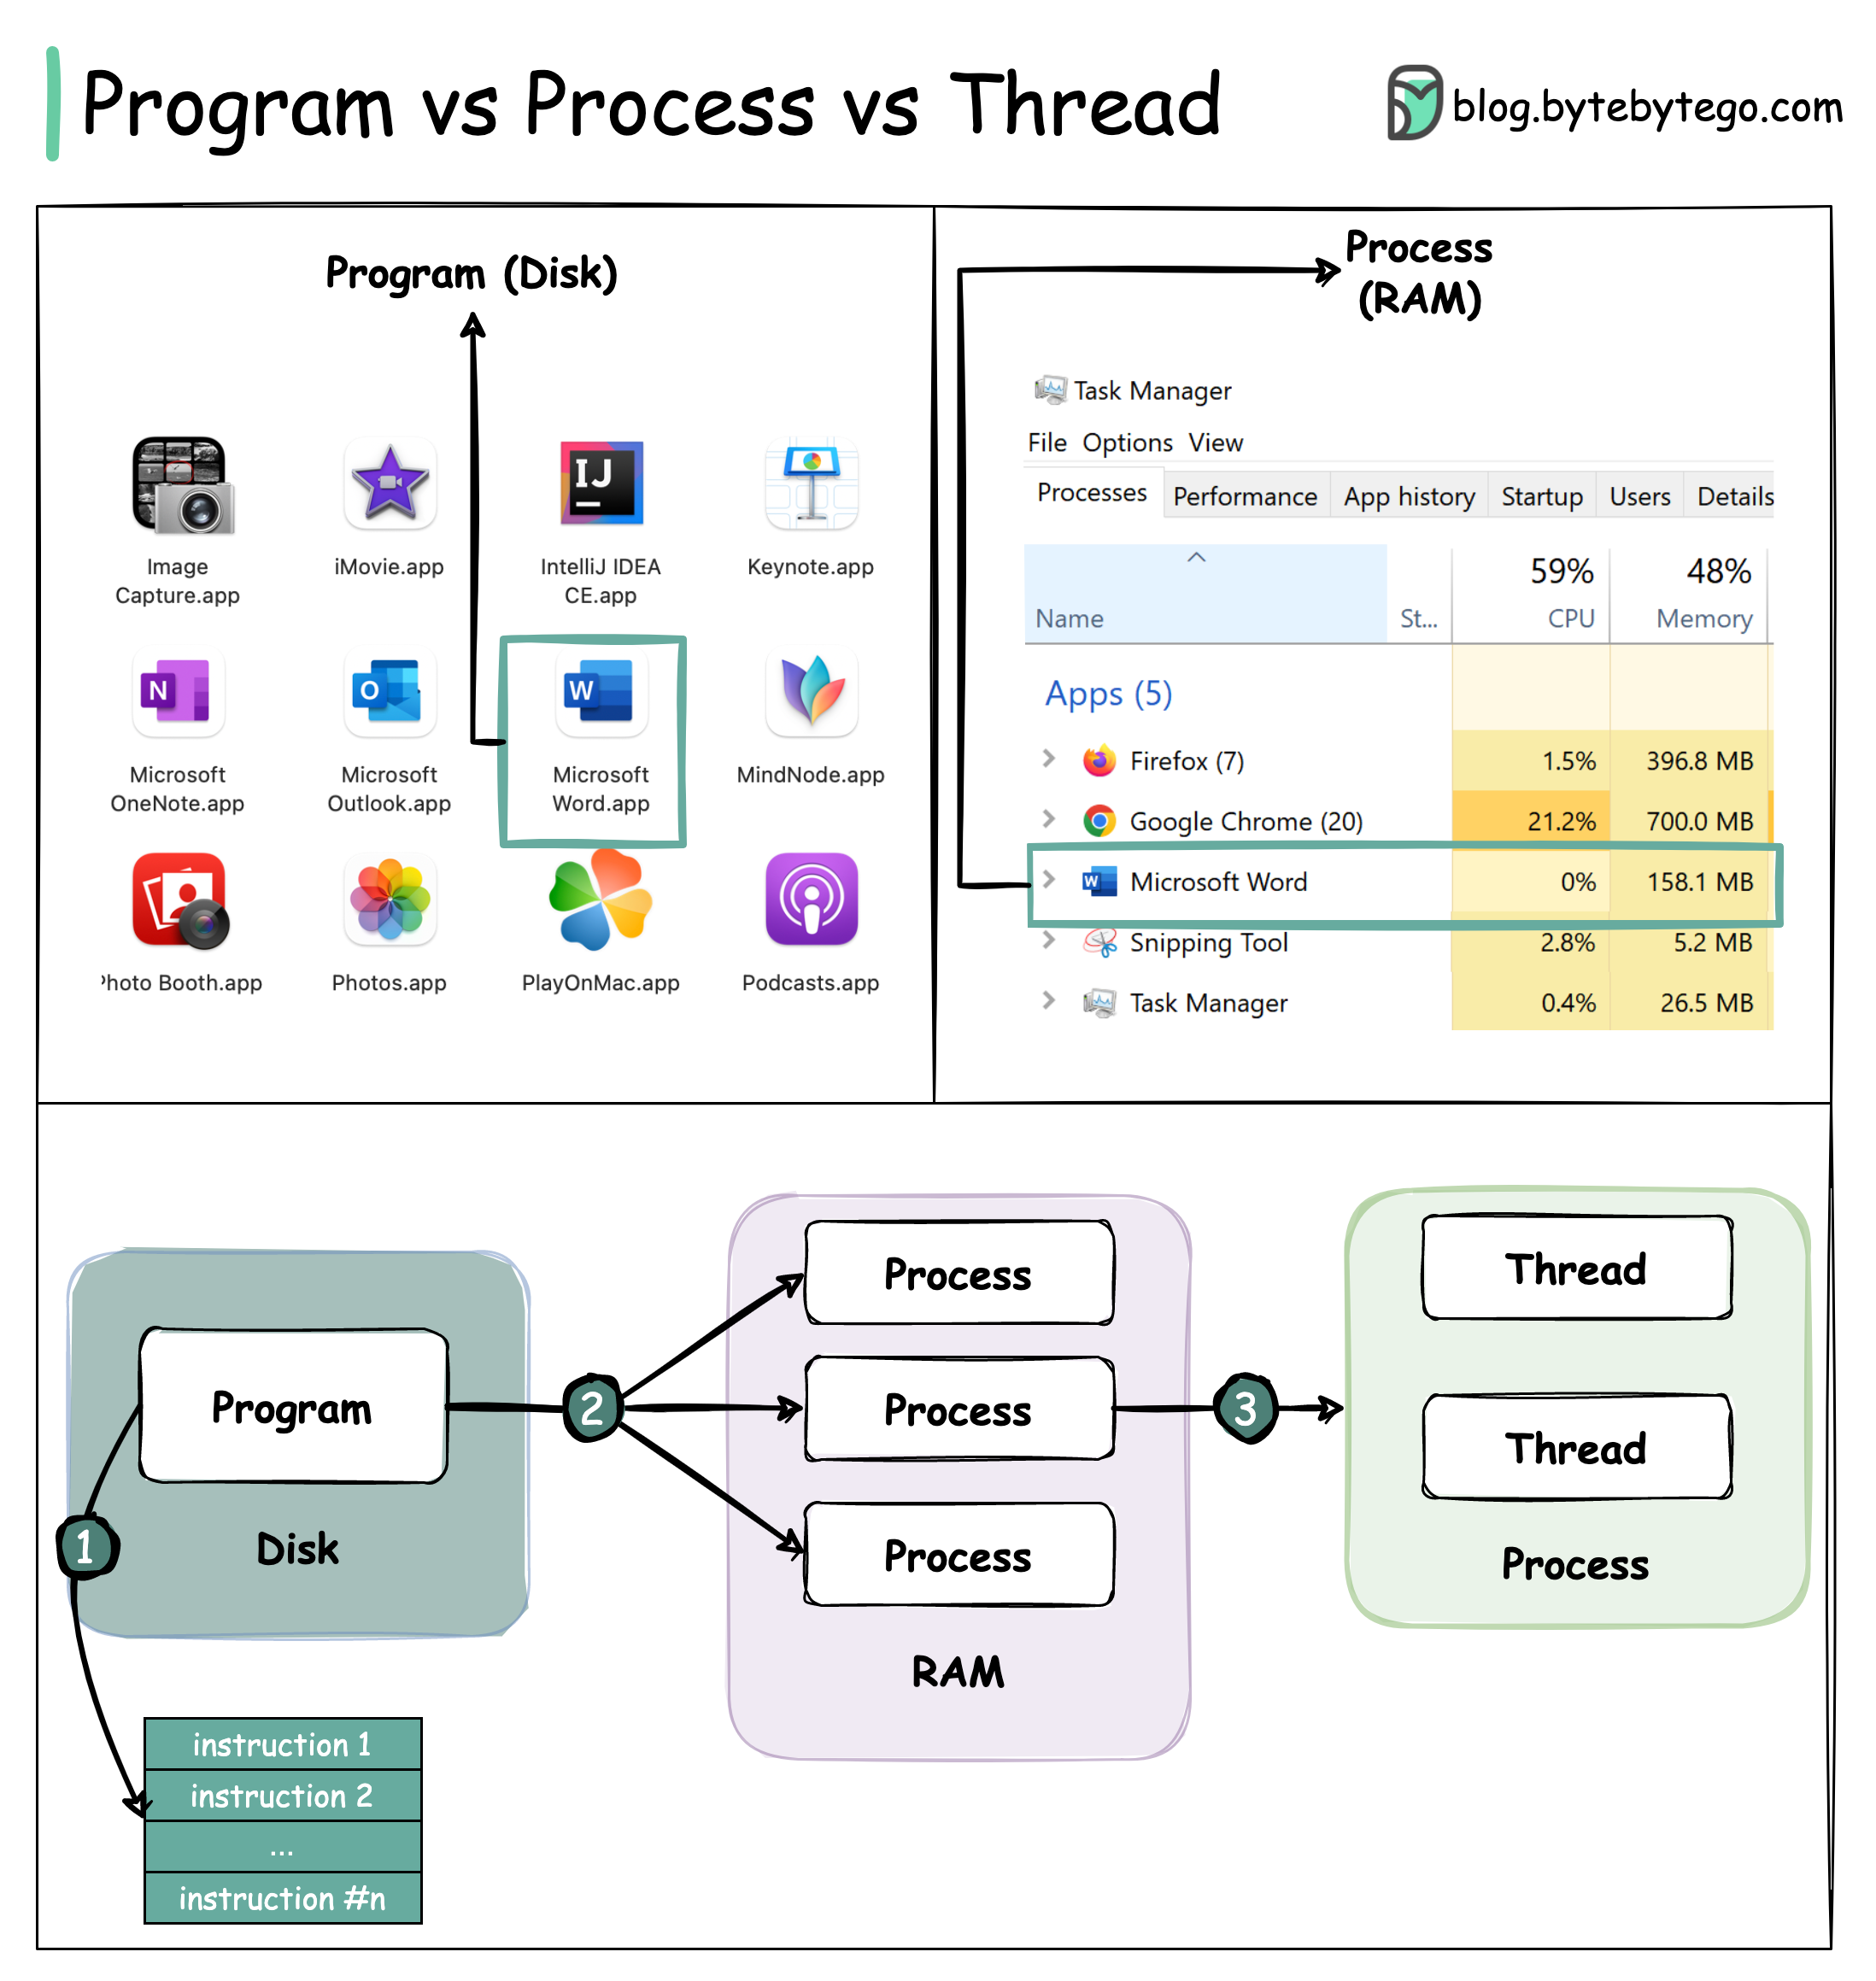
To fully grasp the significance of threads, it’s helpful to distinguish them from processes. A process is an independent execution environment that includes its own private memory space, code, and data. When you launch a program, you’re typically creating a new process. While processes are robust and provide strong isolation, inter-process communication can be resource-intensive.
Threads, on the other hand, exist within a process. A single process can contain multiple threads, each acting as an independent sequence of instructions. Crucially, all threads within a process share the same memory space, global variables, and open files. This shared memory model facilitates faster data exchange and communication between tasks, making threads ideal for dividing a single complex problem into smaller, concurrently executable parts. For drone technology, where various systems like navigation, camera feeds, and flight control must operate in concert and share data instantly, the efficiency of threads is indispensable.
Why Concurrency Matters for Innovation
The drive for innovation in drone technology—from AI follow modes and sophisticated mapping to autonomous obstacle avoidance and real-time remote sensing—is inextricably linked to the ability to handle multiple operations concurrently. A drone’s flight controller, for instance, must simultaneously monitor sensor inputs (IMU, GPS, lidar), execute control algorithms, communicate with the ground station, and potentially process camera data for object recognition. If these tasks were executed sequentially, the system would suffer from critical delays, rendering advanced features impractical or unsafe. Concurrency, facilitated by threads, allows these diverse operations to progress in parallel, ensuring timely responses, smooth operation, and the robust performance required for complex aerial missions.
Threads in Action: Powering Drone Intelligence
The practical application of threads is evident in almost every aspect of an intelligent drone system. They enable the seamless integration of various hardware components and software modules, transforming raw data into actionable intelligence.
Real-time Sensor Data Processing
Modern drones are equipped with an array of sensors: accelerometers, gyroscopes, magnetometers, barometers, GPS receivers, lidar, radar, and vision sensors. Each of these generates a continuous stream of data that needs to be acquired, filtered, and processed in real-time. A dedicated thread might be responsible for reading data from the IMU (Inertial Measurement Unit), while another processes GPS coordinates, and yet another handles lidar point cloud generation. These threads operate concurrently, ensuring that the drone’s flight controller always has up-to-date information for stabilization, navigation, and environmental awareness. Without this parallel processing, the drone’s ability to react to sudden gusts of wind, maintain a precise position, or avoid obstacles would be severely compromised.
Enabling Autonomous Flight and Navigation
Autonomous flight relies on intricate algorithms that process sensor data, generate flight paths, and execute control commands. A key innovation in drone technology is the shift from manual piloting to intelligent autonomy. Threads are fundamental here. One thread might be dedicated to executing the primary flight control loop, managing motor speeds and attitude. Another thread could be running a path planning algorithm, dynamically calculating optimal routes based on mission parameters and detected obstacles. A third might be responsible for fusing data from multiple sensors to maintain an accurate estimate of the drone’s position and orientation. The ability of these threads to operate in parallel, feeding information to each other, allows for complex decision-making and seamless autonomous navigation, from pre-programmed routes to dynamic obstacle avoidance in unpredictable environments.
AI Follow Mode and Object Recognition
AI follow mode, a popular feature for aerial filmmaking and surveillance, exemplifies the power of threading. This mode requires real-time object detection and tracking from the drone’s camera feed, followed by continuous adjustment of the drone’s flight path to maintain a lock on the subject. One thread can be solely dedicated to running a deep learning model for object recognition on the video stream. Simultaneously, another thread uses the output of this AI model to compute the necessary adjustments to the drone’s position and velocity, while a third thread manages the gimbal to keep the subject centered in the frame. These demanding computational tasks, when distributed across multiple threads, allow the drone to perform sophisticated AI-driven maneuvers with minimal latency, transforming raw pixel data into intelligent, dynamic flight control.
Optimizing Performance for Advanced Aerial Systems

Beyond enabling core functionalities, threading is crucial for optimizing the overall performance and responsiveness of drone software, particularly as systems become more complex and data-intensive.
Parallelizing Complex Computations
Many advanced drone applications involve computationally intensive tasks. For example, generating detailed 3D maps from aerial photogrammetry involves processing thousands of images, identifying common features, and reconstructing geometry. Remote sensing applications might require complex spectral analysis of captured data. These tasks are often “embarrassingly parallel,” meaning they can be broken down into many independent sub-tasks that can be processed simultaneously. By distributing these computations across multiple threads, developers can leverage the full power of multi-core processors, significantly reducing processing times from hours to minutes, thereby accelerating data delivery for critical applications in agriculture, construction, and environmental monitoring.
Responsive User Interfaces and Ground Control Stations
The ground control station (GCS) is the human-machine interface for drone operations. It displays real-time telemetry, video feeds, mission plans, and allows for command input. A responsive GCS is vital for safe and effective drone operation. Threads ensure that the user interface remains fluid and interactive, even when the system is performing demanding background tasks like receiving large data packets, processing video streams, or executing complex mission planning algorithms. A dedicated UI thread handles user interactions and screen updates, while other background threads manage communication protocols, data logging, and complex computations, preventing the interface from freezing or becoming unresponsive. This separation of concerns is critical for maintaining situational awareness and control during critical flight operations.
Challenges and Best Practices in Thread Management
While threads offer immense benefits, their management introduces complexities. Incorrect handling can lead to subtle bugs, performance issues, or even system crashes, which are unacceptable in critical drone applications.
Synchronization and Data Integrity
When multiple threads share common data, there’s a risk of data corruption if they attempt to modify the same piece of data simultaneously without proper coordination. This is where synchronization mechanisms come into play. Tools like mutexes, semaphores, and locks are used to ensure that only one thread can access a critical section of shared code or data at any given time. In drone systems, guaranteeing data integrity is paramount for mission-critical information such as current position, battery level, or flight mode. Careful implementation of synchronization prevents inconsistent states that could lead to erratic behavior or safety failures.
Avoiding Deadlocks and Race Conditions
Two common pitfalls in multithreaded programming are deadlocks and race conditions. A race condition occurs when the output of concurrent execution depends on the sequence or timing of other uncontrollable events, leading to unpredictable results. A deadlock happens when two or more threads are blocked indefinitely, each waiting for the other to release a resource. For drone developers, rigorously analyzing potential race conditions in sensor data processing or control command execution is vital. Designing systems to avoid deadlocks, perhaps by enforcing strict resource acquisition orders or using timeout mechanisms, is essential to prevent system freezes or loss of control during flight.
Designing for Scalability and Robustness
As drone hardware evolves with more powerful multi-core processors and specialized accelerators, software designs must be scalable to fully utilize these resources. A well-threaded application can easily adapt to different hardware configurations, distributing its workload efficiently. Robustness is also key; individual thread failures should ideally not bring down the entire system. Implementing proper error handling, thread monitoring, and recovery mechanisms ensures that drone systems remain operational and resilient, even in the face of unexpected events or software anomalies.
The Future of Threading in Drone Tech Innovation
The trajectory of drone technology points towards increasingly autonomous, intelligent, and interconnected systems. The role of threads will only grow in importance, adapting to new computing paradigms and enabling even more sophisticated capabilities.
Multi-core Processors and Heterogeneous Computing
Modern embedded processors in drones are often multi-core, with some even incorporating heterogeneous architectures that combine general-purpose CPUs with specialized GPUs or FPGAs. Threads are the primary mechanism for effectively utilizing these diverse processing units. By offloading computationally intensive tasks like image processing or AI inference to GPU-accelerated threads, and maintaining flight control and communication on CPU threads, drone systems can achieve unprecedented levels of performance and efficiency. This heterogeneous threading model will be crucial for pushing the boundaries of real-time perception and decision-making.
Towards More Sophisticated Autonomy
The ultimate goal for many drone innovations is fully autonomous operation in complex, dynamic environments. This requires a level of intelligence that can perceive, understand, plan, and act with human-like proficiency. Such capabilities demand an orchestration of numerous concurrent processes: continuous self-assessment, predictive modeling of environmental changes, collaborative multi-drone operations, and adaptive mission planning. Threads will continue to serve as the fundamental building blocks for these intricate, interwoven systems, enabling the modularity, responsiveness, and parallel execution necessary to bring true, unassisted autonomy in the skies to fruition. The careful crafting and management of threads are not just technical details but critical enablers for the future of aerial innovation.