
In the dynamic realm of Tech & Innovation, particularly in areas like AI, autonomous flight, mapping, and remote sensing, the term “zeros in a function” transcends its purely mathematical definition to represent critical points, thresholds, and foundational elements for system intelligence and operational precision. Far from being an abstract concept confined to textbooks, the identification and interpretation of these zeros are integral to designing sophisticated algorithms that enable drones to navigate complex environments, process vast datasets, and execute intelligent decisions. Understanding where a function’s output becomes zero, or where it reaches a specific value relative to a baseline, is not just about solving an equation; it’s about pinpointing moments of significance within a continuous system, driving everything from collision avoidance to precise environmental modeling.

Mathematical Models as the Blueprint for Tech
At the heart of virtually every advanced technological system, especially those involving autonomous operations and complex data analysis, lies a foundation of mathematical models. These models are essentially functions designed to describe, predict, or interpret real-world phenomena. Whether it’s the flight dynamics of a quadcopter, the propagation of a radio signal, the spectral characteristics of vegetation detected by a sensor, or the decision-making process of an artificial intelligence, these functions encapsulate the governing principles.
Consider a drone’s flight controller. Its ability to maintain stable flight in varying wind conditions, execute precise maneuvers, or follow a predefined trajectory relies on intricate control loops. These loops continuously feed sensor data (gyroscope, accelerometer, GPS) into mathematical functions that model the drone’s current state and predict its future behavior. An error function, for instance, might quantify the deviation between the desired state (e.g., target altitude or heading) and the actual state. The goal of the control system is to manipulate actuators (motor speeds) to drive this error function towards zero. When the error is zero, the drone is precisely where and how it’s supposed to be. This constant pursuit of “zero error” is a practical application of understanding function zeros.
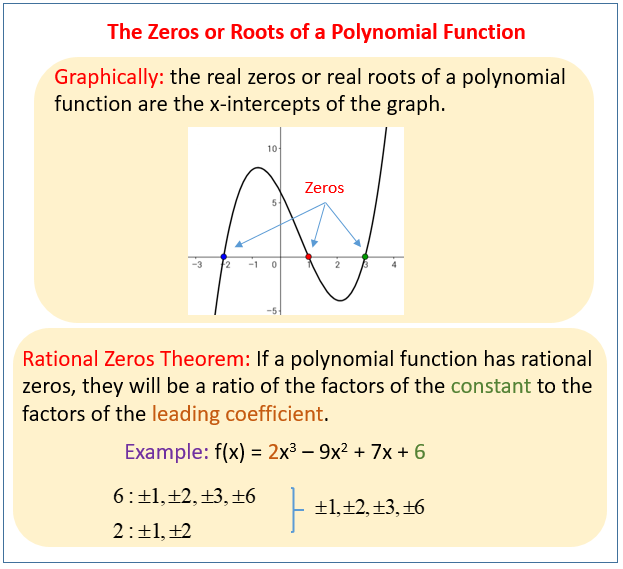
In remote sensing, functions describe the relationship between electromagnetic radiation and surface properties. A specific wavelength’s reflectance from a crop field, for example, can be modeled by a function. Identifying specific “zeros” or thresholds in this function might indicate the presence of disease, water stress, or optimal harvest times. These aren’t necessarily literal zeros in the mathematical sense of f(x)=0, but rather instances where the function reaches a critical value that signifies a change or a boundary, which can be re-contextualized as a zero of a modified function (e.g., f(x) – C = 0).
Zeros as Critical Decision Points in Autonomous Systems
For autonomous drones and AI-powered systems, the “zeros” of a function often represent critical decision boundaries or trigger points for action. This is particularly evident in navigation, obstacle avoidance, and mission planning.
Obstacle Avoidance and Collision Detection
In autonomous flight, a drone uses sensors like LiDAR, ultrasonic, or stereo vision to perceive its environment. The data from these sensors is fed into functions that calculate distances to objects. For example, a function D(x, y, z) might represent the minimum distance to an obstacle from the drone’s current position (x, y, z). A critical threshold for safe operation might be D_min. If D(x, y, z) - D_min approaches zero, it signifies that the drone is at the brink of its safety margin, triggering an avoidance maneuver. If D(x, y, z) itself were to hit zero, it would imply an imminent collision, necessitating immediate evasive action or a complete stop. The ‘zero’ here is a direct indicator of a state that demands immediate, predefined responses to ensure safety and mission success.
Path Planning and Optimization
Autonomous flight path generation often involves complex optimization functions. These functions evaluate potential flight paths based on criteria such as shortest distance, minimum energy consumption, maximum data collection efficiency, or avoidance of restricted airspace. The ‘zeros’ in this context frequently emerge from the derivatives of these cost functions. To find the optimal path (e.g., the path with minimum energy expenditure), algorithms search for points where the derivative of the energy function with respect to path parameters equals zero. These points often correspond to local minima or maxima, guiding the drone’s navigation system towards the most efficient or desired trajectory. For example, a “cost” function C(path) might quantify the resources needed for a path. Finding where dC/d(path_parameter) = 0 leads to an optimized path.
AI Follow Mode and Target Tracking
AI follow modes, where a drone autonomously tracks a moving subject, rely heavily on functions that define the relative position and velocity between the drone and the target. A control function might aim to minimize the distance and relative velocity error between the drone and the subject. When the functions representing these errors reach zero, it means the drone is perfectly tracking the subject at the desired offset. The AI continually adjusts the drone’s flight parameters to drive these error functions towards zero, maintaining a steady, cinematic shot without manual intervention.

Data Interpretation and Feature Extraction in Remote Sensing & Mapping
In mapping and remote sensing, drones collect vast amounts of geospatial data, from photogrammetric imagery to LiDAR point clouds and multispectral scans. Extracting meaningful information from this data often involves applying functions whose “zeros” or specific output values delineate important features or classifications.
Terrain Modeling and Elevation Contours
When creating Digital Elevation Models (DEMs) from drone-acquired data, mathematical functions describe the terrain’s surface. To generate contour lines, which represent points of equal elevation, the process effectively searches for ‘zeros’ of a modified elevation function. For instance, if an elevation function is H(x, y), then a contour line at height h is found where H(x, y) - h = 0. Each contour line is thus a set of points where this difference function is zero, providing a clear visualization of topographical features.
Feature Detection and Classification
In precision agriculture, multispectral sensors gather data on crop health. Indices like the Normalized Difference Vegetation Index (NDVI) are calculated using specific functions of red and near-infrared light reflectance. Thresholds (which can be viewed as ‘zeros’ of a difference function relative to that threshold) applied to these indices help identify areas of healthy vegetation, stressed crops, or bare soil. For example, an NDVI value below a certain threshold might indicate disease. The function (NDVI_value - threshold) = 0 delineates the boundary between healthy and unhealthy regions, enabling targeted intervention.
Similarly, in urban planning, functions might be developed to identify buildings, roads, or bodies of water from aerial imagery. These functions often involve complex algorithms that classify pixels based on their spectral characteristics, texture, and shape. The ‘zeros’ of these classification functions define the boundaries between different land cover types, allowing for automated mapping and inventory.
Optimization and Control Algorithms
The very foundation of robust control systems in flight technology hinges on optimization principles, where the concept of “zeros” plays a pivotal role. Every action a drone takes, from maintaining altitude to executing a complex waypoint mission, is orchestrated by control algorithms designed to optimize performance against various constraints.
PID Controllers and System Stability
Proportional-Integral-Derivative (PID) controllers are ubiquitous in drone flight systems. They work by continuously calculating an “error” value—the difference between a desired setpoint (e.g., target altitude, heading, or speed) and the actual measured value. The PID algorithm then computes an output (e.g., motor thrust adjustments) to drive this error to zero.
- Proportional (P) term: Corrects error based on its current value.
- Integral (I) term: Corrects based on the accumulation of past errors, helping eliminate steady-state errors.
- Derivative (D) term: Corrects based on the rate of change of the error, anticipating future errors.
The entire operation is geared towards making the error functione(t) = (setpoint - actual_value)equal zero, thus achieving stability and accurate control. The ‘zeros’ in this context are the very states of equilibrium and precision the system strives for.
Resource Allocation and Mission Efficiency
Beyond flight stability, optimization extends to mission-level planning. This includes optimizing battery usage, determining the most efficient flight path for surveying a large area, or allocating tasks among multiple drones. These problems are often framed as minimizing a cost function (e.g., total energy consumed) or maximizing a utility function (e.g., amount of data collected). Calculus provides the tools to find the extrema (minima or maxima) of these functions by identifying where their first derivative is zero. For example, if E(t) is the energy consumption function over time for a particular flight profile, finding dE/dt = 0 helps identify points of minimum energy use, informing more efficient mission designs.
In essence, “what are the zeros in a function” within the Tech & Innovation landscape represents the fundamental targets, thresholds, and decision points that mathematical models provide for intelligent systems. From guiding autonomous navigation and ensuring safety to precisely interpreting complex sensor data and optimizing operational efficiency, understanding these critical function outputs is indispensable for pushing the boundaries of what drones and associated technologies can achieve.