
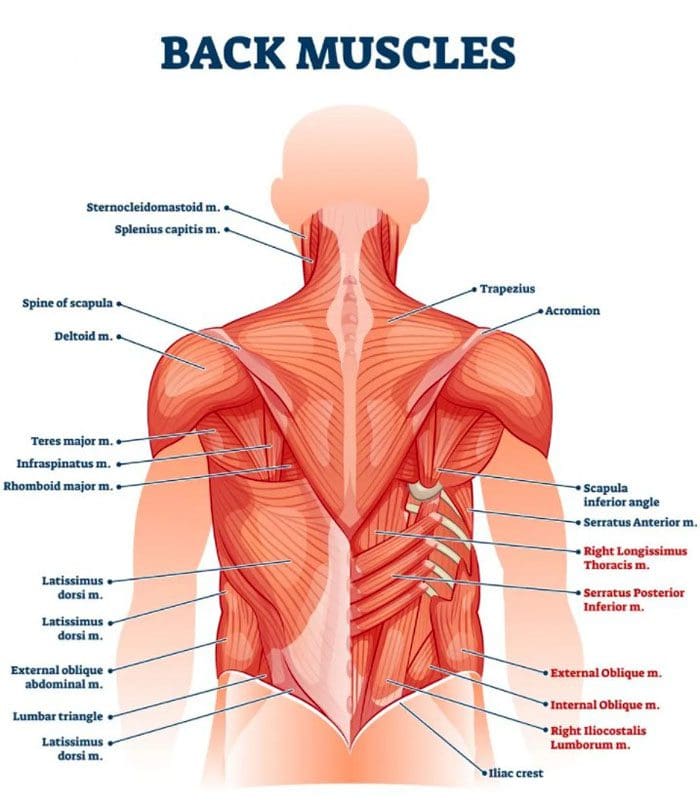
In the sophisticated world of unmanned aerial vehicles (UAVs), particularly drones, the concept of “muscles” takes on a purely mechanical and electronic interpretation. While the term “lat muscles” traditionally refers to a specific group of human back muscles (latissimus dorsi) responsible for arm movement and torso stability, within the context of drone flight technology, this phrase can be metaphorically understood as the intricate systems and components that enable precise lateral control, stability, and maneuverability. These “lat muscles” are the unsung heroes responsible for a drone’s ability to move sideways with precision, counteract wind, maintain a steady hover, and execute complex flight paths. They are fundamental to everything from basic flight to advanced autonomous operations.

Understanding Lateral Dynamics in Drone Flight
To fully grasp what constitutes the “lat muscles” of a drone, it’s essential to understand the fundamental principles of flight dynamics, particularly how a drone moves and maintains equilibrium. Unlike fixed-wing aircraft, multirotor drones achieve lift and control through the independent manipulation of multiple propellers.
Pitch, Roll, and Yaw: The Core Rotations
A drone’s orientation and movement are described using three primary axes of rotation:
- Pitch: Rotation around the lateral (side-to-side) axis, causing the nose of the drone to move up or down.
- Roll: Rotation around the longitudinal (front-to-back) axis, causing the drone to tilt left or right.
- Yaw: Rotation around the vertical axis, causing the drone to rotate horizontally, left or right.
While pitch and roll are directly involved in generating forward, backward, and sideways motion, it is roll that directly dictates lateral movement. By subtly adjusting the thrust of the propellers on one side of the drone relative to the other, the drone can tilt, causing a lateral component of its thrust to propel it sideways. Maintaining this precise roll angle, and thereby its lateral trajectory, against external forces like wind, is where the “lat muscles” truly exert their influence.
Lateral Movement Defined
Lateral movement refers to the drone’s ability to translate horizontally across a plane, specifically along its side-to-side axis, without significant changes in altitude or yaw. This seemingly simple action is incredibly complex to achieve with precision, requiring constant, dynamic adjustments to motor speeds across the airframe. The “lat muscles” of a drone are therefore the sum total of the hardware and software systems that empower this controlled side-to-side drift, counteracting unwanted lateral motion and enabling intentional, precise lateral translation. This capability is paramount for tasks such as tracking a moving subject, inspecting structures from specific angles, or navigating tight spaces.
The Actuators: True “Muscles” of Lateral Control
The literal “muscles” providing the physical force for lateral control are the drone’s propulsion system components. Without these, no amount of sophisticated software could translate commands into movement.
Propellers and Motors: The Thrust Providers
At the heart of a drone’s movement are its propellers and electric motors. Each motor, paired with a propeller, generates thrust. In a multirotor configuration, the motors are arranged such that differential thrust can create torque around any axis. To achieve lateral movement, for instance, the flight controller will command motors on one side of the drone to decrease speed slightly while motors on the opposite side increase speed, creating a roll moment. This tilt then translates a portion of the total vertical thrust into a horizontal, lateral force. The efficiency, responsiveness, and power of these motors and propellers are direct determinants of a drone’s lateral agility and stability. High-quality, balanced propellers and powerful, efficient brushless motors are crucial for instantaneous response to control inputs and external disturbances.
Electronic Speed Controllers (ESCs): Precise Power Delivery
Working in tandem with the motors are the Electronic Speed Controllers (ESCs). These small, yet powerful, circuit boards take signals from the flight controller and convert them into precise electrical power delivered to the motors. For lateral control, the ESCs must be capable of:
- Rapid Response: Instantly increasing or decreasing motor RPM based on flight controller commands to effect quick changes in roll.
- Accurate Speed Control: Maintaining specific motor speeds with high precision, even under varying loads, to ensure smooth and stable lateral translation.
- Efficient Power Management: Minimizing energy loss to maximize flight time, especially during dynamic lateral maneuvers that demand frequent power adjustments.
The synchronization and precision offered by advanced ESCs are critical; any lag or inaccuracy can lead to unstable lateral flight, drifting, or even loss of control. They are the nervous system connecting the brain (flight controller) to the muscles (motors/propellers).
The Brain and Nerves: Flight Controllers and Sensor Integration
While motors and ESCs provide the brawn, the intelligence behind the “lat muscles” resides in the flight controller and its array of integrated sensors. These components form the drone’s central nervous system, constantly sensing its environment and issuing precise commands.
The Flight Controller: Orchestrating Movement
The flight controller is the brain of the drone. It’s a miniaturized computer responsible for interpreting pilot commands, processing sensor data, and sending appropriate signals to the ESCs to adjust motor speeds. For lateral control, the flight controller continuously calculates the drone’s desired position and orientation versus its actual state. If the drone is drifting laterally due to wind or an uncommanded roll, the flight controller immediately calculates the necessary motor adjustments to correct the deviation, restoring stability or initiating a commanded lateral movement. Its processing power and the sophistication of its control algorithms are paramount for responsive and stable lateral flight.

Gyroscopes and Accelerometers: Sensing Lateral Motion
Integrated into the flight controller are Inertial Measurement Units (IMUs), primarily consisting of gyroscopes and accelerometers.
- Gyroscopes: Detect angular velocity, measuring how fast the drone is rotating around its pitch, roll, and yaw axes. This provides critical, real-time feedback on the drone’s current roll angle and its rate of change, directly informing the flight controller about any lateral tilt or instability.
- Accelerometers: Measure linear acceleration along the drone’s three axes. While primarily used for detecting gravity and determining absolute orientation, they also provide crucial data on lateral acceleration, indicating whether the drone is moving sideways and at what rate.
These sensors provide the immediate, high-frequency data streams that allow the flight controller to detect even the slightest lateral disturbance or deviation from the desired path and initiate corrective action with millisecond precision.
GNSS and Barometers: Enhancing Positional Awareness
While IMUs provide local orientation and acceleration data, other sensors enhance the “lat muscles'” ability to maintain or achieve precise lateral positions:
- Global Navigation Satellite System (GNSS), e.g., GPS: Provides absolute positional data, allowing the drone to know its precise latitude, longitude, and altitude. For lateral control, GNSS enables the drone to hold a specific lateral position (GPS Hold mode) or navigate along predefined lateral waypoints. Advanced RTK/PPK GNSS systems offer centimeter-level positional accuracy, crucial for high-precision mapping or inspection tasks where exact lateral placement is vital.
- Barometers: Measure atmospheric pressure to determine altitude. While primarily for vertical stability, maintaining a constant altitude is often a prerequisite for precise lateral movement, ensuring that sideways motion occurs on a consistent plane.
These external sensors provide the broader context that informs the immediate adjustments made possible by the IMU, allowing for both short-term stabilization and long-term positional accuracy.
Algorithms and Control Loops: Coordinating the “Muscles”
The “lat muscles” aren’t just hardware; they are equally defined by the intelligent software algorithms that govern their operation. These algorithms translate raw sensor data and pilot commands into precise instructions for the physical components.
PID Control and Beyond
The most common control algorithm used in drone flight controllers is the Proportional-Integral-Derivative (PID) controller. For lateral control (specifically, roll stabilization), the PID loop constantly performs three calculations:
- Proportional (P): Calculates the immediate response based on the current error (how far off the drone’s current roll angle is from the target roll angle).
- Integral (I): Accounts for accumulated past errors, helping to eliminate steady-state errors and drifts over time (e.g., a persistent lateral drift).
- Derivative (D): Predicts future errors based on the rate of change of the current error, providing a dampening effect to prevent overshooting or oscillations.
Advanced flight controllers utilize sophisticated adaptive PID controllers, Kalman filters, and other state estimation techniques to further refine control, making the “lat muscles” more responsive, stable, and resilient to disturbances.
Dynamic Thrust Vectoring
Beyond simple differential thrust, some advanced drone designs employ thrust vectoring, where the direction of thrust from individual propellers can be altered. While more common in specialized VTOL (Vertical Take-Off and Landing) aircraft, even in standard multirotors, the dynamic and differential application of thrust across the airframe constitutes a form of thrust vectoring. The algorithms behind this dynamically adjust the power to each motor not just to create a tilt but to vector the overall thrust in the precise direction required for desired lateral movement or to counteract an external force. This sophisticated coordination ensures smooth, predictable, and highly stable lateral maneuvers, regardless of flight speed or environmental conditions.
The Criticality of Lateral Control in Drone Applications
The highly tuned “lat muscles” of a drone are indispensable across a vast array of applications, underscoring their importance in modern flight technology.
Precision Navigation and Obstacle Avoidance
For autonomous navigation, industrial inspection, or surveying, a drone’s ability to maintain precise lateral position and execute accurate lateral movements is paramount. During obstacle avoidance, for example, the drone must be able to shift laterally with high precision to circumnavigate an object without overcorrecting or colliding. In delivery or payload drop scenarios, exact lateral positioning over a target is critical for mission success. Advanced sensing systems like LiDAR and vision-based obstacle avoidance rely on robust lateral control to translate their detection into safe flight paths.
Aerial Imaging and Filmmaking Stability
In aerial photography and videography, smooth, stable lateral movement is not just desirable but essential. Jerky or imprecise lateral drifts can ruin cinematic shots, leading to unusable footage. The “lat muscles” here ensure that the drone can hold a static lateral position perfectly, track a subject with fluid sideways motion, or execute complex dolly-like shots where the camera moves horizontally parallel to the subject. The integration of stabilized gimbals further enhances image stability, but the underlying lateral stability of the drone itself is the foundational requirement.
Advanced Autonomous Operations
For cutting-edge applications such as agricultural spraying, structural integrity monitoring, or search and rescue, autonomous lateral control is a core capability. Drones must accurately fly pre-programmed grids, hover precisely at specific points for data collection, or follow complex contours of terrain or structures. These tasks demand not only accurate positional data but also the finely tuned “lat muscles” to execute those lateral commands with unwavering precision and reliability, often in challenging environmental conditions. The responsiveness of these systems directly impacts the safety and effectiveness of autonomous missions, ensuring the drone can react dynamically to unforeseen variables while maintaining its programmed lateral trajectory.
In conclusion, while “lat muscles” might conjure images of human anatomy, in the context of drone flight technology, this metaphorical term encapsulates the complex interplay of propulsion, sensing, and control systems. These “lat muscles” are fundamental to a drone’s ability to achieve stable, precise, and dynamic lateral movement, enabling the sophisticated capabilities that define modern UAV operations.