
In the burgeoning field of drone technology, where autonomous flight, precision mapping, and intelligent remote sensing are becoming commonplace, the reliability of a drone’s “perception” and decision-making processes is paramount. While traditionally a psychological term, “cognitive distortions” can be metaphorically applied to systematic errors or biases in how drone AI and sensor systems perceive, interpret, and act upon environmental data. These distortions, though mechanical or algorithmic in nature, can lead to faulty conclusions, suboptimal performance, and even operational failures, mirroring how human cognitive biases can skew judgment. Understanding these technological “distortions” is crucial for advancing drone autonomy, ensuring safety, and maximizing efficiency in various applications, from AI follow mode to complex mapping missions.
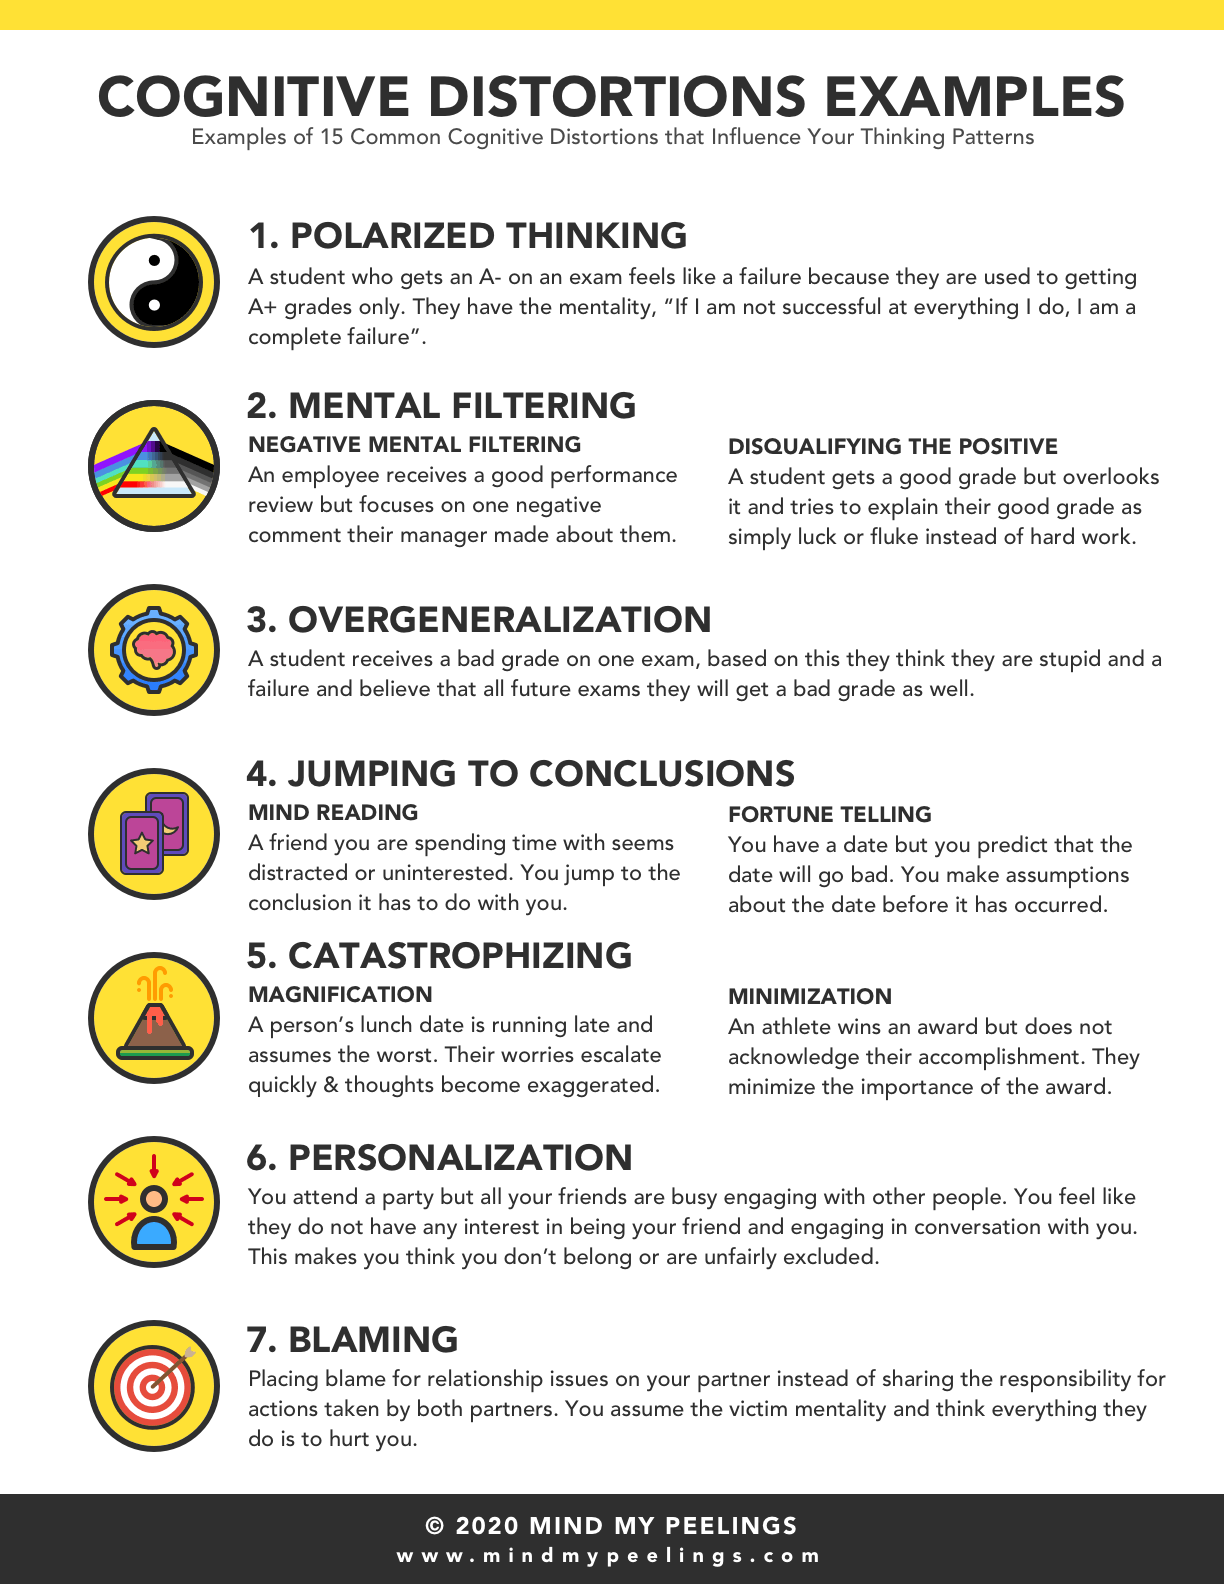
The Analogy of Cognitive Distortions in Artificial Intelligence
Artificial intelligence, particularly in the context of autonomous drones, is designed to emulate certain aspects of human cognition, such as perception, reasoning, and decision-making. When we consider “cognitive distortions” in this domain, we are examining the systemic flaws in an AI’s processing pipeline that lead to an inaccurate or biased “understanding” of its environment. These are not emotional biases, but rather logical or data-driven ones that can result from imperfect sensor data, flawed algorithms, or inadequate training.
Sensor Data Misinterpretation
Just as human eyes can be tricked by optical illusions or poor lighting, drone sensors can misinterpret environmental cues. A “distortion” here might manifest as a visual sensor misidentifying an object due to insufficient training data for that specific scenario, or a thermal sensor misjudging temperature due to reflections. For instance, in an AI follow mode, a drone might “distort” its perception of a moving target’s trajectory if sensor data is noisy or if the algorithm struggles with occlusions, leading to jerky movements or loss of lock. Similarly, lidar or sonar systems might suffer from multi-path reflections in complex urban environments, creating “ghost” obstacles or misjudging distances, akin to a human overgeneralizing a threat. This misinterpretation directly impacts the drone’s ability to build an accurate real-time map of its surroundings, which is fundamental for safe navigation and task execution.
Algorithmic Biases and Heuristics
AI algorithms, especially those based on machine learning, are trained on vast datasets. If these datasets are incomplete, biased, or contain anomalies, the resulting algorithm can develop “cognitive distortions” in its decision-making. For example, an autonomous flight system trained predominantly in open, clear environments might exhibit “catastrophizing” tendencies (a human cognitive distortion) when introduced to a dense forest, perceiving every branch as an insurmountable obstacle due to its limited exposure to complex, navigable foliage. Conversely, it might display “minimization” by underestimating risks in novel situations not adequately represented in its training. These algorithmic biases can lead to inefficient flight paths, unnecessary detours, or even risky maneuvers. The heuristics, or mental shortcuts, employed by the AI to make quick decisions can also be a source of distortion; while useful for speed, they can sometimes lead to systematic errors when the environmental conditions deviate from the assumptions embedded in those shortcuts.
Impact on Autonomous Flight and Navigation
The presence of these “cognitive distortions” within a drone’s AI and sensor systems directly affects its ability to perform autonomous flight and navigation reliably and safely. Precision in these tasks is paramount, whether for delivery, surveillance, or exploration.
Obstacle Avoidance Challenges
Obstacle avoidance is a critical function for autonomous drones. “Cognitive distortions” here can lead to a drone either perceiving obstacles that don’t exist (false positives) or failing to detect actual obstacles (false negatives). A false positive might cause a drone to take an unnecessarily long route, interpreting a shadow as a solid barrier. More dangerously, a false negative, such as ignoring a thin wire or a transparent pane of glass due to sensor limitations or algorithmic biases, can lead to collisions. The “all-or-nothing thinking” (another human cognitive distortion) can manifest as an avoidance system that either overreacts to minor disturbances or becomes complacent in complex environments, failing to adapt its avoidance strategy dynamically. This directly undermines the promise of truly autonomous and safe drone operations, particularly in dynamic and unpredictable settings.
GPS and Positional Drift “Illusions”

While GPS provides a cornerstone for drone navigation, it’s not immune to “distortions.” Multipath interference in urban canyons, signal jamming, or atmospheric conditions can lead to GPS “illusions” – where the drone’s perceived position deviates significantly from its actual location. This is akin to a human experiencing vertigo or disorientation. A drone’s navigation system, relying heavily on GPS, might develop a “filtering” distortion, prioritizing GPS data even when other sensors (like IMUs or vision-based positioning systems) indicate a discrepancy, potentially leading to positional drift. This can be critical for applications requiring high precision, such as package delivery to a specific landing pad or executing precise mapping grids. When the drone’s internal “mental map” of its position is distorted, its ability to execute planned flight paths accurately is severely compromised.
Distortions in Data Acquisition and Analysis
Beyond navigation and flight, drone technology is increasingly vital for data acquisition, including high-resolution mapping and sophisticated remote sensing. “Cognitive distortions” at this stage impact the quality, accuracy, and utility of the collected data.
Mapping Inaccuracies and Spectral Ambiguities
High-resolution mapping requires meticulous data stitching and precise geospatial referencing. Distortions can arise from camera calibration errors, flight path deviations, or software-based rectification issues. For example, a drone performing photogrammetry might create a “catastrophized” model of terrain if inconsistent lighting or shadows cause the photogrammetry software to misinterpret surface features, leading to erroneous elevation data or distorted object shapes. In remote sensing, especially with multispectral or hyperspectral cameras, “spectral ambiguities” can occur. Here, different materials might present similar spectral signatures, causing the AI to “mind read” (another cognitive distortion) and misclassify land cover types. A healthy crop might be misidentified as stressed, or vice versa, based on subtle, misinterpreted spectral data, leading to incorrect agricultural interventions or environmental assessments. These ambiguities are “distortions” in the sense that the drone’s perception of the material world is not an accurate representation of its true properties.
Remote Sensing “Halo Effects”
In remote sensing, a “halo effect” distortion can occur where the interpretation of one data point or feature unfairly influences the interpretation of surrounding or related data. For instance, if a drone’s AI is programmed to identify a particular anomaly (e.g., a specific type of pollution plume) based on a strong, clear signature, it might then over-attribute similar, weaker signals in adjacent areas to the same phenomenon, even if those areas are clear. This is akin to a human jumping to conclusions based on initial strong evidence. Conversely, if the AI’s training data predominantly features anomalies in specific environmental conditions, it might exhibit a “personalization” distortion, interpreting any deviation from those conditions as an anomaly, even when benign. Such distortions can lead to inefficient resource allocation in monitoring, false alarms, or missed critical observations due to misprioritization based on skewed “perceptions.”
Mitigating Distortions for Enhanced Drone Performance
Addressing these “cognitive distortions” is key to unlocking the full potential of drone technology. This involves a multi-faceted approach focusing on robust hardware, sophisticated software, and rigorous validation.
Advanced Sensor Fusion and Redundancy
One of the most effective strategies for mitigating sensor data misinterpretation is advanced sensor fusion. By combining data from multiple, diverse sensors—such as GPS, IMUs, visual cameras, lidar, and thermal imagers—a drone’s AI can cross-reference information and identify inconsistencies. This redundancy acts as a built-in “reality check,” allowing the system to detect and correct “distorted” inputs from a single sensor. For example, if GPS data shows a sudden, unlikely jump in position, the IMU and visual odometry can provide corroborating evidence or contradict the GPS reading, enabling the navigation system to filter out the erroneous data. The goal is to create a more comprehensive and robust “perception” of the environment, reducing the likelihood of any single sensor’s distortion leading to systemic errors.

Machine Learning Refinement and Validation
To combat algorithmic biases and heuristics, continuous refinement and rigorous validation of machine learning models are indispensable. This includes training AI with larger, more diverse, and meticulously curated datasets that represent a broader spectrum of operational environments and conditions. Techniques like adversarial training, where the AI is exposed to data specifically designed to trick it, can help improve its robustness against subtle distortions. Furthermore, employing explainable AI (XAI) techniques can shed light on how algorithms arrive at their decisions, helping developers identify and rectify underlying biases. Regular field testing in varied real-world scenarios, alongside comprehensive simulation environments, allows for the identification of previously unseen “distortions” and the iterative improvement of the drone’s “cognitive” abilities, ultimately leading to more reliable AI follow modes, precise mapping, and safer autonomous flight. By proactively addressing these technological “cognitive distortions,” we can propel drone innovation towards unprecedented levels of intelligence and utility.