
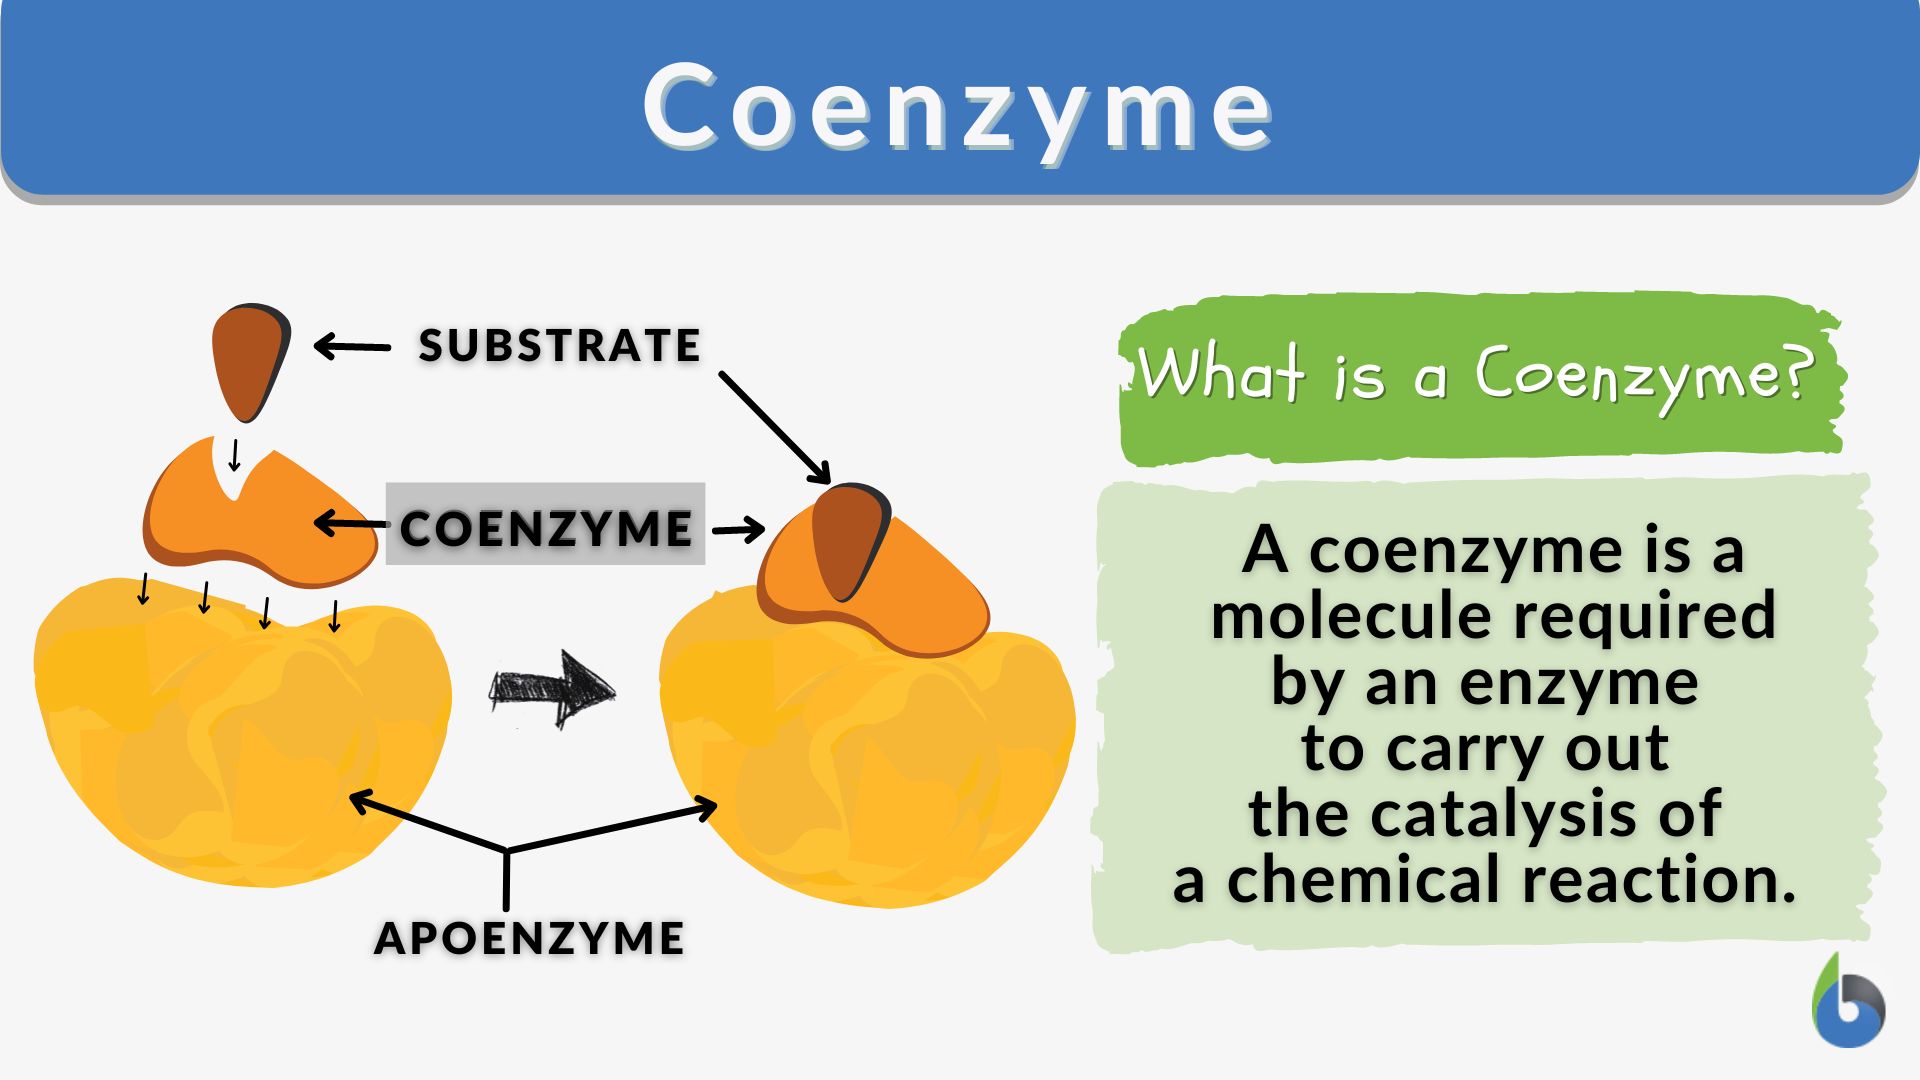
In the intricate ecosystem of modern drone technology, the term “coenzymes” can be thoughtfully applied to the indispensable technological components that facilitate, accelerate, and enable the complex operations of unmanned aerial vehicles (UAVs). Much like biological coenzymes act as non-protein organic molecules essential for enzyme activity, these core flight technologies serve as the critical catalysts and enablers, allowing the drone’s primary systems (its “enzymes”) to perform their advanced functions with precision, stability, and intelligence. Without these fundamental “coenzymes,” the full potential of aerial robotics—from stable flight to autonomous navigation and sophisticated data acquisition—would remain untapped. Understanding these foundational elements is crucial to appreciating the sophistication and future trajectory of drone capabilities.
The Core Catalysts of Stable Flight
The very essence of controlled drone flight hinges upon a set of fundamental “coenzymes” that work tirelessly to maintain stability and execute commands. These are the unsung heroes translating pilot input or autonomous instructions into smooth, predictable aerial maneuvers, countering environmental disturbances, and ensuring the platform remains level and oriented correctly.
Inertial Measurement Units (IMUs)
At the heart of a drone’s stability is the Inertial Measurement Unit (IMU). This sophisticated assembly of sensors acts as the drone’s primary perception of its own motion and orientation in three-dimensional space. Typically comprising accelerometers, gyroscopes, and often magnetometers, the IMU continuously measures linear acceleration, angular velocity, and magnetic field strength. Accelerometers detect changes in velocity, helping to determine the drone’s position relative to gravity. Gyroscopes measure the drone’s rotation rates around its three axes (roll, pitch, and yaw), providing crucial data for correcting unwanted rotations. Magnetometers, or digital compasses, sense the Earth’s magnetic field, providing absolute heading information that helps to mitigate gyro drift over time. The IMU, therefore, is a prime example of a core coenzyme, providing the raw, essential data that catalyses the entire flight stabilization process. Without its precise inputs, a drone would be incapable of maintaining a stable hover or executing controlled movements.
Flight Controllers and Stabilization Algorithms
The data streamed from the IMU requires interpretation and rapid reaction. This is where the flight controller, powered by sophisticated stabilization algorithms, steps in as a vital “coenzyme.” The flight controller is the drone’s brain, processing sensor inputs multiple times per second, comparing the drone’s current state (position, velocity, orientation) with its desired state (as commanded by the pilot or autonomous program). Its embedded algorithms, such as PID (Proportional-Integral-Derivative) controllers, calculate the necessary adjustments to motor speeds and propeller thrusts to correct any deviations. For instance, if a gust of wind causes the drone to tilt, the gyroscopes detect the angular velocity, the flight controller calculates the required counter-thrust, and immediately signals the motors to adjust, restoring the drone to its stable position. This seamless, rapid feedback loop, facilitated by the flight controller and its algorithms, is a classic example of a “coenzyme” enabling the “enzymatic reaction” of stable aerial locomotion. It’s the critical link that translates raw sensor data into actionable control signals, ensuring smooth and predictable flight dynamics.
GPS and Advanced Navigation: The Directional Coenzymes
Beyond mere stability, a drone’s ability to navigate accurately in space, follow predetermined paths, and return to specific locations relies on advanced navigational “coenzymes.” These systems provide the drone with an understanding of its absolute position and facilitate complex aerial maneuvers far beyond manual line-of-sight control.
Global Positioning Systems (GPS/GNSS)
The Global Positioning System (GPS), or more broadly, Global Navigation Satellite Systems (GNSS) encompassing systems like GLONASS, Galileo, and BeiDou, serves as a paramount directional “coenzyme.” By receiving signals from multiple orbiting satellites, the drone’s GNSS receiver can triangulate its precise latitude, longitude, and altitude. This absolute positioning information is fundamental for virtually all modern drone operations, including waypoint navigation, automated flight routes, and accurate data geotagging. While GPS provides essential positional data, its accuracy can be limited by atmospheric conditions, signal obstructions (urban canyons, dense foliage), and inherent system noise. Despite these limitations, it is the primary enabler for a drone to know “where” it is in the world, making it an indispensable coenzyme for spatial awareness.
Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK)
To overcome the accuracy limitations of standard GPS, advanced “coenzymes” like Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) systems are employed. These technologies significantly enhance positional precision down to centimeter levels. RTK involves a drone communicating wirelessly in real-time with a stationary base station (or a network of base stations) on the ground that has a precisely known location. By comparing the satellite signals received by both the drone and the base station, RTTK algorithms can correct for atmospheric and orbital errors, providing highly accurate positional data in real-time. PPK operates similarly but processes the correction data after the flight, often yielding slightly higher accuracy as it can utilize more robust computational models. These systems are crucial “coenzymes” for applications demanding extreme positional accuracy, such as high-precision mapping, surveying, construction site monitoring, and inspection, where every centimeter matters. They transform general location awareness into pinpoint precision.
Visual Positioning Systems (VPS) and Optical Flow
In environments where GNSS signals are weak or unavailable (e.g., indoors, under bridges, dense urban areas), Visual Positioning Systems (VPS) and optical flow sensors act as alternative or supplementary directional “coenzymes.” VPS leverages downward-facing cameras and sometimes ultrasonic sensors to observe patterns on the ground. By continuously capturing images and analyzing the movement of these patterns relative to the drone, the system can estimate its lateral movement and altitude. Optical flow, a key component of VPS, calculates the motion of objects in the camera’s field of view to infer the drone’s velocity and position. These systems are critical for maintaining stability and precise positioning during take-off, landing, and low-altitude flight where GNSS might be unreliable. They essentially provide a localized “map” for the drone, enabling it to maintain position hold and execute controlled movements even without external satellite signals, acting as vital coenzymes for localized spatial awareness.
Sensor Fusion: The Perceptive Enablers
Modern drones are equipped with an array of sensors that extend beyond basic flight control and navigation, providing a rich perception of their surroundings. These perceptive “coenzymes” are critical for advanced functions like obstacle avoidance, terrain following, and environmental data collection. The integration of data from multiple sensor types (sensor fusion) further enhances situational awareness.
Ultrasonic and Infrared Sensors
Ultrasonic and infrared sensors are among the simplest yet effective perceptive “coenzymes” for proximity detection. Ultrasonic sensors emit high-frequency sound waves and measure the time it takes for the echo to return, calculating the distance to objects. Infrared sensors work similarly using infrared light. These are commonly used for short-range obstacle detection, providing data that helps the drone avoid collisions with immediate surroundings. They are particularly effective for detecting objects directly in their path and are essential for maintaining a safe distance from surfaces during automated landings or close-quarter inspections. While their range is limited, they provide critical real-time, low-latency proximity data that complements other, more complex sensing systems.
Lidar and Radar Systems
For more comprehensive and robust environmental perception, especially at greater distances and in challenging conditions, Lidar (Light Detection and Ranging) and Radar systems serve as powerful “coenzymes.” Lidar sensors emit laser pulses and measure the time of flight for each pulse to return, creating a precise 3D point cloud map of the drone’s surroundings. This technology is invaluable for obstacle detection in complex environments, terrain mapping, and even vegetation analysis. Radar systems, conversely, use radio waves, making them less susceptible to adverse weather conditions like fog, rain, or dust, where optical sensors (like Lidar or cameras) might struggle. Radar can detect objects at longer ranges and through obscurants, making it an essential “coenzyme” for all-weather autonomous flight and for detecting fast-moving objects. The data from these systems feeds directly into the flight controller’s decision-making process, enabling proactive avoidance maneuvers.
Vision-Based Obstacle Avoidance
Perhaps the most advanced perceptive “coenzyme” is vision-based obstacle avoidance. Utilizing multiple high-resolution cameras, often stereoscopic, drones can build a real-time 3D understanding of their environment. Computer vision algorithms process these images to identify and track obstacles, map collision hazards, and even classify objects. This technology allows drones to perceive and navigate around complex obstacles dynamically, adjust flight paths in real-time, and perform sophisticated maneuvers in cluttered spaces. Combined with machine learning, vision systems enable drones to understand complex scenarios, making autonomous flight safer and more versatile. They provide a rich, detailed, and intelligent understanding of the world, directly influencing the drone’s operational enzymes to ensure safe and efficient navigation.
Autonomous Flight Systems: The Orchestrating Coenzymes
The culmination of these individual technological “coenzymes” is their synergistic integration into autonomous flight systems. These orchestrating “coenzymes” enable drones to execute complex missions with minimal human intervention, unlocking capabilities that were once purely theoretical.
Mission Planning and Waypoint Navigation
Mission planning software and waypoint navigation systems represent fundamental orchestrating “coenzymes.” Pilots can pre-program intricate flight paths by setting a series of GPS waypoints, defining altitudes, speeds, and specific actions to be performed at each point (e.g., take a photo, activate a sensor). The drone’s flight controller, leveraging its GNSS, IMU, and stabilization “coenzymes,” then executes this pre-defined mission autonomously. This capability is critical for applications like systematic aerial mapping, agricultural spraying, and infrastructure inspection, ensuring consistent data collection and repeatable flight patterns. These systems transform manual piloting into precise, automated operations, greatly enhancing efficiency and data quality.
AI-Driven Object Tracking and Follow Modes
Artificial Intelligence (AI) and machine learning algorithms act as highly sophisticated “coenzymes” when integrated into flight technology, particularly for object tracking and follow modes. By processing real-time video feeds from onboard cameras, AI can identify, classify, and track specific subjects (people, vehicles, animals) and then autonomously adjust the drone’s flight path to maintain a desired distance or angle. This is a powerful enabler for dynamic aerial filmmaking, search and rescue operations, and security surveillance. The AI “coenzyme” dynamically interprets complex visual data and instructs the flight controller to adapt the drone’s movement in a fluid and intelligent manner, a level of autonomy impossible without advanced computational perception.

Precision Landing and Return-to-Home Functions
Even at the end of a mission, specialized “coenzymes” ensure safe and accurate operation. Precision landing systems, often utilizing downward-facing cameras or markers, allow drones to land within a few centimeters of a designated spot, even in challenging conditions. This is vital for battery swapping in drone delivery systems or for sensitive payloads. The Return-to-Home (RTH) function, another critical autonomous “coenzyme,” is a safety feature that automatically guides the drone back to its take-off point or a pre-defined home location when battery levels are low, communication is lost, or a manual command is issued. These functions integrate all the core navigation and stabilization “coenzymes” to execute critical actions reliably, ensuring the drone’s longevity and the success of its missions by providing a fail-safe and automated conclusion to its operations.
In essence, the “coenzymes” of drone flight technology are the integrated, interdependent systems that provide stability, spatial awareness, environmental perception, and intelligent autonomy. They are the non-propulsive, non-structural elements that unlock and catalyze the full operational capabilities of the drone, transforming it from a simple flying machine into a sophisticated aerial robot capable of executing complex tasks with precision and reliability. As these technologies continue to evolve, the capabilities and applications of UAVs will expand exponentially, driven by ever more advanced and integrated “coenzymes.”