
In the dynamic world of drone technology and innovation, from autonomous flight to sophisticated mapping and AI-driven features, the underlying mathematical principles are as crucial as the hardware itself. Among these foundational concepts, polynomials play an indispensable role in modeling, prediction, and control. Understanding “terms in a polynomial” isn’t merely an academic exercise; it’s key to comprehending how drones achieve precise navigation, smooth trajectories, and accurate data collection.
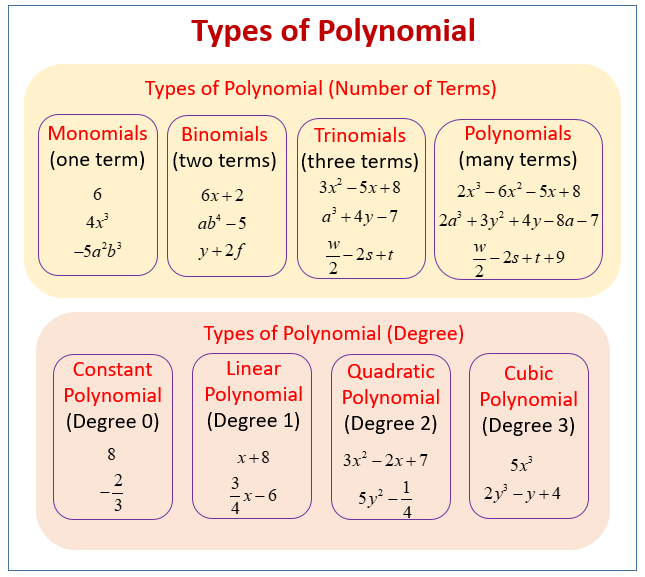
At its core, a polynomial is an expression consisting of variables and coefficients, involving only the operations of addition, subtraction, multiplication, and non-negative integer exponents of variables. Each individual component within this expression, separated by addition or subtraction, is known as a “term.” These terms are the fundamental building blocks that engineers and data scientists manipulate to sculpt the behavior and intelligence of modern UAVs.
The Fundamental Building Blocks: Understanding Polynomials in Drone Tech
To appreciate the impact of polynomials in drone innovation, we must first dissect what constitutes their individual terms. This understanding then paves the way for grasping their broad utility in diverse applications, from predicting flight paths to correcting sensor data.
Defining Terms: Coefficients, Variables, and Exponents
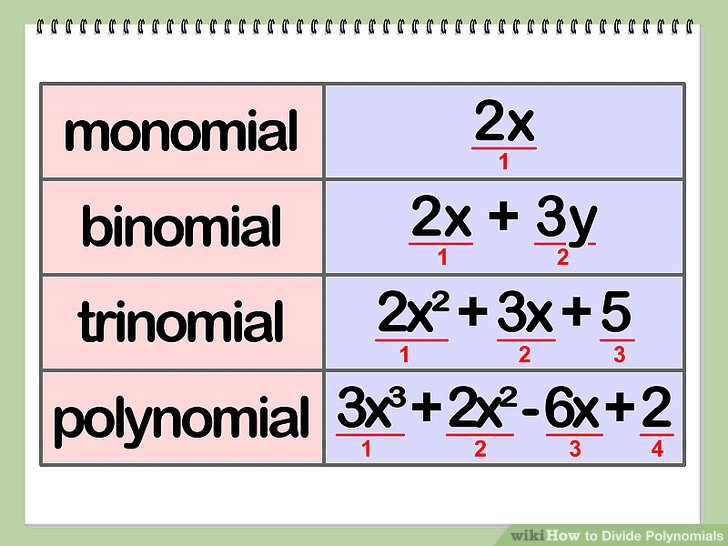
A term in a polynomial is a product of a coefficient, one or more variables, and their respective exponents. For instance, in the polynomial $3x^2 + 2x – 5$:
- $3x^2$ is one term.
- $2x$ is another term (where $x$ implicitly has an exponent of 1).
- $-5$ is the third term (a constant term, which can be thought of as $-5x^0$).
Let’s break down each component of a term:
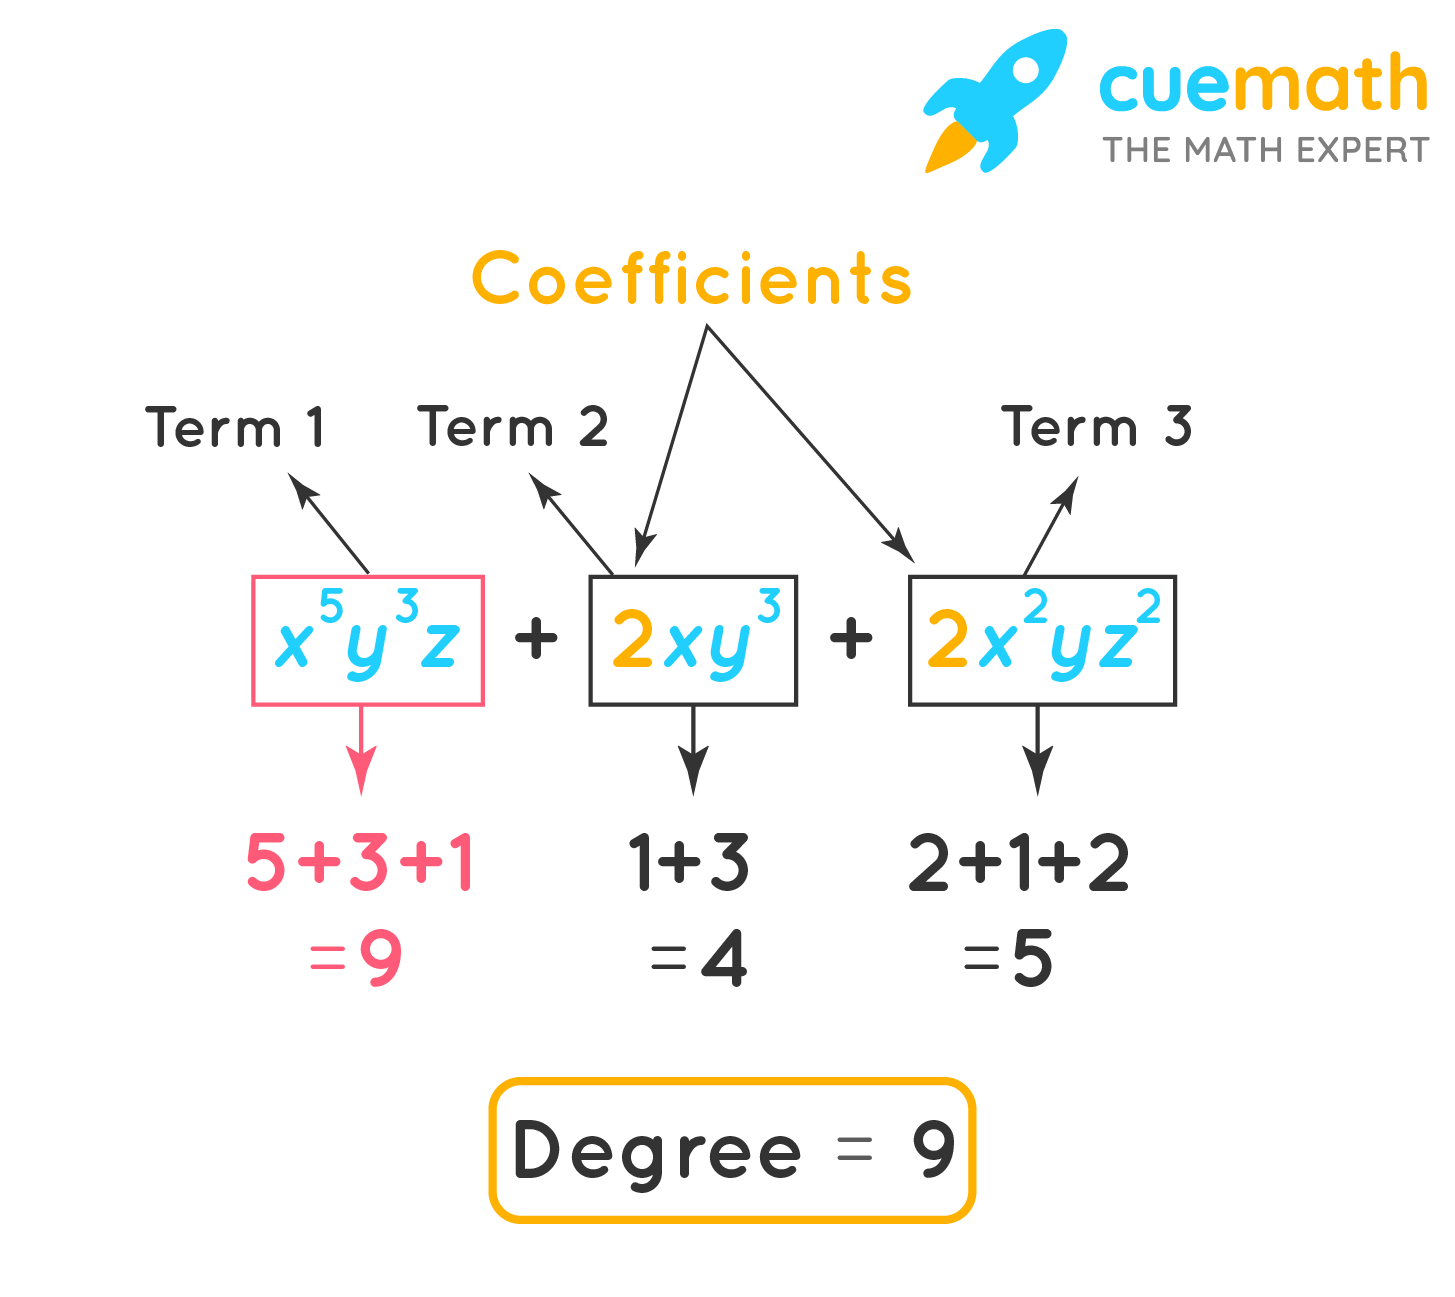
- Coefficient: This is the numerical factor that multiplies the variable part of the term. In the term $3x^2$, ‘3’ is the coefficient. In drone applications, coefficients often represent specific physical parameters, scaling factors, or learned weights in an algorithm. For instance, in a polynomial representing a drone’s velocity profile, a coefficient might dictate the maximum acceleration or deceleration rate.
- Variable: Typically represented by letters like $x$, $y$, or $t$ (for time), variables denote quantities that can change or vary. In drone navigation, variables might represent position coordinates $(x, y, z)$, velocity components, angular rates, or time. The manipulation of these variables through polynomial expressions allows for the dynamic modeling of drone states.
- Exponent: A non-negative integer indicating the power to which the variable is raised. In $3x^2$, ‘2’ is the exponent. The degree of the exponent dictates the complexity and curvature of the relationship being modeled. Higher-degree polynomial terms allow for more complex curves and surfaces, which are essential for generating intricate flight paths or accurately modeling complex terrain from remote sensing data. A term with an exponent of 0 (e.g., $5x^0$) simplifies to just the coefficient, as any non-zero number raised to the power of 0 is 1. These are known as constant terms and often represent offsets or initial conditions.
The sum of the exponents of the variables in a term is the degree of that term. The highest degree of any term in a polynomial determines the degree of the polynomial itself. This degree is a critical factor influencing the computational complexity and the fitting capability of the polynomial model.
The Power of Polynomials: Modeling and Approximation
Why are these structured expressions so vital? Polynomials offer a robust and flexible framework for modeling a vast array of phenomena critical to drone innovation:
- Approximation: Many complex functions that describe physical systems (like atmospheric drag on a drone or the non-linear response of a sensor) can be challenging to work with directly. Polynomials can approximate these functions over specific ranges with remarkable accuracy. This approximation simplifies calculations, enabling real-time processing required for autonomous flight.
- Smoothness: Polynomials are inherently smooth and continuous, making them ideal for generating trajectories and curves. A drone’s flight path, for example, needs to be smooth to avoid abrupt maneuvers that could destabilize the aircraft or compromise cinematic footage.
- Computational Efficiency: While higher-degree polynomials can become complex, their evaluation primarily involves basic arithmetic operations (addition, subtraction, multiplication). This makes them computationally efficient, a significant advantage for resource-constrained drone processors needing to perform calculations rapidly.
- Predictability: By fitting polynomial models to observed data (e.g., a target’s movement pattern), drones can predict future states, which is fundamental for features like AI follow mode.
Understanding the components of a polynomial term is the first step towards leveraging their power in advanced drone applications, providing the mathematical bedrock for intelligent flight and sophisticated data analysis.
Powering Autonomous Flight and Trajectory Planning
Autonomous flight is perhaps one of the most compelling applications of advanced drone technology, and polynomials are at its heart. The ability for a drone to plan and execute a flight path without constant human intervention relies heavily on mathematical models that describe desired movement.
Smooth Path Generation and Spline Interpolation
For a drone to navigate an environment, whether it’s inspecting infrastructure or delivering a package, it must follow a pre-defined or dynamically generated path. These paths cannot be jagged or unpredictable; they must be smooth, continuous, and adhere to the drone’s kinematic and dynamic constraints. This is where polynomial terms become crucial in techniques like spline interpolation.
Splines are piecewise polynomials used to construct smooth curves that pass through a set of given waypoints. For example, a cubic spline uses third-degree polynomials (meaning terms like $ax^3$, $bx^2$, $cx$, and $d$) to connect successive waypoints. Each segment of the flight path between two waypoints is defined by its own polynomial. The coefficients of these polynomial terms are carefully chosen to ensure not only that the curve passes through the waypoints but also that the transitions between segments are smooth—meaning the position, velocity, and often acceleration are continuous at the waypoints.
If the coefficients of these polynomial terms were not precisely calculated, the drone would experience abrupt changes in direction or speed, leading to oscillations, inefficiency, or even loss of control. The exponents (e.g., $x^3$) dictate the curve’s flexibility, allowing for complex, yet smooth, trajectories that can weave through obstacles or maintain a specific flight profile. These mathematically generated paths enable drones to perform intricate maneuvers, conduct efficient searches, or execute delicate landing procedures with precision and stability.
Predicting Motion for AI Follow Mode
AI follow mode, where a drone autonomously tracks a moving subject, is another testament to the utility of polynomial terms. To effectively follow a person, vehicle, or animal, the drone needs to predict its subject’s future position. Simple linear extrapolation is often insufficient, especially if the subject moves in non-linear patterns (e.g., accelerating, turning).
Polynomial regression is a statistical technique where the relationship between the independent variable (often time) and the dependent variable (subject’s position) is modeled as an nth-degree polynomial. By fitting a polynomial to a series of past observed positions of the target, the drone can infer the pattern of movement. The terms within this polynomial (e.g., $at^2 + bt + c$) contribute to shaping the predictive curve.
- The constant term ($c$) might represent the initial position.
- The linear term ($bt$) could account for constant velocity.
- The quadratic term ($at^2$) would model constant acceleration.
Higher-degree terms allow for modeling more complex, varying rates of change in velocity or acceleration, providing a more accurate short-term prediction of the subject’s trajectory. This predictive capability allows the drone to anticipate the subject’s movements and adjust its own flight path smoothly, ensuring the subject remains in frame without needing reactive, jerky corrections. The coefficients of these polynomial terms are dynamically updated as new data comes in, allowing the drone’s AI to adapt to changing movement patterns.
Enhancing Mapping and Remote Sensing Precision
The precision of data gathered by drones for mapping and remote sensing applications is paramount. Whether creating detailed 3D models of terrain or analyzing crop health, the accuracy of the spatial information relies heavily on mathematical corrections and modeling, where polynomial terms again play a critical role.
Geometric Correction and Calibration
Drone cameras, like all optical systems, are subject to various distortions. Lens distortion (radial and tangential), for example, causes straight lines in the real world to appear curved in an image, especially towards the edges. To produce geometrically accurate maps and 3D models, these distortions must be precisely corrected.
Polynomials are widely used in camera calibration models to describe and correct these geometric distortions. A common approach involves fitting polynomial functions to the observed distortion patterns. Each term in these polynomials (e.g., $k1r^2 + k2r^4 + dots$ for radial distortion, where $r$ is the radial distance from the image center) contributes to modeling different aspects of the distortion.
- The coefficients ($k1, k2$) are specific calibration parameters determined through a calibration process.
- The exponents ($r^2, r^4$) dictate the non-linear nature of the distortion.
By applying the inverse of these polynomial models, every pixel in a distorted image can be mapped to its corrected, geometrically accurate position. This ensures that distances, angles, and shapes derived from drone imagery are precise, which is critical for applications like surveying, construction monitoring, and disaster assessment where minute inaccuracies can have significant consequences. Similar polynomial models are used to correct for platform tilt and other orientation errors during photogrammetric processing, ensuring that the final output aligns perfectly with real-world coordinates.
Surface Modeling and Data Interpolation
When drones collect data points from a landscape, such as elevations for a Digital Elevation Model (DEM) or temperature readings for environmental monitoring, these points are discrete. To create a continuous surface or fill in gaps where data might be sparse, interpolation techniques are employed, and polynomials are often at the forefront.
Polynomial surface fitting, for instance, involves constructing a polynomial function in two variables ($x$ and $y$) that best describes the terrain’s height ($z$) or a temperature field across a given area. Terms in such a polynomial might look like $ax^2 + by^2 + cxy + dx + ey + f$.
- The coefficients ($a, b, c, dots$) are determined by minimizing the error between the polynomial surface and the actual measured data points.
- The combinations of variables ($x, y, xy$) and their exponents allow the model to capture the curvature and slope of the surface in two dimensions.
This method allows for the creation of smooth, continuous representations of complex terrains or environmental fields. For remote sensing, where data might be collected irregularly or have small gaps due to obstacles or sensor limitations, polynomial interpolation can provide robust estimates for missing values, enabling comprehensive analysis and visualization. The degree and combination of terms chosen for the polynomial significantly impact the fidelity and smoothness of the interpolated surface, directly influencing the accuracy of subsequent analyses like volumetric calculations or hydrological modeling.
Optimizing Control Systems and Sensor Fusion
The ability of a drone to maintain stable flight, execute complex maneuvers, and interpret its environment relies heavily on sophisticated control systems and effective sensor fusion. Polynomial terms are foundational elements within the algorithms that manage these critical functions, ensuring responsive and reliable operation.
Filter Design and Signal Processing
Drones are equipped with an array of sensors—IMUs (Inertial Measurement Units) providing acceleration and angular velocity, GPS for position, barometers for altitude, and more. The data from these sensors is inherently noisy and subject to errors. To extract meaningful information, signal processing techniques, often involving filters based on polynomial models, are employed.
Kalman filters, for example, widely used in drone navigation and state estimation, rely on linear models. However, when dealing with non-linear system dynamics or sensor characteristics, Extended Kalman Filters (EKF) or Unscented Kalman Filters (UKF) are used, which often linearize or approximate non-linear functions using polynomial expansions (like Taylor series expansions). The terms in these polynomial approximations allow the filter to handle the complexities of real-world physics, such as non-linear drag or sensor biases, converting raw, noisy measurements into accurate and reliable estimates of the drone’s position, velocity, and orientation.
Similarly, in digital signal processing, polynomial FIR (Finite Impulse Response) or IIR (Infinite Impulse Response) filters can be designed. The coefficients of the polynomial terms define the filter’s characteristics—its ability to smooth data, remove specific frequencies of noise, or enhance certain signal components. For a drone’s flight controller, filtering noisy gyroscope data using polynomial-based filters is essential to prevent erroneous control inputs, ensuring stable and precise flight.
Predictive Control for Dynamic Environments
Beyond simply reacting to current sensor data, advanced drone control systems incorporate predictive capabilities to anticipate future states and plan control actions proactively. This is especially vital in dynamic environments, such as flying through gusts of wind or navigating around moving obstacles. Predictive control strategies, like Model Predictive Control (MPC), frequently utilize polynomial models.
In MPC, a dynamic model of the drone and its environment is used to predict the system’s future behavior over a short time horizon. This model often includes polynomial terms to describe how the drone responds to control inputs (e.g., motor speeds) and how external disturbances (e.g., wind) might affect its trajectory. For instance, a polynomial model might predict a drone’s position ($x, y, z$) as a function of time ($t$) and control inputs.
The terms in these predictive polynomials allow the control algorithm to simulate various control sequences and choose the one that optimizes a given objective (e.g., minimize error to a target path, minimize energy consumption) while respecting constraints (e.g., maximum acceleration, obstacle avoidance). The coefficients of these polynomial terms are continuously updated or identified to ensure the model accurately reflects the current conditions. This forward-looking approach, enabled by the predictive power of polynomial terms, empowers drones to react intelligently to changing conditions, execute smoother maneuvers, and maintain robust performance even in complex, unpredictable settings.
In conclusion, “terms in a polynomial” are far from abstract mathematical curiosities. They are the granular elements of mathematical expressions that imbue drones with the intelligence and precision required for autonomous navigation, sophisticated data capture, and adaptive control. From the smooth curves of a flight path to the accurate correction of sensor distortions and the predictive power behind AI features, polynomials, through their carefully constructed terms, are silent enablers of cutting-edge drone innovation.